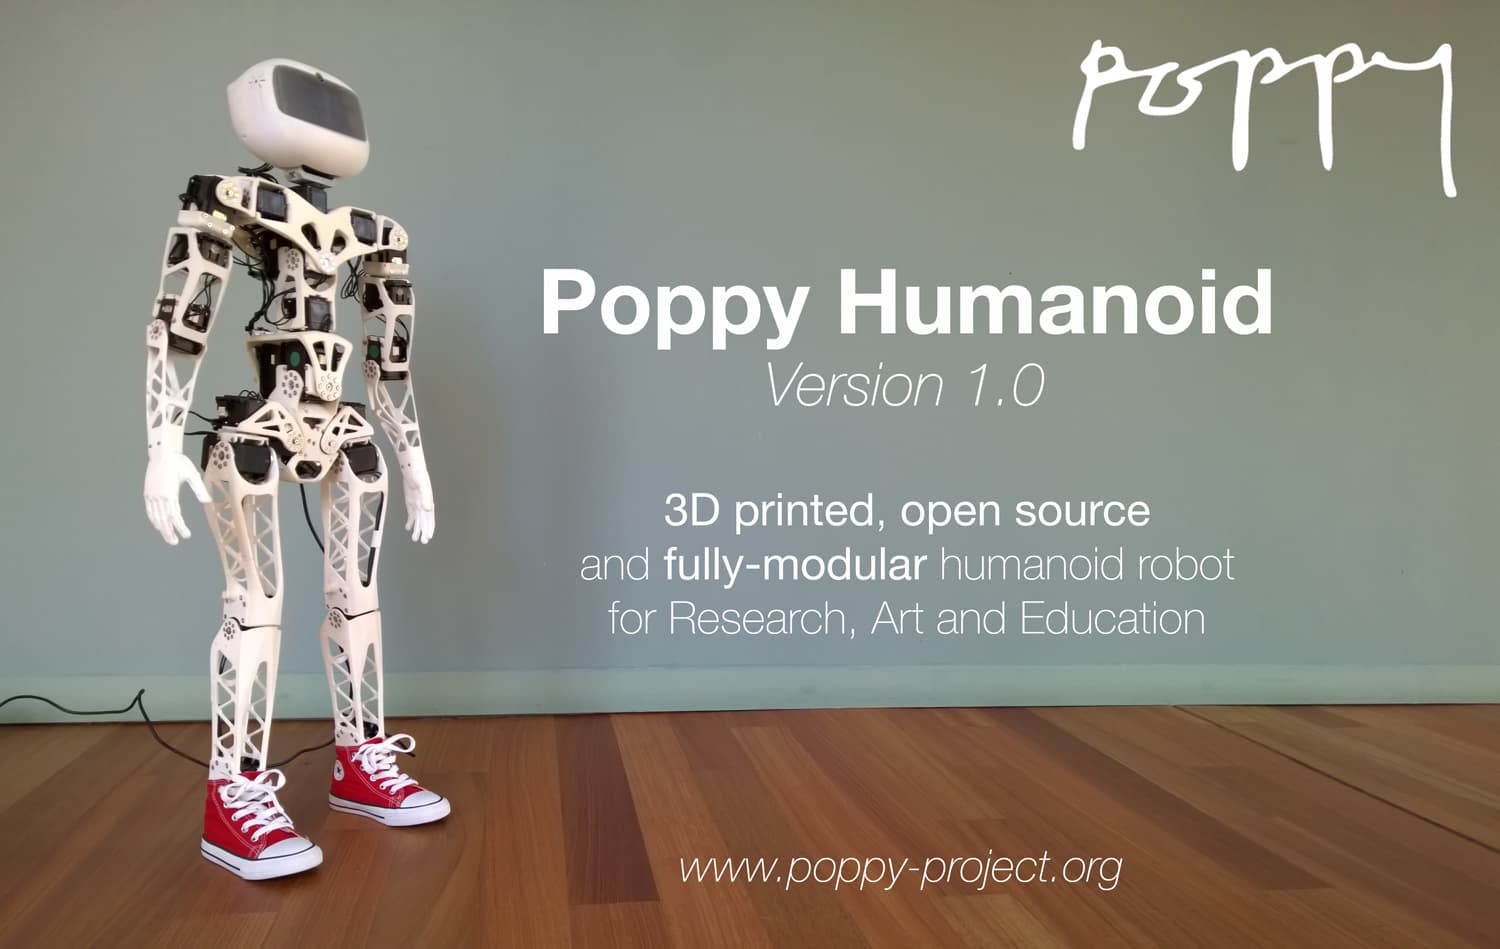
Poppy Humanoid
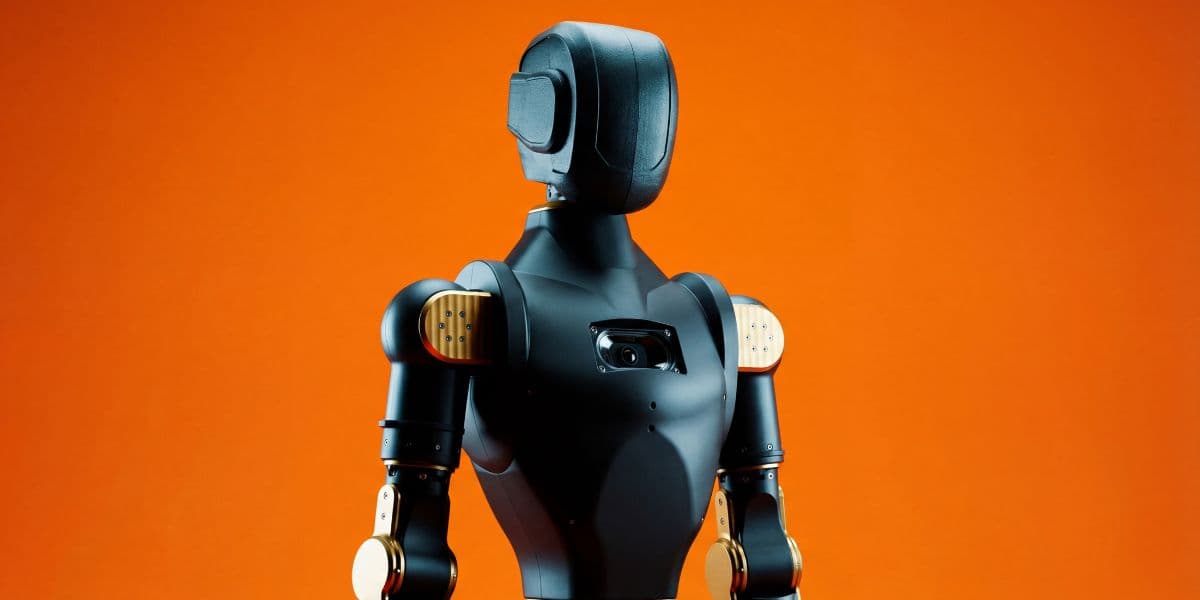
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 5 · Ready to build first, then by buildability
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
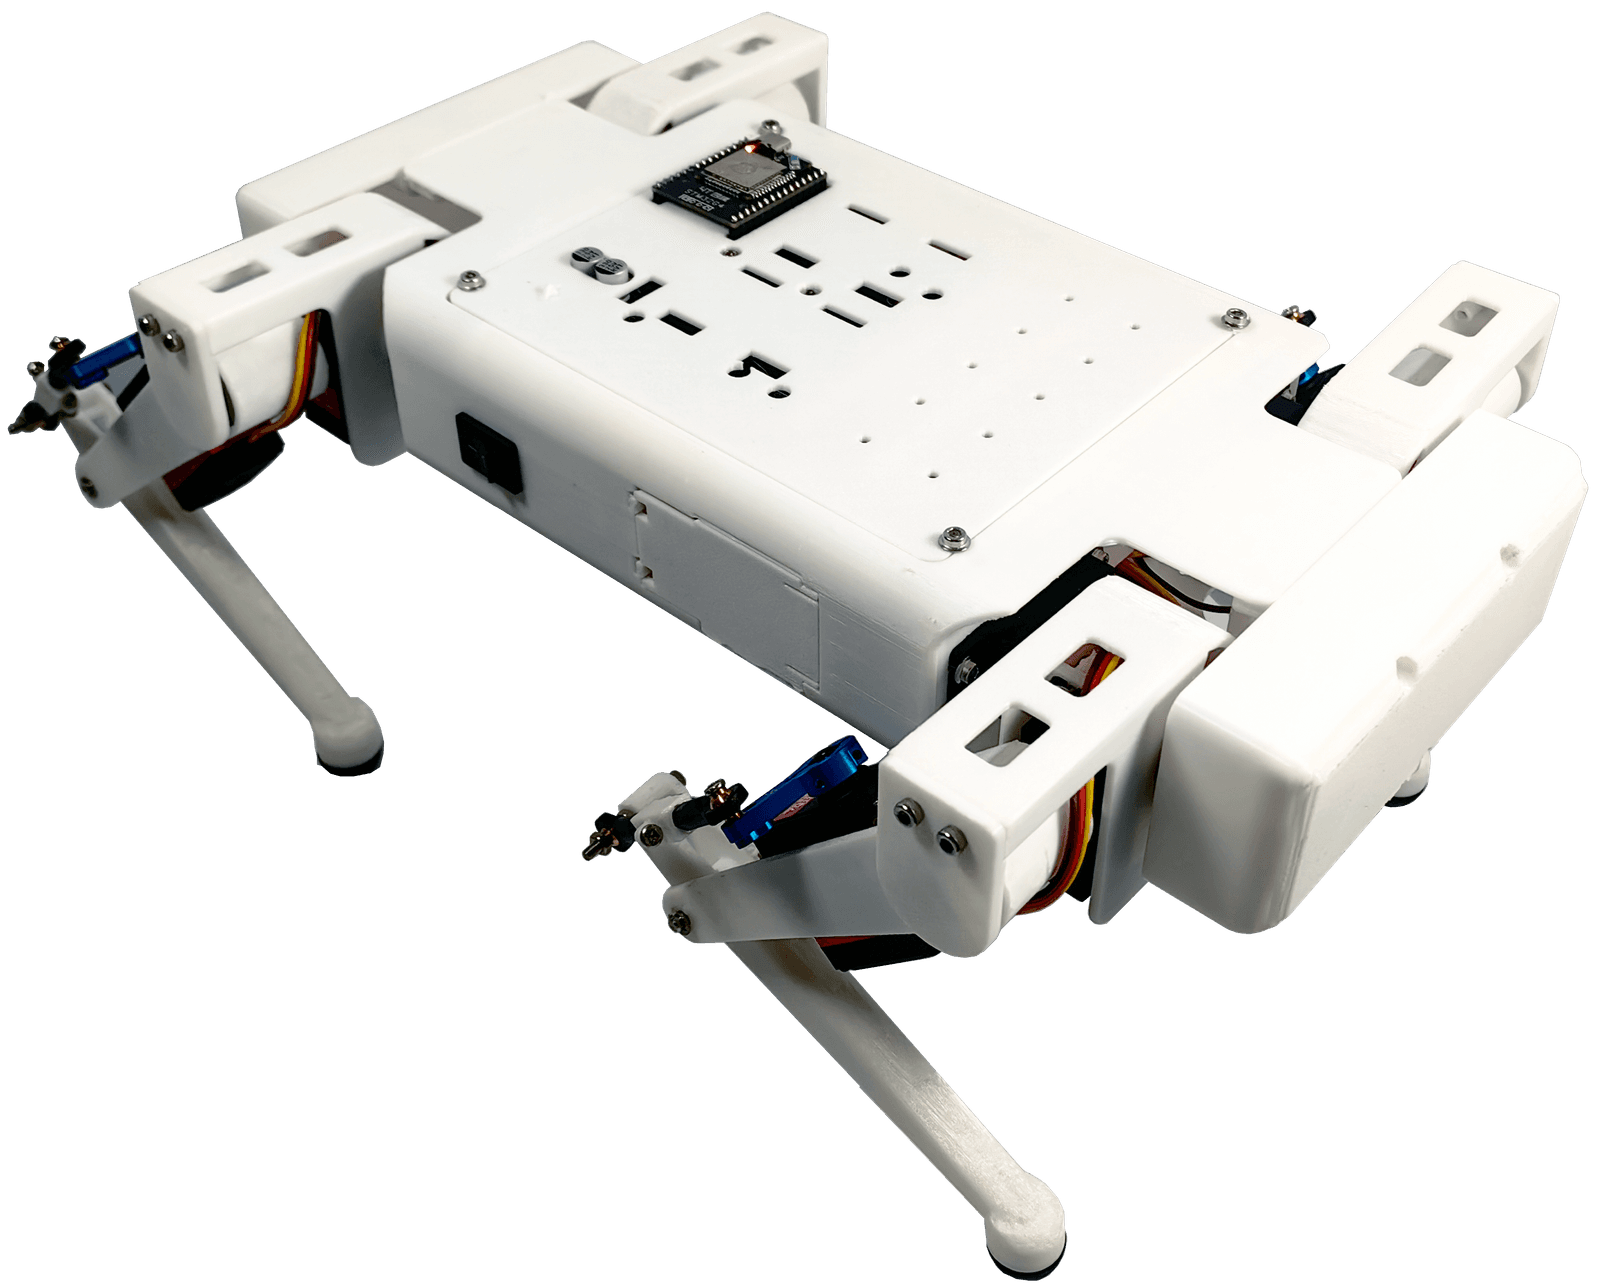
A low-cost 12-DOF quadruped robot actuated by hobby servos, with optional feet sensors and a trot gait firmware.
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
An open and affordable ESP32-based mini quadruped robot with an OLED face that walks, waves and dances.
A 7-DOF personal robotic arm with ROS-based simulation and control.
A safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.
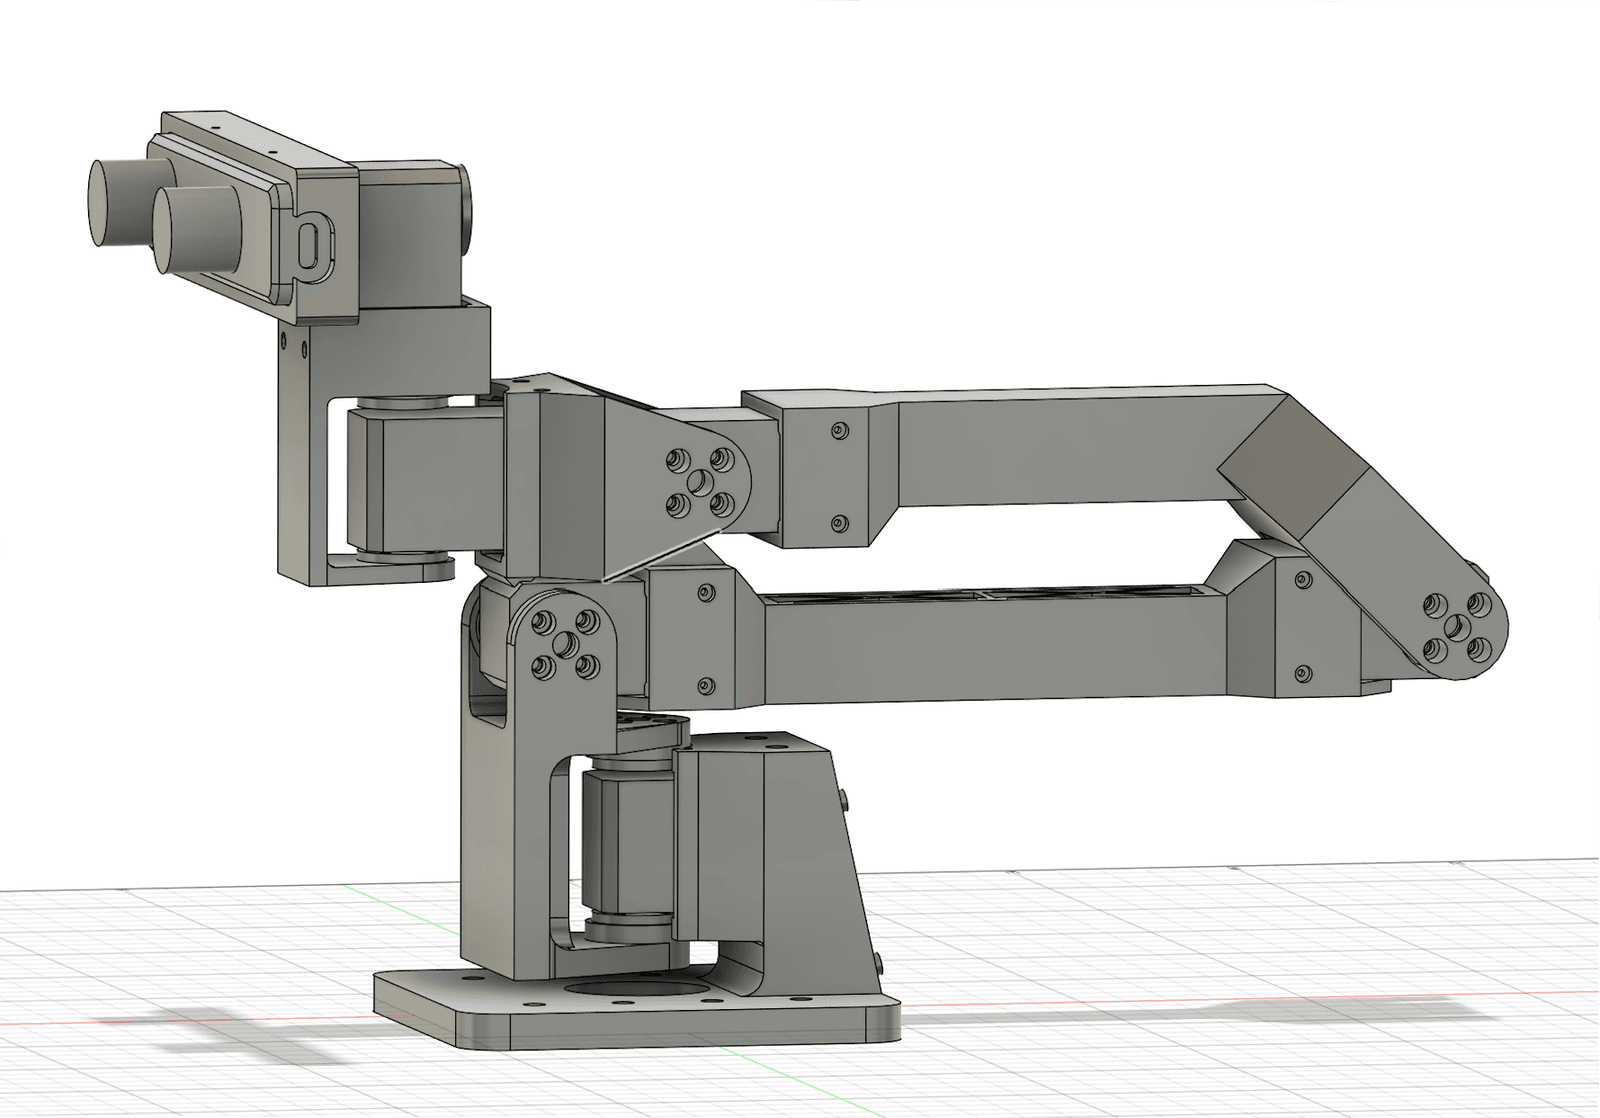
A 6-DOF camera arm with a ZED Mini stereo camera that streams video to a WebXR VR headset and follows head tracking for teleoperation.
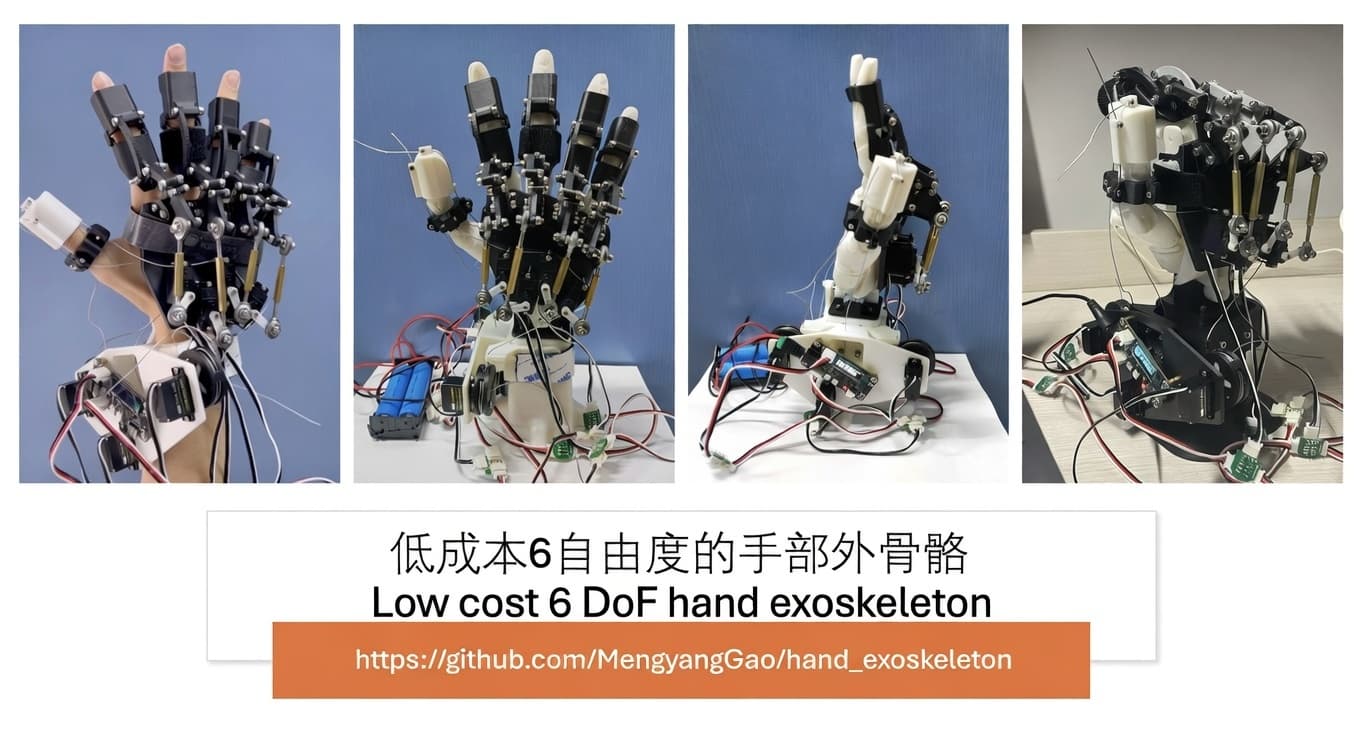
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
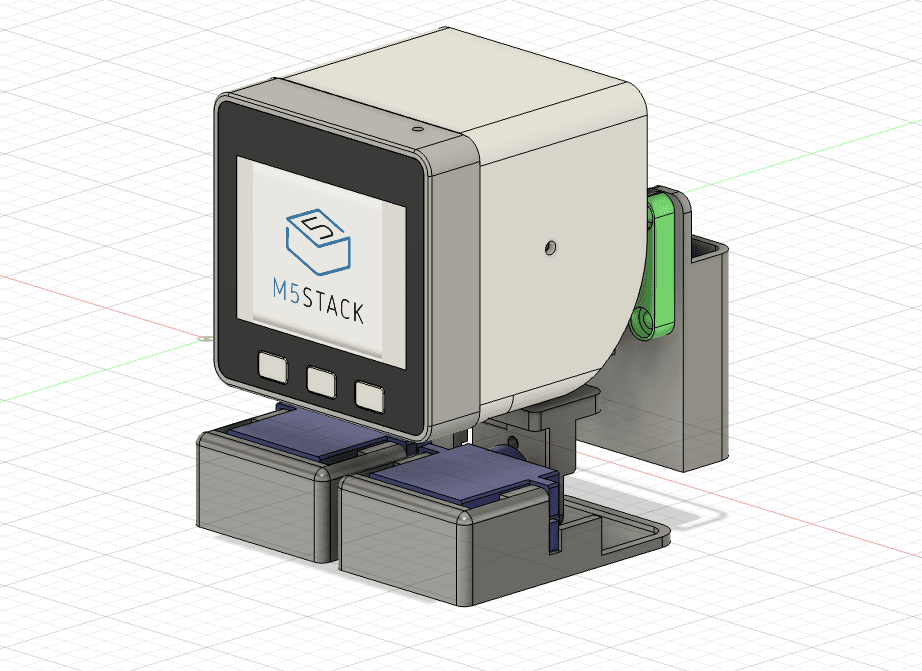
A small bipedal walking robot controlled by an M5Stack board, with a sliding battery that shifts its balance between legs.
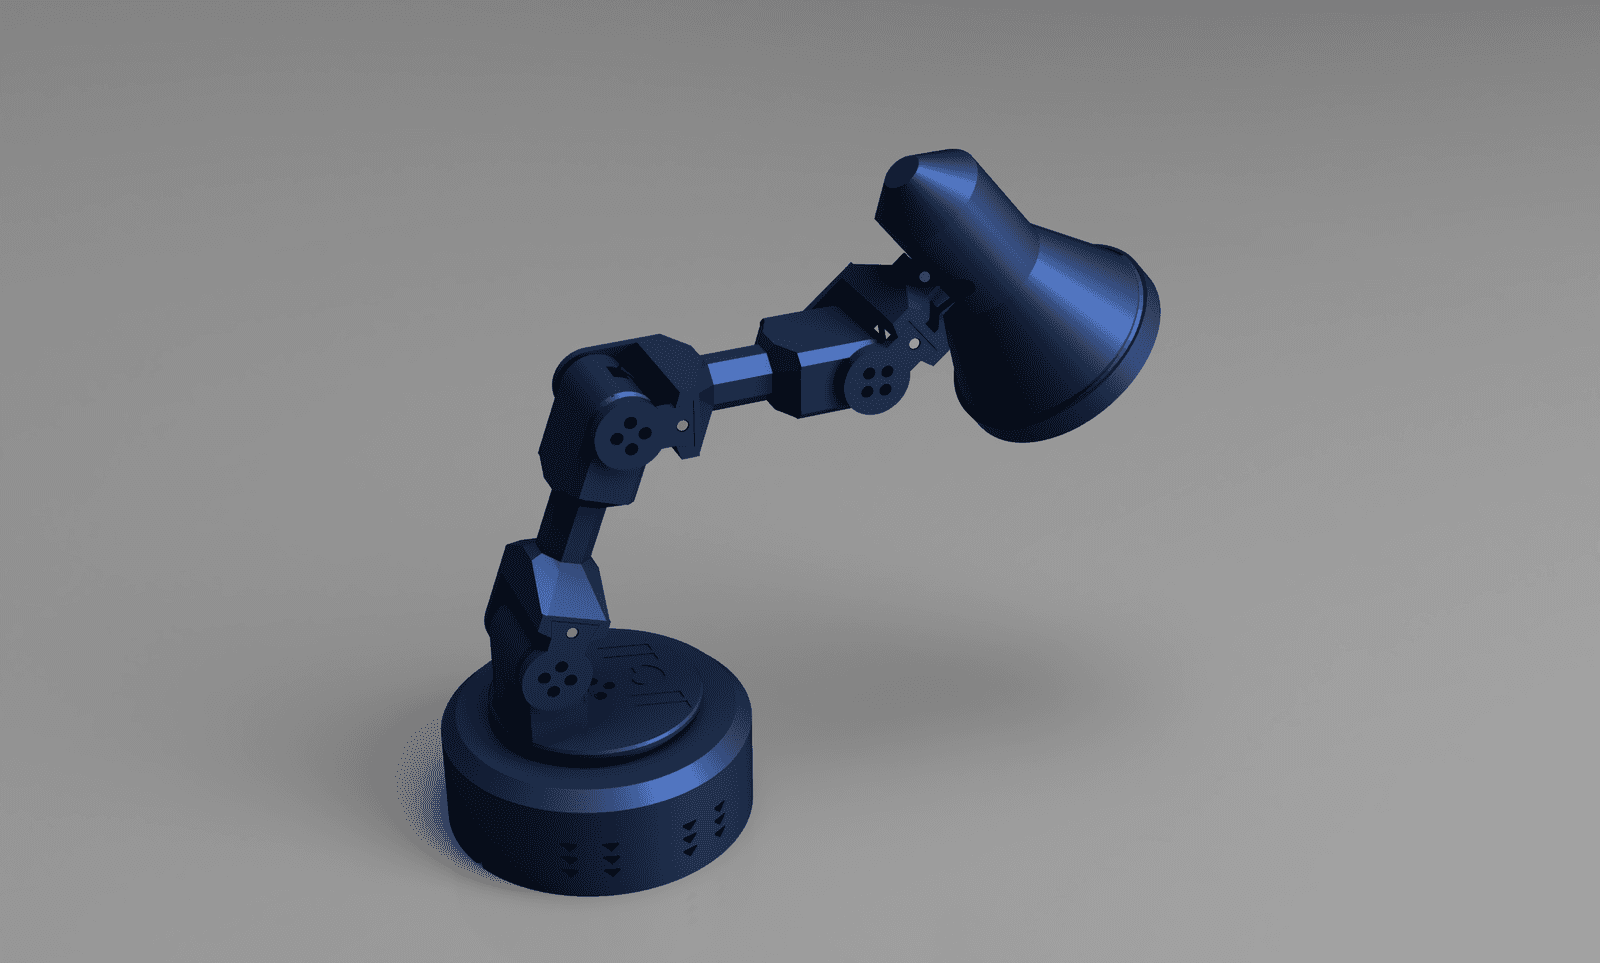
NormaCore is a unified open-source toolkit and platform for developing and operating physical systems, including a 7+1 DoF 3D-printed robotic arm (ElRobot) and a desk lamp.
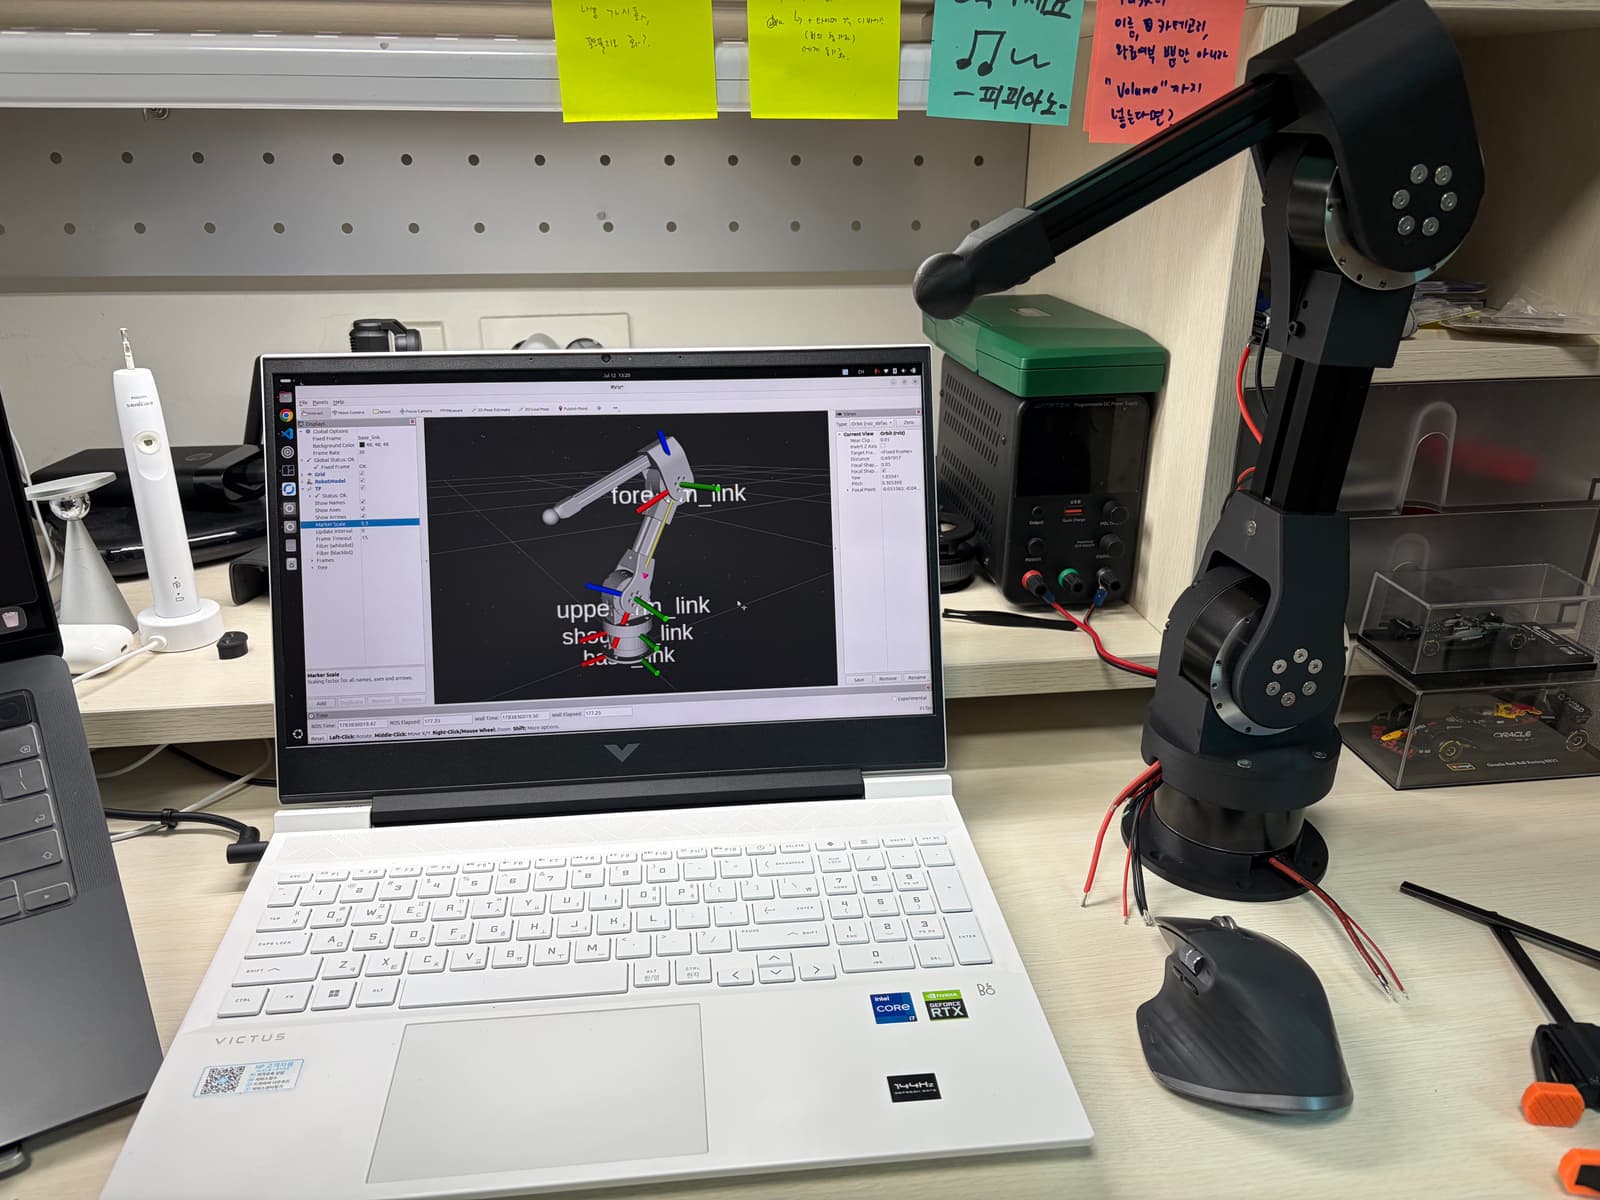
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
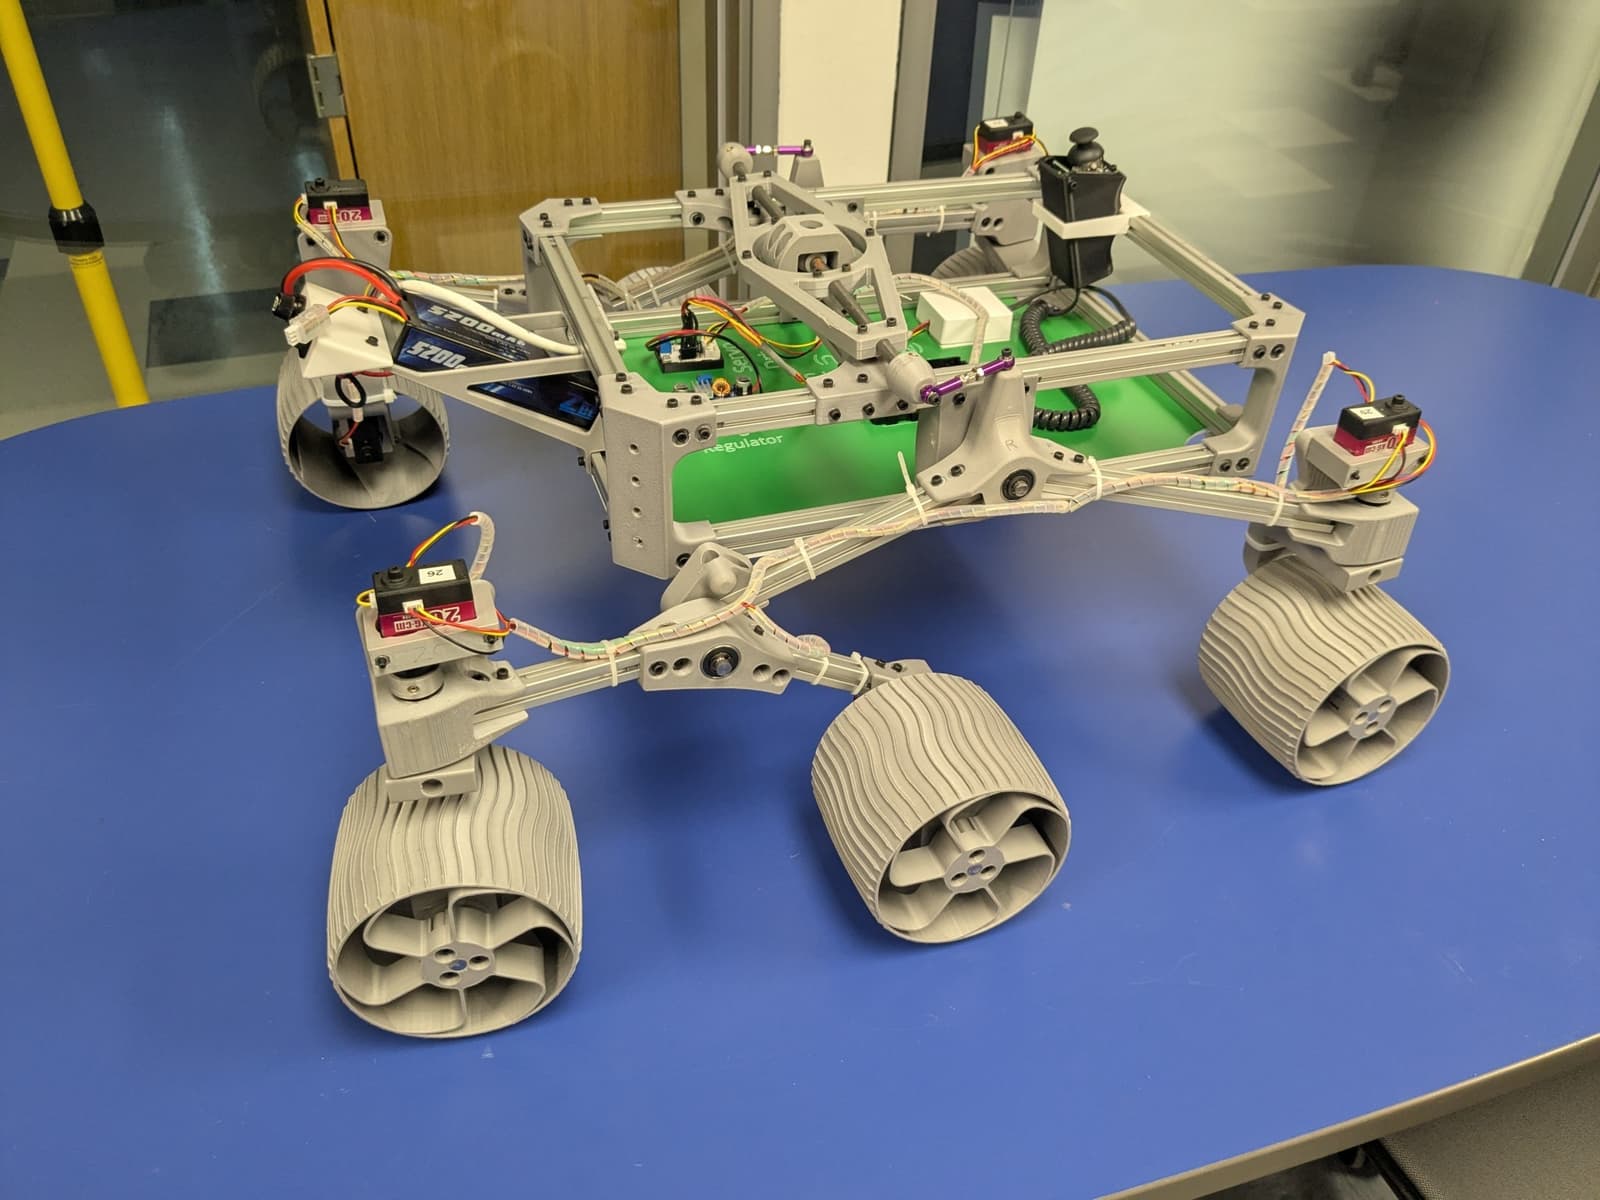
A motorized model of Mars rovers Curiosity and Perseverance that reproduces Rocker-Bogie suspension, built with 3D-printed parts and serial bus servo wheels.
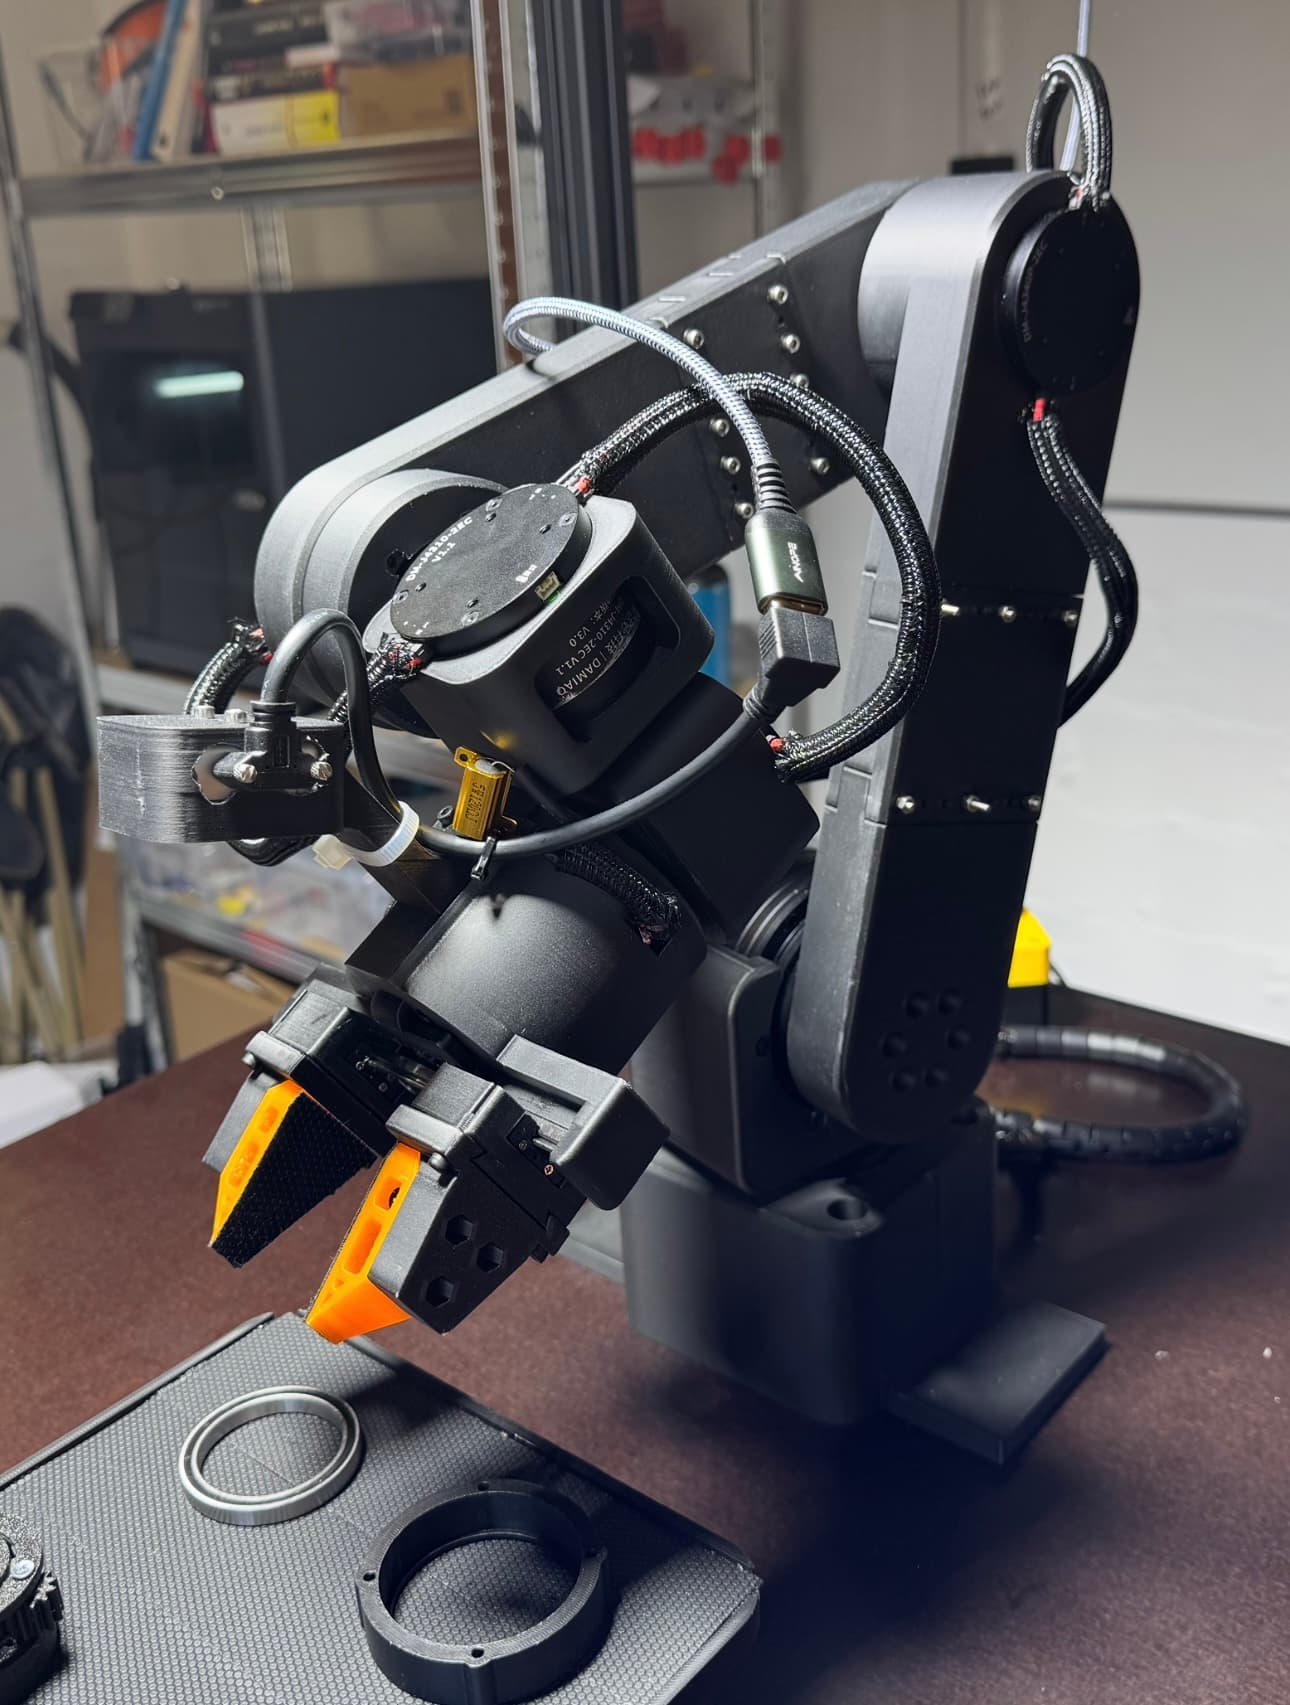
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
An educational open-source AI robot platform built on NVIDIA Jetson Nano for learning and experimenting with AI-based motion and collision avoidance.
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
An open-source, low-cost humanoid robot designed for AI experimentation and education.
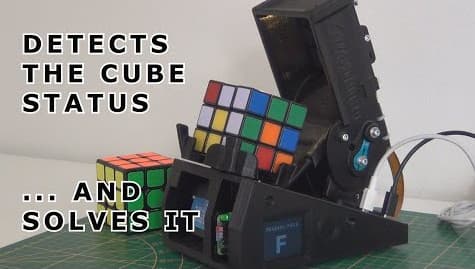
A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.
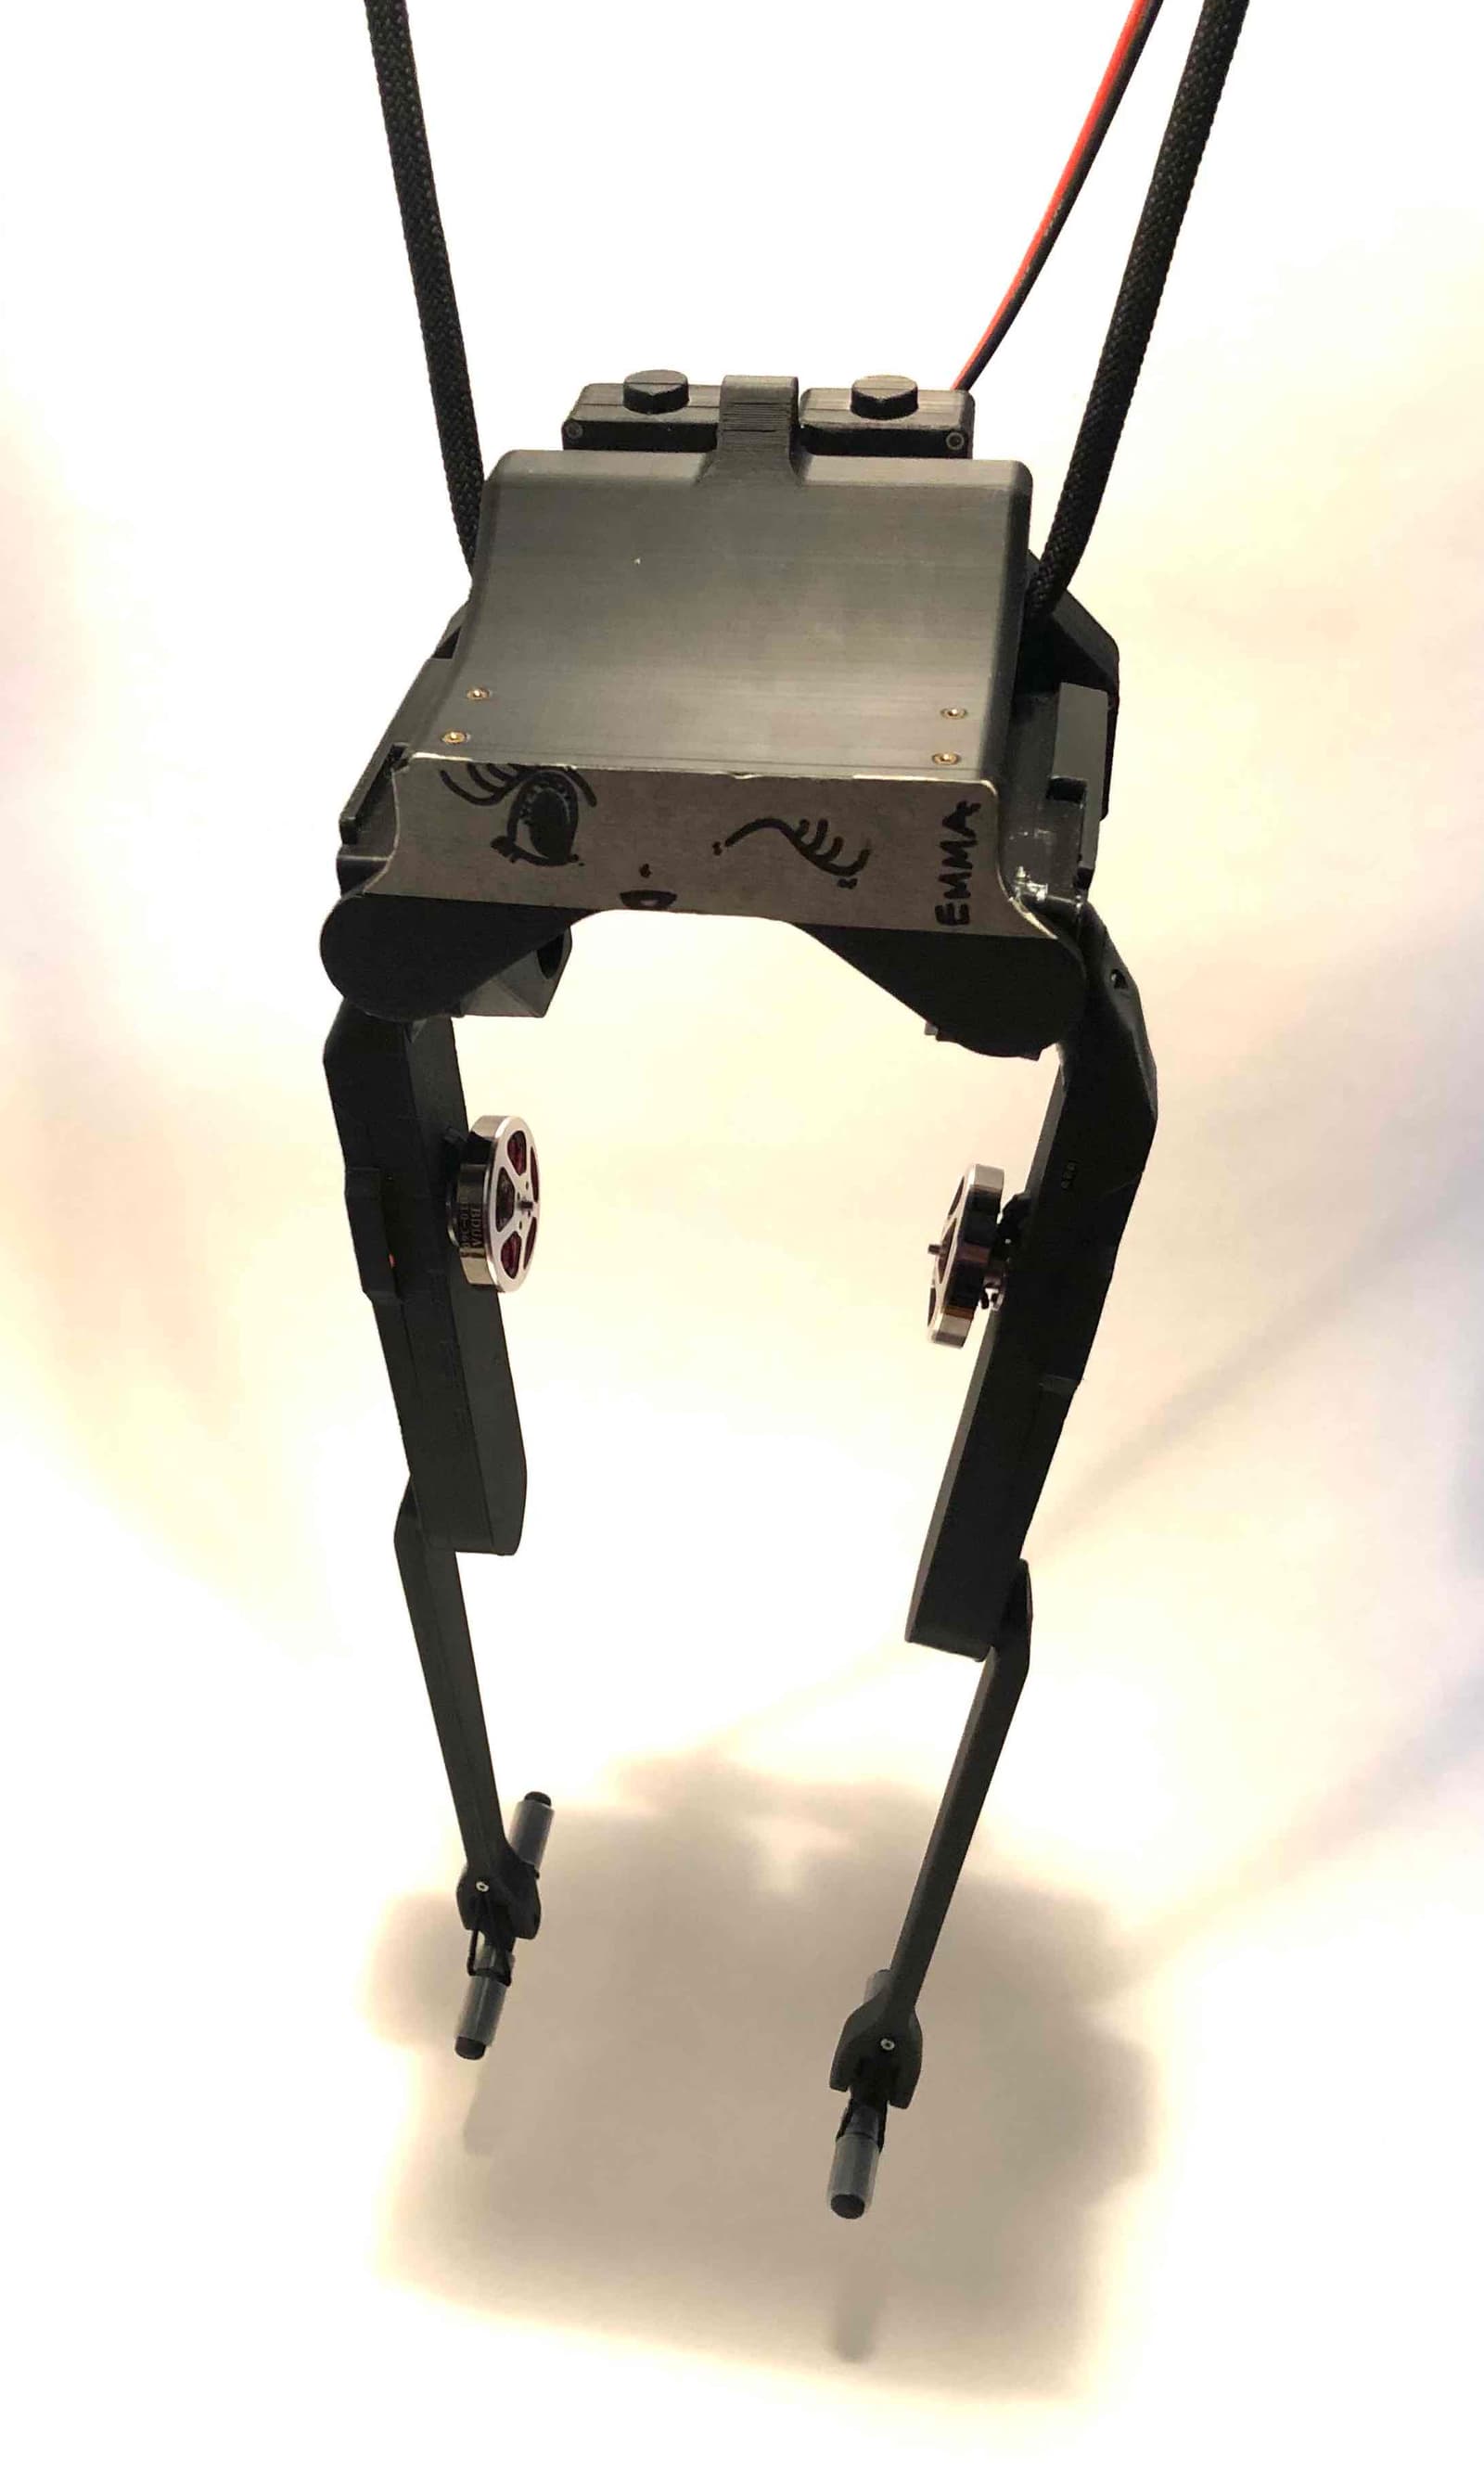
A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.
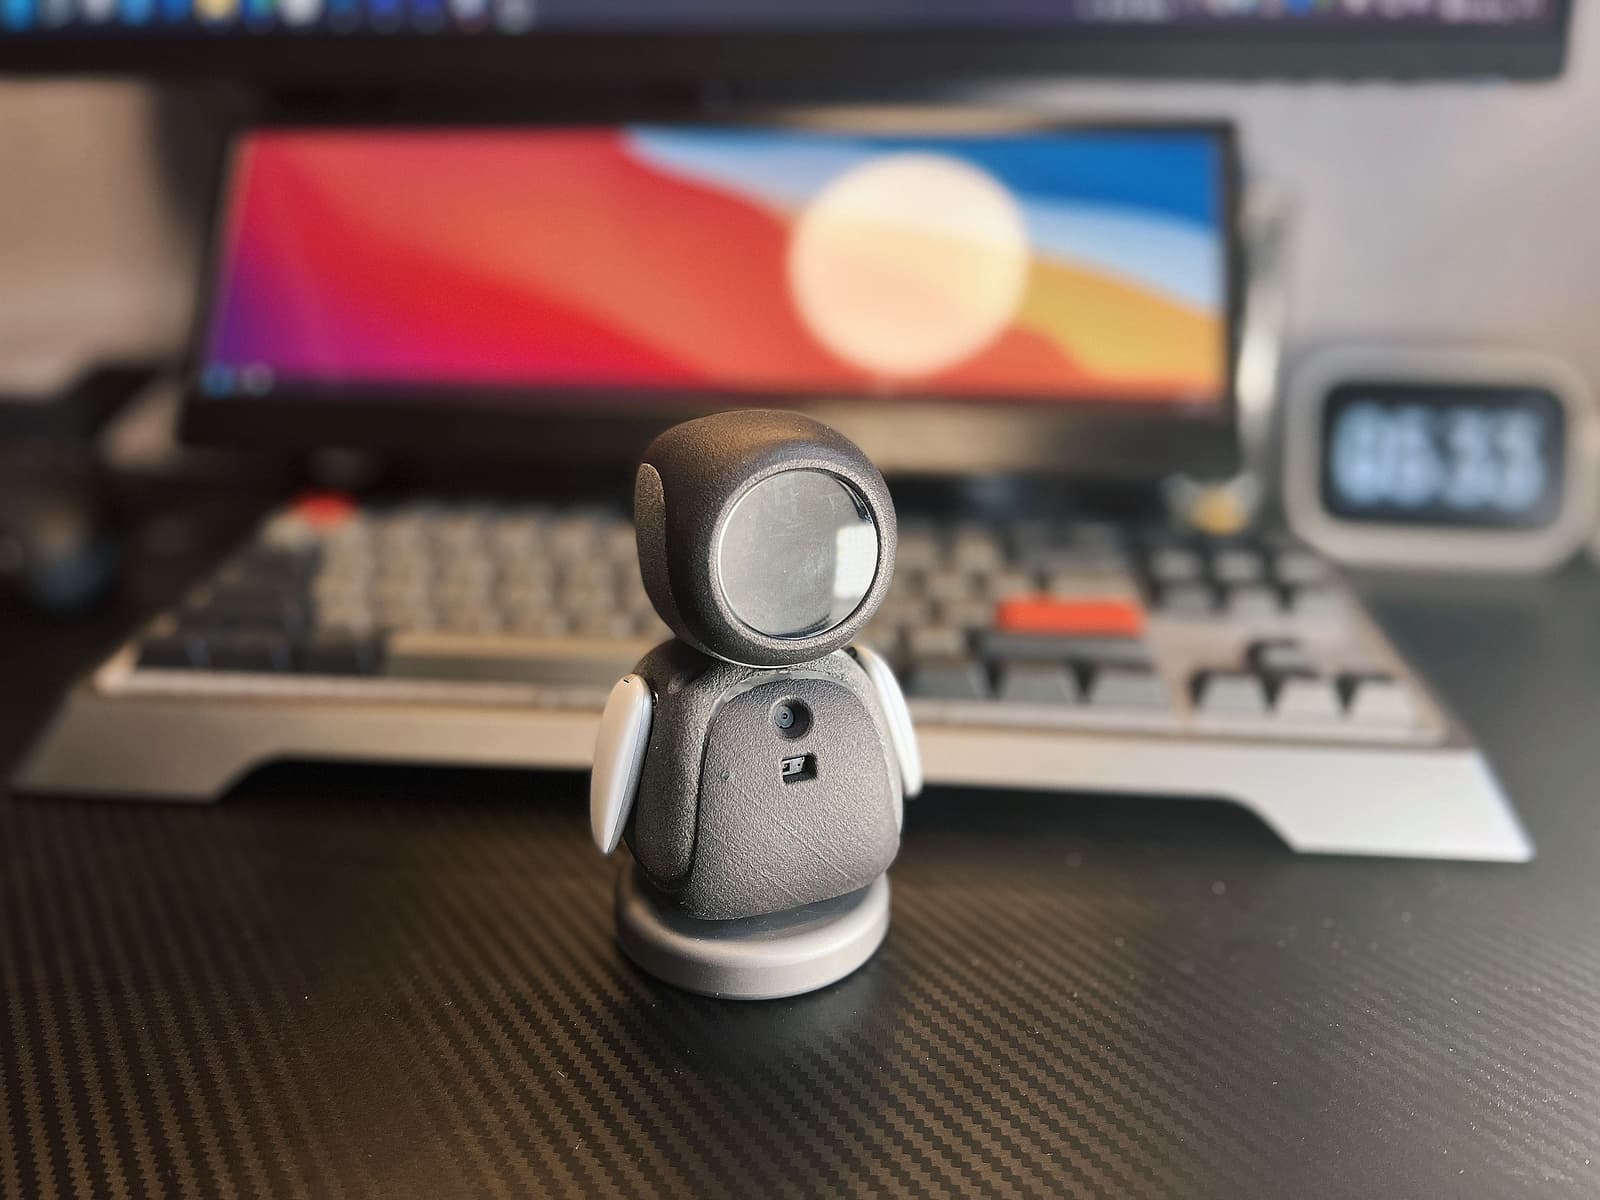
A mini desktop robot with 6 degrees of freedom, USB communication, and a display screen, inspired by WALL-E's EVE.
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
An autonomous self-balancing bicycle robot designed for outdoor track racing, featuring lane detection, obstacle recognition, and balance control algorithms.
Robots 25–48 of 120