
Open source · free files
Giraffe
Robot arm · Intermediate
- Score
- Buildability 100 out of 100
- Cost
- ₹14,585.71≈ €138
3D preview converted from github.com/wengmister/BiDexHand at 6cd2c75, under MIT. View the original files from GitHub (5.9 MB) (opens in a new tab)
Robot arm
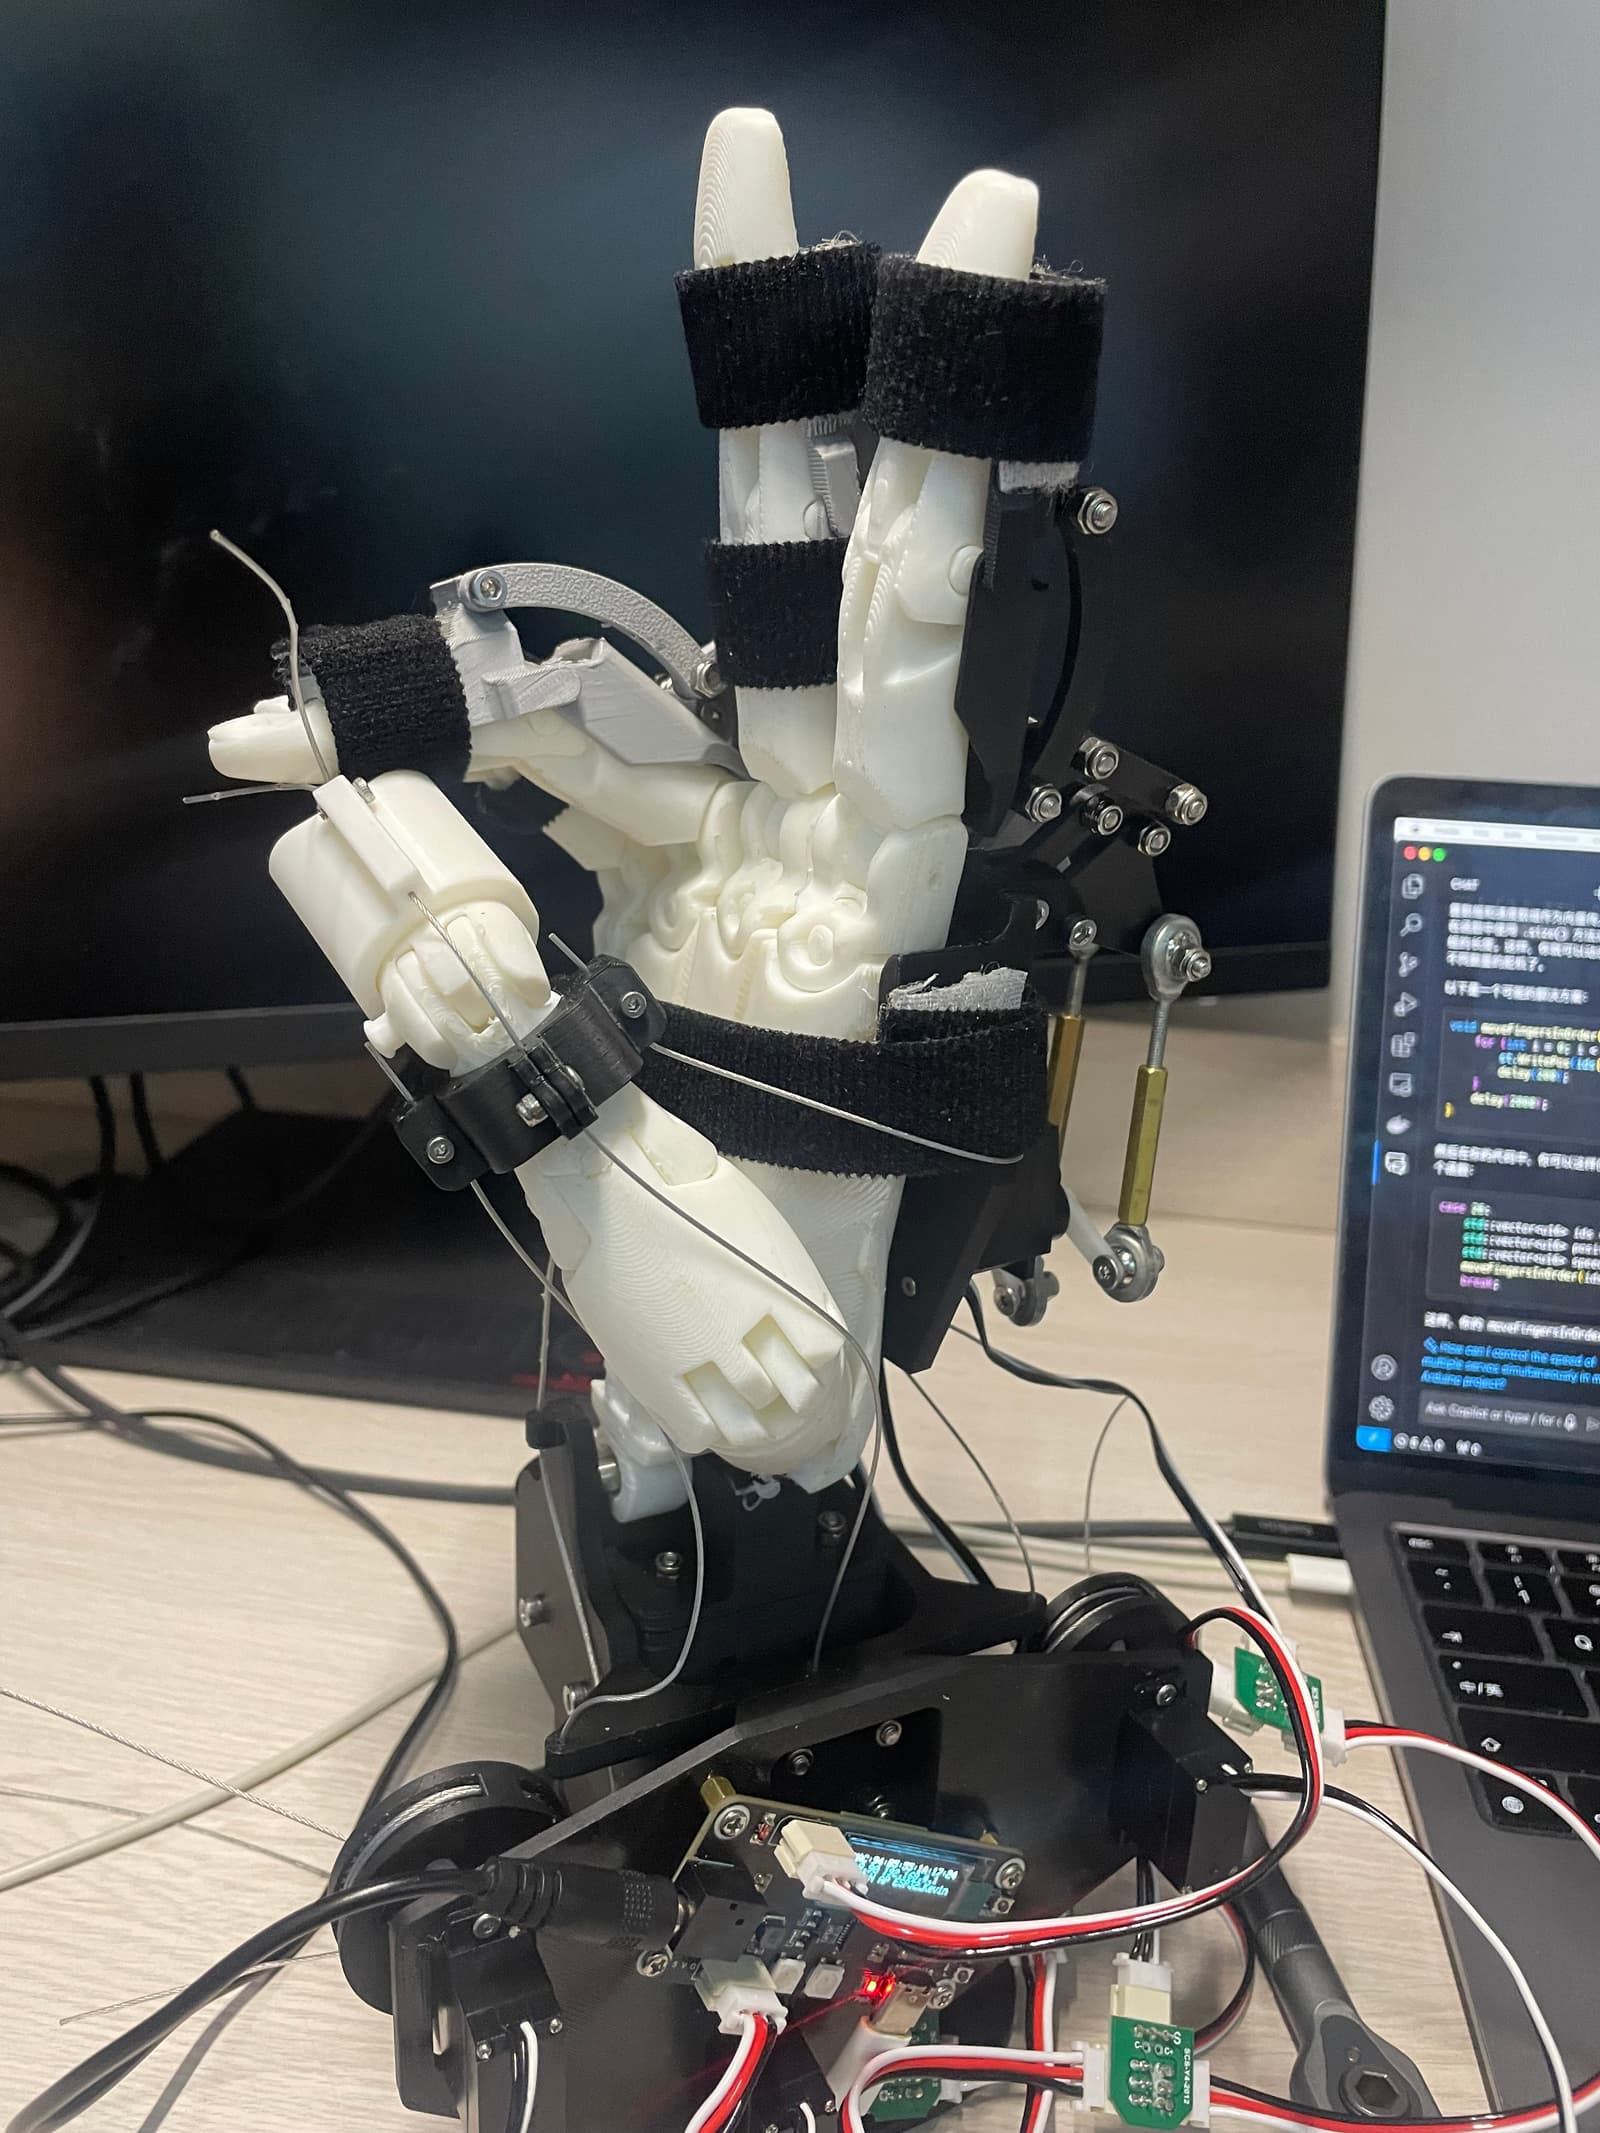
An open-source 16-degree-of-freedom biomimetic dexterous robotic hand driven by a cable-and-pulley system with servos.
Suggested by Robotheca, created by @wengmister (opens in a new tab), from github.com/wengmister/BiDexHand (opens in a new tab), pinned to commit 6cd2c75 (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.
55 of 55 parts shown
| Item | Part | Qty | Unit price | Amount | Source |
|---|---|---|---|---|---|
| Bill of Material | |||||
| 01 | 1 palm, base 3D printed part | 1 | – | – | – |
| 02 | 2 plx, base 3D printed part | 4 | – | – | – |
| 03 | 3 plx, knuckle 3D printed part | 4 | – | – | – |
| 04 | 4 plx, proximal 3D printed part | 4 | – | – | – |
| 05 | 5 plx, support 3D printed part | 5 | – | – | – |
| 06 | 6 plx, middle 3D printed part | 5 | – | – | – |
| 07 | 7 plx, distal 3D printed part | 5 | – | – | – |
| 08 | 8 plx, cover 3D printed part | 4 | – | – | – |
| 09 | 9 pulley, scs0009 3D printed part | 15 | – | – | – |
| 10 | 10 thumb, base 3D printed part | 1 | – | – | – |
| 11 | 11 thumb, arm 3D printed part | 1 | – | – | – |
| 12 | 12 thumb, cmc 3D printed part | 1 | – | – | – |
| 13 | 13 thumb, bridge 3D printed part | 1 | – | – | – |
| 14 | 14 thumb, proximal 3D printed part | 1 | – | – | – |
| 15 | 15 thumb, mcp 3D printed part | 1 | – | – | – |
| 16 | 16 thumb, cover 3D printed part | 1 | – | – | – |
| 17 | 17 palm, coupler 3D printed part | 1 | – | – | – |
| 18 | 18 sleeve, servo rack top 3D printed part | 2 | – | – | – |
| 19 | 19 sleeve, servo rack back 3D printed part | 2 | – | – | – |
| 20 | 20 sleeve, servo carriage 3D printed part | 10 | – | – | – |
| 21 | 21 sleeve, servo rack 3D printed part | 1 | – | – | – |
| 22 | 22 sleeve, servo single rack 3D printed part | 1 | – | – | – |
| 23 | 23 sleeve, servo single rack top 3D printed part | 2 | – | – | – |
| 24 | 24 sleeve, servo single rack back 3D printed part | 1 | – | – | – |
| 25 | 25 sleeve, base 3D printed part | 1 | – | – | – |
| 26 | 26 palm, guard 3D printed part | 2 | – | – | – |
| 27 | 27 90323A605 18-8 Stainless Steel Low-Profile Precision Shoulder Screw | 5 | – | – | – |
| 28 | 28 90323A608 18-8 Stainless Steel Low-Profile Precision Shoulder Screw | 15 | – | – | – |
| 29 | 29 97307A111 Slotted 18-8 Stainless Steel Precision Shoulder Screw | 10 | – | – | – |
| 30 | 30 91290A021 Alloy Steel Socket Head Screw | 61 | – | – | – |
| 31 | 31 2705T112 Light Duty Dry-Running Flanged Sleeve Bearing | 26 | – | – | – |
| 32 | 32 98089A201 18-8 Stainless Steel Round Shim | 16 | – | – | – |
| 33 | 33 92010A778 Passivated 18-8 Stainless Steel Phillips Flat Head Screw | 28 | – | – | – |
| 34 | 34 90323A604 18-8 Stainless Steel Low-Profile Precision Shoulder Screw | 3 | – | – | – |
| 35 | 35 90323A612 18-8 Stainless Steel Low-Profile Precision Shoulder Screw | 1 | – | – | – |
| 36 | 36 7119N113 Ultra-Low-Friction Oil-Embedded Sleeve Bearing | 1 | – | – | – |
| 37 | 37 6658K412 Oil-Embedded 841 Bronze Sleeve Bearing | 2 | – | – | – |
| 38 | 38 91290A015 Alloy Steel Socket Head Screw | 39 | – | – | – |
| 39 | 39 91292A028 18-8 Stainless Steel Socket Head Screw | 10 | – | – | – |
| 40 | 40 2006N111 302 Stainless Steel Corrosion-Resistant Compression Springs | 10 | – | – | – |
| 41 | 41 94510A370 Brass Screw-to-Expand Inserts | 10 | – | – | – |
| 42 | 42 91290A019 Alloy Steel Socket Head Screw | 14 | – | – | – |
| 43 | 43 91502A109 Blue-Dyed Zinc-Plated Alloy Steel Socket Head Screw | 2 | – | – | – |
| 44 | 44 91502A107 Blue-Dyed Zinc-Plated Alloy Steel Socket Head Screw | 4 | – | – | – |
| 45 | 45 FeeTech FT90M Servo* 9G servo motor, PWM | 16 | – | – | Alibaba: buy 45 FeeTech FT90M Servo* 9G servo motor, PWM, opens in a new tab |
| 46 | 46 Pimoroni Servo2040* RP2040 Servo Shell | 1 | – | – | Adafruit: buy 46 Pimoroni Servo2040* RP2040 Servo Shell, opens in a new tab |
| 47 | 47 6V 5A Power Supply Alternatively use adjustable bench power supply | 1 | – | – | – |
| 48 | 48 DuraBraid fishing wire 40lb | – | – | – | Amazon: buy 48 DuraBraid fishing wire 40lb, opens in a new tab |
| 49 | 49 2mm zipties Cable management | – | – | – | – |
| 50 | 50 3mm OD PTFE Tube | – | – | – | Amazon: buy 50 3mm OD PTFE Tube, opens in a new tab |
| 51 | 51 D405_Solid Intel Realsense wrist camera | 1 | – | – | – |
| 52 | 52 SCS009 Feetech Servo Motor | 16 | – | – | – |
| 53 | 53 scs_board Signal distribute board | 5 | – | – | – |
| 54 | 54 FE-URT-1 USB to TTL level shifter | 1 | – | – | – |
| 55 | 55 ESP32 MCU | 1 | – | – | – |
55 of 55 needed parts have no price in the source, so there is no parts total.
84/100
Well documented, cost unknown
How complete the published files are for rebuilding this robot, measured by Robotheca at commit 6cd2c75. It isn't a rating of the robot. Counted out of 95 points and scaled to 100: the parts that don't apply to this robot are left out.
The guide appears here as you scroll.
Guide by @wengmister (README.md), under MIT.
From the parts list.
Found by Robotheca in the project's files at commit 6cd2c75, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Uses computer vision: YOLO
In the project files: src/hand_vision/hand_vision/yolo_node.pyRobotheca doesn't review code. Read it before running it.
Written by Robotheca from the project's documents, not by its creator.
No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.
Every file of the project, at commit 6cd2c75.
Questions and improvements go to the creator's repository.
For the creator: two badges that link back here. The second always shows this page's current label and score.

Markdown (one click selects it)
[](https://robotheca.org/robots/bidexhand) [](https://robotheca.org/robots/bidexhand)
Open source · free files
Robot arm · Intermediate
Open source · free files
Robot arm · Intermediate
Open source · free files
Robot arm · Advanced
≈ € values are approximate, converted at the ECB euro reference rate of 5 Nov 2026. The creator's original price always comes first.