Koch v1.1
An improved version of Alexander Koch's low-cost robot arm, a leader and follower pair with Dynamixel servos for LeRobot. The price includes both arms.
- Robot arm
- Open source
- Works with AI
- LeRobot
- 3D printable
Added from github.com/jess-moss/koch-v1-1 (opens in a new tab), created by @jess-moss (opens in a new tab). Pinned to commit 1a553e1 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
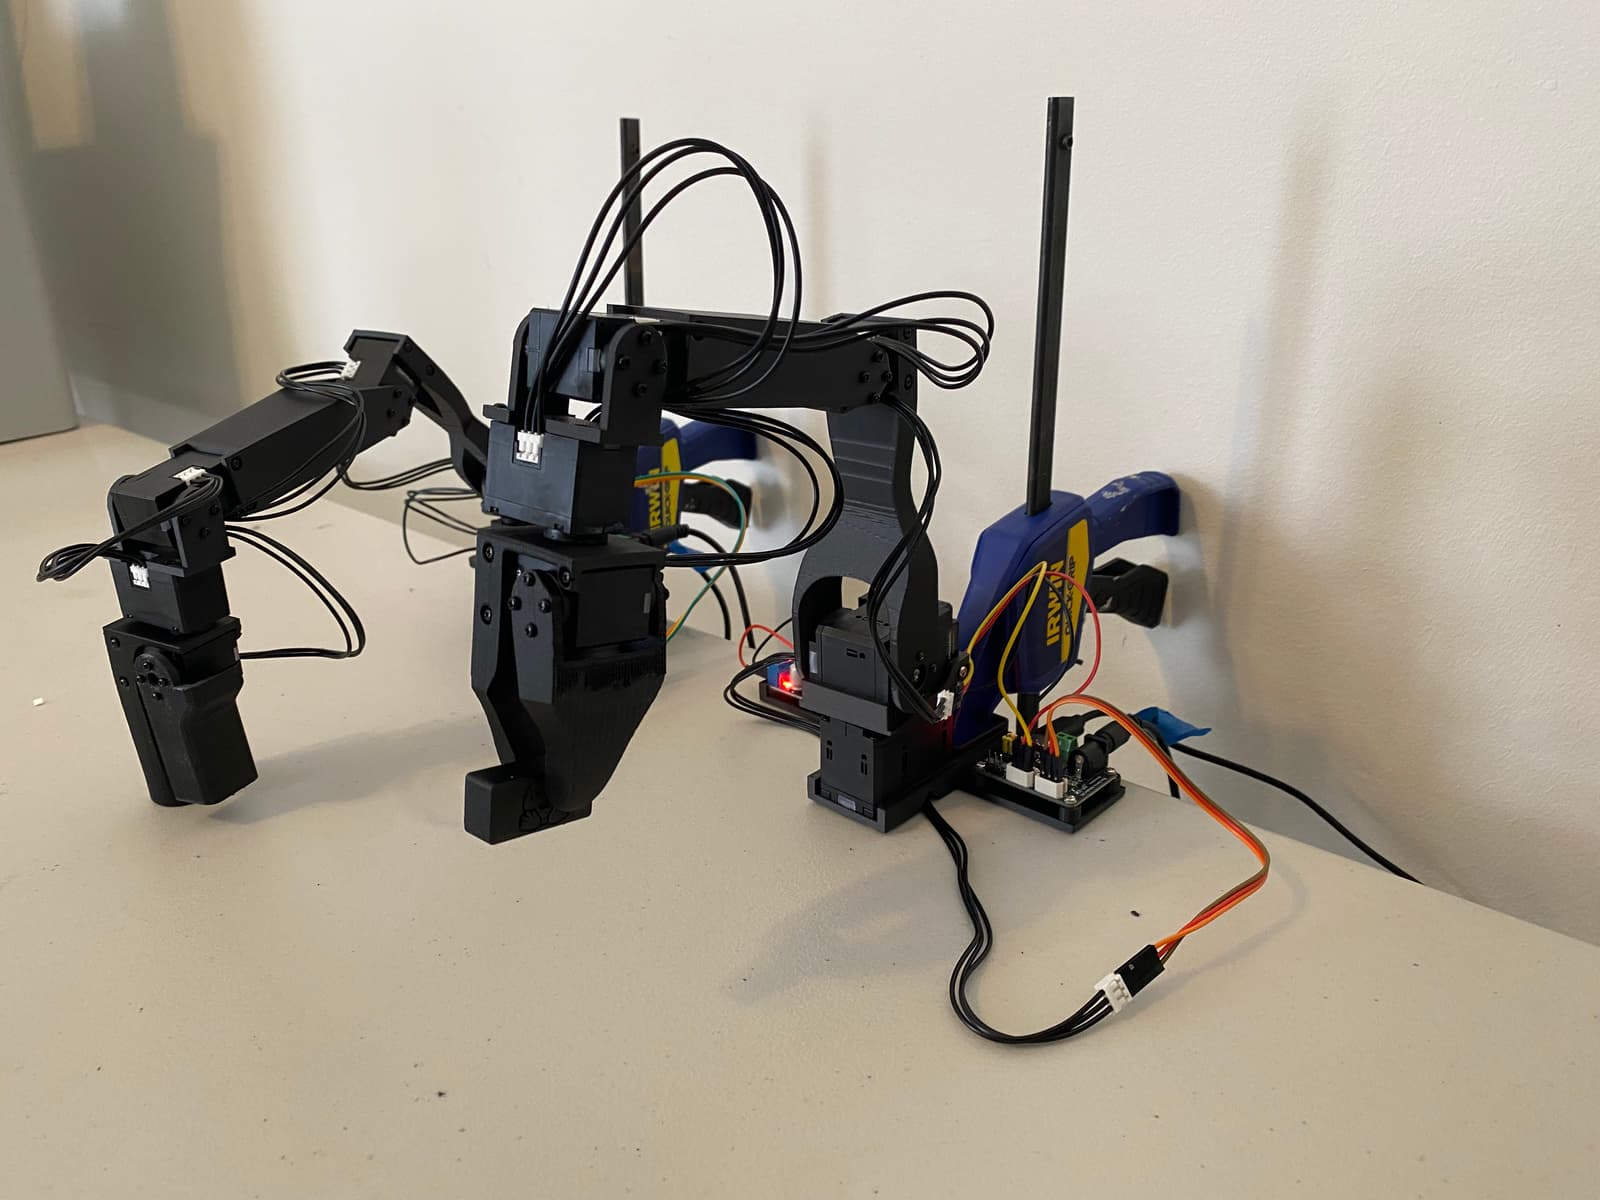
3D preview converted from github.com/jess-moss/koch-v1-1 at 1a553e1, under Apache-2.0. View the original files from GitHub (4.3 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Moves as a 6-DOF robot arm with leader and follower arms
- Controlled via USB from a computer
- Can pick and place small objects using a gripper
- Follower arm can reach the ground with the added platform
Works with AI
Found by Robotheca in the project's files at commit 1a553e1, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Runs LeRobot
Stated in robot.yaml
Bill of materials
21 parts21 of 21 parts shown
5 of 21 parts have no price in the source, so there is no parts total. Read from README.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Get the parts for both armsREADME.md
- 2Print the partsREADME.md
- 3Assemble the two arms (video) (opens in a new tab)youtube.com
- 4Set up the motors and calibrate with LeRobot (opens in a new tab)huggingface.co
The guide appears here as you scroll.
Guide by @jess-moss (README.md), under Apache-2.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Dynamixel XL330-M077-T servos (6 for leader arm)
- Dynamixel XL330-M288-T servos (4 for follower arm)
- Dynamixel XL430-W250-T servos (2 for follower arm)
- Waveshare Serial Bus Servo Driver Board
- 5V power supply for leader arm
- 12V power supply for follower arm
- Voltage reducer for follower arm power input
Connections
- Servos connected to the Waveshare Serial Bus Servo Driver Board via serial bus
- Driver board powered by 5V for leader arm and 12V via voltage reducer for follower arm
- Driver board connected to computer via USB-C cable
Cables and connectors
From the parts list.
- Jumper Wires 3*40 pcs set (M-M, M-F, F-F) × 1
- Jumper Wires 3*40 pcs set (M-M, M-F, F-F) × 1