Manuel 1.0
A flexible, human-arm-sized open-source robotic arm with 6 degrees of freedom plus a gripper, built from 3D-printed parts and Dynamixel X-series motors.
- Robot arm
- Open source
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @mattweidman (opens in a new tab), from github.com/mattweidman/Manuel-1.0 (opens in a new tab). Pinned to commit 27784e7 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
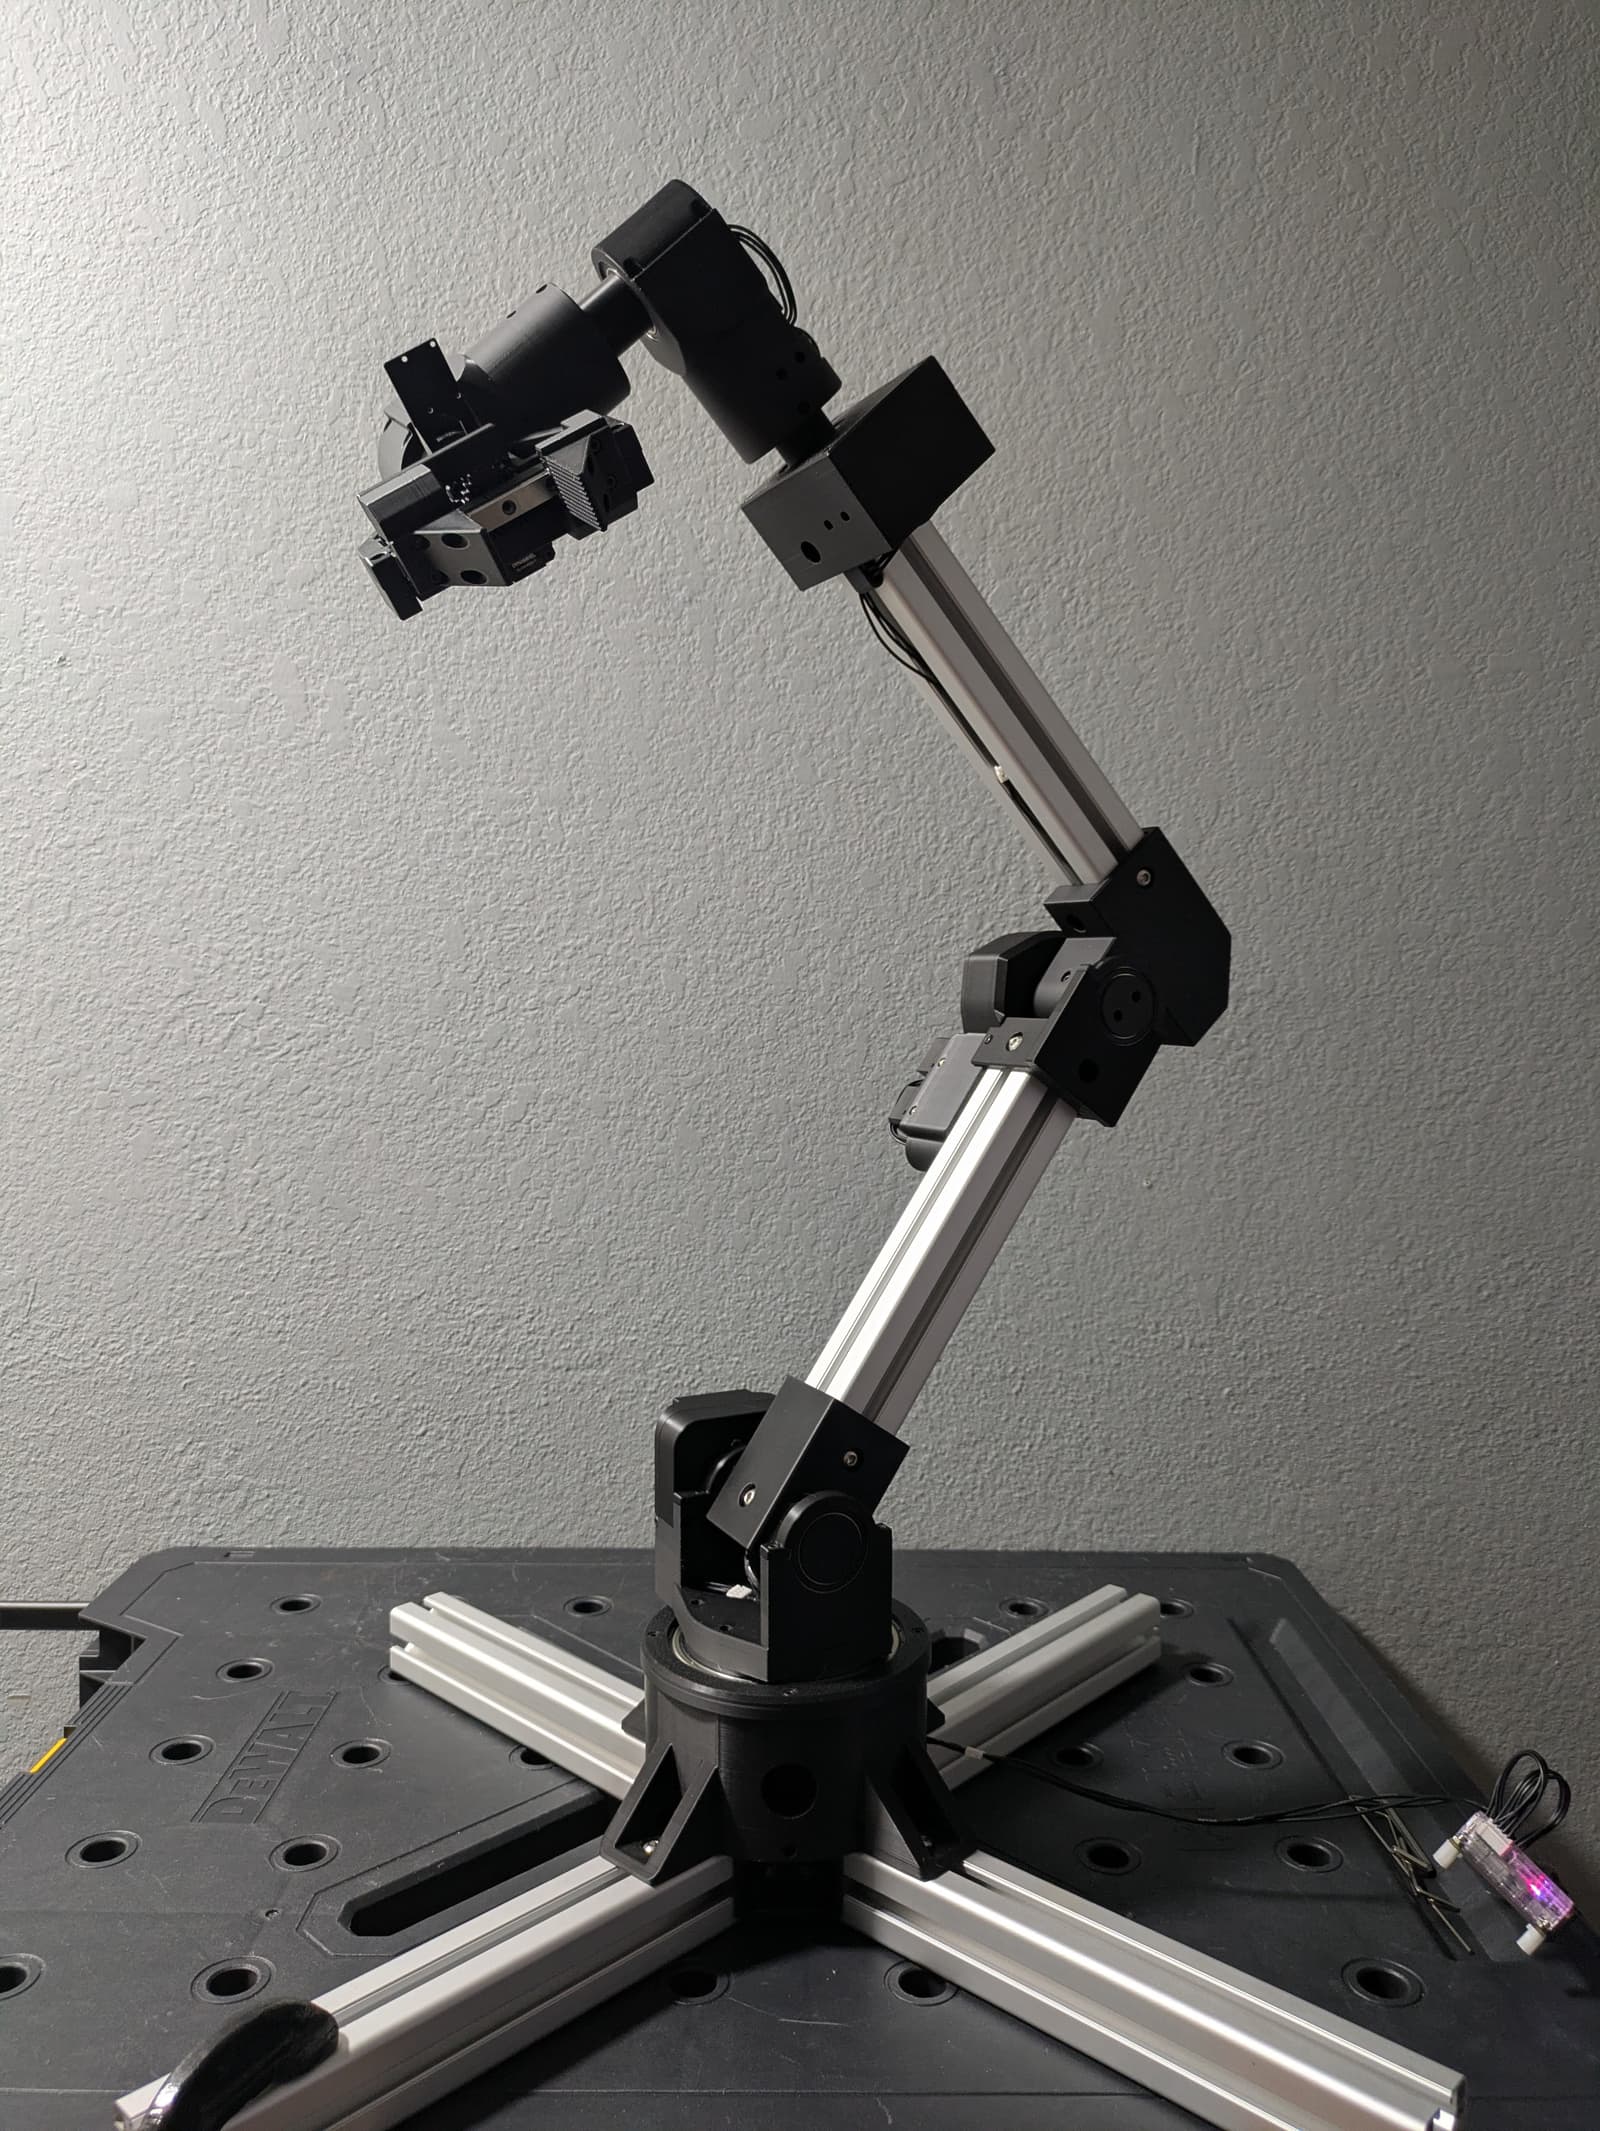
Try it in the browser
3D preview converted from github.com/mattweidman/Manuel-1.0 at 27784e7, under MIT. View the original files from GitHub (14.0 MB) (opens in a new tab)
- Degrees of freedom
- 6
- Reach
- 860 mm
- Payload
- 1 kg
What it can do
Written by Robotheca from the project's documents.
- Robotic arm with 6 degrees of freedom plus a gripper, seven motors in total
- Waist and three wrist joints can turn more than 360 degrees
- Wrist allows the gripper to point in any direction when unobstructed
- Reaches about 860 mm from shoulder to gripper tip with the documented extrusion length
- Can hold a 1 kg payload when extended
- Motors are backdrivable; joints can be frozen or unfrozen on a timer
- Sample scripts record joint positions and run a wave motion
- Controlled from a computer over USB using the Dynamixel SDK in Python
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @mattweidman (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Dynamixel XM540-W270-T motors at the shoulder and elbow
- Dynamixel XM430-W350-T motors at the waist and wrist 1 and 2
- Dynamixel XL430-W250-T motors at wrist 3 and the gripper
- U2D2 USB converter connecting the motor chain to the computer, with a power supply and on/off switch
- JST EH and JST SM connectors and cables made from 22 gauge wire
Connections
- Motors are daisy-chained in series from the U2D2 USB converter, base to tip
- Each link between components is a 3-wire cable with JST EH or JST SM connectors
- The documents list the cable length between each pair of electronics, from base to tip
- Many Dynamixel motors include an 18 cm female-female JST EH cable