SO-101
A low-cost 3D-printed robot arm built as a leader and follower pair, for teleoperation and for teaching tasks by demonstration with LeRobot.
- Robot arm
- Open source
- Works with AI
- LeRobot
- 3D model (URDF)
- 3D printable
Added from github.com/TheRobotStudio/SO-ARM100 (opens in a new tab), created by @TheRobotStudio (opens in a new tab). Pinned to commit 5f6d2b8 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
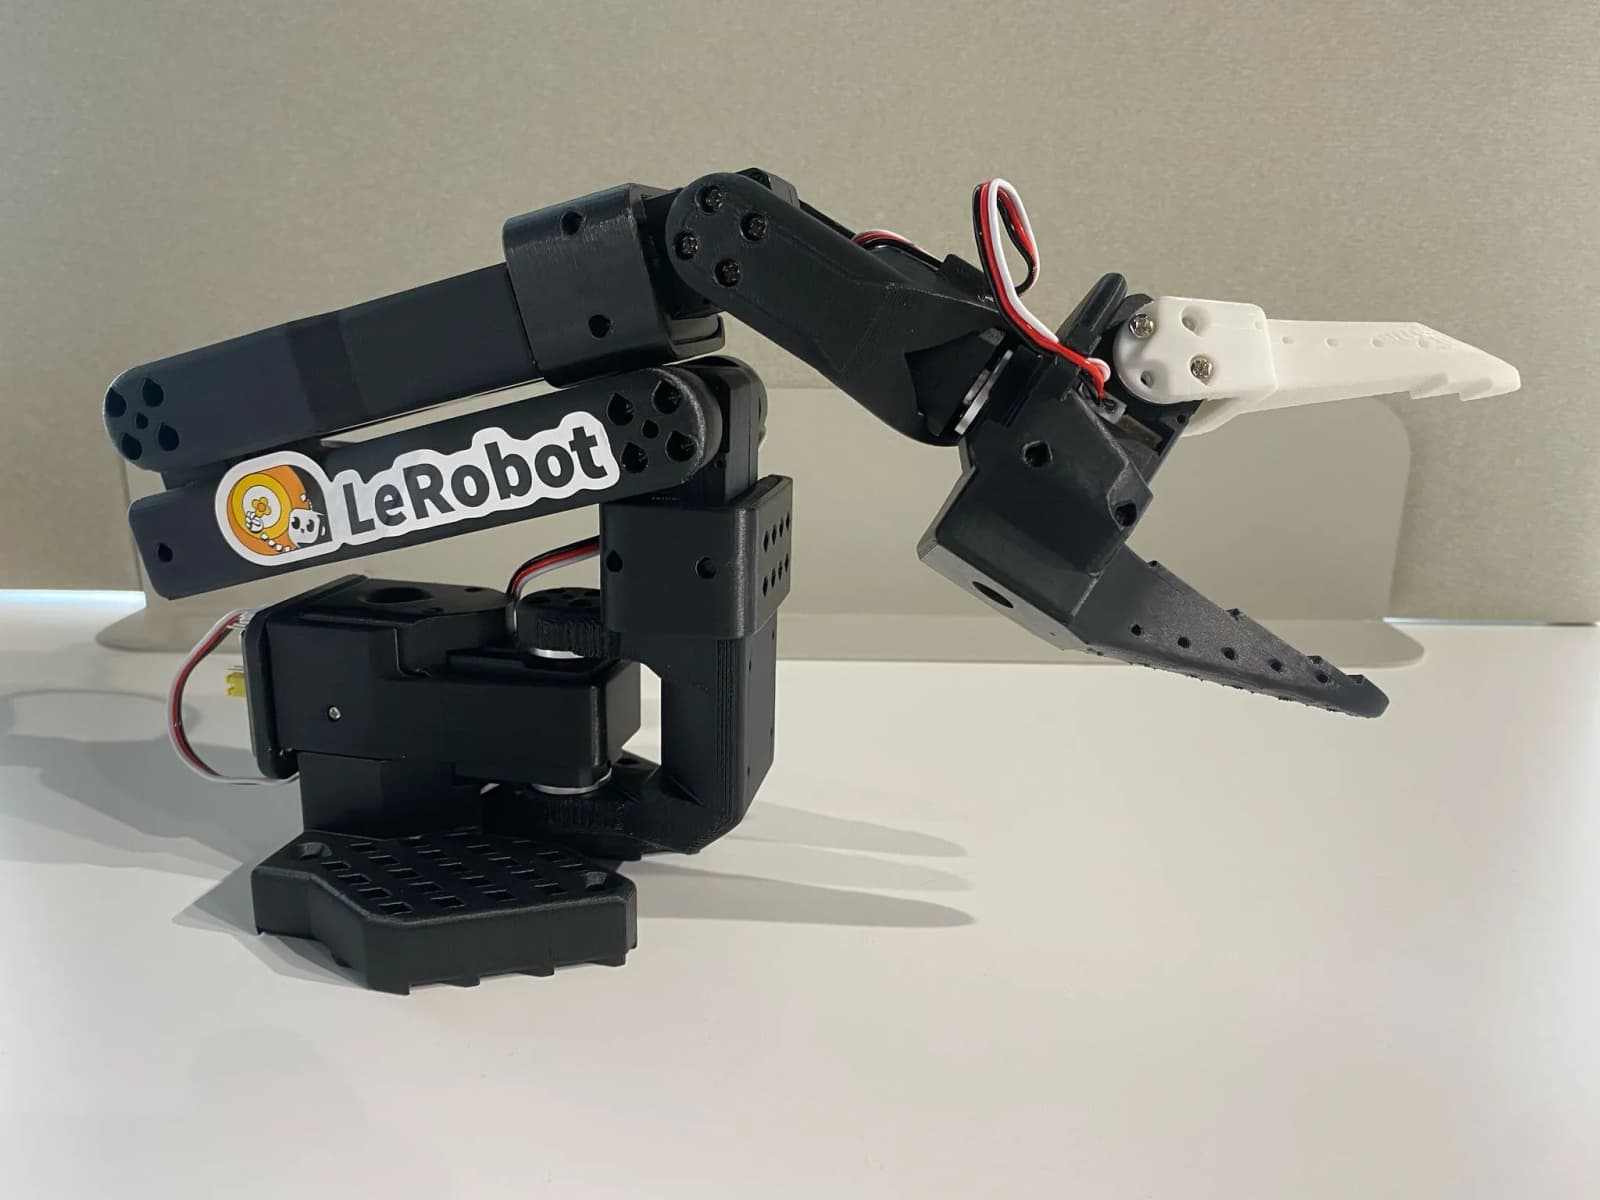
3D preview converted from github.com/TheRobotStudio/SO-ARM100 at 5f6d2b8, under Apache-2.0. View the original files from GitHub (16.1 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Teleoperated dual-arm robot arm system
- Leader arm replicates human arm movements
- Follower arm mirrors leader arm motions
- Designed for use with LeRobot library for AI control
- Supports end-to-end AI robotics tasks
Works with AI
Found by Robotheca in the project's files at commit 5f6d2b8, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Runs LeRobot
Stated in robot.yaml“Designed for use with LeRobot library for AI control”
Robotheca's notes: What it can do“Supports end-to-end AI robotics tasks”
Robotheca's notes: What it can do“Install LeRobot library as per LeRobot documentation”
Robotheca's notes: How to run it
Bill of materials
8 parts8 of 8 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | STS3215 Servo 7.4V, 1/345 gear (C001) | 7 | €12.20 | Alibaba: buy STS3215 Servo 7.4V, 1/345 gear (C001) (EU shop), opens in a new tab |
| 2 | STS3215 Servo 7.4V, 1/191 gear (C044) | 2 | €12.20 | Alibaba: buy STS3215 Servo 7.4V, 1/191 gear (C044) (EU shop), opens in a new tab |
| 3 | STS3215 Servo 7.4V, 1/147 gear (C046) | 3 | €12.20 | Alibaba: buy STS3215 Servo 7.4V, 1/147 gear (C046) (EU shop), opens in a new tab |
| 4 | Motor Control Board | 2 | €11.40 | Amazon: buy Motor Control Board (EU shop), opens in a new tab |
| 5 | USB-C Cable 2 pcs | 1 | €7 | Amazon: buy USB-C Cable 2 pcs (EU shop), opens in a new tab |
| 6 | Power Supply | 2 | €15.70 | Amazon: buy Power Supply (EU shop), opens in a new tab |
| 7 | Table Clamp 4pcs | 1 | €9.70 | Amazon: buy Table Clamp 4pcs (EU shop), opens in a new tab |
| 8 | Screwdriver Set | 1 | €9 | Amazon: buy Screwdriver Set (EU shop), opens in a new tab |
Parts total: €226.30. Read from README.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Get the parts for both armsREADME.md
- 2Print the partsREADME.md
- 3Install LeRobot (opens in a new tab)huggingface.co
- 4Set the motor IDs and baud rates (opens in a new tab)huggingface.co
- 5Assemble the arms joint by joint (opens in a new tab)huggingface.co
- 6Calibrate the leader and follower arms (opens in a new tab)huggingface.co
The guide appears here as you scroll.
Guide by @TheRobotStudio (README.md), under Apache-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Motor Control Board (Waveshare integrated control circuit)
- USB-C cables for communication
- Power supply (5V or 12V depending on motor version)
- Table clamps for securing the base
Connections
- Servos connected to Motor Control Board via USB-C cables
- Motor Control Board powered by Power Supply
- Servos arranged in leader and follower configurations with specified gear ratios
Cables and connectors
From the parts list.
- USB-C Cable 2 pcs × 1