Skip to content

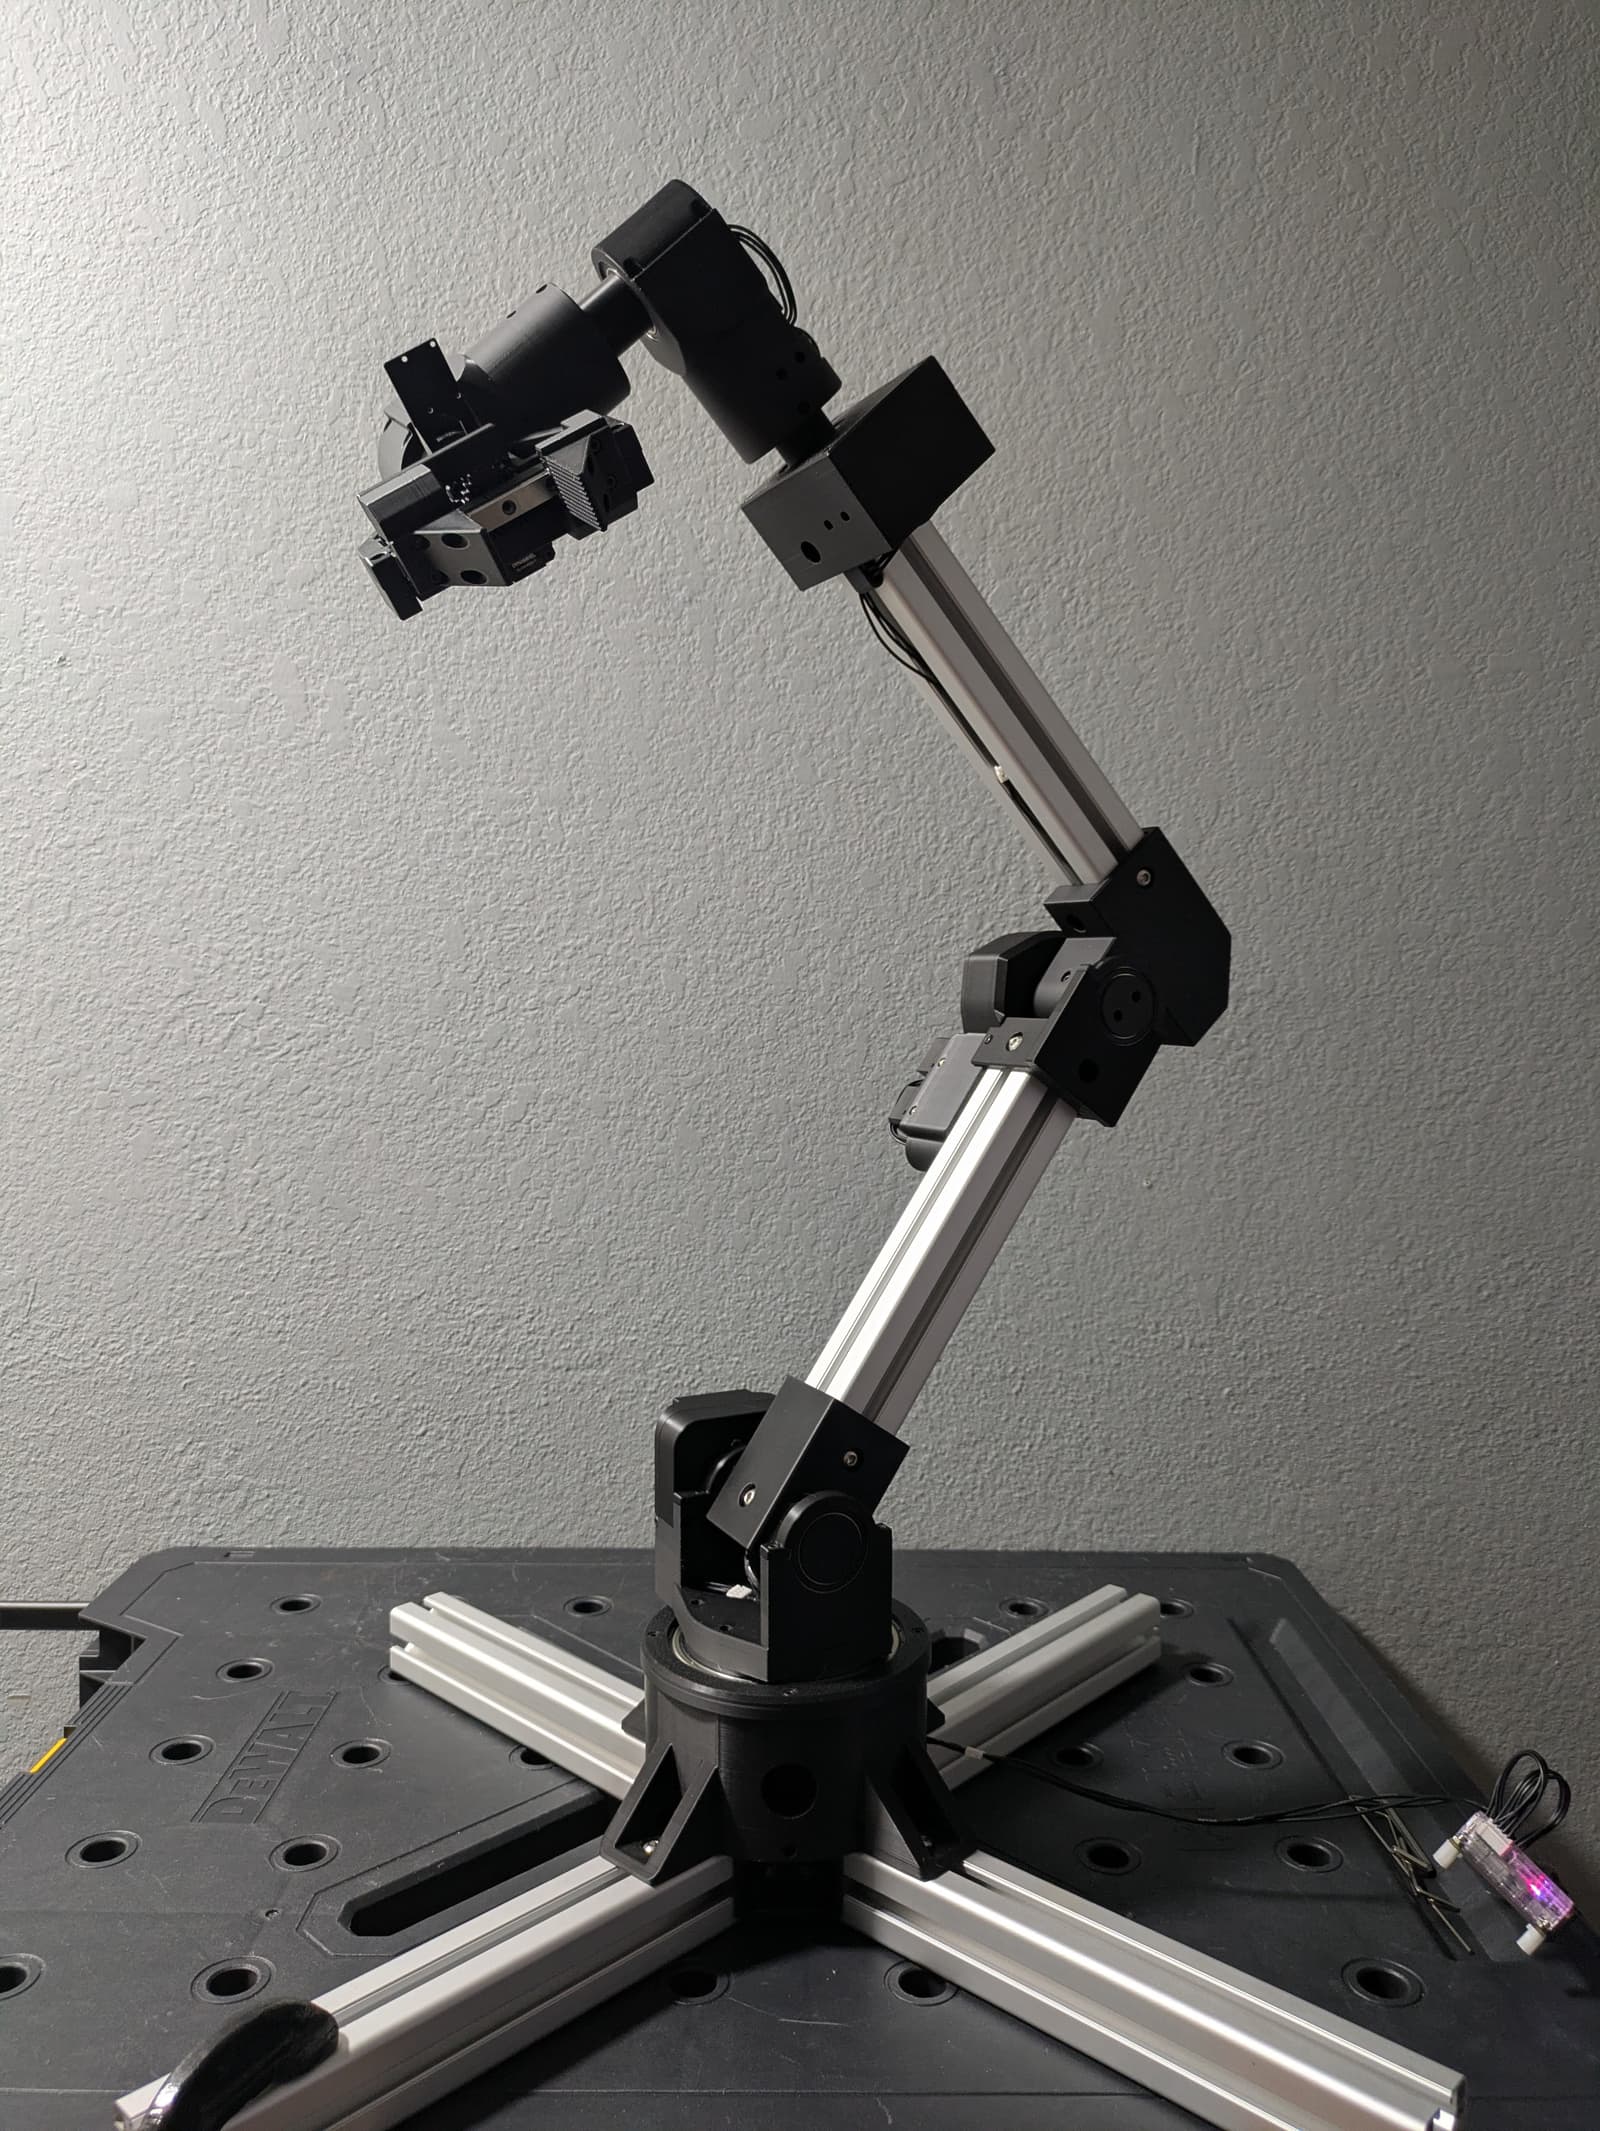
Photo and 3D model

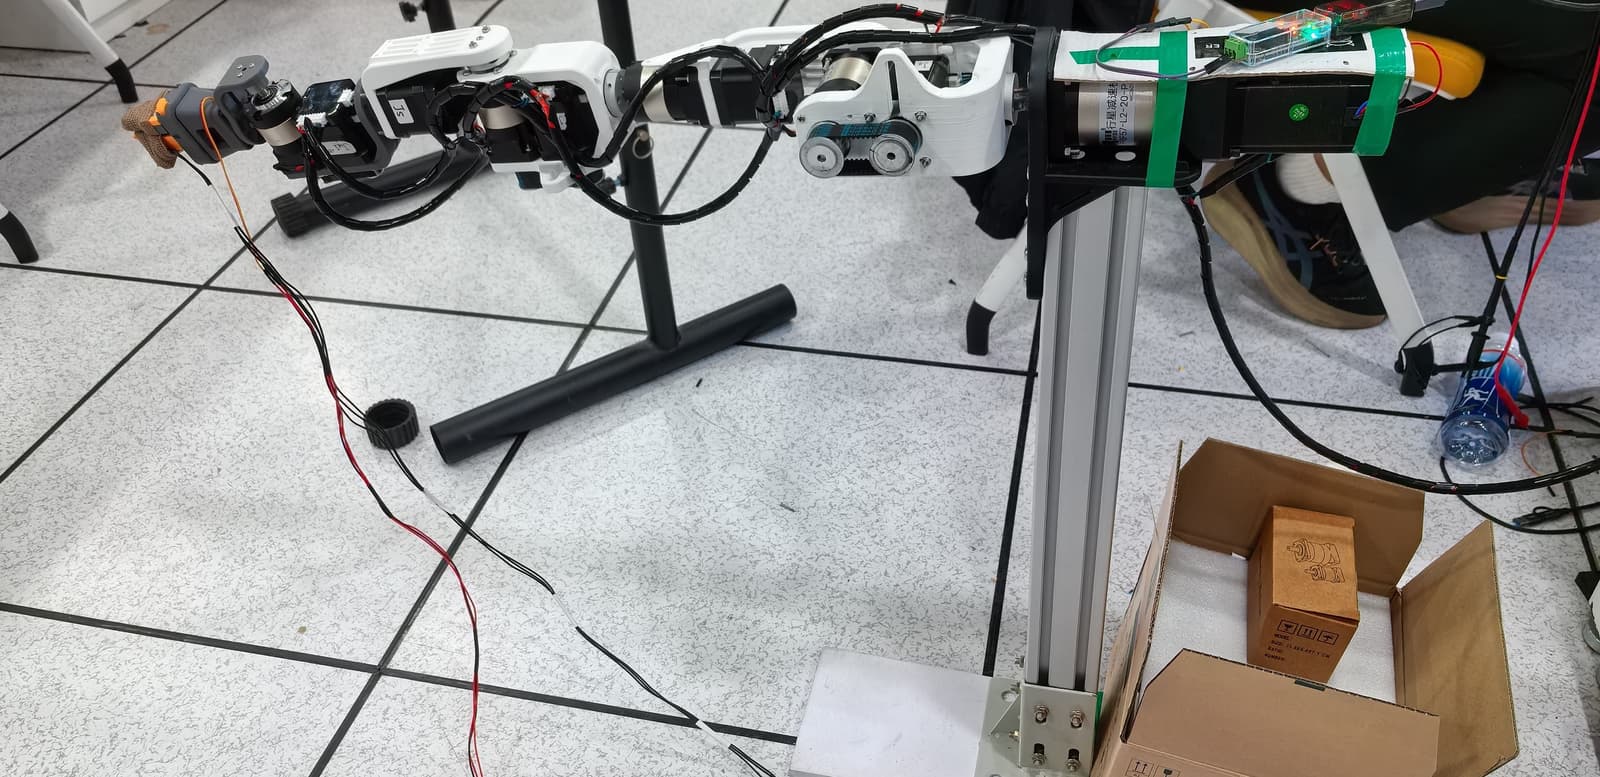
ArmSync, photo from its repository
Photo@WilliTourt (opens in a new tab)MITsource file (opens in a new tab)
Try it in the browser

3D preview converted from github.com/WilliTourt/ArmSync at 2c92623, under MIT. View the original files from GitHub (15.1 MB) (opens in a new tab)

Open source · free filesReady to build

ArmSync

Robot arm

A six-degree-of-freedom robotic arm, mostly 3D-printed in PLA, controlled wirelessly by a dual-IMU master-slave scheme.

Project information

Buildability
83/100Ready to build
Estimated cost
¥1,500approx. €202 (ECB rate, 30 Oct 2026)21 parts have no listed price; the real cost may be higher.About this, as the creator estimates in Hardware/Parts BOM.md (the table's 1,240.5 RMB leaves out screws, extrusion, printing, PCBs and shipping).
Level
Advanced
Parts
34 lines
Tools
3D printer, soldering iron
Licenses
MIT (opens in a new tab), hardware and software
Commercial use
Allowed
Reach
610 mm
Payload
350 g

This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.

Which files (6 scripts, 8 firmware images)

Suggested by Robotheca, created by @WilliTourt (opens in a new tab), from github.com/WilliTourt/ArmSync (opens in a new tab), pinned to commit 2c92623 (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

34 lines, read from Hardware/Parts BOM-zh-CN.md at 2c92623
Export CSV (parts list)

34 of 34 parts shown

  • 3. 同步带轮传动系统
  • 2同步轮¥8≈ €1¥4 each ·–
  • 2同步轮¥12.80≈ €2¥6.40 each ·–
  • 2同步轮¥14.20≈ €2¥7.10 each ·–
  • 1同步带¥1≈ €0¥1 each ·–
  • 1同步带¥3.50≈ €0¥3.50 each ·–
  • 1同步带¥4≈ €1¥4 each ·–
  • 4.1 胀紧套 (对于J1/J2/J3/J4不推荐)
  • 4Z21 8×18×11¥56≈ €8¥14 each ·–
  • 1Z21 14×26×17¥13≈ €2¥13 each ·–
  • 4.2 联轴器
  • 2单膜联轴器 D32d14 L28¥38≈ €5¥19 each ·–
  • 2单膜联轴器 D32d8 L28¥38≈ €5¥19 each ·–
  • 1单膜联轴器 D19d4 L20¥18≈ €2¥18 each ·–
  • 4.3 轴类
  • 3D型轴––
  • 6.1 基座铝型材
  • 10M6×16––
  • 12M6 T型螺母––
  • 1铝型材––
  • 6.2 J1 基座旋转
  • 4M3×31––
  • 8M5×25––
  • 6.3 J2 肩部俯仰
  • 3M2.5×24––
  • 8M3×20+––
  • 4M3×75+––
  • 6.4 J3 肩部偏航
  • 3M2.5×16––
  • 4M3×59+––
  • 6.5 J4 肘部
  • 3M2.5×19––
  • 4M3×15+––
  • 4M3×48+––
  • 6.6 J5 腕部俯仰
  • 3M2.5×13––
  • 4M3×53+––
  • 6.7 J6 腕部旋转
  • 3M2.5×17––
  • 4M3×13+––
  • 4M3×48+––
  • 6.8 EE 末端夹爪
  • 4M3×38––
  • 5M2.5×18––
  • 7. 开发调试工具(可选)Optional, not in the total
  • –CAN收发器模块–¥3 each ·–
  • 1CAN测试仪 (ZDT)¥50≈ €7¥50 each ·–

≈ € amounts use the ECB reference rate of 30 Oct 2026, for comparison only.

21 of 32 needed parts have no price in the source, so there is no parts total.

Why it scores 83

It measures the published files, not the robot · How we score

83/100

Ready to build

How complete the published files are for rebuilding this robot, measured by Robotheca at commit 2c92623. It isn't a rating of the robot. Counted out of 95 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD files8 printable parts (STL, 3MF), 67 CAD source files.20/20
  2. 2Robot descriptionA URDF with all its mesh files.15/15
  3. 3Parts list34 lines: 13 with a price, 0 with a shop link.Most points to gain: Add prices to 21 lines. Add shop links to 34 lines.9/20
  4. 4SoftwareCode in this repository, instructions to install or run it.Say which software framework it uses (ROS 2, LeRobot, Arduino…).10/15
  5. 5DocumentationREADME of 4,078 characters with 2 pictures; 3 build steps.15/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 6LicensesHardware: MIT; software: MIT.10/10

Build it

The creator's 3 steps, each linked to its instructions
  1. J1 Base Rotation JointAssembly Guide.md
  2. J2 Shoulder Pitch JointAssembly Guide.md
  3. J3 Shoulder Yaw JointAssembly Guide.md

The guide appears here as you scroll.

Guide by @WilliTourt (README.md), under MIT.

More guides

Wiring and electronics

Notes written by Robotheca from the project's documents

Main parts

  • Renesas RA8P1 dual-core MCU as the robot-arm controller, with CPU0 for control and motion processing and CPU1 for actuator control.
  • Renesas RA4M1 MCUs on the user-side controller and the IMU module.
  • ICM42688 accelerometer and gyroscope and QMC5883P magnetometer on the IMU module.
  • Stepper motors for joints J1 to J6 (57x76, 42x60, 42x40, 42x48 and 42x34 mm sizes), driven by ZDT stepper-motor controllers.
  • ZP20S bus servo for the gripper, or an MG90S servo or other end effector.
  • CAN transceiver module and a KiCad CAN connector board that plugs into each ZDT stepper-motor controller.
  • Power supply of 24 VDC for the stepper motors and 5 VDC for the servo.

Connections

  • All stepper-motor controllers are connected in series on one CAN bus: controller CAN_H and CAN_L run through J1 to J6.
  • A 120 ohm termination resistor is placed at both ends of the CAN bus, using twisted-pair wire.
  • Each motor node has its own address, set as J1=1, J2=2 and so on up to J6.
  • Stepper motors are supplied from 24 VDC through 14 AWG silicone wire connected in parallel, with careful solder joints and insulation.
  • The gripper servo runs from a 5 VDC supply.
  • CPU0 and CPU1 of the RA8P1 exchange motion plans and feedback over dual-core inter-processor communication (IPC).
  • The user-side IMU module sends attitude frames over serial to the user-side controller, which forwards them downstream.

What it can do

Written by Robotheca from the project's documents
  • Six-degree-of-freedom robotic arm with joints J1 to J6, made mostly from PLA 3D-printed parts.
  • Teleoperation via dual IMU master-slave control: user-side IMUs on the upper arm and forearm drive the arm wirelessly or over serial.
  • Stepper-motor joints with gearboxes and motor controllers; reach about 610 mm including gripper, target payload 350 g.
  • Configurable end effector; a parallel gripper is provided, and a gripper adapter supports other end effectors and an end-effector camera.
  • Inverse kinematics and motion planning run on the arm controller, which computes joint targets from the end-effector target.
  • Gripper driven by a ZP20S bus servo on a half-duplex single-wire UART, with a default 180 degree mode.

Works with AI

Found by Robotheca in the project's files at commit 2c92623, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.

Software

Framework
Not stated
Languages
C, C++, Verilog, Python, Shell
License
MIT

Robotheca doesn't review code. Read it before running it.

How to run it

Written by Robotheca from the project's documents.

  1. 1Import the ArmSync_Solution project into e2 studio, then import the ArmSync_Solution_CPU0 and ArmSync_Solution_CPU1 C/C++ projects.
  2. 2In each project's C/C++ Build settings, set the compiler include paths, linker script paths and linker options, including --specs=nano.specs, -u_printf_float, -u_scanf_float and --specs=nosys.specs.
  3. 3For the RA4M1 CMake projects (Armsync_Ctrller and Armsync_ArmIMU), set the ARM_TOOLCHAIN_PATH environment variable and select the ARM GCC kit in VS Code.
  4. 4Make sure the FSP version, Arm GCC toolchain, serial-port configuration and hardware version are compatible before building.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

The code

Free files

Every file of the project, at commit 2c92623.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/armsync/badge.svg)](https://robotheca.org/robots/armsync)
[![Robotheca buildability](https://robotheca.org/robots/armsync/score.svg)](https://robotheca.org/robots/armsync)

Other robot arms

All 80 robot arms
  • Ready to build

    Open source · free files

    Giraffe

    Robot arm · Intermediate

    Score
    Buildability 100 out of 100
    Cost
    ₹14,585.71≈ €137
  • Ready to build

    Open source · free files

    Hand Exoskeleton

    Robot arm · Intermediate

    Score
    Buildability 100 out of 100
    Cost
    ¥500≈ €67
  • Ready to build

    Open source · free files

    SO-101

    Robot arm · Beginner

    Score
    Buildability 98 out of 100
    Cost
    €226.30
  • Ready to build

    Open source · free files

    Koch v1.1

    Robot arm · Beginner

    Score
    Buildability 91 out of 100
    Cost
    €673

≈ € values are approximate, converted at the ECB euro reference rate of 30 Oct 2026. The creator's original price always comes first.