 Humanoid
Roboto Origin
A fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
- Work in progress
- Works with AI
- Level
- Advanced
- Buildability
- 81/100
- Well documented, not finished yet
- Cost
- Not stated
Projects their creators are still working on: worth following, not yet ready to rebuild. 27 robots on Robotheca, each with its licenses and its source on GitHub.
Page 1 of 2 · Ready to build first, then by buildability
HumanoidA fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
 Quadruped
An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
 Home
A lightweight home robot with modular architecture, supporting remote control, voice interaction, and human following.
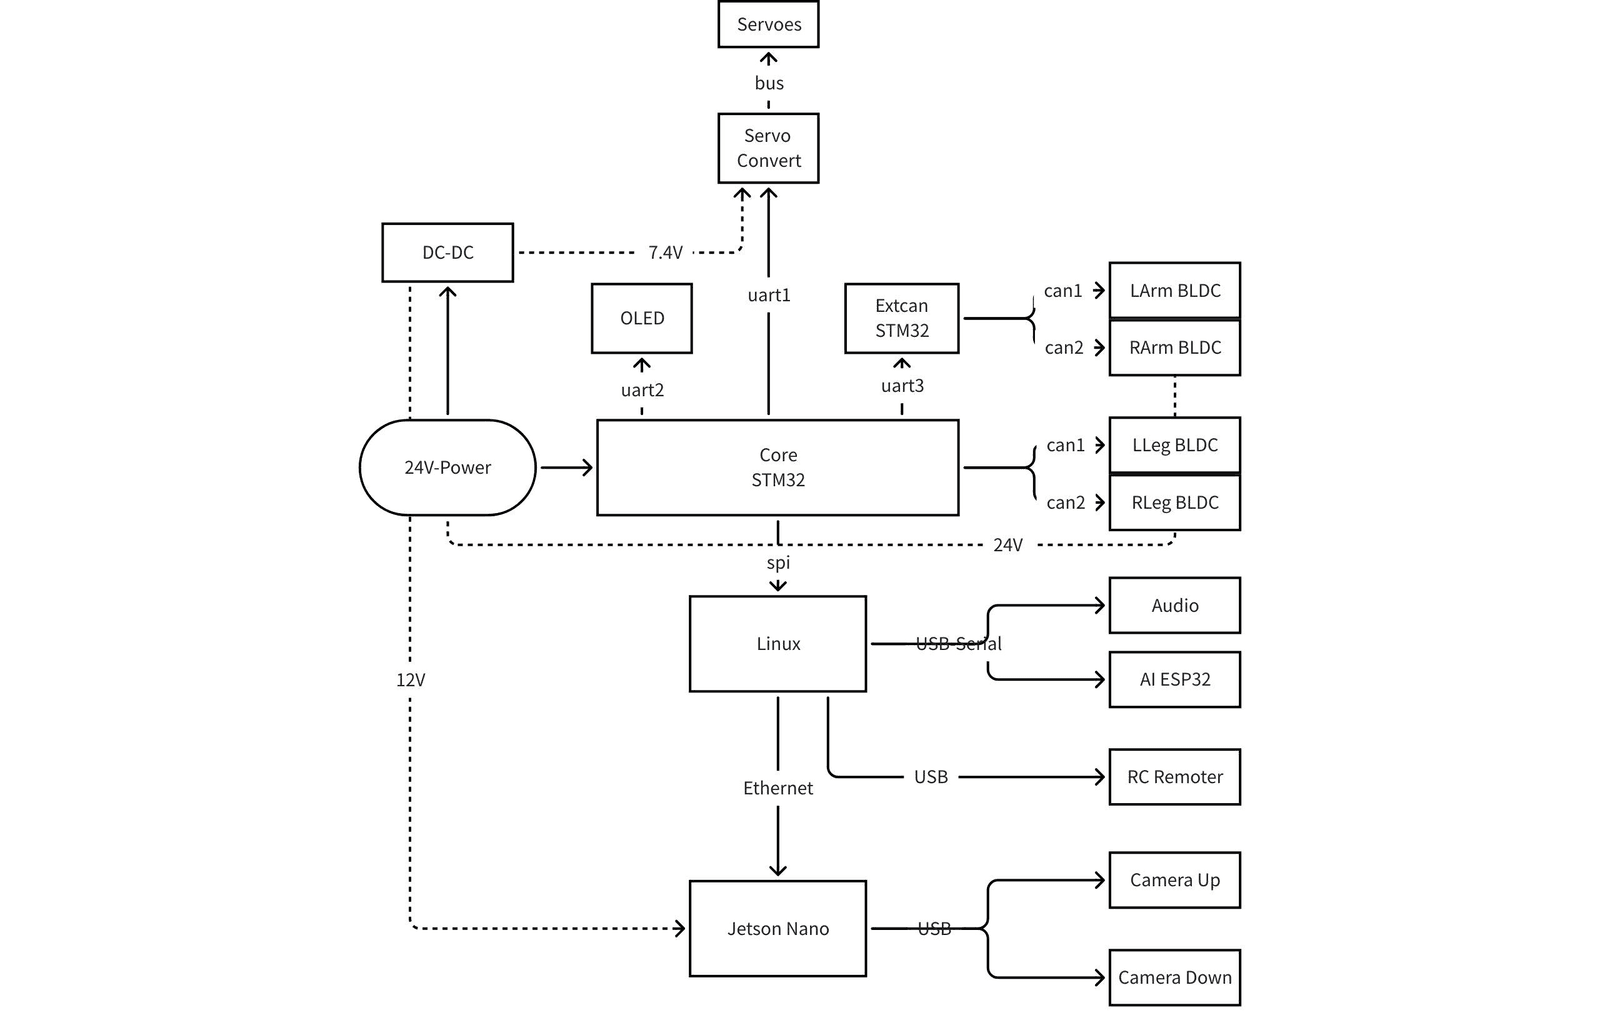 Humanoid
A small 22-degree-of-freedom humanoid robot designed for reinforcement learning and imitation learning, featuring a rotatable waist, head, and upper limbs.
An open-source 6-degree-of-freedom robotic arm designed for simulation, kinematics research, and reinforcement learning-based end-effector control.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
 Humanoid
An open-source, low-cost humanoid robot designed for AI experimentation and education.
A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
 Other
An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.
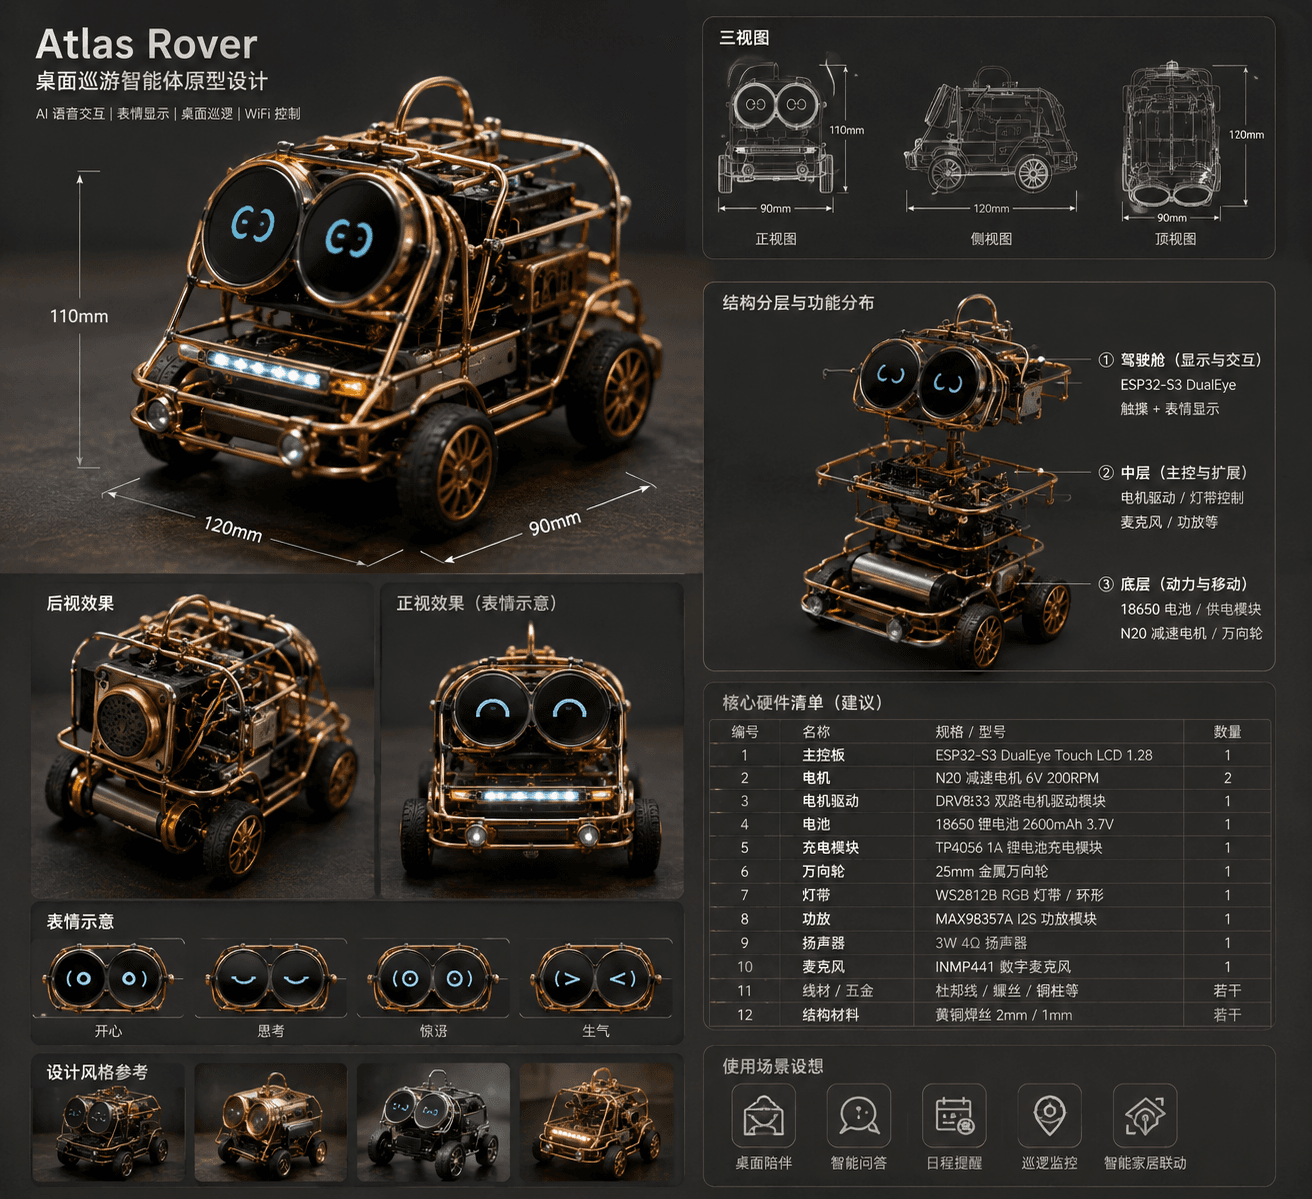 Wheeled
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
 Humanoid
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
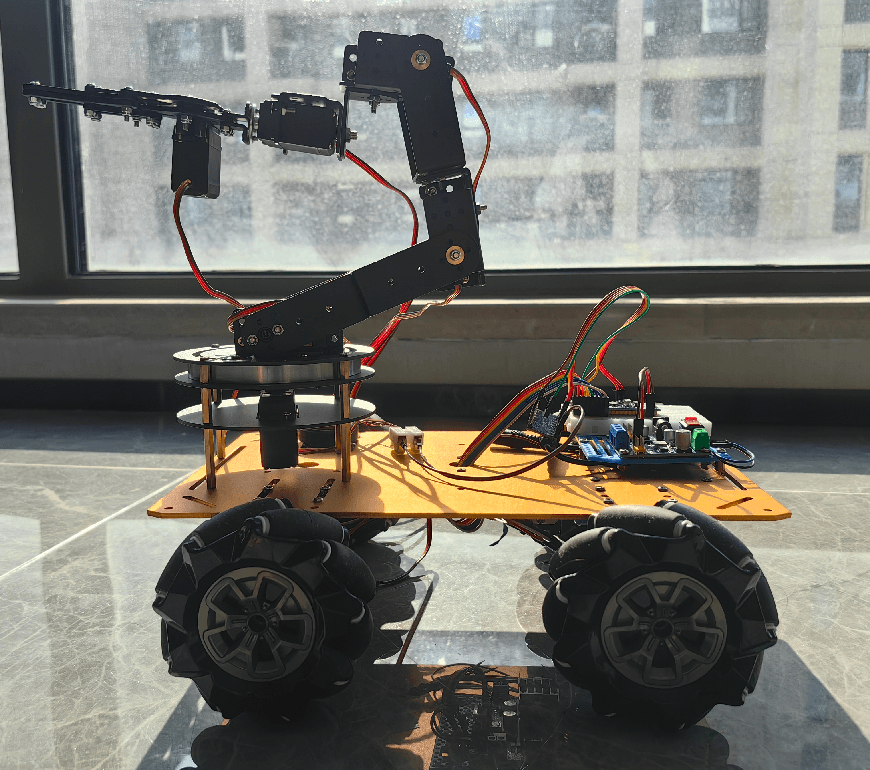 Wheeled
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
An open-source dexterous hand system that uses gesture recognition to control a 3D-printed robotic hand and play music.
A 6-DOF robotic arm built with 3D-printed parts and Feetech STS3215 bus servos, controlled via LeRobot.
 Wheeled
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
A series of open-source remote-controlled mini car modification projects with multiple chassis sizes and control schemes.
A self-balancing robot using STM32F103C8T6 with Mahony algorithm for attitude estimation.
A low-cost DIY writing machine that draws on a vertical surface using two stepper motors and a servo-controlled pen.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
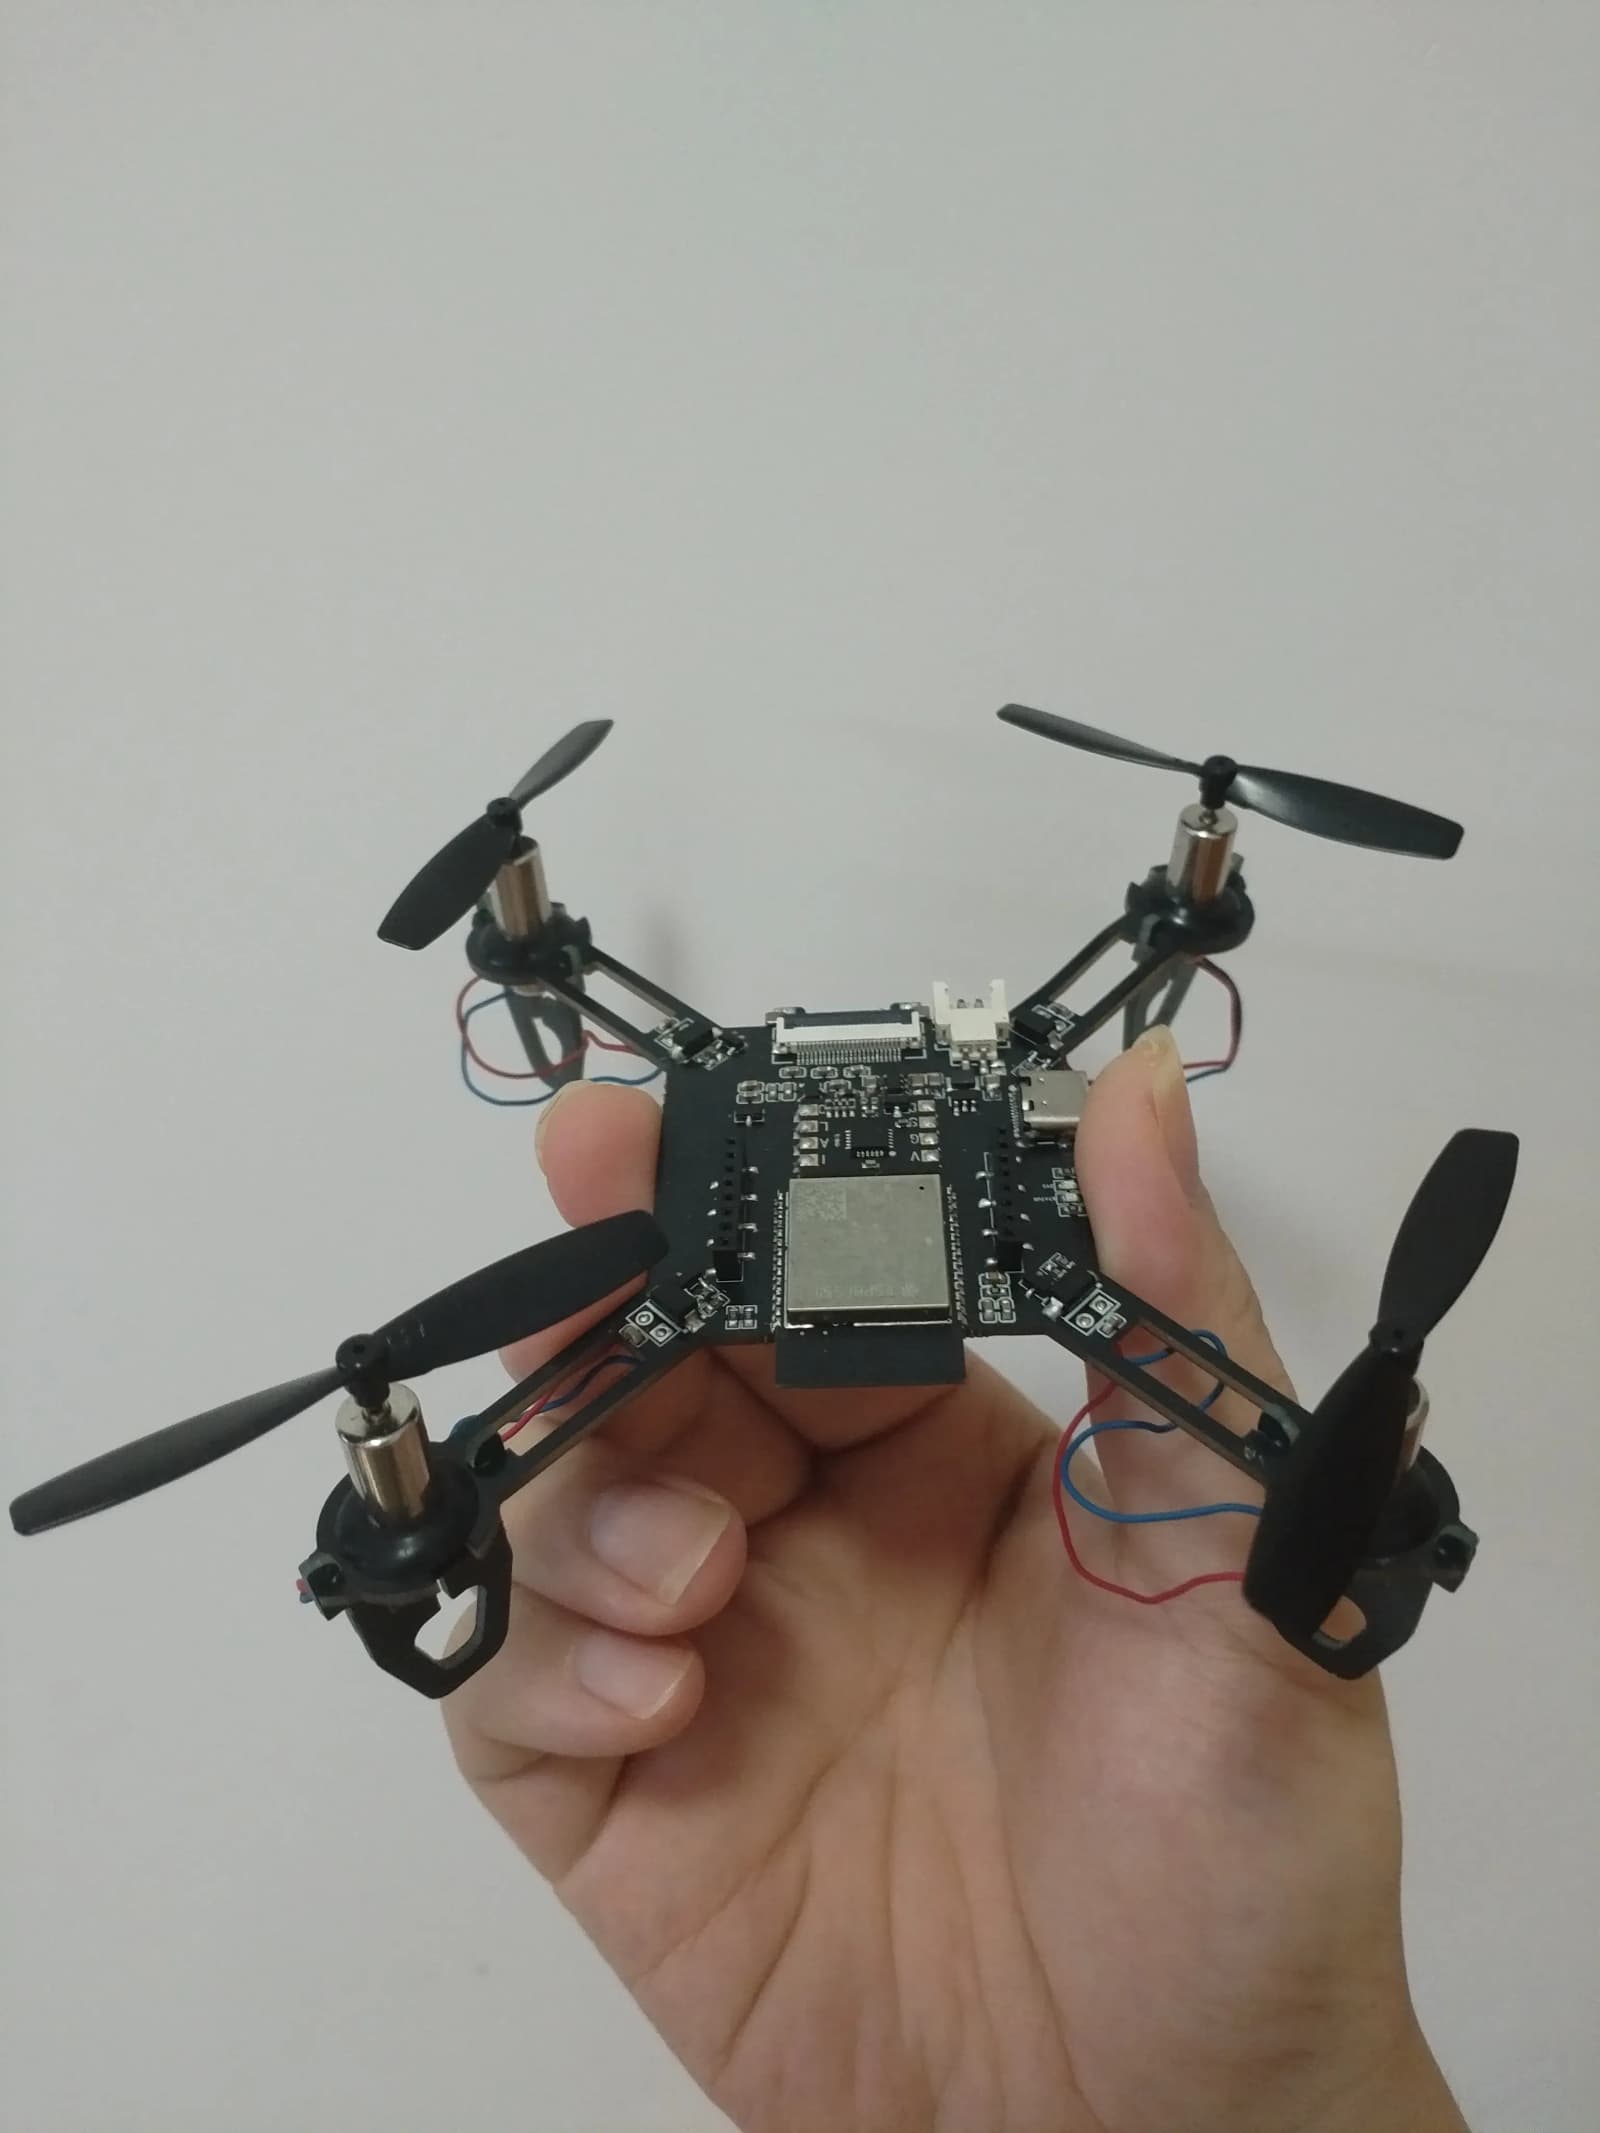 Drone
An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.
An 8-degree-of-freedom parallel quadruped robot using Xiaomi CyberGear motors and STM32F427 control.
An open-source ESP-FLY drone with CAD models, Crazyflie-based flight firmware, a PyQt6 PC debugging tool and an Android control app.
Robots 1–24 of 27