Skip to content

Other robots

Robots that fit none of the other types. 49 robots on Robotheca, each with its licenses and its source on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

49 robots of 270

Page 1 of 3 · Ready to build first, then by buildability

  • No photo yet
    Other

    Open Duck Mini v2

    A 3D-printed bipedal robot about 42 cm tall, inspired by Disney's BDX droids, that walks with reinforcement-learning policies trained in MuJoCo.

    • Works with AI
    Level
    Intermediate
    Buildability
    85/100
    Ready to build
    Cost
    Not stated
  • Other

    Koriobots

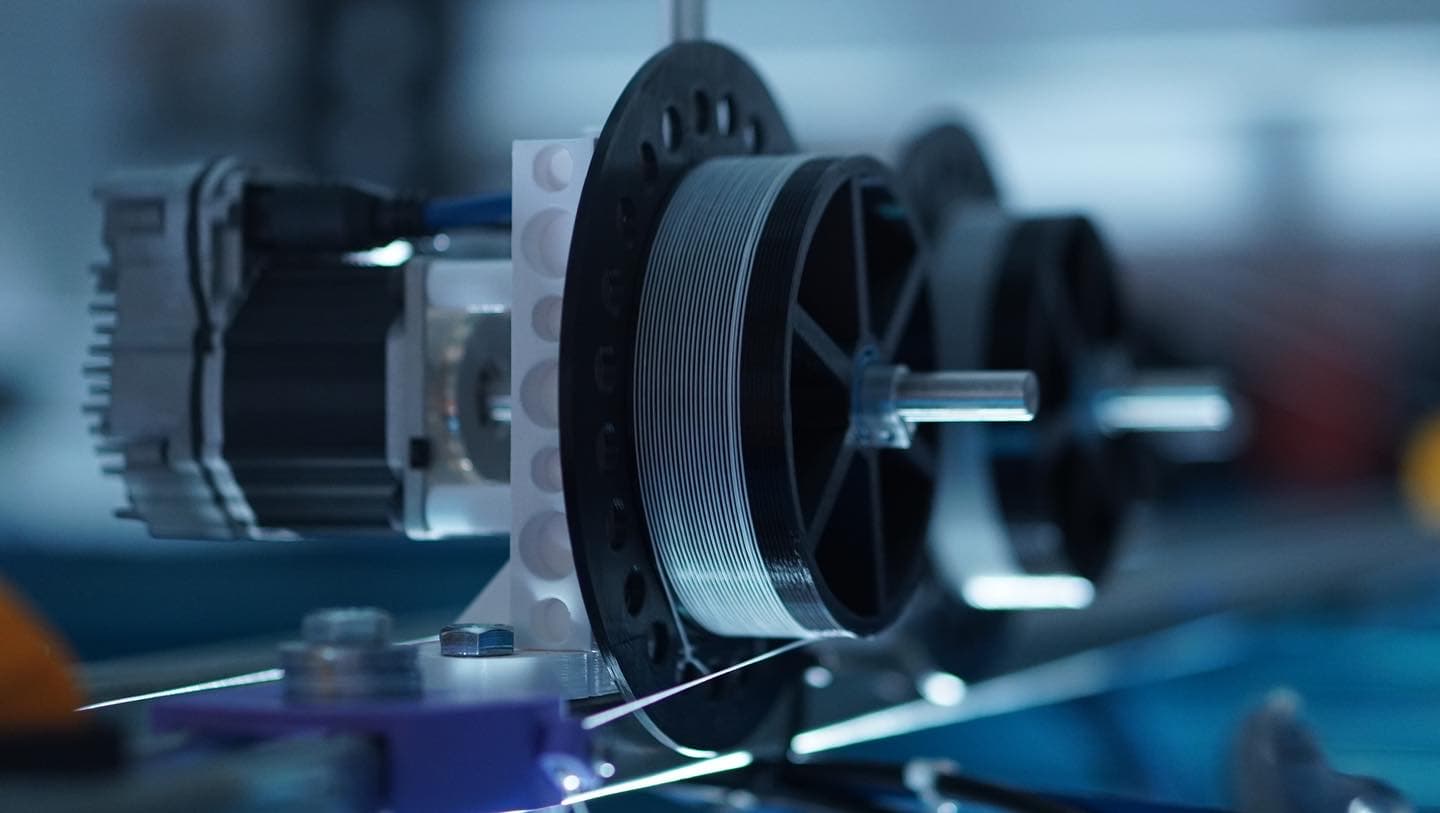
    A toolkit for cable-driven robots that move objects through the air, built from 3D-printed cable drums on industrial servo motors, made for art installations.

    Level
    Intermediate
    Buildability
    78/100
    Buildable with some effort
    Cost
    $972.06≈ €868 (ECB rate, 14 Oct 2026)
  • Other

    Hexapod

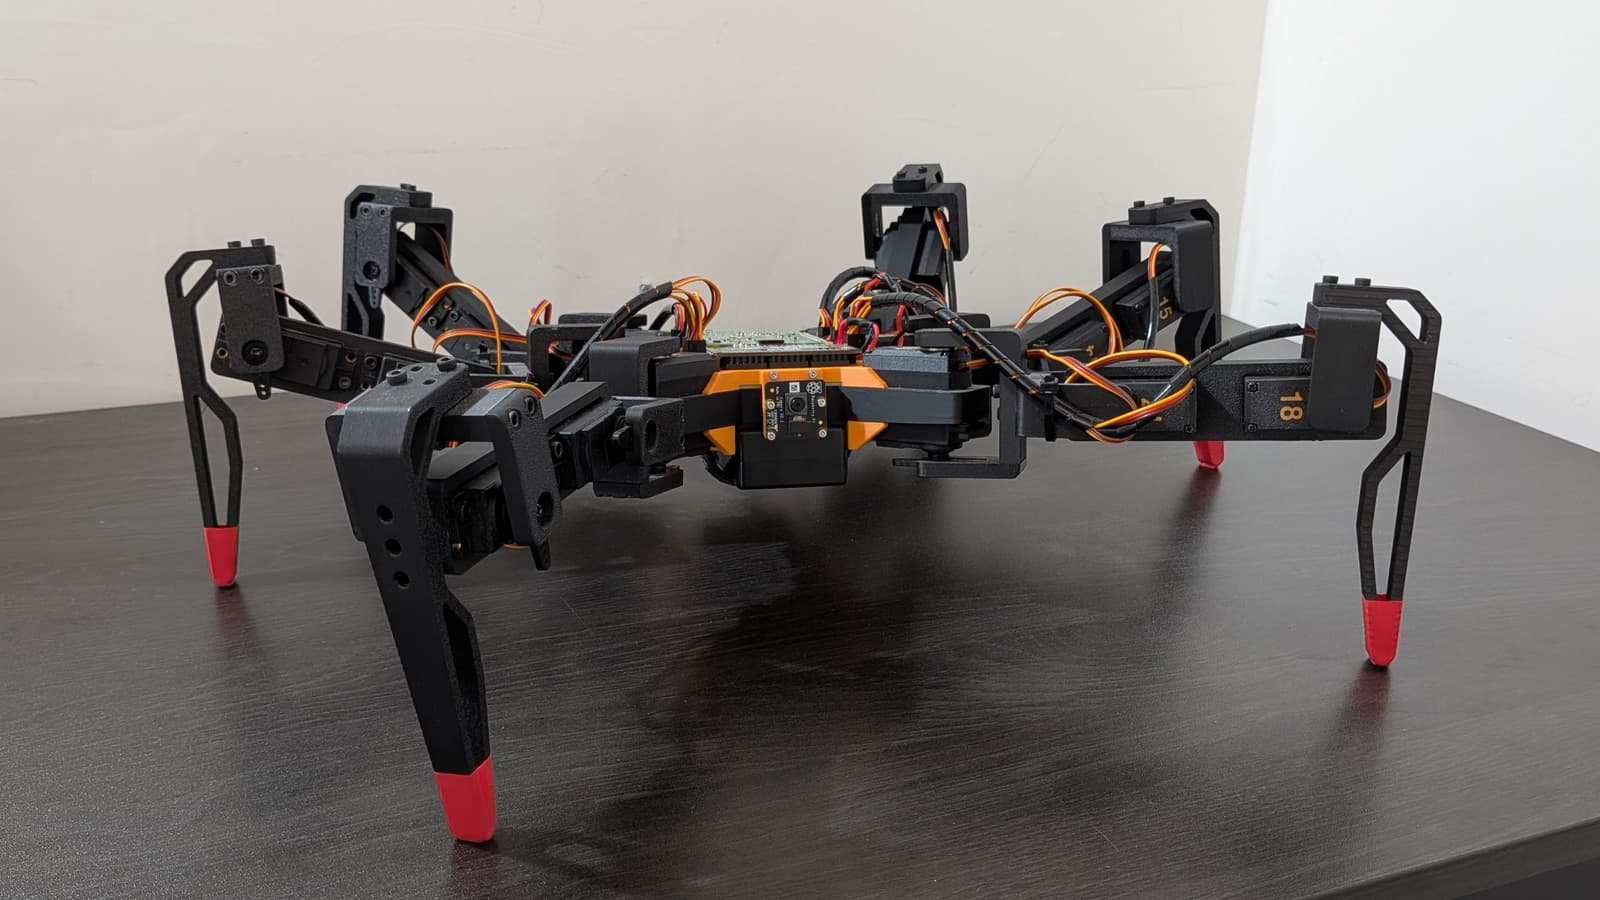
    A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.

    Level
    Advanced
    Buildability
    71/100
    Buildable with some effort
    Cost
    €280
  • Other

    Balancio-Kit

    An ultra-low-cost self-balancing robot that can run a neural network to stay balanced and be controlled wirelessly, built for teaching RL, ML, AI and control.

    • Works with AI
    Level
    Intermediate
    Buildability
    65/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Arduino SimpleFOC Balancer

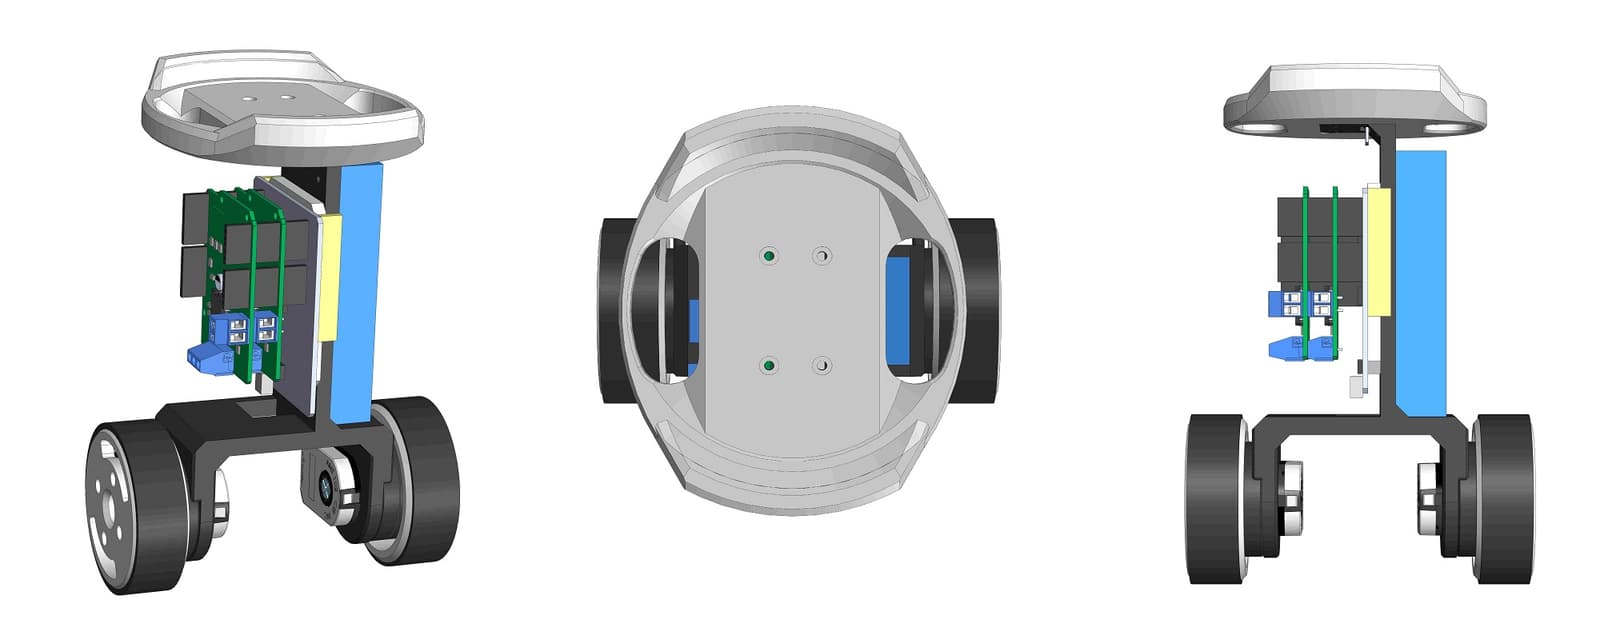
    A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.

    Level
    Advanced
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • Other

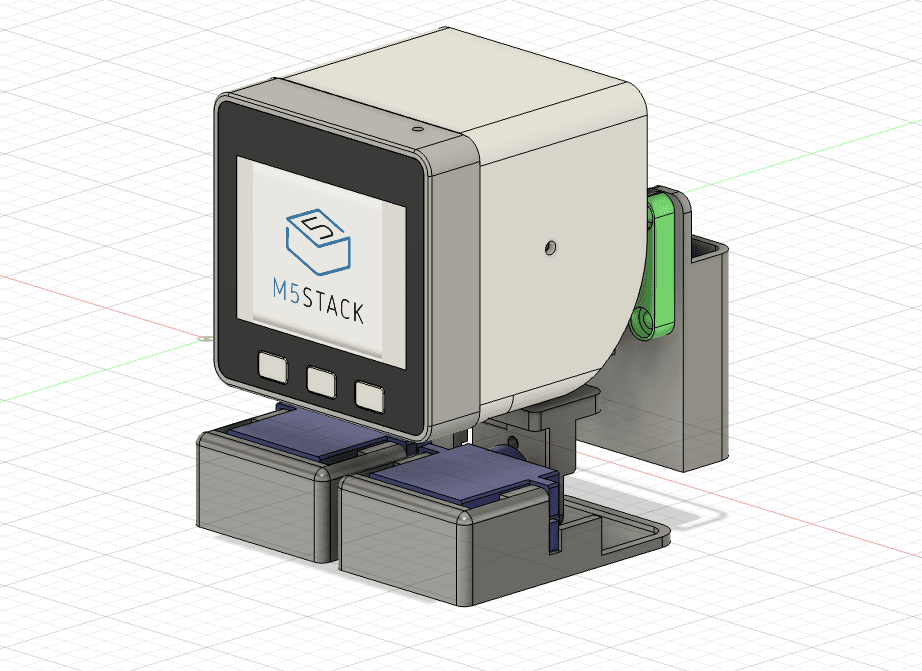
    M5Stack Walk-chan

    A small bipedal walking robot controlled by an M5Stack board, with a sliding battery that shifts its balance between legs.

    Level
    Intermediate
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Other

    WheelLeg FullStack Challenge Robot

    A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.

    • Work in progress
    Level
    Advanced
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Balance Ball

    A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Other

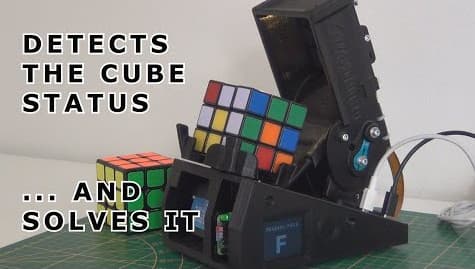
    CUBOTino autonomous

    A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.

    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

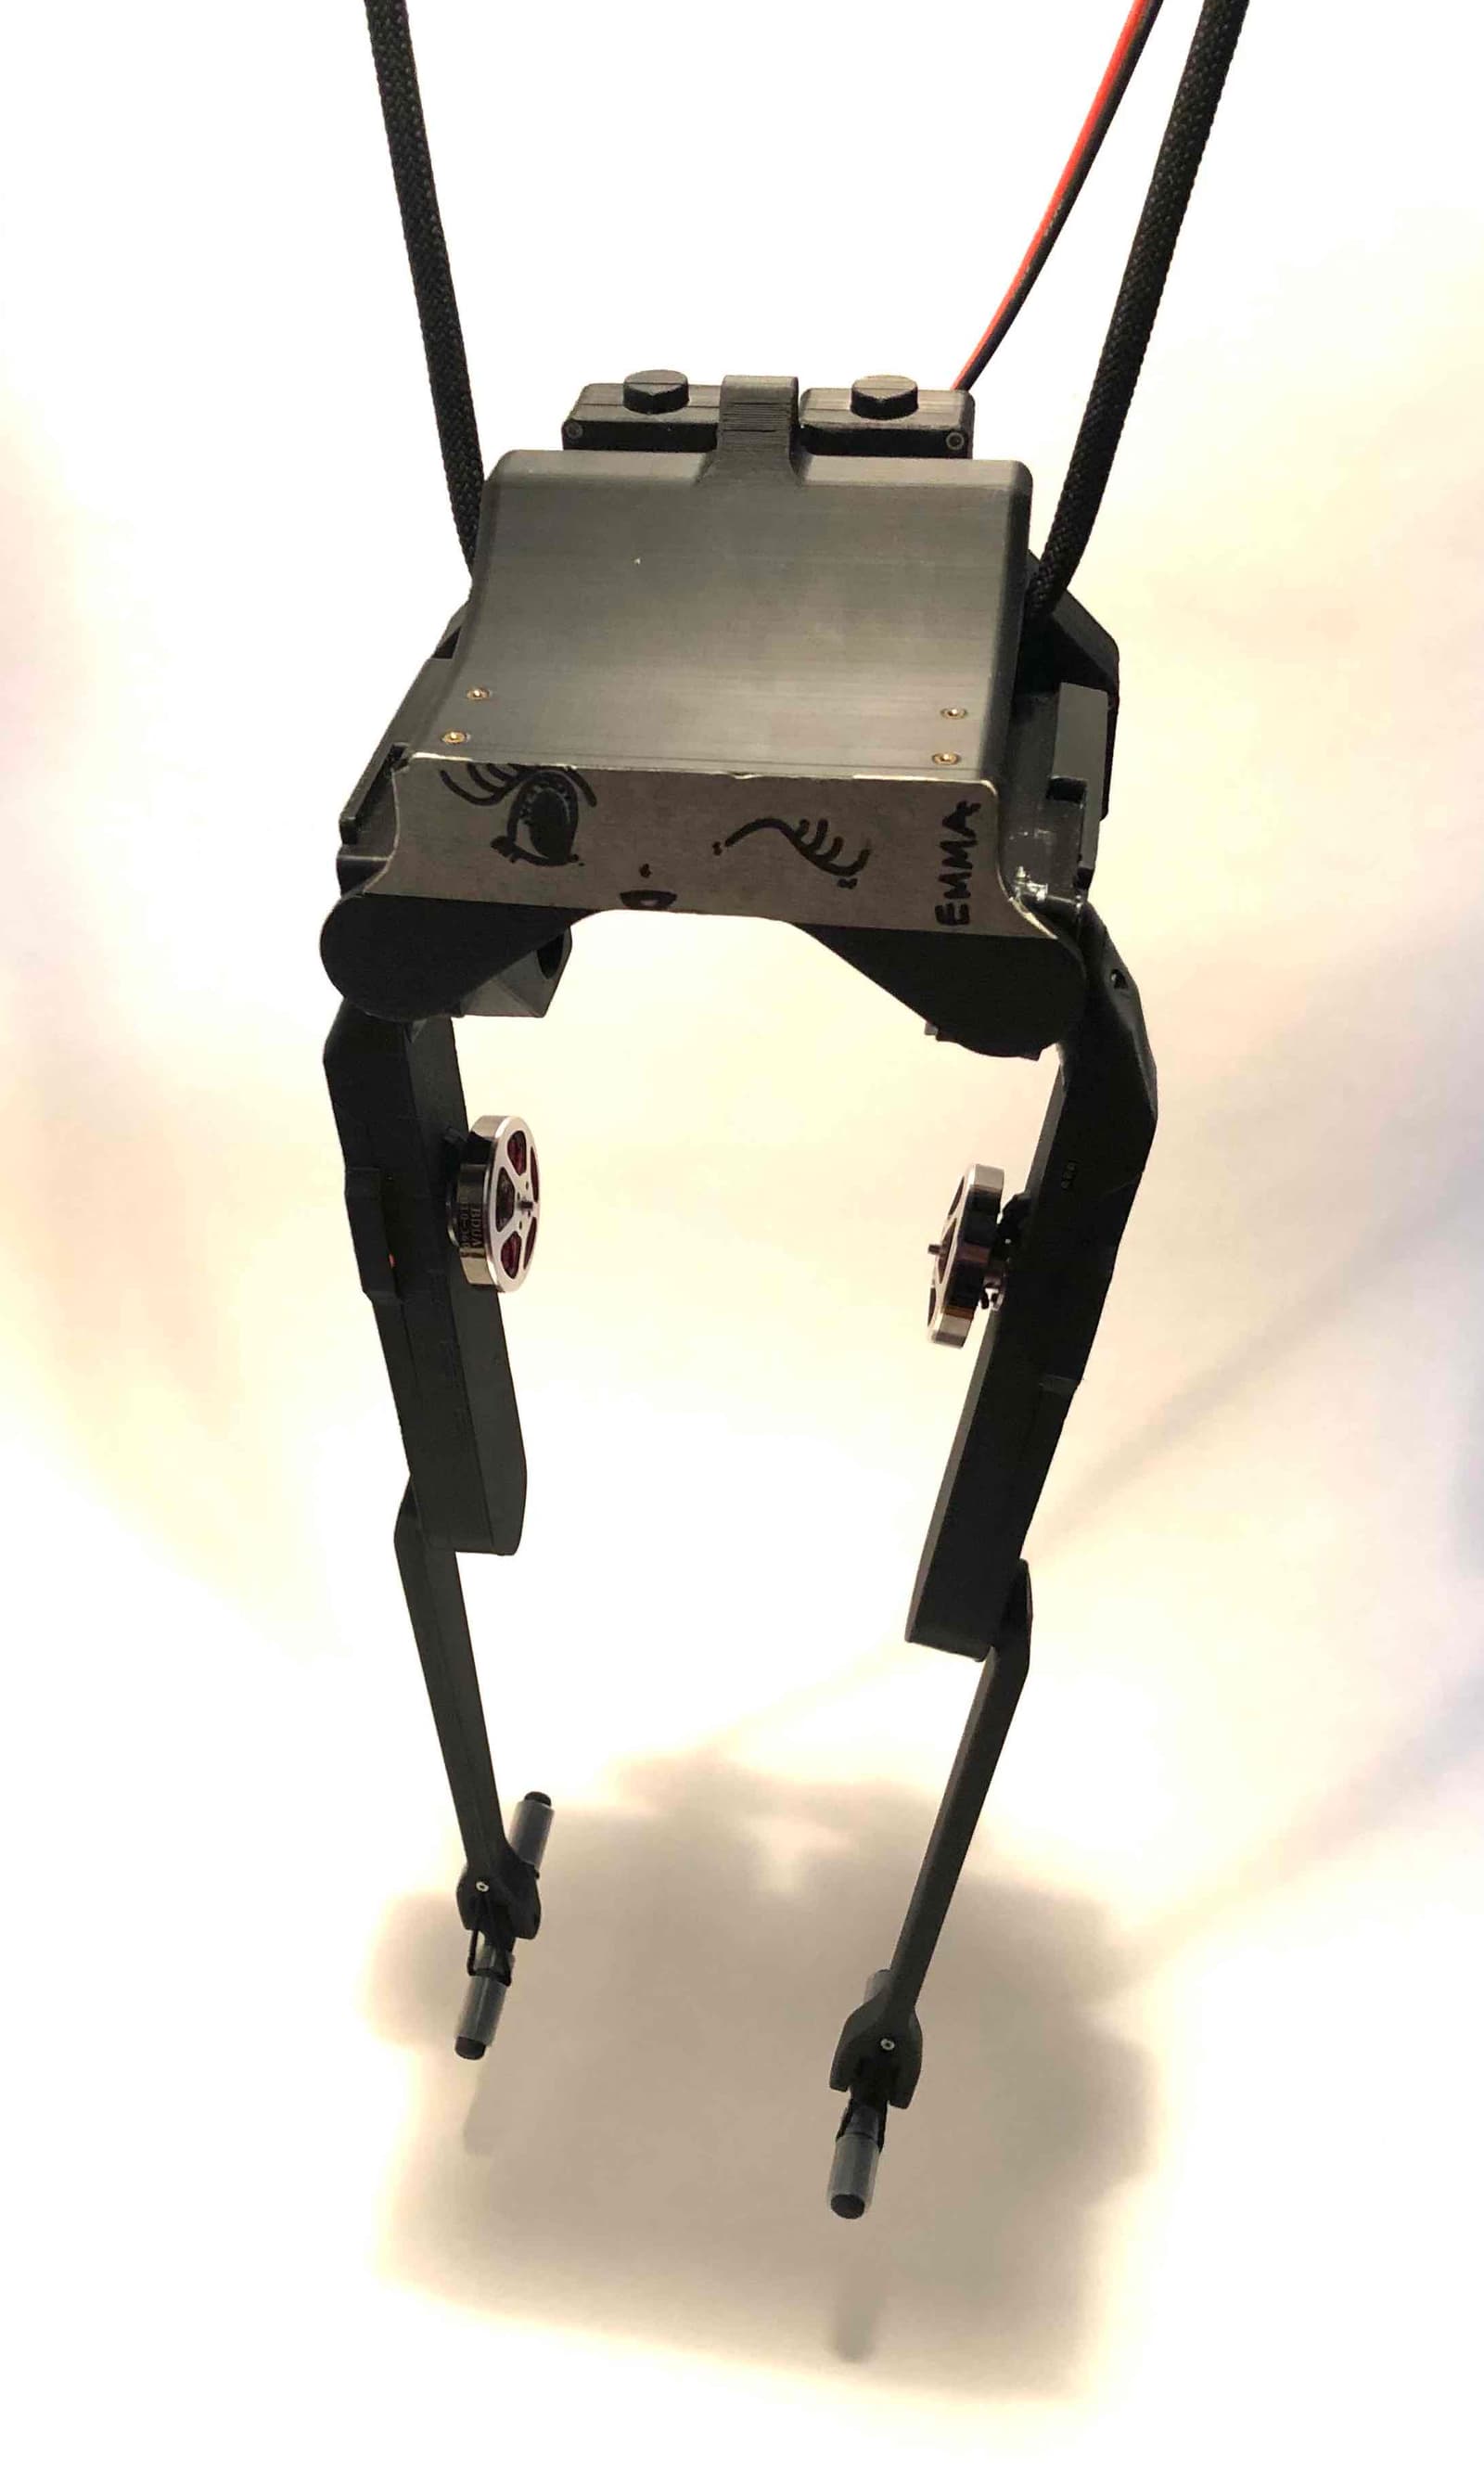
    Dagor Biped

    A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    MABEL

    MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    SoftRobotETF

    A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    AcroMonk

    A minimalist underactuated brachiating robot that swings along a horizontal ladder bar using one quasi-direct drive actuator and passive grippers.

    • Works with AI
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Antagonistic Tendon Driven Continuum Robot

    A research continuum robot with 4 degrees of freedom that drives two tendons per antagonistic pair with a single servo and measures tendon force with load cells.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    DengFOC Inverted Pendulum

    A low-cost, small inverted pendulum robot using DengFOC motor driver and SimpleFOC for balance control.

    Level
    Intermediate
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Stack-chan

    A JavaScript-driven, super-kawaii desktop robot built on the M5Stack platform, with open-source firmware, MODs, and printable cases.

    • Works with AI
    Level
    Beginner
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    OpenKidCar (Ganbei No.1)

    An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.

    • Work in progress
    • Works with AI
    Level
    Intermediate
    Buildability
    48/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Hexapod

    A family of 18-DOF, 3D-printed hexapod walking robots powered by an ESP32, controlled over WiFi or live pose streaming.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Hexapod v2 (Linkit 7697)

    A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    LZU Ascento

    A two-wheeled, four-bar-linkage wheel-leg balancing robot modeled on the ASCENTO, controlled with LQR on an STM32H723 board.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Penny#3

    A low-budget three-servo hexapod robot that walks, dances and avoids obstacles using infrared proximity sensors.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    €10
  • Other

    RhinoV2.0 Adaptive Gripper

    An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Other

    ZeroBug

    A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Mech Butterfly

    A biomimetic butterfly robot controlled via ESP32C3 using ESP-NOW wireless communication.

    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated

Robots 1–24 of 49

More to explore