Skip to content

Other robots

Robots that fit none of the other types. 49 robots on Robotheca, each with its licenses and its source on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

49 robots of 270

Page 2 of 3 · Ready to build first, then by buildability

  • Photo on GitHub
    Other

    Tdrone

    An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
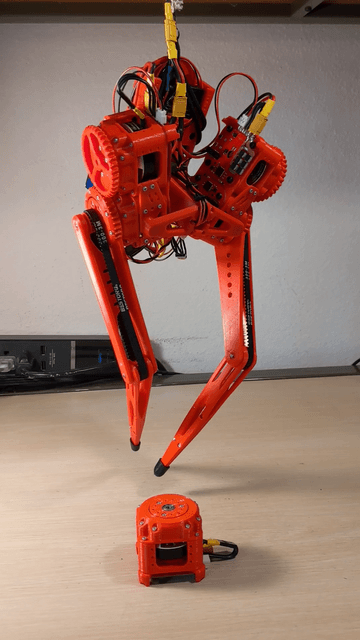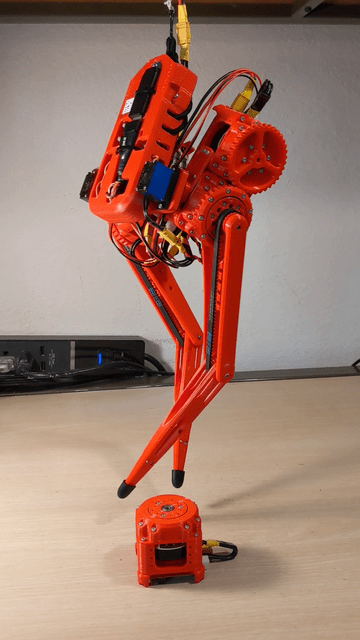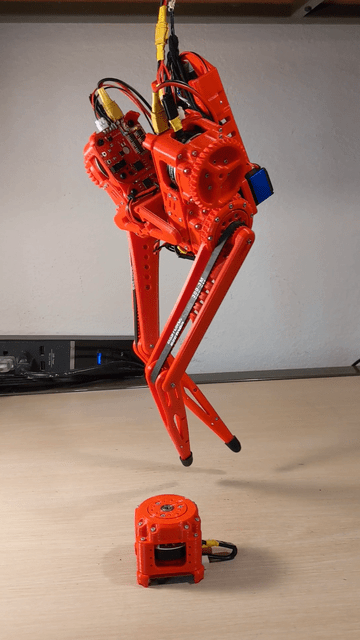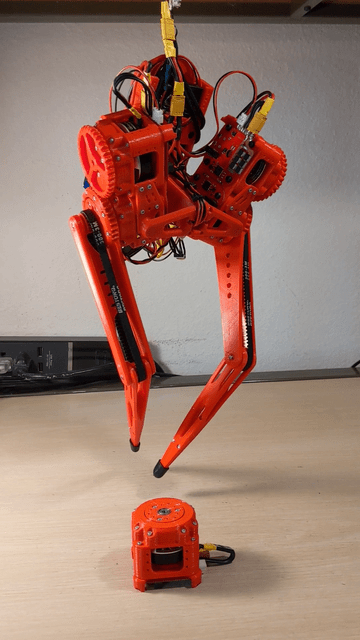
    • No license
    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    TipTap

    A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Upkie

    Open-source wheeled biped robot with wheels for balance and legs for uneven terrain, controllable in simulation and on hardware.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Woodpecker Writing Machine

    A low-cost DIY writing machine that draws on a vertical surface using two stepper motors and a servo-controlled pen.

    • Work in progress
    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    ¥25.80≈ €3 (ECB rate, 14 Oct 2026)
  • No photo yet
    Other

    DrawBot

    A writing robot with a 2040 aluminum frame and Core-XY structure that automates handwriting tasks.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    ElectronBot Peripheral

    A collection of 3D-printable accessories and decorations for the ElectronBot robot.

    • No license
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Peeqo

    A desktop robot that responds entirely in its own voice, built from 3D-printed parts and custom electronics.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    ProtoBot

    An ultra cheap, simple two-motor robot with four sensors that a middle schooler can build in several hours.

    Level
    Beginner
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Wheel-legged Robot (Balance Leg V2)

    A wheel-legged balancing robot with leg-joint motors and hub-wheel motors, controlled by a custom STM32H723 board using LQR and VMC.

    • No license
    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Wheelbot

    A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    ZGPS-01

    A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    ALARIS Hand

    An open-source 6-DOF anthropomorphic robotic hand with linkage-based fingers and worm-and-rack transmissions, intended as a low-cost platform for research and education.
    Level
    Advanced
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Combat Robot

    A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.

    • Competition robot
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Hexapod Robot STC15 Controller

    A hexapod robot controlled by an STC15 microcontroller, featuring a 21-channel servo controller and 3D-printable parts.

    • No license
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    ONE-Robot

    A self-balancing unicycle robot based on IMU and STM32.

    • No license
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Robot Nano Hand

    An AI-powered robot hand that can be rebuilt by 3D printing its parts.

    • Works with AI
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Cube Solver

    A compact robot that solves a scrambled 3x3 Rubik's Cube using a STM32F407 microcontroller.

    • No license
    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    LEAP ROS2

    A low-cost ROS2 robot designed for students and hobbyists to learn robotics and ROS2 development through hands-on assembly and programming.
    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    ¥200≈ €27 (ECB rate, 14 Oct 2026)
  • Other

    Stepping Balancer

    A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.

    Level
    Advanced
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Zhuge Liang Four-Wheel Car Kart Hardware

    Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.

    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Rhino Gripper

    An open-source two-finger adaptive gripper inspired by the Robotiq design.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Balance Car 2

    A two-wheeled self-balancing car based on STM32.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    SmartCar

    An open-source smart car designed for the 18th Smart Car Competition, featuring camera-based recognition and control.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    105 underwater robot (sea version)

    An underwater robot made by team 105, sea version: its control programs and the circuit boards of the main board and the power compartment.

    • No license
    Level
    Advanced
    Buildability
    5/100
    Incomplete documentation
    Cost
    Not stated

Robots 25–48 of 49

More to explore