Skip to content

Photo and 3D model

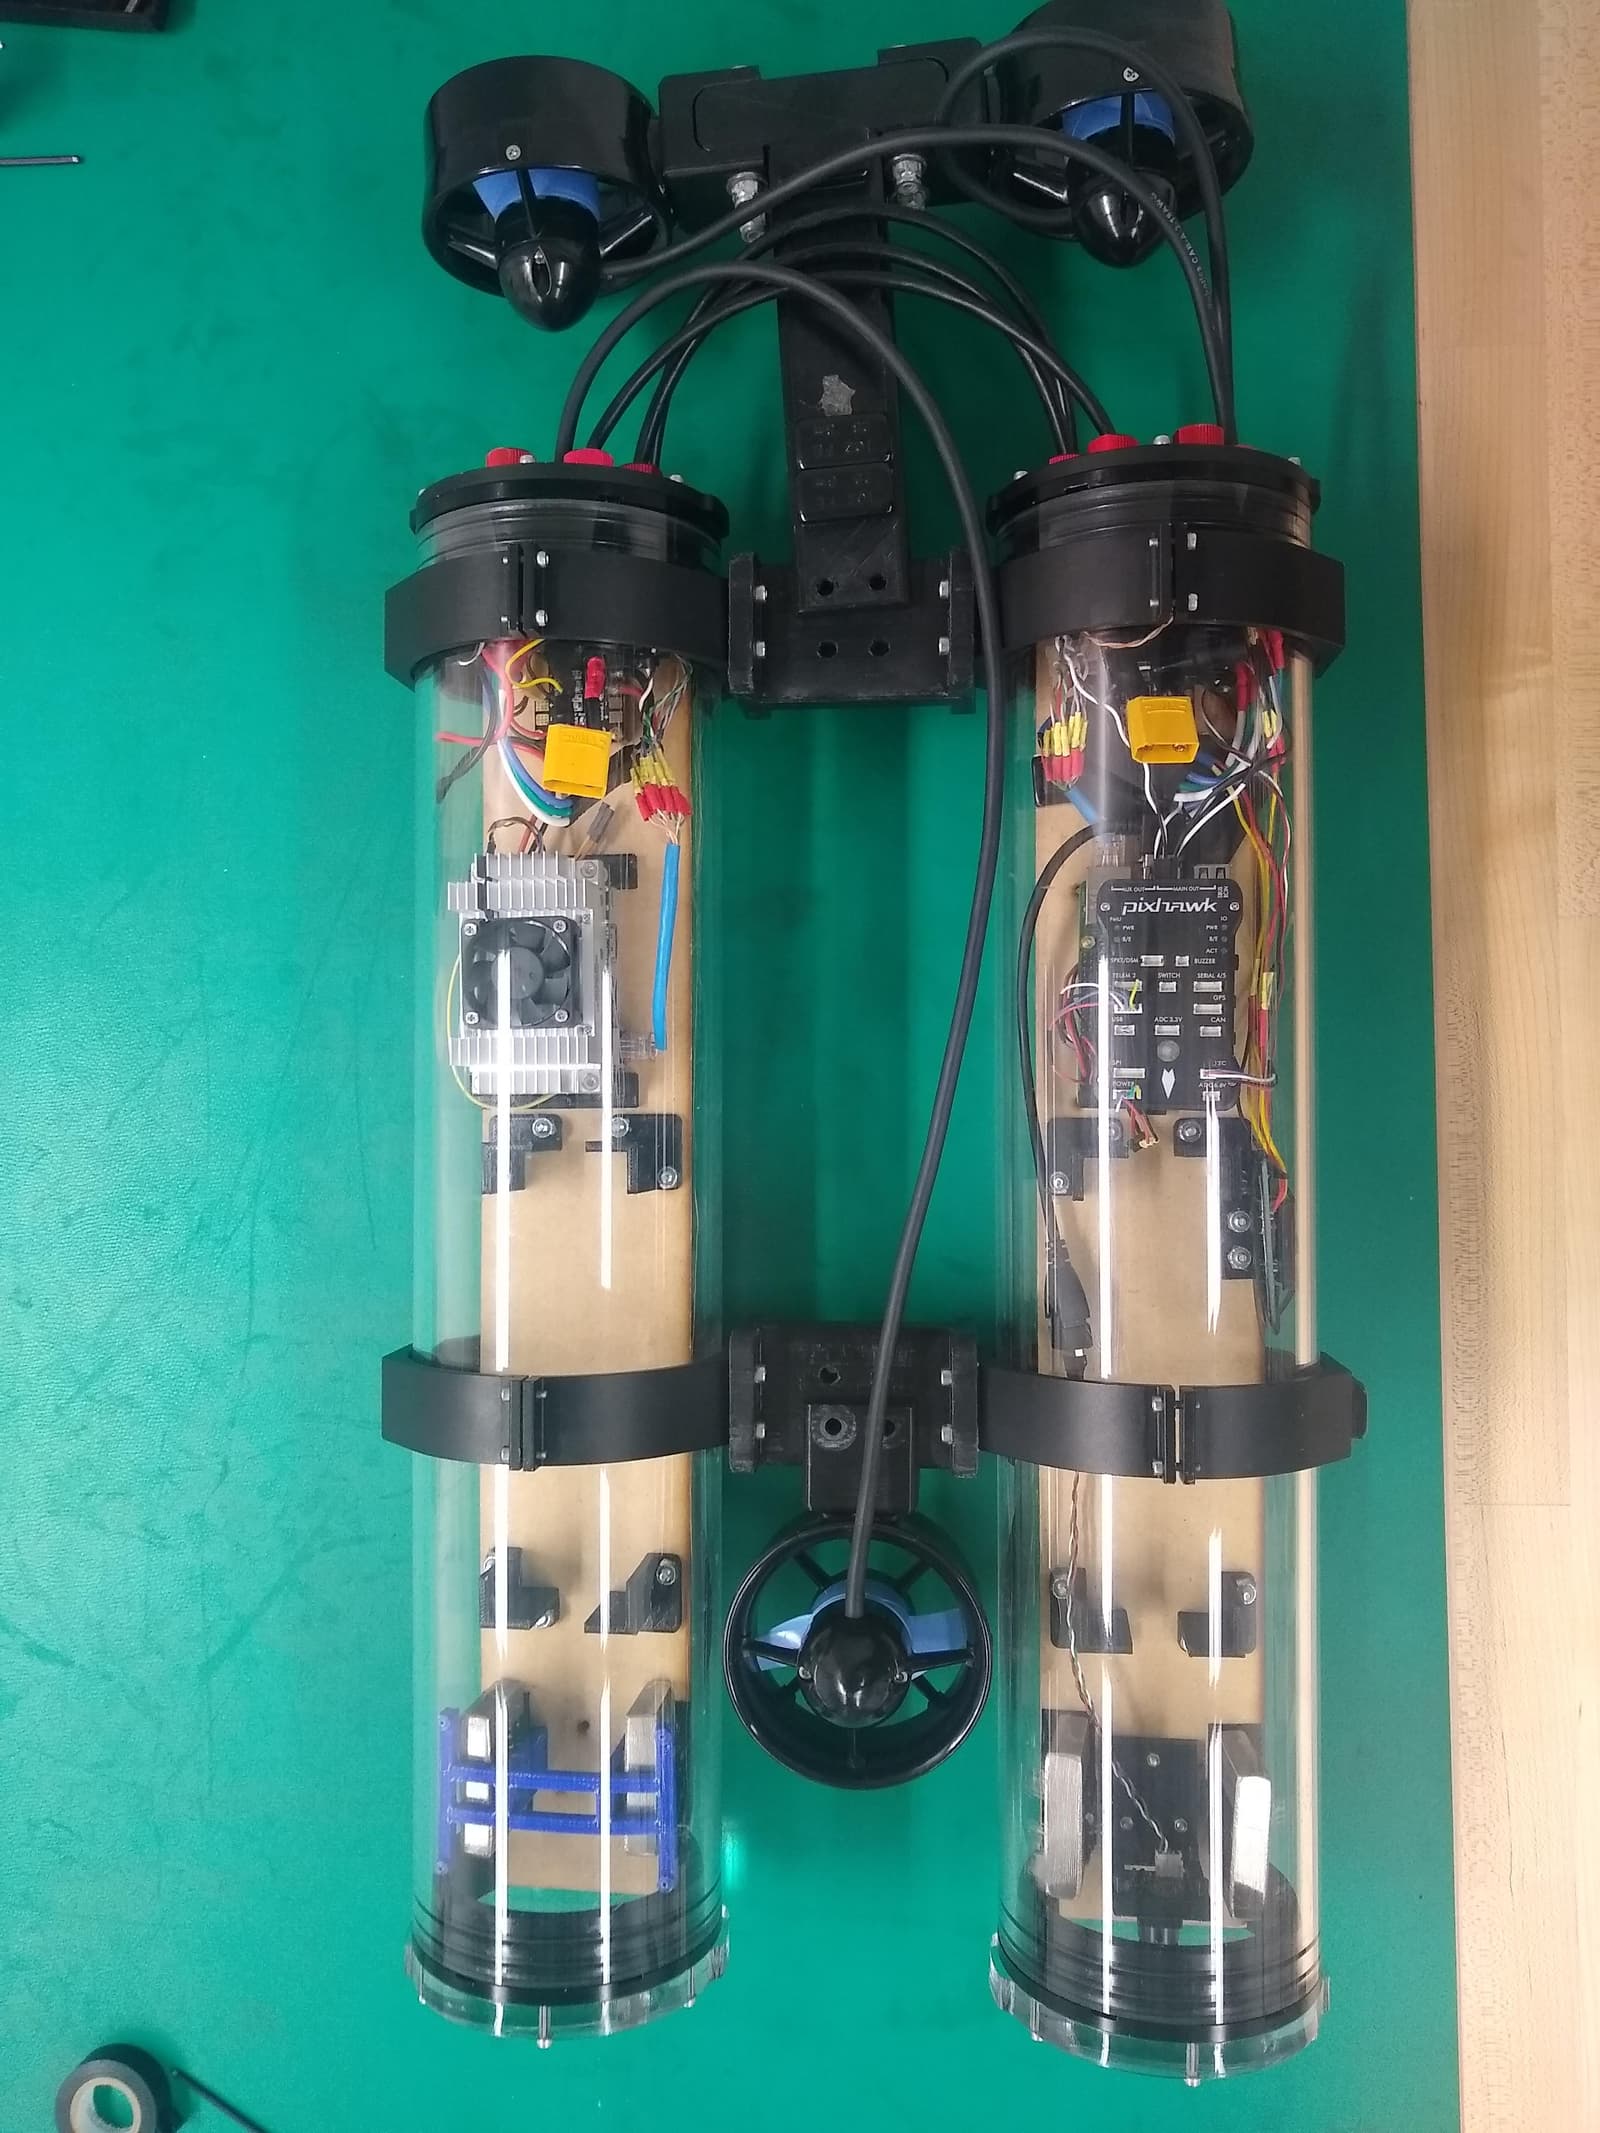
LoCO, photo from its repository
Photo@LoCO-AUV (opens in a new tab)CC-BY-SA-4.0source file (opens in a new tab)

3D preview converted from github.com/LoCO-AUV/loco_config at cf30cb1, under CC-BY-SA-4.0. View the original files from GitHub (8.2 MB) (opens in a new tab)

Open source · free files

LoCO

Other

LoCO is a low-cost, open-source autonomous underwater vehicle (AUV).

Project information

Buildability
63/100Buildable with some effort
Estimated cost
Not stated
Level
Advanced
Parts
Not listed
Commercial use
Allowed
Works with
ROS

This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.

Which files (4 scripts)

Suggested by Robotheca, created by @LoCO-AUV (opens in a new tab), from github.com/LoCO-AUV/loco_config (opens in a new tab), pinned to commit cf30cb1 (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

This repository has no parts list Robotheca can read yet.

Why it scores 63

It measures the published files, not the robot · How we score

63/100

Buildable with some effort

How complete the published files are for rebuilding this robot, measured by Robotheca at commit cf30cb1. It isn't a rating of the robot. Counted out of 80 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD files29 printable parts (STL, 3MF), 67 CAD source files.20/20
  2. –Robot descriptionNo URDF. Not counted: the score is made of the parts that apply.Optional: add a URDF, and the robot can be seen in 3D and tried in the browser.Not counted
  3. 2Parts listNo parts list in the repository or linked.Most points to gain: Link to your parts list, or add it to the repository (a CSV or a Markdown table) with quantities, prices and where to buy each part.0/20
  4. 3SoftwareCode in this repository, instructions to install or run it, built on ros.15/15
  5. 4DocumentationREADME of 2,658 characters with 0 pictures; 0 build steps.Split the build into at least 3 steps. Show the robot and its assembly in pictures in the README.5/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 5LicensesHardware: CC-BY-SA-4.0; software: GPL-3.0-only.10/10

Build it

The guide appears here as you scroll.

Guide by @LoCO-AUV (README.md), under CC-BY-SA-4.0 (hardware) and GPL-3.0-only (software).

More guides

Wiring and electronics

Notes written by Robotheca from the project's documents, not by its creator

Main parts: Robotheca's summary

  • Raspberry Pi is referenced through its rpi_config_files folder.
  • Pixhawk flight controller is referenced in a wiring diagram filename.
  • TX2 board is referenced through its tx2_config_files folder.
  • An operator control unit (OCU) is referenced through its ocu_config_files folder.
  • A power switch and power circuit are shown in the diagrams.

Connections: Robotheca's summary

  • Diagrams show Raspberry Pi wiring to a Pixhawk.
  • A power circuit diagram and a power switch wiring diagram are included in the repository images.

What it can do: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator
  • LoCO is described as a low-cost, open-source autonomous underwater vehicle (AUV).
  • This repository is a meta-repository holding the current stable package configuration for the robot.
  • The documents mention it being built and used for research and education.

Software

Framework
ROS
Languages
Shell
License
GPL-3.0-only

Robotheca doesn't review code. Read it before running it.

How to run it: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator.

  1. 1Configuration files are split into folders for the OCU, Raspberry Pi and TX2, each with its own shell scripts.
  2. 2The per-folder README files say where these files should be placed, but their content is not detailed in the provided documents.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

The code

Free files

Every file of the project, at commit cf30cb1.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/loco/badge.svg)](https://robotheca.org/robots/loco)
[![Robotheca buildability](https://robotheca.org/robots/loco/score.svg)](https://robotheca.org/robots/loco)

Other other robots

All 100 other robots
  • Ready to build

    Open source · free files

    Koriobots

    Other · Intermediate

    Score
    Buildability 98 out of 100
    Cost
    $972.06≈ €866
  • Ready to build

    Open source · free files

    AmazingHand

    Other · Intermediate

    Score
    Buildability 88 out of 100
    Cost
    under €200
  • Ready to build

    Open source · free files

    DigiArm Prosthetic Hand

    Other · Advanced

    Score
    Buildability 85 out of 100
    Cost
    $250≈ €223
  • 3D render

    Open source · free files

    FloatingFace

    Other · Advanced

    Score
    Buildability 100 out of 100
    Cost
    $328.47≈ €293

≈ € values are approximate, converted at the ECB euro reference rate of 5 Nov 2026. The creator's original price always comes first.