RhinoV2.0 Adaptive Gripper
An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.
- Other
- Open source
- 3D printable
Suggested by Robotheca, created by @Ragtime-LAB (opens in a new tab), from github.com/Ragtime-LAB/RhinoV2.0_Gripper (opens in a new tab). Pinned to commit 099a3cd (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo
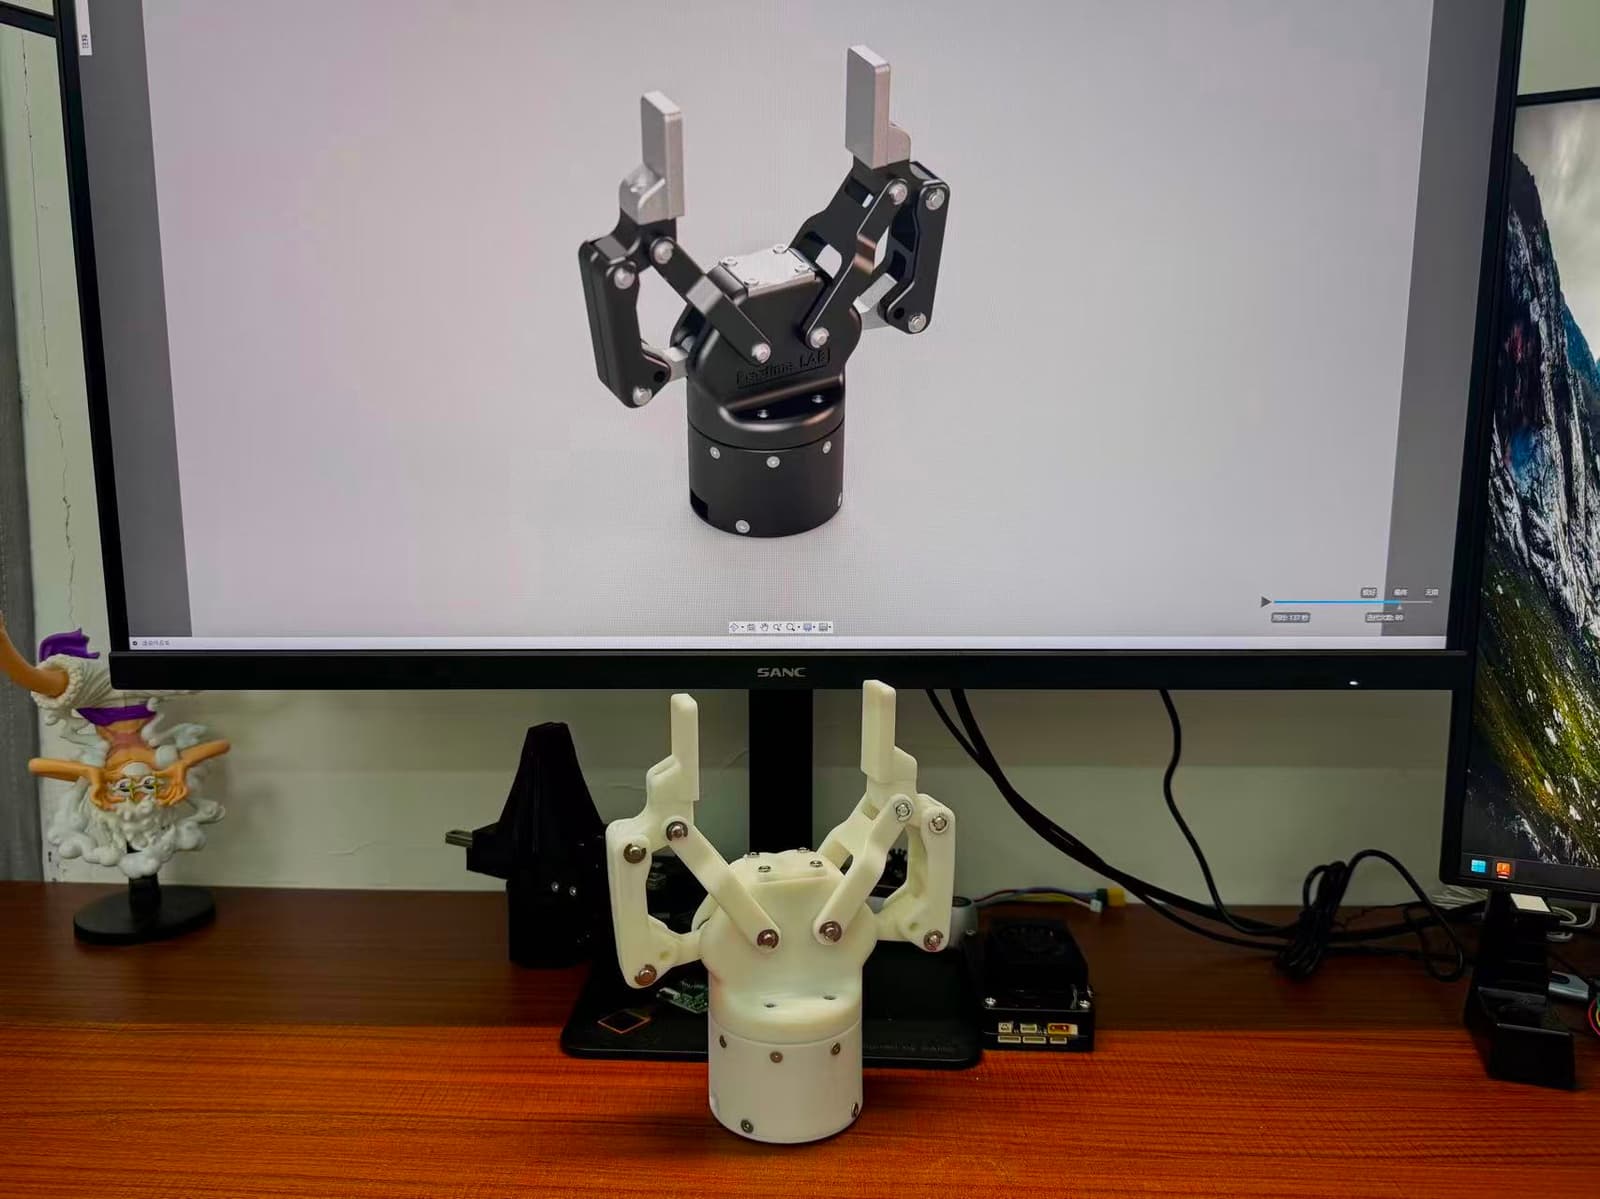
What it can do
Written by Robotheca from the project's documents.
- Adaptive two-finger gripping for objects of various shapes and sizes
- Manual open/close control via GUI
- PID closed-loop control with force feedback
- Real-time 6x6 pressure sensor visualization
- Motor enable/disable control
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Obtain design files
- 2Manufacture parts
- 3Assemble the gripper
The guide appears here as you scroll.
Guide by @Ragtime-LAB (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- DAMIAO DM4310 joint motor (or DM4340/DM6006)
- DAMIAO DM-FDCAN USB-CAN adapter
- 6x6 array pressure sensor (36 points, 2.5 mm x 2.5 mm per point)
- 24 V DC power supply for motors
- USB connection for CAN adapter
- UART serial connection for pressure sensor
Connections
- USB cable connects computer to DM-FDCAN adapter
- CAN bus cable connects DM-FDCAN adapter to DM4310 motor
- UART serial cable connects computer to 6x6 pressure sensor
- Motor powered by 24 V DC supply
- CAN bus terminated with 120 Ω resistor at both ends