Project files
- 0_Solidworks202548 files
- 1_STEP1 file
- 2_BOM20 files
- 3_RhinoV2.0_Gripper_control25 files
- img1 file
- LICENSE35 KB
- README.md13 KB
README.md
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
📖 Project Introduction
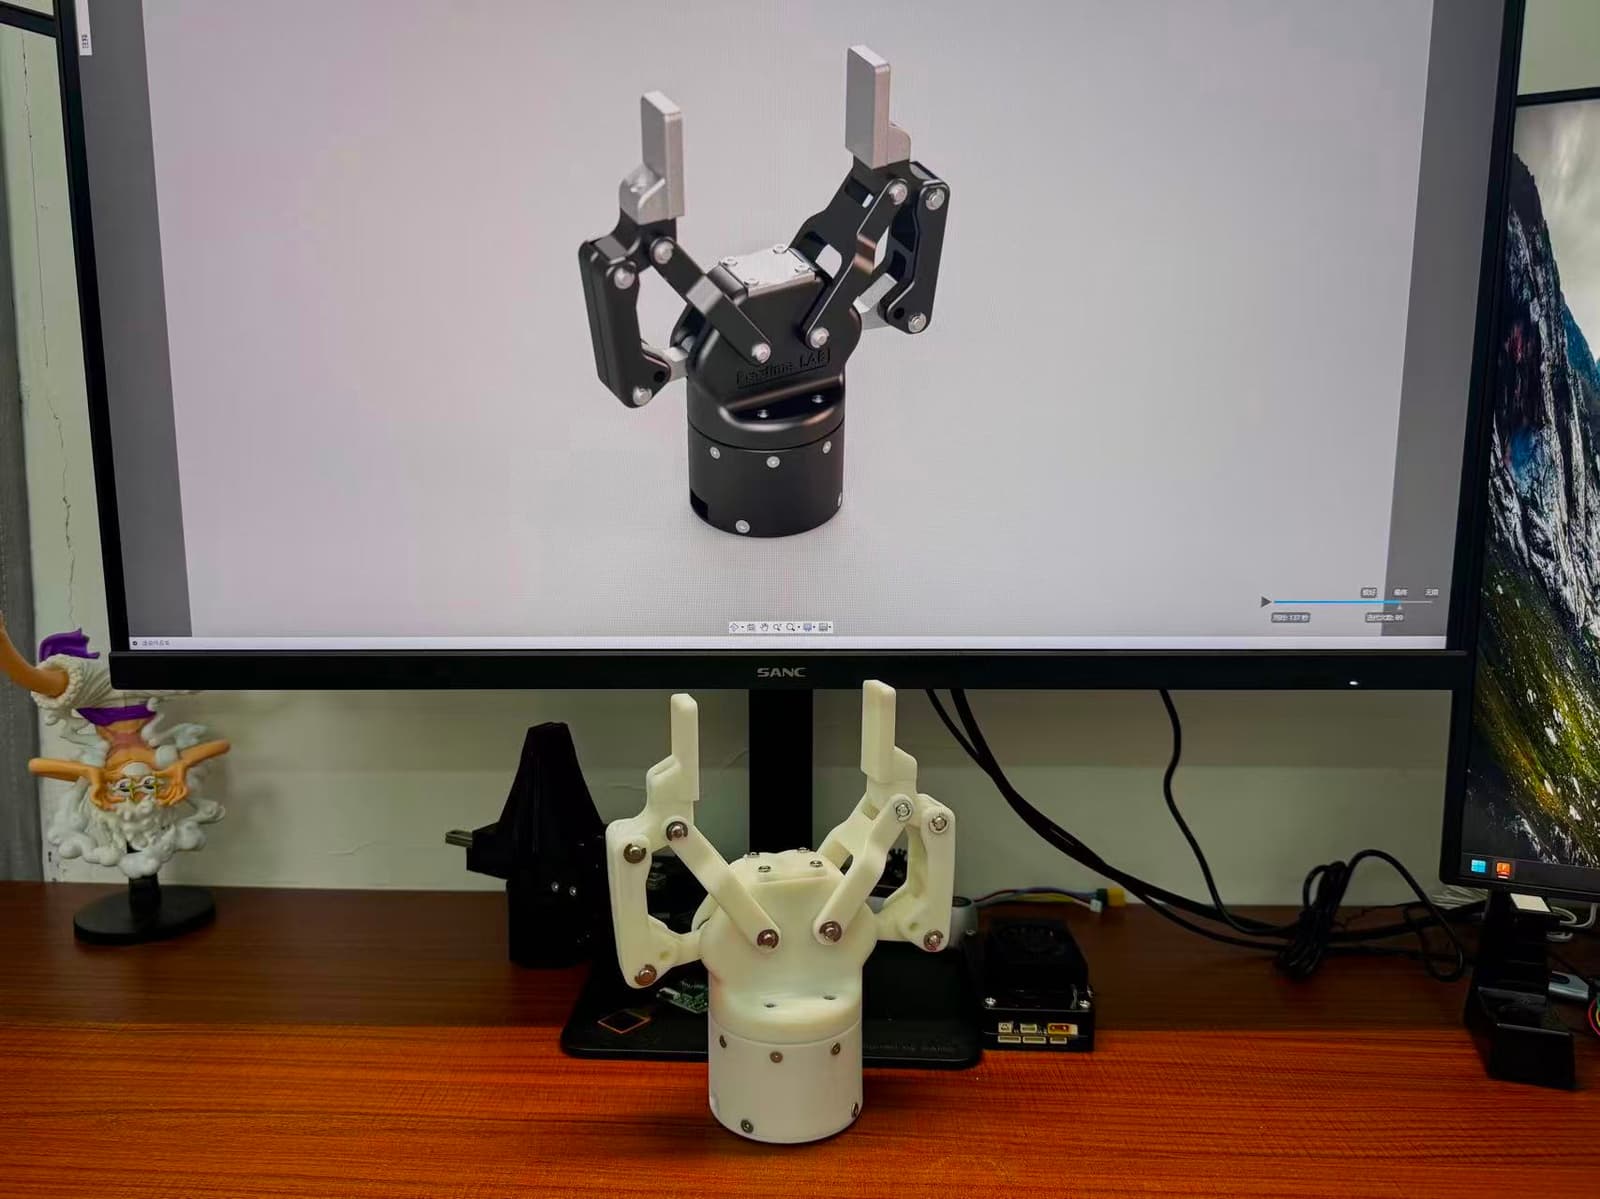
RhinoV2.0 is an open-source adaptive two-finger gripper inspired by the Robotiq 2F-85 commercial gripper. This project aims to provide a low-cost, high-performance, easy-to-manufacture, and easy-to-assemble mechanical gripper solution, enabling more robot enthusiasts, students, and individual developers to access affordable end-effectors.
💰 Cost Advantage: Made using 3D printing, the entire set costs no more than ¥1000, significantly lower than commercial grippers!
🎯 Project Purpose
- Lower the Barrier: Commercial grippers are expensive (e.g., Robotiq 2F-85 costs around ¥14,000+), and we aim to make them more accessible to everyone.
- Open Source Sharing: All design files are fully open source, supporting free modification and optimization.
- Educational Value: Provides design examples for students in mechanical engineering and robotics for learning and reference.
- Manufacturability: Uses standard parts and common processing techniques to reduce manufacturing costs.
- Scalability: Modular design facilitates secondary development and improvements.
✨ Main Features
- 💰 Ultra-low cost: The entire set costs < ¥1000 for the 3D-printed version
- Adaptive gripping, compatible with objects of various shapes and sizes
- Underactuated mechanism design, compact structure
- Powered by joint motors (Dynamixel DM4310)
- Supports FDM 3D printing or CNC machining
- Complete SolidWorks source files and STEP universal format
📁 File Structure
RhinoV2.0_Gripper/
├── 0_Solidworks2025/          # SolidWorks 2025 source files
│   ├── RhinoV2.0_Assembly.SLDASM   # Main assembly
│   ├── DM4310.SLDPRT               # Joint motor model
│   └── ...                         # All part models
│
├── 1_STEP/                         # STEP universal format files
│   └── RhinoV2.0_Assembly.STEP     # Complete assembly STEP file
│
├── 2_Bom/                          # Bill of Materials and manufacturing files
│   ├── BOM.xlsx                    # Master bill of materials
│   ├── FDM_or_CNC/                 # Parts for 3D printing or CNC machining
│   ├── JLCPCB_Sheet_Metal_304_or_Quanzhou/  # Sheet metal or CNC machining files
│   ├── Quanzhou_3Axis_CNC/         # CNC machining files
│   └── Lead_Screw_and_Nut/         # Lead screw assembly components
│
├── 3_RhinoV2.0_Gripper_control/   # Gripper control system code
│   ├── gripper_ui_integrated.py    # Integrated control UI (recommended)
│   ├── motor_control_pyqt.py       # Manual control program
│   ├── damiao.py                   # DAMIAO motor control library
│   ├── test_pressure.py            # Pressure sensor test
│   ├── requirements.txt            # Python dependencies
│   └── README.md                   # Detailed control system documentation
│
├── img/                            # Project images
│   └── RhinoV2.0_Real.jpg          # Real object photo
│
├── README.md                  # This file
└── LICENSE                    # GPL-3.0 open-source license
⚙️ Hardware Configuration
| Item | Parameter |
|---|---|
| Drive Motor | Dmio DM4310 Joint Motor |
| Grip Stroke | (To be added) |
| Maximum Grip Force | (To be added) |
| Weight | (To be added) |
| Manufacturing Method | FDM 3D Printing / CNC / Sheet Metal |
🚀 Quick Start
1. 📄 Obtain the design files
- SolidWorks users: Modify the source files directly in
0_Solidworks2025/ - Other CAD software: Import the
1_STEP/RhinoV2.0_Assembly.STEPfile
2. 🔧 Part Processing
Refer to the detailed list in the 2_Bom/ directory:
- List of 3D-printable parts
- CNC machining drawings
- Sheet metal processing files
- Standard parts procurement list (bearings, screws, etc.)
💡 Student Discount Benefit: If you find structural components or lead screws too expensive, feel free to contact us to organize group purchases—buying in bulk with others can reduce costs!
3. 🔨 Assembly
(Detailed assembly tutorial videos/documents coming soon)
🤝 Contribution Guidelines
We welcome contributions in any form:
- 🐛 Reporting bugs
- 💡 Suggesting new features
- 🎨 Submitting design improvements
- 📝 Improving documentation
- 📸 Sharing your build results
Interested in joining the team?
If you are passionate about this project and would like to join our team to develop better grippers, feel free to contact us via the above methods (email or WeChat)! We look forward to your participation!
⚖️ License
This project is licensed under the GPL-3.0 License, with the following key features:
- ✅ Commercial use allowed: You are free to use this project for commercial purposes
- ✅ Open source requirement: If you modify or derive new works based on this project, you must also open-source them under the GPL-3.0 license
- ✅ Patent protection: GPL-3.0 provides clear patent licensing protection, preventing patent lawsuits
- ✅ Freedom to use: You are free to use, modify, and distribute this project
💡 In short: You can use it commercially, modify it, but the modified code must also be open-source!
🙏 Acknowledgments
- Design inspiration from Robotiq 2F-85 (opens in a new tab)
- Thanks to all developers who contributed to this project
Special Thanks
- Xiao Yi – Thank you for your sponsorship support | GitHub: KelvinLauMiau (opens in a new tab) Contributions: Provided most of the structural ideas, appearance optimization, and covered all R&D expenses
- Lele Burger – Thank you for your encouragement and guidance | Bilibili: 乐乐汉堡 (opens in a new tab) Contributions: Served as a role model for the author’s learning and provided key guidance
📧 Contact Information
- 👤 Author: wEch1ng (Cheese Durian Beef)
- 🔗 Previous project: RhinoV1.0_Gripper (opens in a new tab)
- 📧 Email: 3575868884@qq.com (opens in a new tab)
- 💬 WeChat: xwccc12028
- 🤝 Feel free to reach out if you have any questions or collaboration ideas!
If this project has been helpful to you, please give it a Star ⭐
📖 Introduction
RhinoV2.0 is an open-source adaptive two-finger gripper inspired by the commercial Robotiq 2F-85 gripper. This project aims to provide a low-cost, high-performance, and easy-to-manufacture robotic gripper solution, making end-effectors accessible to more robotics enthusiasts, students, and individual developers.
💰 Cost Advantage: With 3D printing, the complete set costs less than $200, far below commercial gripper prices!
🎯 Project Motivation
- Accessibility: Commercial grippers are expensive (e.g., Robotiq 2F-85 costs around $2000+); we aim to make them affordable.
- Open Source: All design files are fully open-source, supporting free modification and optimization.
- Educational Value: Provides design references for mechanical engineering and robotics students.
- Manufacturability: Uses standard parts and common manufacturing processes to reduce cost.
- Extensibility: Modular design facilitates secondary development and improvements.
✨ Key Features
- 💰 Ultra-low Cost: Complete set for 3D-printed version under $200
- Adaptive gripping compatible with objects of various shapes and sizes
- Underactuated mechanism design with compact structure
- Driven by joint motor (DAMIAO DM4310)
- Supports FDM 3D printing or CNC machining
- Includes complete SolidWorks source files and STEP universal format
📁 File Structure
RhinoV2.0_Gripper/
├── 0_Solidworks2025/          # SolidWorks 2025 source files
│   ├── RhinoV2.0_Assembly.SLDASM   # Main assembly
│   ├── DM4310.SLDPRT              # Joint motor model
│   └── ...                        # All part models
│
├── 1_STEP/                    # STEP universal format files
│   └── RhinoV2.0_Assembly.STEP    # Complete assembly STEP file
│
├── 2_Bom/                     # Bill of materials and manufacturing files
│   ├── BOM.xlsx                    # Total BOM list
│   ├── FDM或CNC/                   # FDM 3D printing or CNC parts
│   ├── 嘉立创钣金304或铨洲/         # Sheet metal fabrication or CNC files
│   ├── 铨洲三轴CNC/                 # CNC machining files
│   └── 丝杆及螺母/                  # Lead screw assembly related
│
├── 3_RhinoV2.0_Gripper_control/   # Gripper control system code
│   ├── gripper_ui_integrated.py    # Integrated control UI (recommended)
│   ├── motor_control_pyqt.py       # Manual control program
│   ├── damiao.py                   # DAMIAO motor control library
│   ├── test_pressure.py            # Pressure sensor test
│   ├── requirements.txt            # Python dependencies
│   └── README.md                   # Control system documentation
│
├── img/                       # Project images
│   └── RhinoV2.0_Real.jpg          # Photo of real product
│
├── README.md                  # This file
└── LICENSE                    # GPL-3.0 open source license
⚙️ Hardware Specifications
| Item | Specification |
|---|---|
| Motor | DAMIAO DM4310 Joint Motor |
| Gripping Stroke | (TBD) |
| Max Gripping Force | (TBD) |
| Weight | (TBD) |
| Manufacturing | FDM 3D printing / CNC / Sheet metal |
🚀 Quick Start
1. 📄 Obtain Design Files
- For SolidWorks Users: Use source files in
0_Solidworks2025/directly for modification - For Other CAD Software: Import
1_STEP/RhinoV2.0_Assembly.STEPfile
2. 🔧 Parts Manufacturing
Refer to detailed lists in the 2_Bom/ directory:
- List of 3D-printable parts
- CNC machining drawings
- Sheet metal fabrication files
- List of standard parts to procure (bearings, screws, etc.)
💡 For Students: If you find structural parts or lead screws too expensive, feel free to contact us to arrange group purchases. Buying in bulk can significantly reduce costs!
3. 🔨 Assembly
(Detailed assembly tutorial video/documentation coming soon)
🤝 Contributing
We welcome contributions in any form:
- 🐛 Bug reports
- 💡 Feature requests
- 🎨 Design improvements
- 📝 Documentation enhancements
- 📸 Share your build
Interested in Joining the Team?
If you are passionate about this project and want to join our team to develop better grippers together, please feel free to contact us via email or WeChat listed above. We look forward to having you!
⚖️ License
This project is licensed under the GPL-3.0 License. Key features:
- ✅ Commercial Use Allowed: You are free to use this project for commercial purposes
- ✅ Copyleft Required: If you modify or create derivative works based on this project, you must release them under GPL-3.0 as well
- ✅ Patent Protection: GPL-3.0 provides explicit patent license protection to prevent patent litigation
- ✅ Freedom to Use: You are free to use, modify, and distribute this project
💡 In Short: Commercial use is allowed, modifications are allowed, but modified code must also be open source!
🙏 Acknowledgments
- Design inspired by Robotiq 2F-85 (opens in a new tab)
- Thanks to all developers who contributed to this project
Special Thanks
- 小一 (Xiao Yi) - Thank you for your sponsorship | GitHub: KelvinLauMiau (opens in a new tab)
- Contribution: Proposed most of the structural design concepts, appearance optimization, and covered all R&D expenses
- 乐乐汉堡 (Lele Hamburger) - Thank you for your motivation and guidance | Bilibili: 乐乐汉堡 (opens in a new tab)
- Contribution: Served as the author's role model and provided key guidance
📧 Contact
- 👤 Author: wEch1ng (Cheese Durian Beef)
- 🔗 Previous Project: RhinoV1.0_Gripper (opens in a new tab)
- 📧 Email: 3575868884@qq.com (opens in a new tab)
- 💬 WeChat: xwccc12028
- 🤝 Feel free to contact for any questions or collaboration!
If this project helps you, please give it a Star ⭐
Files by @Ragtime-LAB, at commit 099a3cd, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.