Dagor Biped
A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.
- Other
- Open source
- 3D printable
Suggested by Robotheca, created by @elggem (opens in a new tab), from github.com/elggem/dagor_biped_hardware (opens in a new tab). Pinned to commit 8f33ea8 (opens in a new tab).
- Hardware license
- BSD-3-Clause (opens in a new tab)
- Software license
- BSD-3-Clause (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
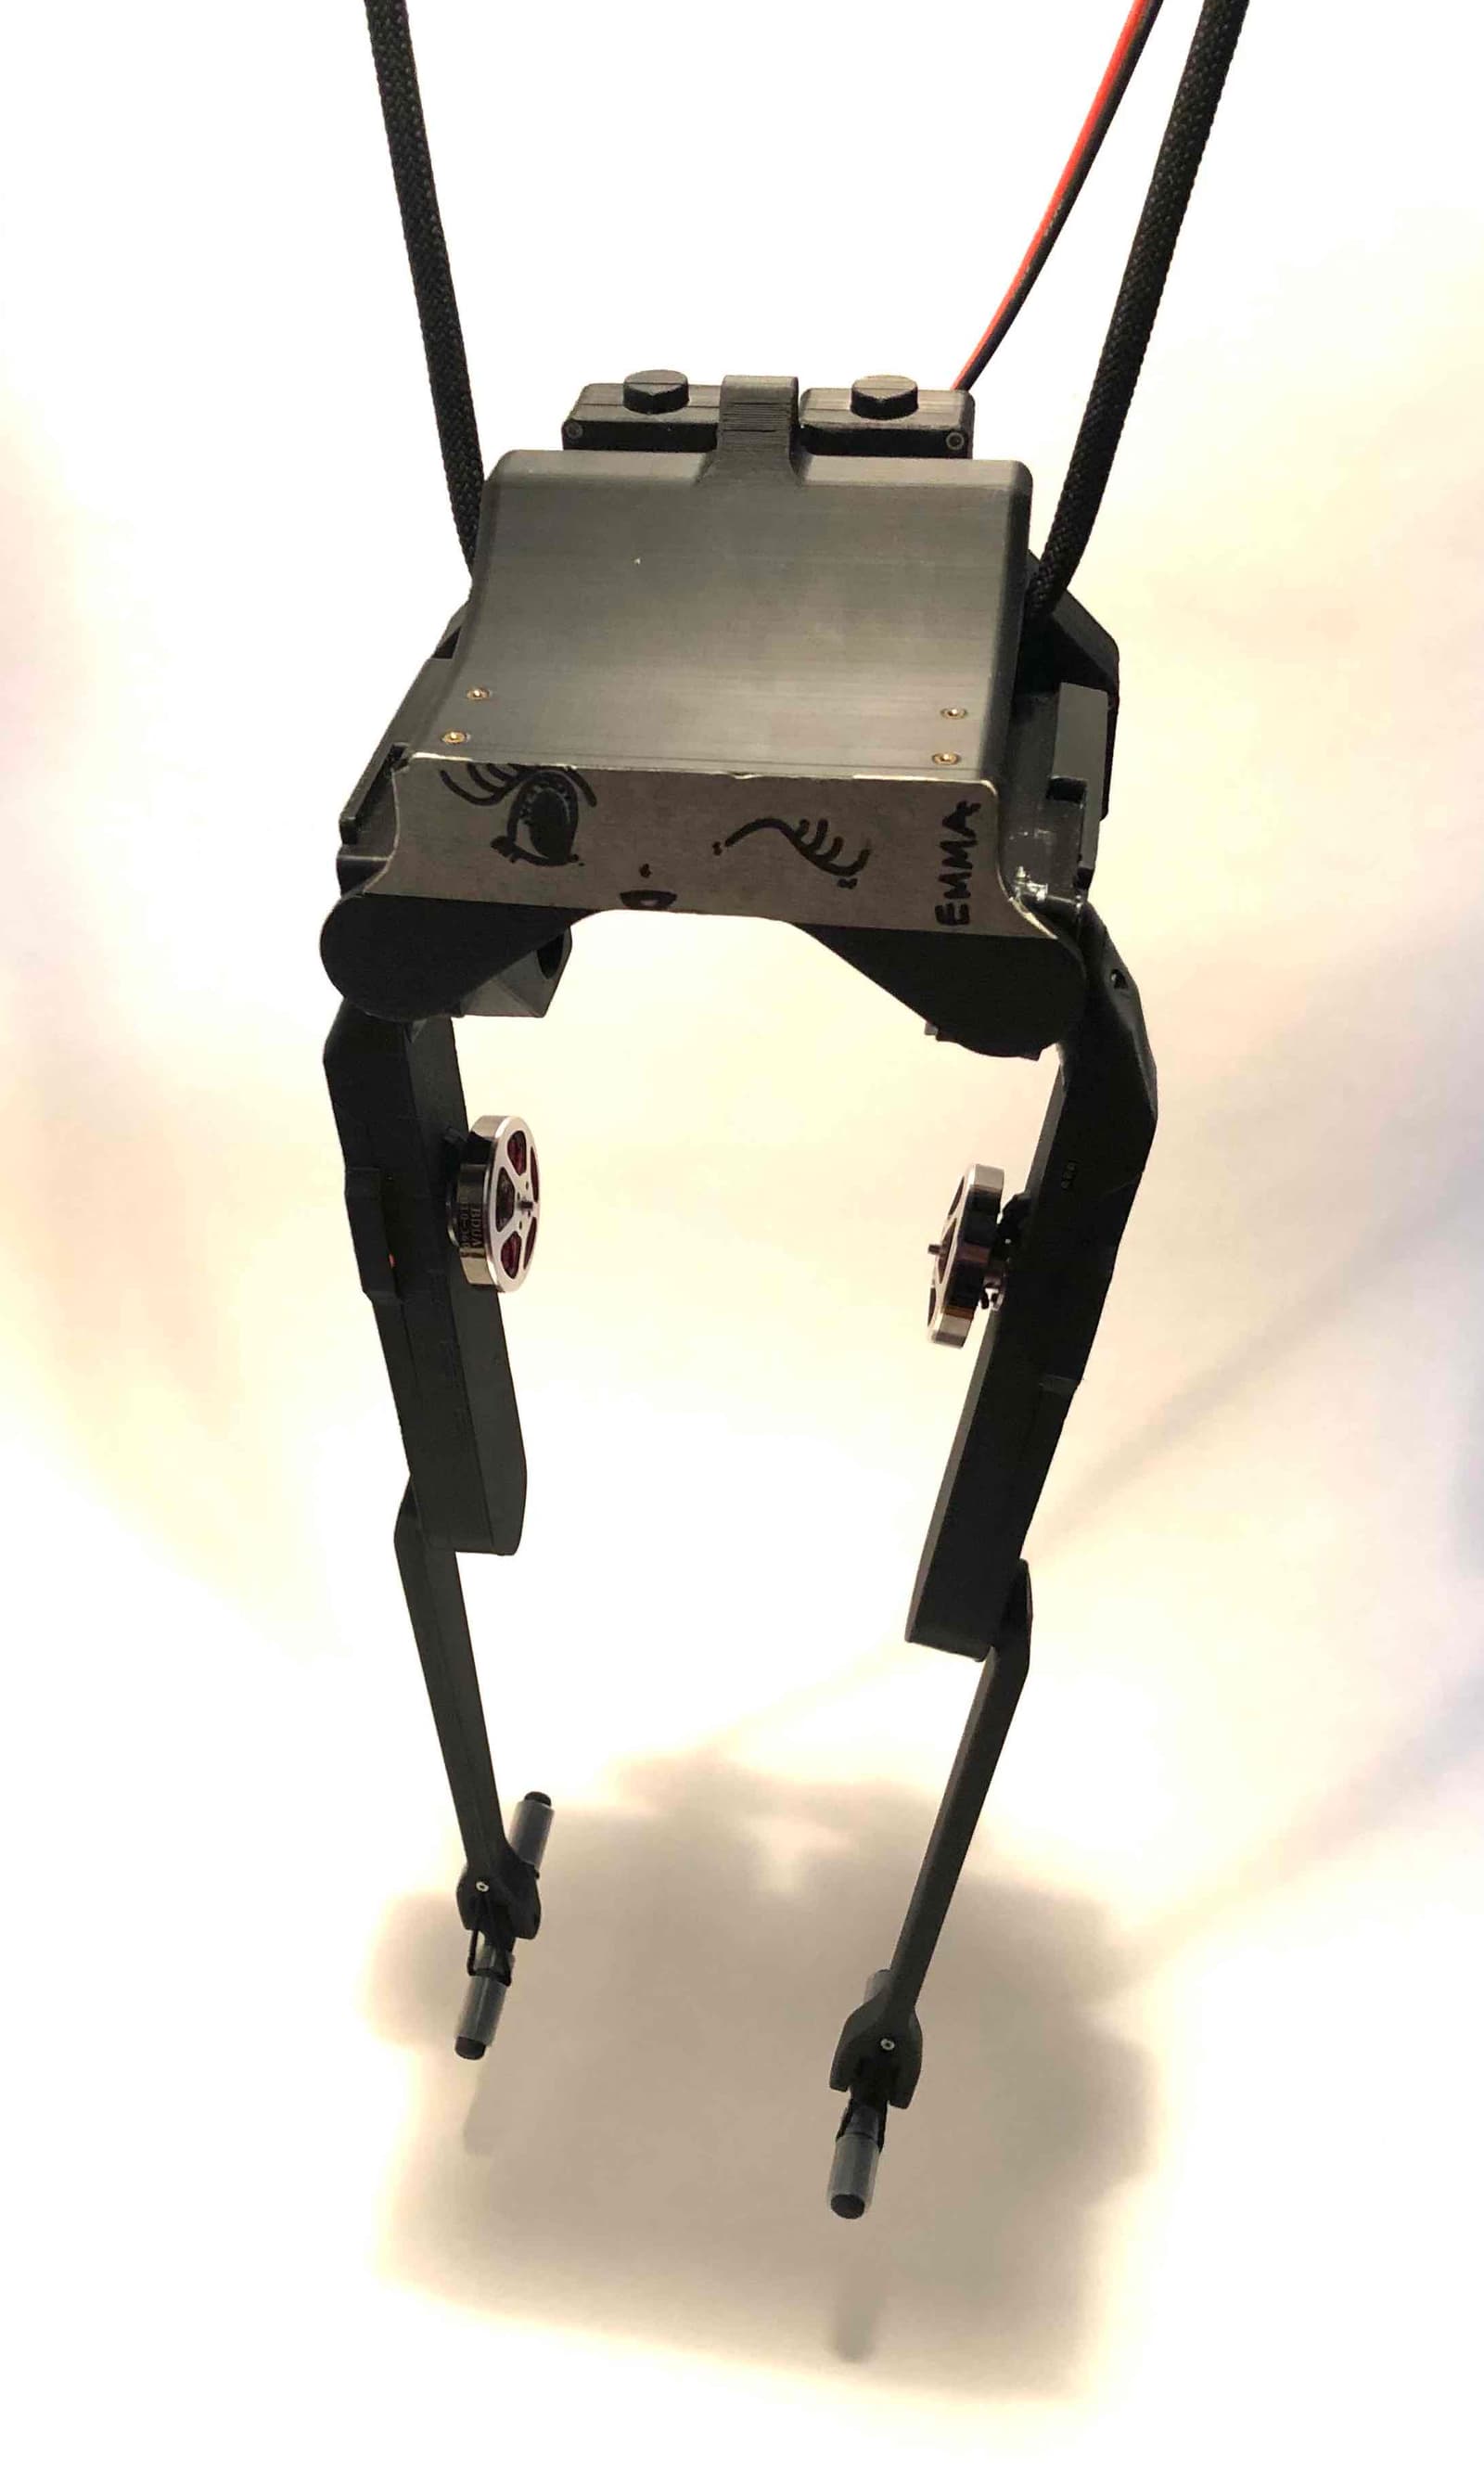
3D preview converted from github.com/elggem/dagor_biped_hardware at 8f33ea8, under BSD-3-Clause. View the original files from GitHub (12.2 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Biped robot built from six actuator modules, each with a brushless motor driving a belt-reduced output shaft.
- Hip modules, upper leg, lower leg and foot structures plus a body structure make up the walking robot.
- Each actuator is controlled by a Dagor Brushless motor control board, with the design remixed for easy FDM printing.
- The gear ratio is 1:8, trading some torque for faster speed compared to the original ODRI design.
Bill of materials
26 parts26 of 26 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | hip_normal_body | 2 | – | – |
| 2 | hip_normal_cover | 2 | – | – |
| 3 | hip_mirrored_body | 2 | – | – |
| 4 | hip_mirrored_cover | 2 | – | – |
| 5 | upper_leg_structure_base | 2 | – | – |
| 6 | upper_leg_structure_cover | 2 | – | – |
| 7 | upper_leg_structure_output_shaft | 2 | – | – |
| 8 | lower_leg_structure | 2 | – | – |
| 9 | foot_structure | 2 | – | – |
| 10 | body_structure | 1 | – | – |
| 11 | motor_pulley | 6 | – | – |
| 12 | transmission_pulley | 6 | – | – |
| 13 | output_pulley | 6 | – | – |
| 14 | Belt 3M HTD 150mm/50t/4mm | 3 | – | – |
| 15 | Belt 3M HTD 201mm/67t/6mm | 3 | – | – |
| 16 | Bearing 6705 25x32x4 | 12 | – | – |
| 17 | Bearing MR105 5x10x4 | 18 | – | – |
| 18 | M2.5 threaded inserts | 48 | – | – |
| 19 | M2.5 x 10mm screw | 48 | – | – |
| 20 | M2.5 x 20mm screw | 16 | – | – |
| 21 | M2.5 distance bolt 10mm | 6 | – | – |
| 22 | Motor encoder magnet | 6 | – | – |
| 23 | Dagor board | 6 | – | – |
| 24 | u.fl IPEX antenna | 6 | – | – |
| 25 | Sunnysky 5010 360kV motor | 6 | – | – |
| 26 | XT60 male connector | 6 | – | – |
26 of 26 parts have no price in the source, so there is no parts total. Read from README.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Print the motor pulley using SLA resin
- 2Attach threaded inserts and bearings to the output pulley
- 3Print and reinforce the center transmission pulley with custom slicer settings
- 4Prepare the motor shaft by replacing the output shaft standoff with Loctite
- 5Prepare Dagor boards with programming and power cables
- 6Assemble the hip actuator module
- 7Attach the cover, secure bolts, and test the actuator
The guide appears here as you scroll.
Guide by @elggem (README.md), under BSD-3-Clause.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Dagor Brushless motor controller board, one per actuator module, with mounting holes for the board.
- Sunnysky 5010 360kV brushless motors, with a magnetic encoder magnet fitted to each motor.
- XT60 male connector for hip module power and a bare power wire for leg modules.
- U.fl IPEX antenna, listed in the bill of materials for the Dagor boards.
- 3-pin programming header connection on the Dagor board RXD/TXD/GND pins.
Connections
- Programming wires are soldered to the RXD, TXD and GND pads of the Dagor board, exiting toward the magnetic encoder side.
- Power wires are soldered on the magnetic encoder side of the module; hip modules use an XT60 connector, leg modules a ~15cm bare wire.
- Motor wires are soldered directly onto the Dagor board pads after assembly, with bullet connectors as an optional alternative.
- Belts connect the motor pulley to the transmission pulley and the transmission pulley to the output pulley.
Cables and connectors
From the parts list.
- XT60 male connector × 6