Skip to content

Photo and 3D model

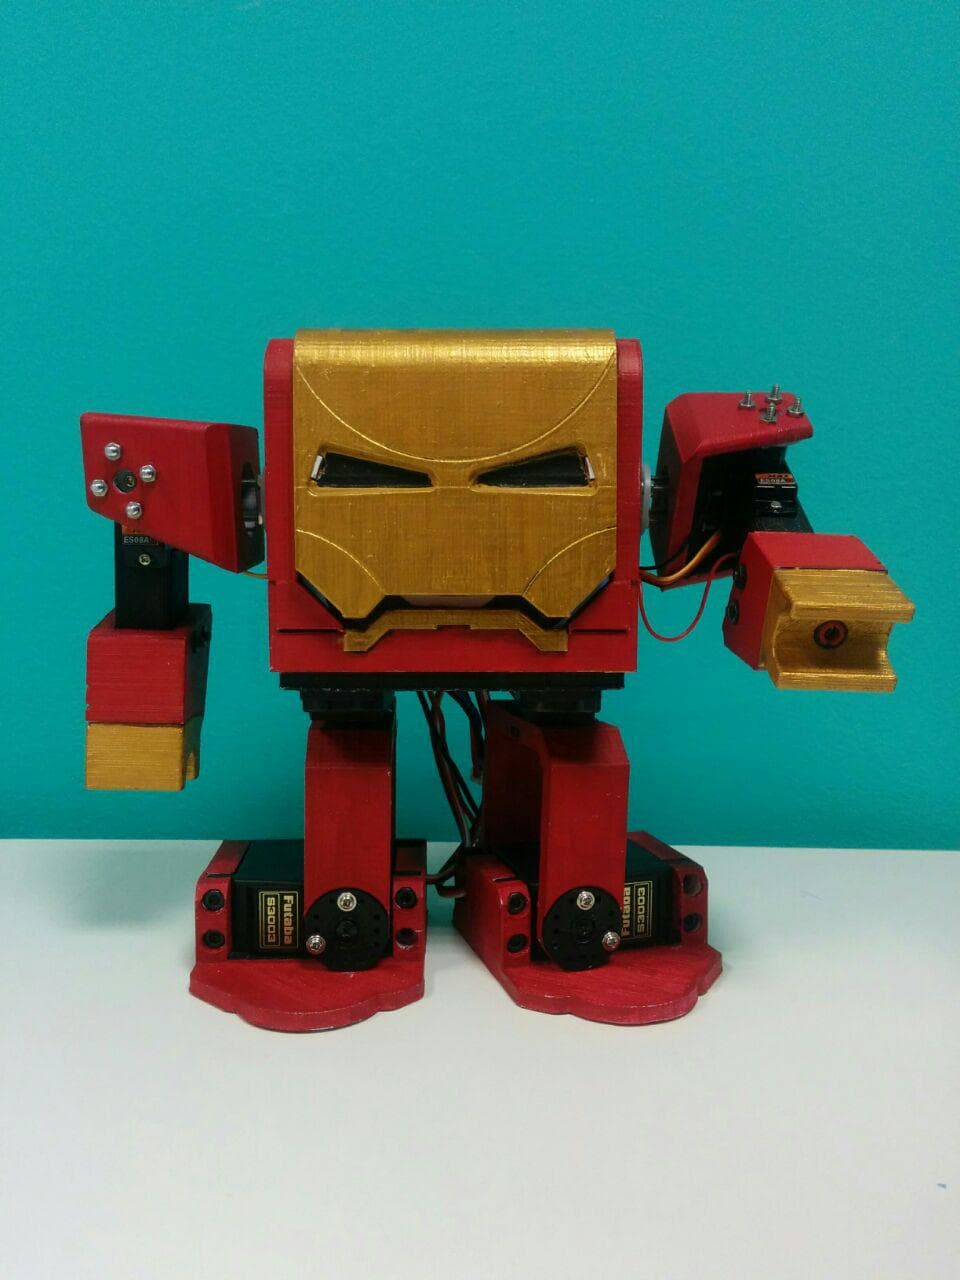
Zowi, photo from its repository
Photo@JavierIH (opens in a new tab)CC-BY-SA-4.0source file (opens in a new tab)

3D preview converted from github.com/JavierIH/zowi at 2dad901, under CC-BY-SA-4.0. View the original files from GitHub (64.1 MB) (opens in a new tab)

Open source · free files

Zowi

Other

An open-source, fully hackable biped robot with 3D-printed parts designed in FreeCAD.

Project information

Buildability
69/100Buildable with some effort
Estimated cost
Not stated
Level
Beginner
Parts
Not listed
Tools
3D printer
Commercial use
Allowed
Works with
Arduino

Suggested by Robotheca, created by @JavierIH (opens in a new tab), from github.com/JavierIH/zowi (opens in a new tab), pinned to commit 2dad901 (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

This repository has no parts list Robotheca can read yet.

Why it scores 69

It measures the published files, not the robot · How we score

69/100

Buildable with some effort

How complete the published files are for rebuilding this robot, measured by Robotheca at commit 2dad901. It isn't a rating of the robot. Counted out of 80 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD files102 printable parts (STL, 3MF), 41 CAD source files.20/20
  2. –Robot descriptionNo URDF. Not counted: the score is made of the parts that apply.Optional: add a URDF, and the robot can be seen in 3D and tried in the browser.Not counted
  3. 2Parts listNo parts list in the repository or linked.Most points to gain: Link to your parts list, or add it to the repository (a CSV or a Markdown table) with quantities, prices and where to buy each part.0/20
  4. 3SoftwareCode in this repository, instructions to install or run it, built on arduino.15/15
  5. 4DocumentationREADME of 1,855 characters with 4 pictures; 0 build steps.Split the build into at least 3 steps.10/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 5LicensesHardware: CC-BY-SA-4.0; software: GPL-3.0-only.10/10

Build it

The guide appears here as you scroll.

Guide by @JavierIH (README.md), under CC-BY-SA-4.0 (hardware) and GPL-3.0-only (software).

More guides

Wiring and electronics

Notes written by Robotheca from the project's documents, not by its creator

Main parts: Robotheca's summary

  • BQ ZUM BT-328 board (ATmega328P, 16 MHz) or an Arduino.
  • 4 Futaba 3003 servos or compatibles for the legs.
  • Ultrasonic distance sensor.
  • Battery pack of 8 AAA batteries in 4 x 2 holders.

Connections: Robotheca's summary

  • Servos connect to pins: YL on pin 2, YR on pin 3, RL on pin 4, RR on pin 5.

What it can do: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator
  • Walks, turns, moonwalks, swings, crawls, flaps, jumps and dances using movement gaits from the Zowi library.
  • Movement trims can be calibrated and stored in EEPROM.
  • Can avoid obstacles using an ultrasonic sensor, per the proto example sketch.

Software

Framework
Arduino
Languages
Arduino, C++, JavaScript, Python, C
License
GPL-3.0-only

Robotheca doesn't review code. Read it before running it.

How to run it: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator.

  1. 1Clone the repository with git clone --recursive, or run git submodule update --init to fetch ArduSnake.
  2. 2With PlatformIO, run pio run in the firmware folder to build, or pio run -e calibration -t upload to upload one sketch.
  3. 3With the Arduino IDE, copy lib/Zowi and external/ArduSnake/ArduSnake into the sketchbook libraries folder, install the Servo library, and open an example sketch.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

The code

Free files

Every file of the project, at commit 2dad901.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/zowi/badge.svg)](https://robotheca.org/robots/zowi)
[![Robotheca buildability](https://robotheca.org/robots/zowi/score.svg)](https://robotheca.org/robots/zowi)

Other other robots

All 100 other robots
  • Ready to build

    Open source · free files

    Koriobots

    Other · Intermediate

    Score
    Buildability 98 out of 100
    Cost
    $972.06≈ €866
  • Ready to build

    Open source · free files

    AmazingHand

    Other · Intermediate

    Score
    Buildability 88 out of 100
    Cost
    under €200
  • Ready to build

    Open source · free files

    DigiArm Prosthetic Hand

    Other · Advanced

    Score
    Buildability 85 out of 100
    Cost
    $250≈ €223
  • 3D render

    Open source · free files

    FloatingFace

    Other · Advanced

    Score
    Buildability 100 out of 100
    Cost
    $328.47≈ €293

≈ € values are approximate, converted at the ECB euro reference rate of 5 Nov 2026. The creator's original price always comes first.