Shoggoth Mini
A soft-bodied tentacle robot based on the SpiRobs design, controlled through reinforcement learning and GPT-4o.
- Other
- Open source
- Works with AI
- LeRobot
- 3D printable
Suggested by Robotheca, created by @mlecauchois (opens in a new tab), from github.com/mlecauchois/shoggoth-mini (opens in a new tab). Pinned to commit c361fda (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
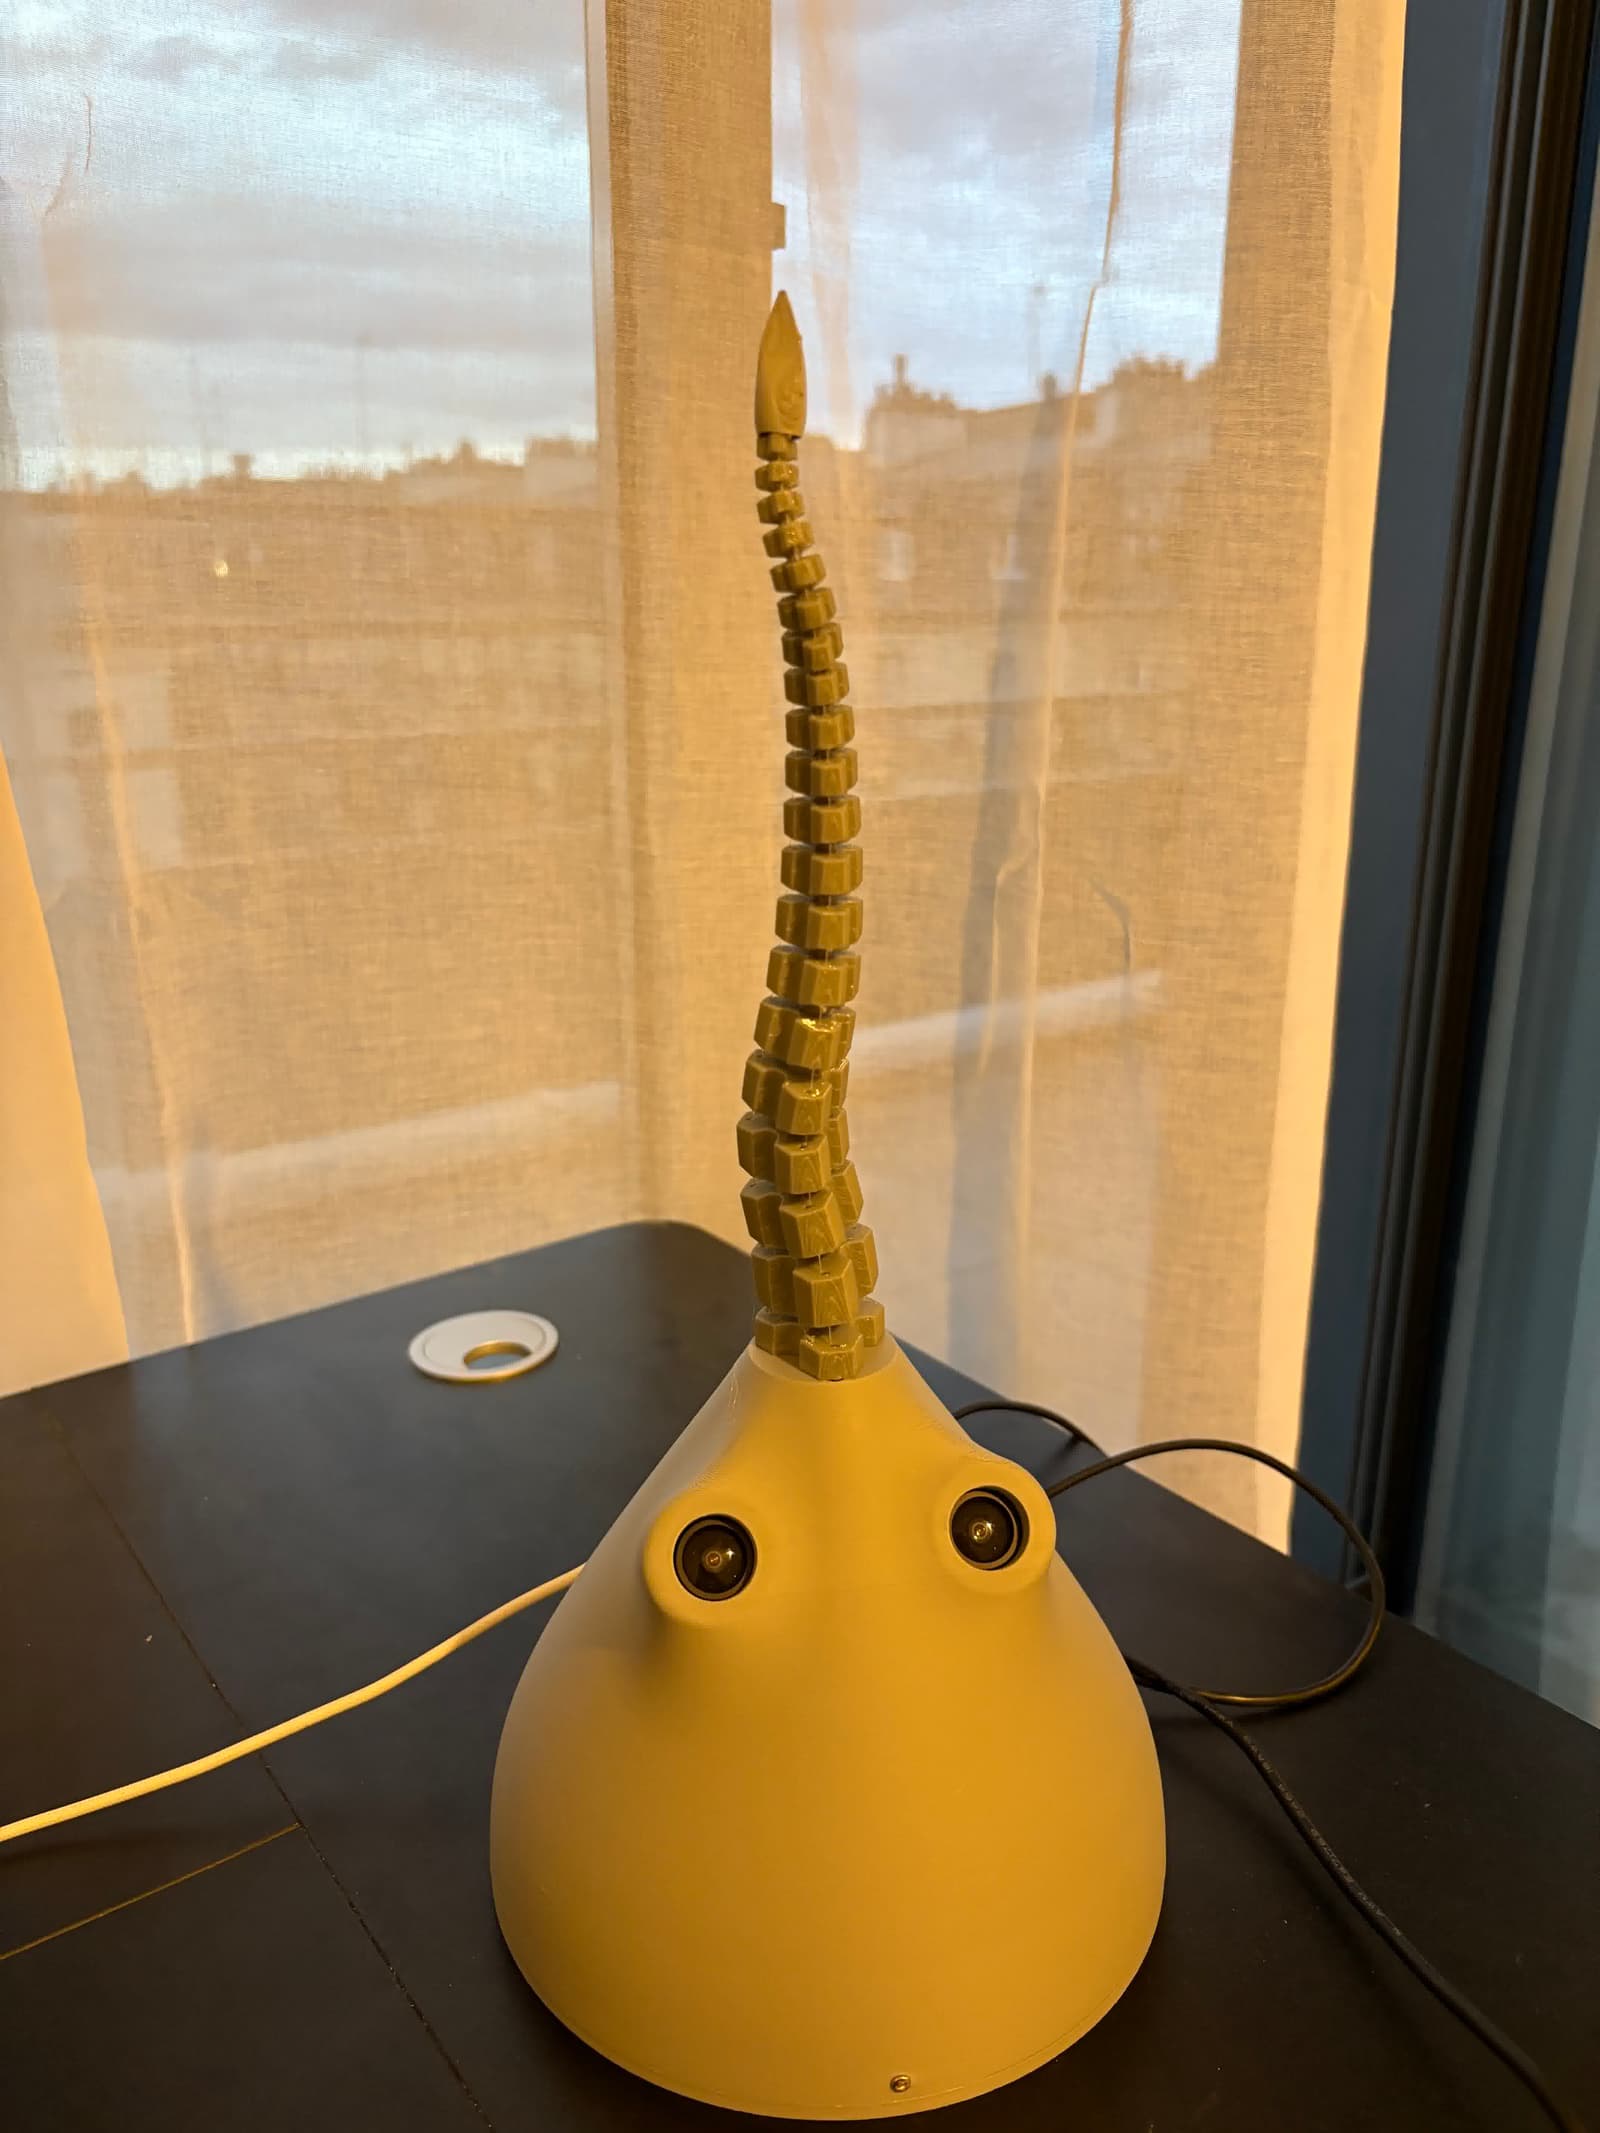
3D preview converted from github.com/mlecauchois/shoggoth-mini at c361fda, under MIT. View the original files from GitHub (822 KB) (opens in a new tab)
1 of the 6 STEP files is not in the 3D view: 1 too large.
What it can do
Written by Robotheca from the project's documents.
- Soft-bodied tentacle robot using the SpiRobs design, bending and articulating with three cable-driven motors
- Controlled through a mix of reinforcement learning and GPT-4o
- Idle breathing motion and manual trackpad control are supported
- Vision-based tracking via a stereo camera feeding a closed-loop RL policy
- Runs a full orchestrator integrating hardware, perception and control components
Works with AI
Found by Robotheca in the project's files at commit c361fda, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Runs LeRobot
Stated in robot.yamlShips a trained model: tentacle_tracking_baseline.onnx
In the project files: assets/models/vision/tentacle_tracking_baseline.onnx“Controlled through a mix of reinforcement learning and GPT-4o”
Robotheca's notes: What it can do“Install the lerobot library from source”
Robotheca's notes: How to run it“Find the driver board USB port with the lerobot script”
Robotheca's notes: How to run it
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @mlecauchois (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Waveshare serial bus servo driver board
- Three Waveshare 20kg.cm bus servo motors (Feetech STS3215, IDs 1, 2, 3)
- Synchronous 3D stereo USB camera, 3840x1080, 60fps
- 12V 5A power supply
- Fishing wire tendons routed to rollers on the motors
Connections
- Driver board connects to the computer over USB-C
- Camera connects to the computer over a USB Micro to USB-C cable
- Driver board is powered by the 12V supply through a separate power cable
- Motors are daisy-chained: motor 2 to motor 3, motor 3 to motor 1, motor 1 to the driver board