No photo yet
HomeAlohaScorpion
A 7-DOF dual-arm mobile manipulator with lift, designed for research in manipulation and mobile robotics.
- Works with AI
- Level
- Advanced
- Buildability
- 60/100
- Buildable with some effort
- Cost
- Not stated
Gymnasium is a Python library offering a standard API for reinforcement learning environments, plus a set of environments that follow that API. It is a maintained fork of OpenAI's Gym.
Made by Farama Foundation.
Source on GitHub: github.com/Farama-Foundation/Gymnasium (opens in a new tab). Facts read at commit 57c1610 (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (MIT) at commit 57c1610 (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 57c1610.
Checked on GitHub on 16 Oct 2026.
A 7-DOF dual-arm mobile manipulator with lift, designed for research in manipulation and mobile robotics.
Found by Robotheca in pyproject.toml (opens in a new tab)
A 7-DOF dual-arm bimanual robot platform derived from the SO-101 design, with matching leader arms for teleoperation.
Found by Robotheca in pyproject.toml (opens in a new tab)
An open-source autonomous drone platform using ROS2 and AI-powered flight control, designed to be understood, built, and extended.
Found by Robotheca in requirements.txt (opens in a new tab)
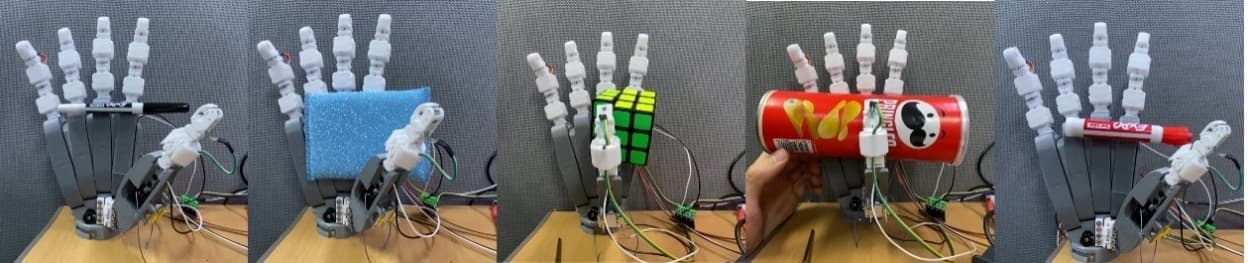 Other
An underactuated anthropomorphic robotic hand with integrated wrist, 7 DOF per finger, cable-driven, 3D printed, and impedance controlled.
Found by Robotheca in requirements.txt (opens in a new tab)
A quadruped ant-style robot with eight Dynamixel actuators that runs learned locomotion policies directly on hardware, controlled by a single computer over USB.
Found by Robotheca in requirements.txt (opens in a new tab)
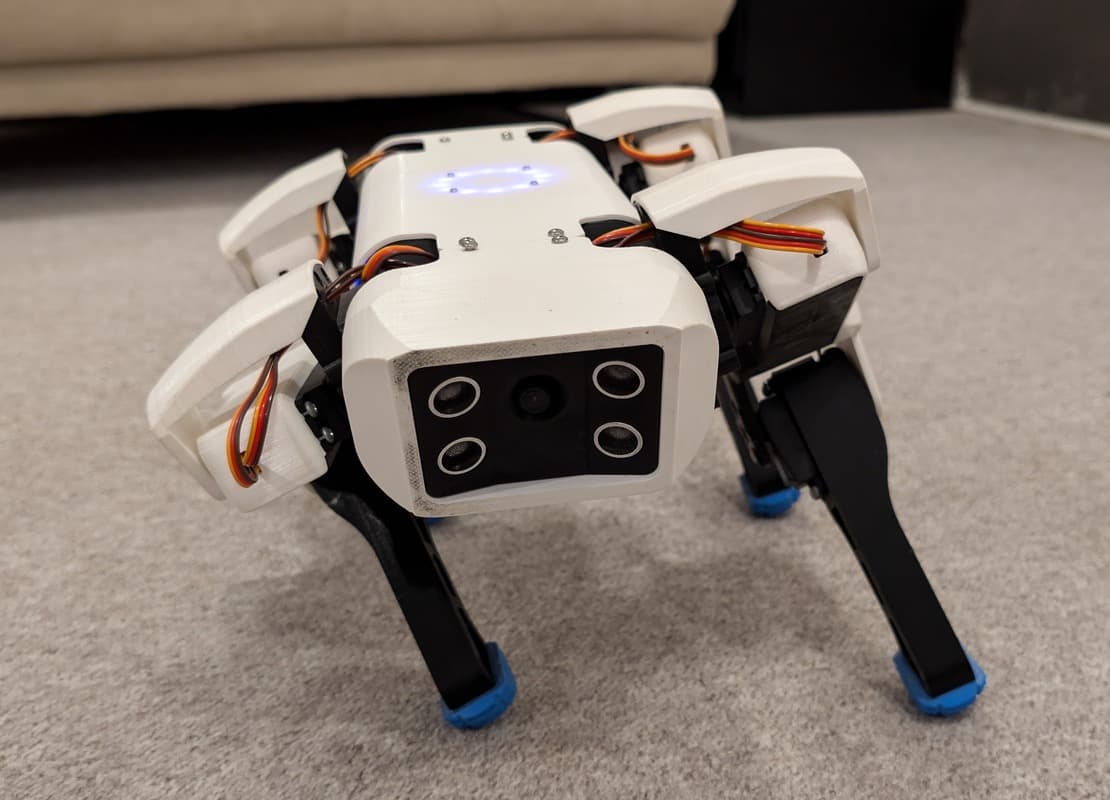 Quadruped
An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
Found by Robotheca in simulation/pyproject.toml (opens in a new tab)
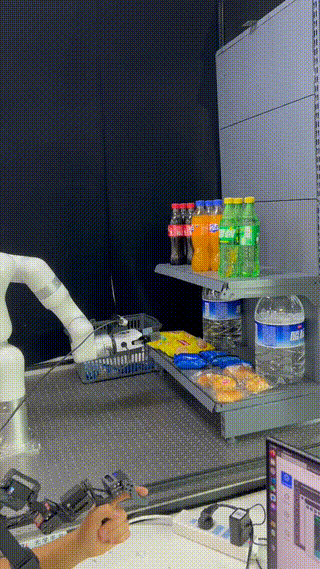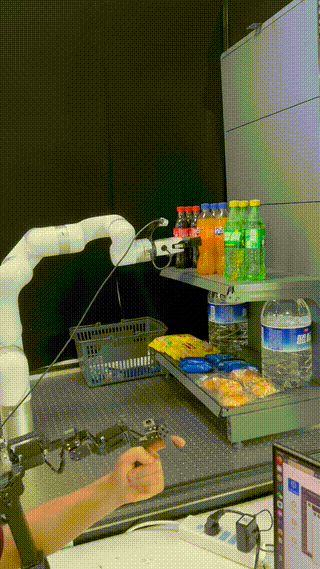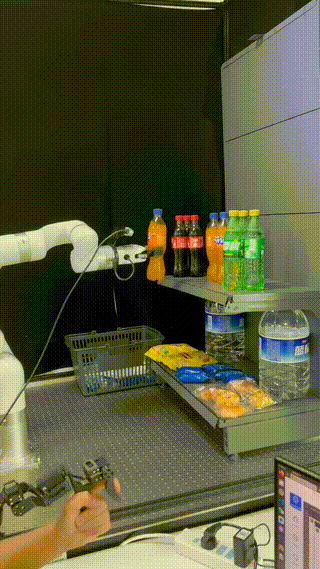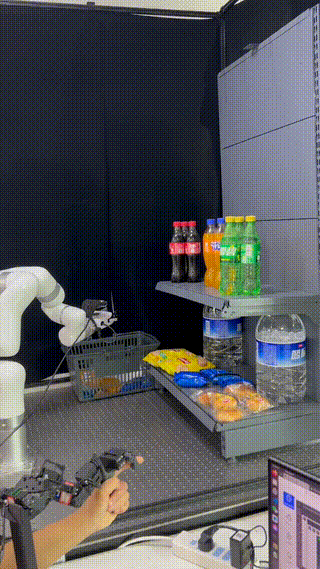 Robot arm
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
Found by Robotheca in requirements.txt (opens in a new tab)
Open-source wheeled biped robot with wheels for balance and legs for uneven terrain, controllable in simulation and on hardware.
Found by Robotheca in pyproject.toml (opens in a new tab)
A 3D printed quadrupedal robot with 4 limbs of 3 degrees of freedom each, built for locomotion research and reinforcement-learned walking.
Found by Robotheca in learning/requirements-rl.txt (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.