U-Arm
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
- Robot arm
- Open source
- Works with AI
- ROS
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @MINT-SJTU (opens in a new tab), from github.com/MINT-SJTU/LeRobot-Anything-U-Arm (opens in a new tab). Pinned to commit bd31c69 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 file marked executable, 14 scripts)
- src/simulation/mani_skill/examples/benchmarking/scripts/isaac_lab.sh (opens in a new tab)
- src/simulation/mani_skill/examples/benchmarking/scripts/maniskill.sh (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/openarm_description/dev/release.sh (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/openarm_mujoco/dev/release.sh (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/openarm_ros2/.docker/ros_entrypoint.sh (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/openarm_ros2/dev/release.sh (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/servo_teleop/run_ros2_teleop_v1.ps1 (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/servo_teleop/run_teleop_v1.ps1 (opens in a new tab)
- src/simulation/mani_skill/examples/bimanual.openarm/servo_teleop/run_teleop.ps1 (opens in a new tab)
- src/simulation/mani_skill/examples/motionplanning/xarm6/generate.sh (opens in a new tab)
- src/uarm/scripts/add_permission.sh (opens in a new tab)
- src/uarm/scripts/Follower_Arm/Dobot/run_Dobot.sh (opens in a new tab)
- src/uarm/scripts/Follower_Arm/xarm/xArm-Python-SDK/LICENSE (opens in a new tab)
- src/uarm/scripts/run_all_nodes.sh (opens in a new tab)
- src/uarm/scripts/test_teleop.sh (opens in a new tab)
Photo and 3D model
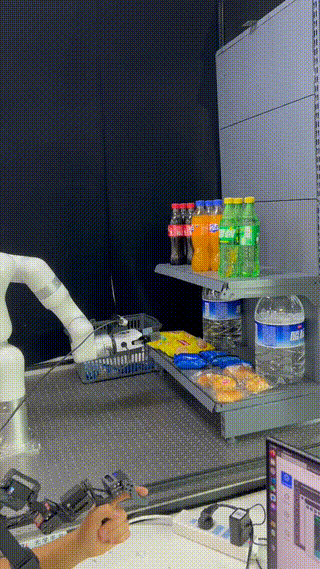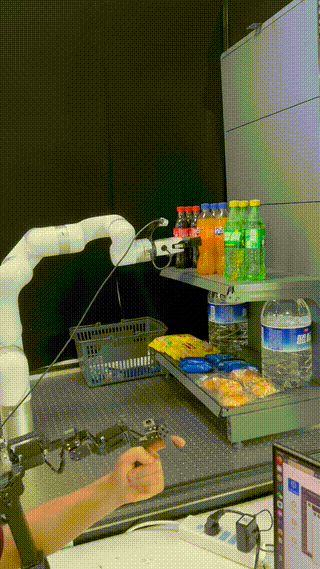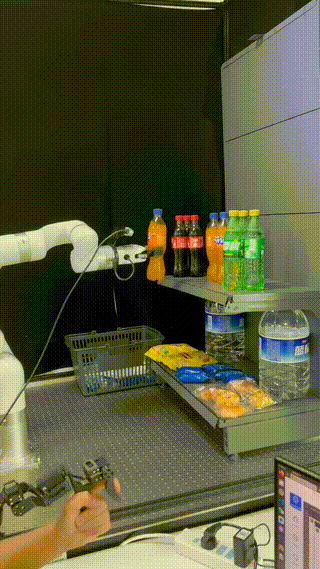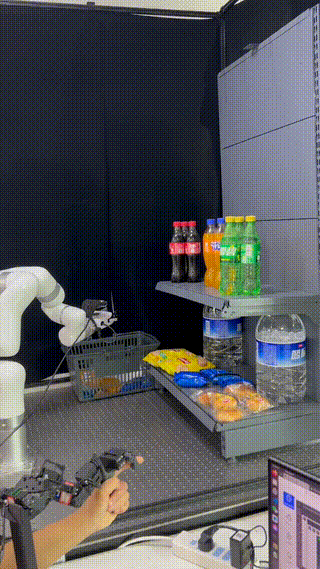
3D preview converted from github.com/MINT-SJTU/LeRobot-Anything-U-Arm at bd31c69, under Apache-2.0. View the original files from GitHub (8.8 MB) (opens in a new tab)
2 mesh files named in the URDF are not in the repository, so those parts are not shown.
What it can do
Written by Robotheca from the project's documents.
- Teleoperates six-axis robot arms in real time
- Supports leader-follower control via ROS Noetic
- Runs in SAPIEN-based simulation for testing
- Publishes joint angles on the /servo_angles topic
- Works with multiple commercial arms (XArm, Dobot, ARX, Franka, UR, etc.)
Works with AI
Found by Robotheca in the project's files at commit bd31c69, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Has LeRobot code
In the project files: src/uarm/scripts/Follower_Arm/LeRobot
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Purchase required parts
- 23D print mechanical components
- 3Assemble hardware
- 4Set up software environment
- 5Configure ROS and teleoperation
- 6Test in simulation and real-world
The guide appears here as you scroll.
Guide by @MINT-SJTU (README.md), under Apache-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Feetech STS3215 servos (six-axis follower arm)
- UArm Swift Pro (leader arm)
- USB-to-serial adapter for servo communication
- ROS Noetic controller
- Ubuntu 20.04 host computer
Connections
- Leader arm connected to host via USB
- ROS nodes communicate over localhost network