No photo yet
Software
vision_opencv
By ROS Perception, from github.com/ros-perception/vision_opencv (opens in a new tab)
- Perception
- Library
- Apache-2.0 AND BSD-3-Clause
A set of ROS 2 packages that connect ROS 2 image messages with the OpenCV computer vision library. It bridges image formats and provides image geometry helpers.
Facts
- GitHub stars
- 673read on 6 Nov 2026
- Last update
- 29 Dec 2025Newest commit on rolling
- Maintenance
- Maintaineda commit in the last 12 months
- Difficulty
- Intermediate
Checked on GitHub on 6 Nov 2026.
Licenses
- Code
- Apache-2.0 (opens in a new tab) AND BSD-3-Clause (opens in a new tab)
Read by Robotheca from LICENSE-Apache (opens in a new tab) (Apache-2.0) and LICENSE-BSD (opens in a new tab) (BSD-3-Clause) at commit 50f6f1f (opens in a new tab), on 16 Oct 2026. The files name several licenses: a person at Robotheca set it on 9 Nov 2026.
- Commercial use
- Yes
Overview
What it does: Robotheca's summary
- Provides cv_bridge, which converts between ROS 2 image messages and OpenCV image representations.
- Provides image_geometry, a collection of methods for working with image and pixel geometry.
- Includes opencv_tests, integration tests that exercise the packages together with OpenCV.
- Provides vision_opencv, a meta-package that installs both cv_bridge and image_geometry.
- Built for computationally efficient, real-time computer vision work with OpenCV.
Written by Robotheca from the project's README (opens in a new tab) at commit 50f6f1f, not by its creator.
The README
Files and versions
Facts read at commit 50f6f1f
- Repository on GitHubgithub.com/ros-perception/vision_opencv (opens in a new tab)
- The version Robotheca read50f6f1f (opens in a new tab)
- Latest releaseNone published on GitHub
Robotheca never hosts the code: each link goes to the creator's own page.
Works with
7 robots on Robotheca
The robots on Robotheca that use it or can run it, each with how the link was found.
Found by Robotheca in src/uav_simulator/local_sensing/package.xml (opens in a new tab)
- Ready to build
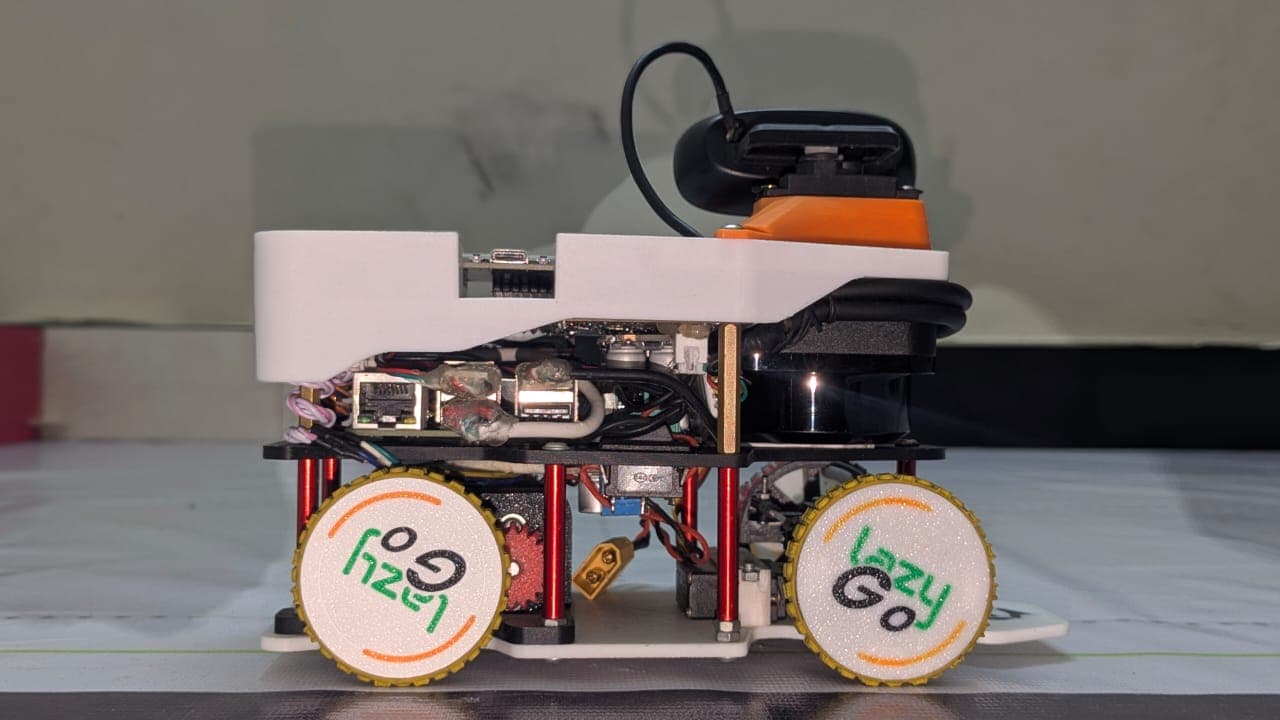
Open source · free files
LazyBot (WRO 2025)
Self-driving 1:10 · Advanced
- Score
- Buildability 88 out of 100
- Cost
- $283.81≈ €254without the 3S LiPo battery and the custom circuit board
Found by Robotheca in src/lazybot/package.xml (opens in a new tab)
- Ready to buildPhoto on GitHub
Found by Robotheca in RapidTeleop/requirements.txt (opens in a new tab)
Found by Robotheca in 05_software/real/sim2real_ros2_v2/src/odin_ros_driver/CMakeLists.txt (opens in a new tab)
- Photo on GitHub
Found by Robotheca in src/uav_simulator/local_sensing/package.xml (opens in a new tab)
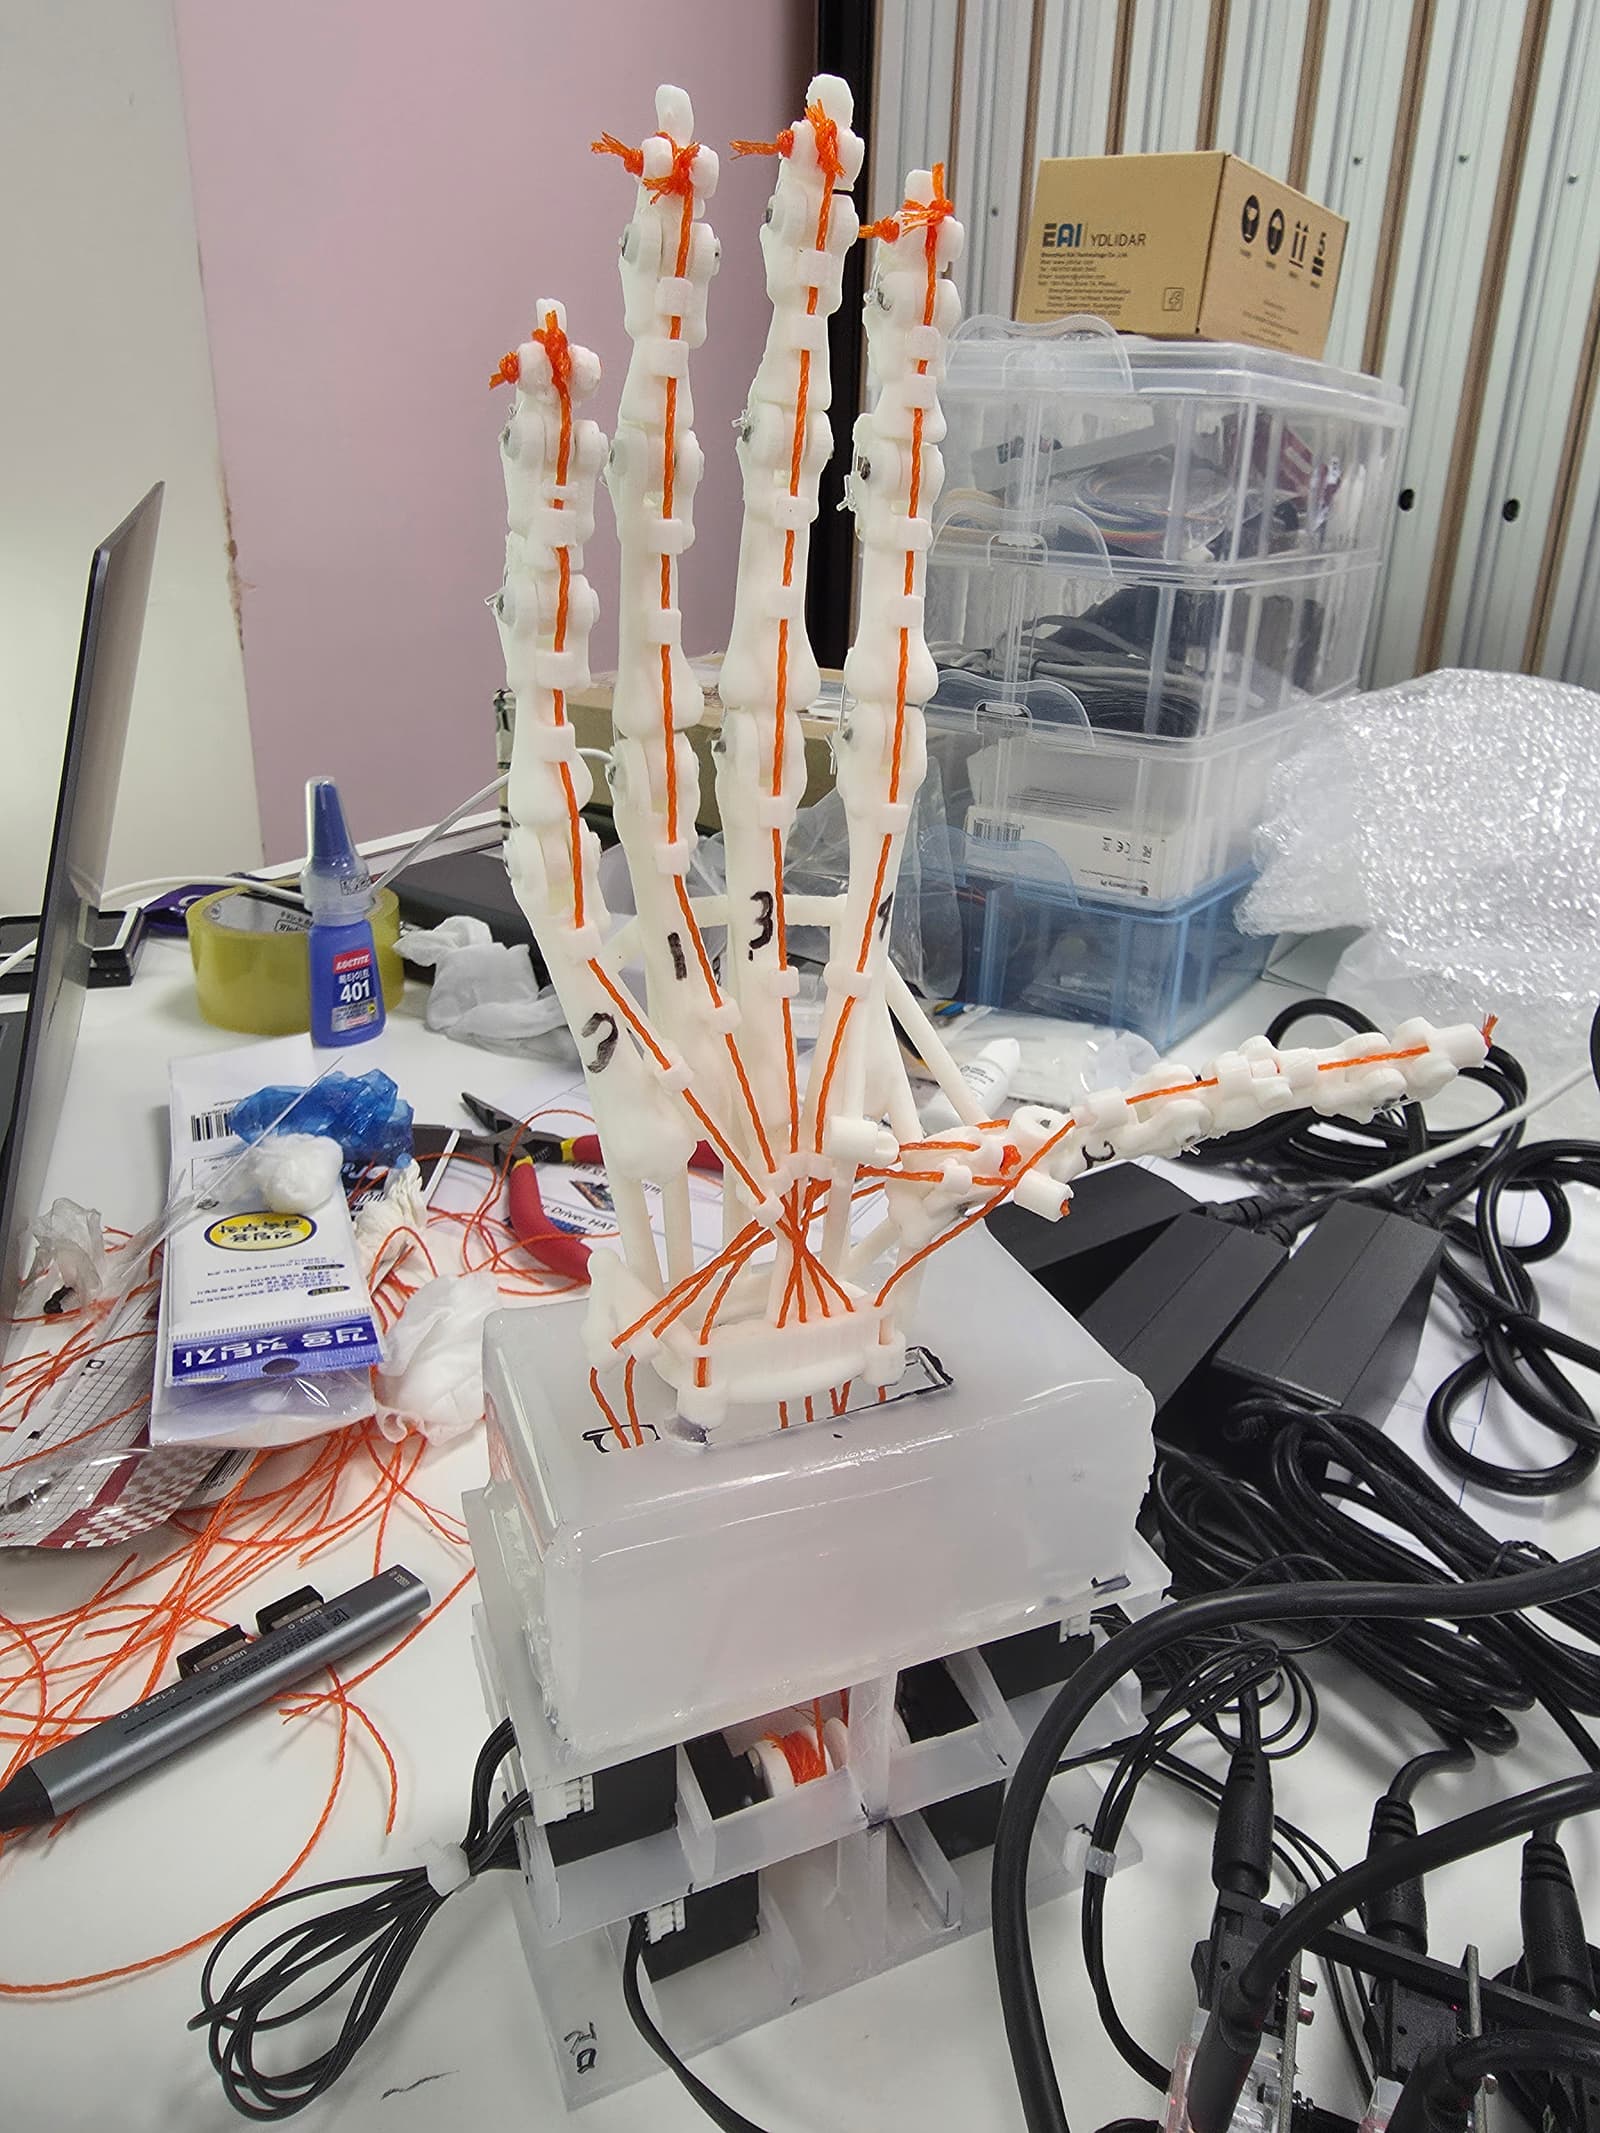
Open source · free files
THING Tendon Hand
Other · Advanced
- Score
- Buildability 74 out of 100
- Cost
- Not stated
Found by Robotheca in thing_ws/src/thing_vision/package.xml (opens in a new tab)
Found by Robotheca in requirements.txt (opens in a new tab)
Use it
How to install it, in the creator's words: The project's README (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.