 3D render
Open source · free files
AhaRobot
Humanoid · Intermediate
- Score
- Buildability 58 out of 100
- Cost
- Not stated
Software
By ROS core stacks, from github.com/ros/joint_state_publisher (opens in a new tab)
Tools for setting and publishing joint state values for a robot's URDF, with a graphical version (joint_state_publisher_gui).
Checked on GitHub on 14 Nov 2026.
No license at the repository's root: each package carries its own. Read the license of each package you use.
No license file at the repository's root at commit 730f48a (opens in a new tab), on 16 Oct 2026.
Each package has its own licence file: joint_state_publisher and joint_state_publisher_gui are BSD-3-Clause.
The robots on Robotheca that use it or can run it, each with how the link was found.
3D renderOpen source · free files
Humanoid · Intermediate
Found by Robotheca in astra_description/package.xml (opens in a new tab)
Found by Robotheca in AlohaMini1/simulation/src/Aloha/package.xml (opens in a new tab)
Open source · free files
Robot arm · Intermediate
Found by Robotheca in arduinobot_controller/package.xml (opens in a new tab)
Open source · free files
Robot arm · Advanced
Found by Robotheca in 2. ros_ws/src/arm_description/package.xml (opens in a new tab)
Open source · free files
Wheeled · Intermediate
Found by Robotheca in bumperbot_description/package.xml (opens in a new tab)
 3D render
Open source · free files
Quadruped · Advanced
Found by Robotheca in code/src/legged_examples/legged_damiao/legged_damiao_description/package.xml (opens in a new tab)
 3D render
Found by Robotheca in el_a3_ros/EDULITE-A3/package.xml (opens in a new tab)
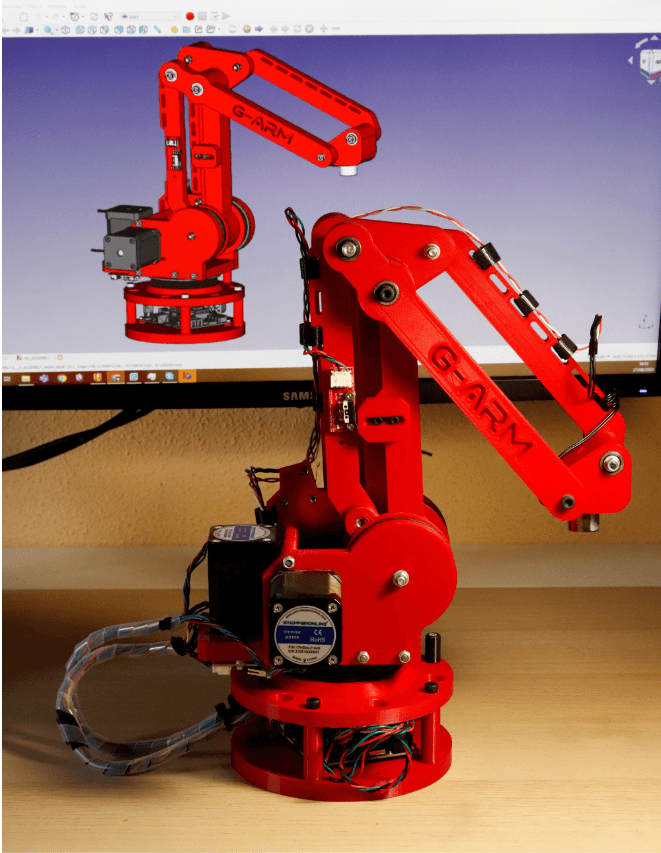
Found by Robotheca in ros2/g_arm_description/package.xml (opens in a new tab)

Open source · free files
Robot arm · Intermediate
Found by Robotheca in giraffe_ws/src/giraffe_description/package.xml (opens in a new tab)
No license yet
Quadruped · Intermediate
Found by Robotheca in 1.Hardware/htdw_4438_urdf/package.xml (opens in a new tab)
Found by Robotheca in sim/gazebo_sim/package.xml (opens in a new tab)
 3D render
Open source · free files
Robot arm · Intermediate
Found by Robotheca in ros2/miniarm_moveit_config/package.xml (opens in a new tab)
Found by Robotheca in 训练代码/OmniBotCtrl/resources/taitan/package.xml (opens in a new tab)
 3D render
Open source · free files
Robot arm · Advanced
Found by Robotheca in moveit_mockway_config/package.xml (opens in a new tab)
Open source · free files
Humanoid · Advanced
Found by Robotheca in OmniBotSeries/URDF/tinker_urdf/package.xml (opens in a new tab)
Found by Robotheca in x37/package.xml (opens in a new tab)
 3D render
Open source · free files
Robot arm · Intermediate
Found by Robotheca in 3.sw2urdf/panther_description/package.xml (opens in a new tab)
Open source · free files
Robot arm · Advanced
Found by Robotheca in PAR6 Description/URDF/par6_flange/package.xml (opens in a new tab)
Found by Robotheca in PAROL6_URDF/PAROL6/package.xml (opens in a new tab)
Found by Robotheca in RapidHandHardware/mechanical_structure/rapidhand_description/package.xml (opens in a new tab)
Open source · free files
Wheeled · Advanced
Found by Robotheca in ROS/rur_description/package.xml (opens in a new tab)
Open source · free files
Other · Advanced
Found by Robotheca in thing_ws/src/thing_description/package.xml (opens in a new tab)
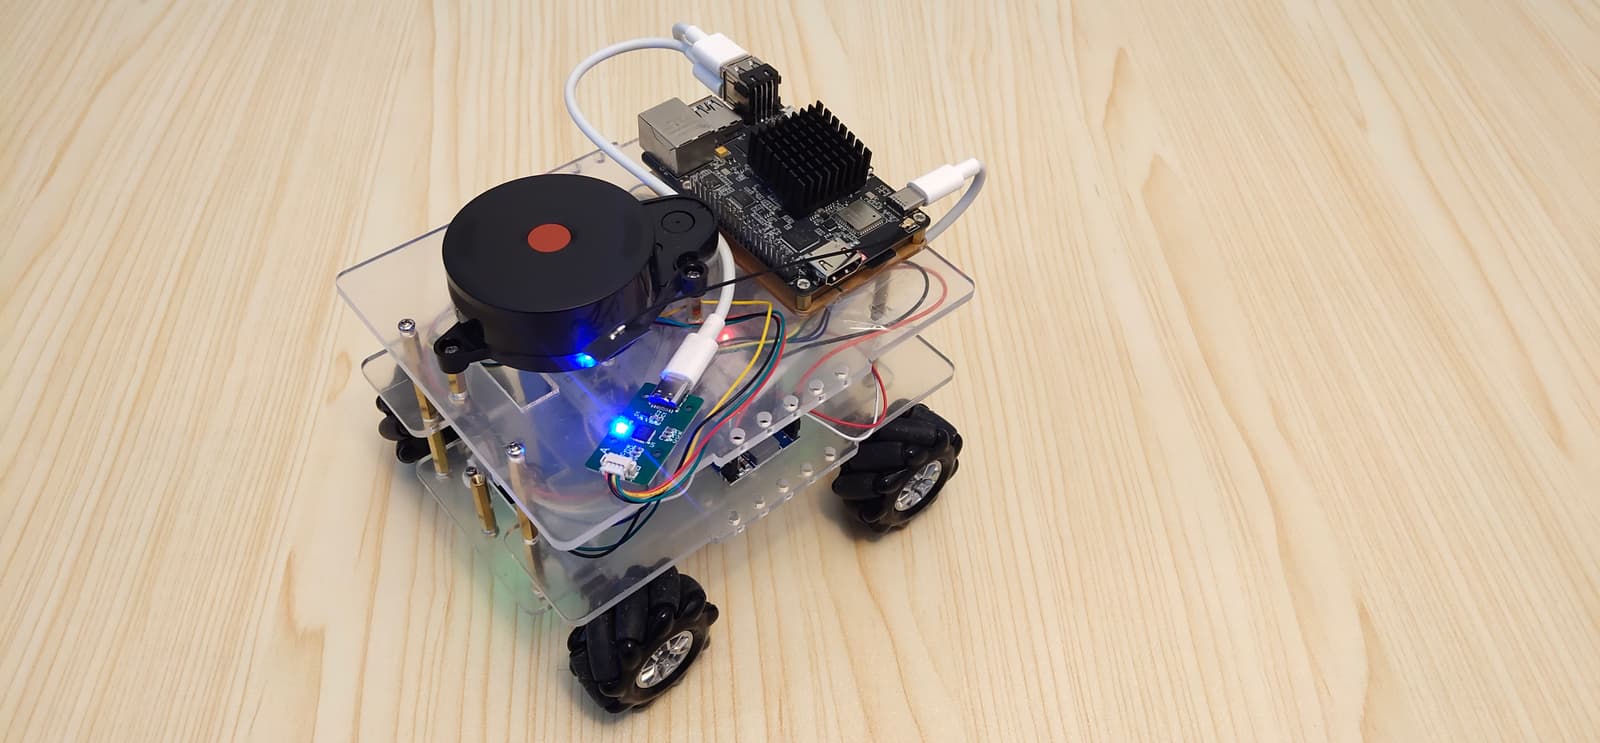
Found by Robotheca in ros2_packages/robot_description/package.xml (opens in a new tab)
Found by Robotheca in src/simulation/mani_skill/examples/bimanual.openarm/openarm_description/package.xml (opens in a new tab)
 3D render
Open source · free files
Other · Advanced
Found by Robotheca in robot_description/8DOFROBOT2/package.xml (opens in a new tab)
 3D render
Found by Robotheca in software/src/enabot_moveit_config/package.xml (opens in a new tab)
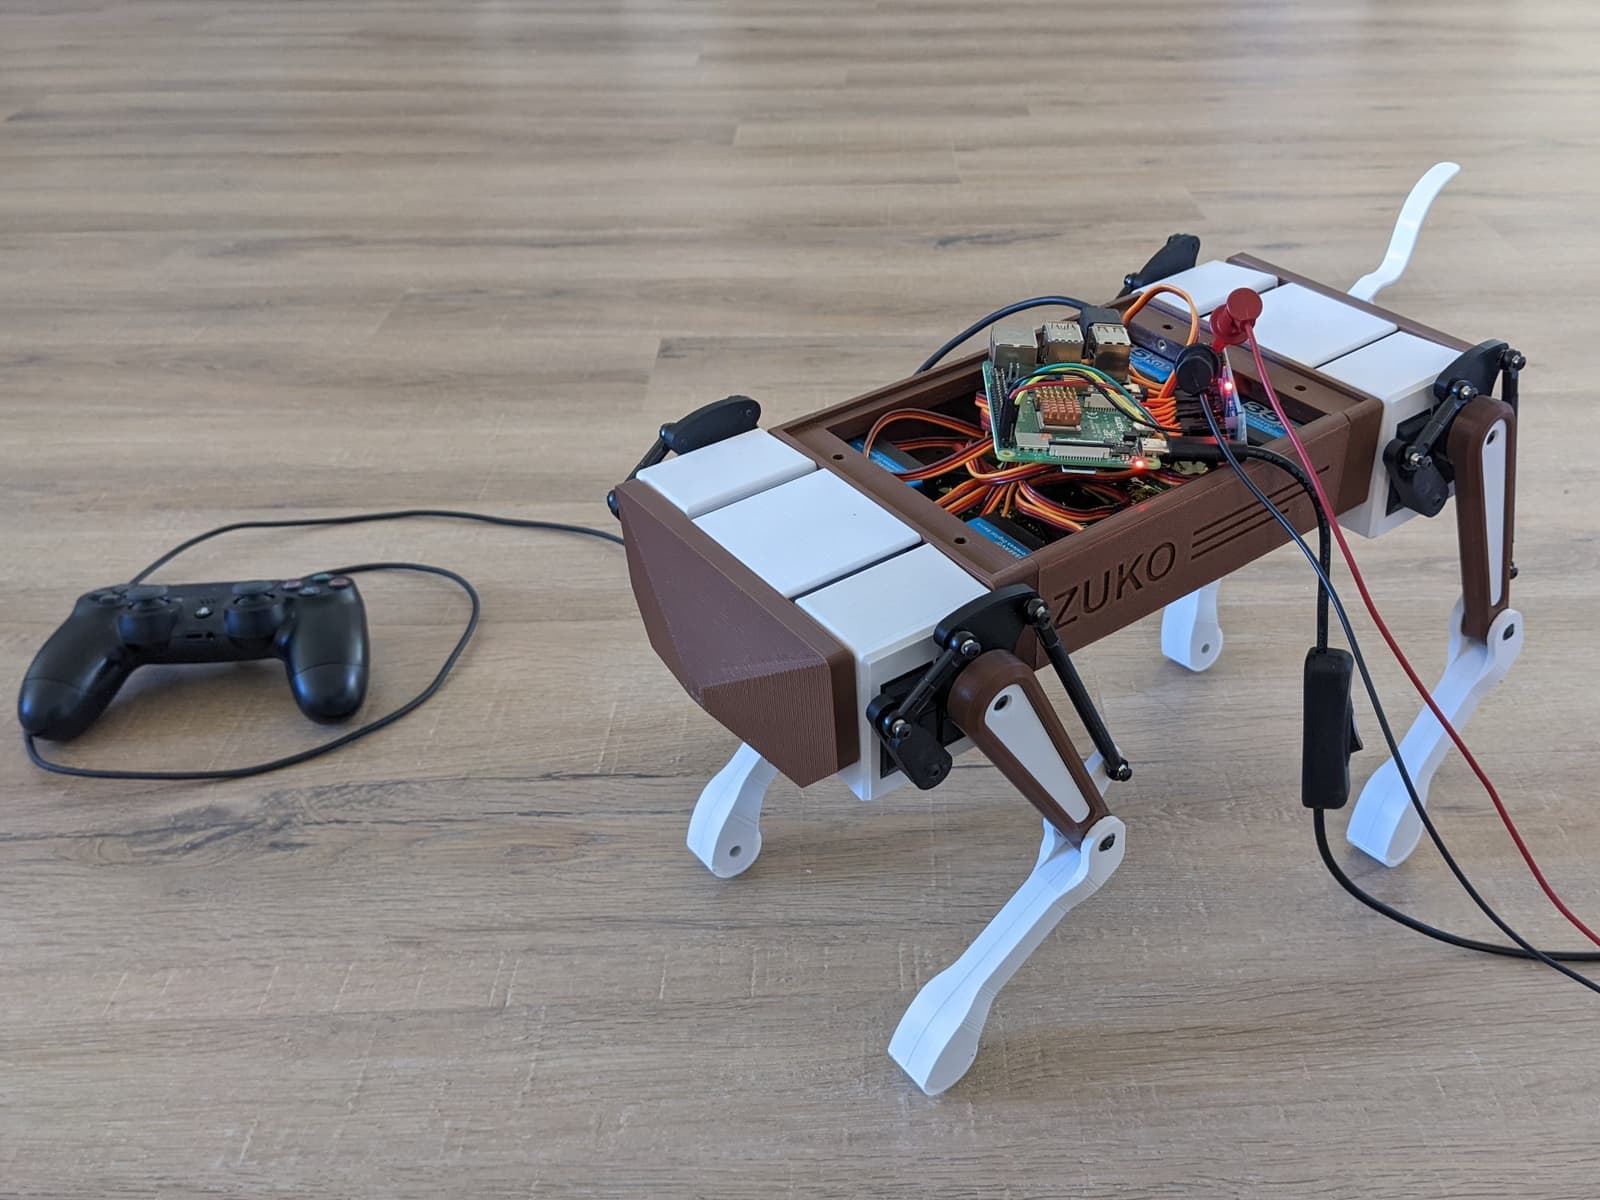
Found by Robotheca in quad_ws/src/quad_udrf/package.xml (opens in a new tab)
How to install it, in the creator's words: Open the repository on GitHub (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca never hosts the code: each link goes to the creator's own page.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.