Bumperbot
An open-source 3D printed self-driving robot powered by ROS 2, designed as a low-cost learning platform.
- Wheeled
- Open source
- ROS 2
- 3D printable
Suggested by Robotheca, created by @AntoBrandi (opens in a new tab), from github.com/AntoBrandi/Bumper-Bot (opens in a new tab). Pinned to commit ffb3948 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
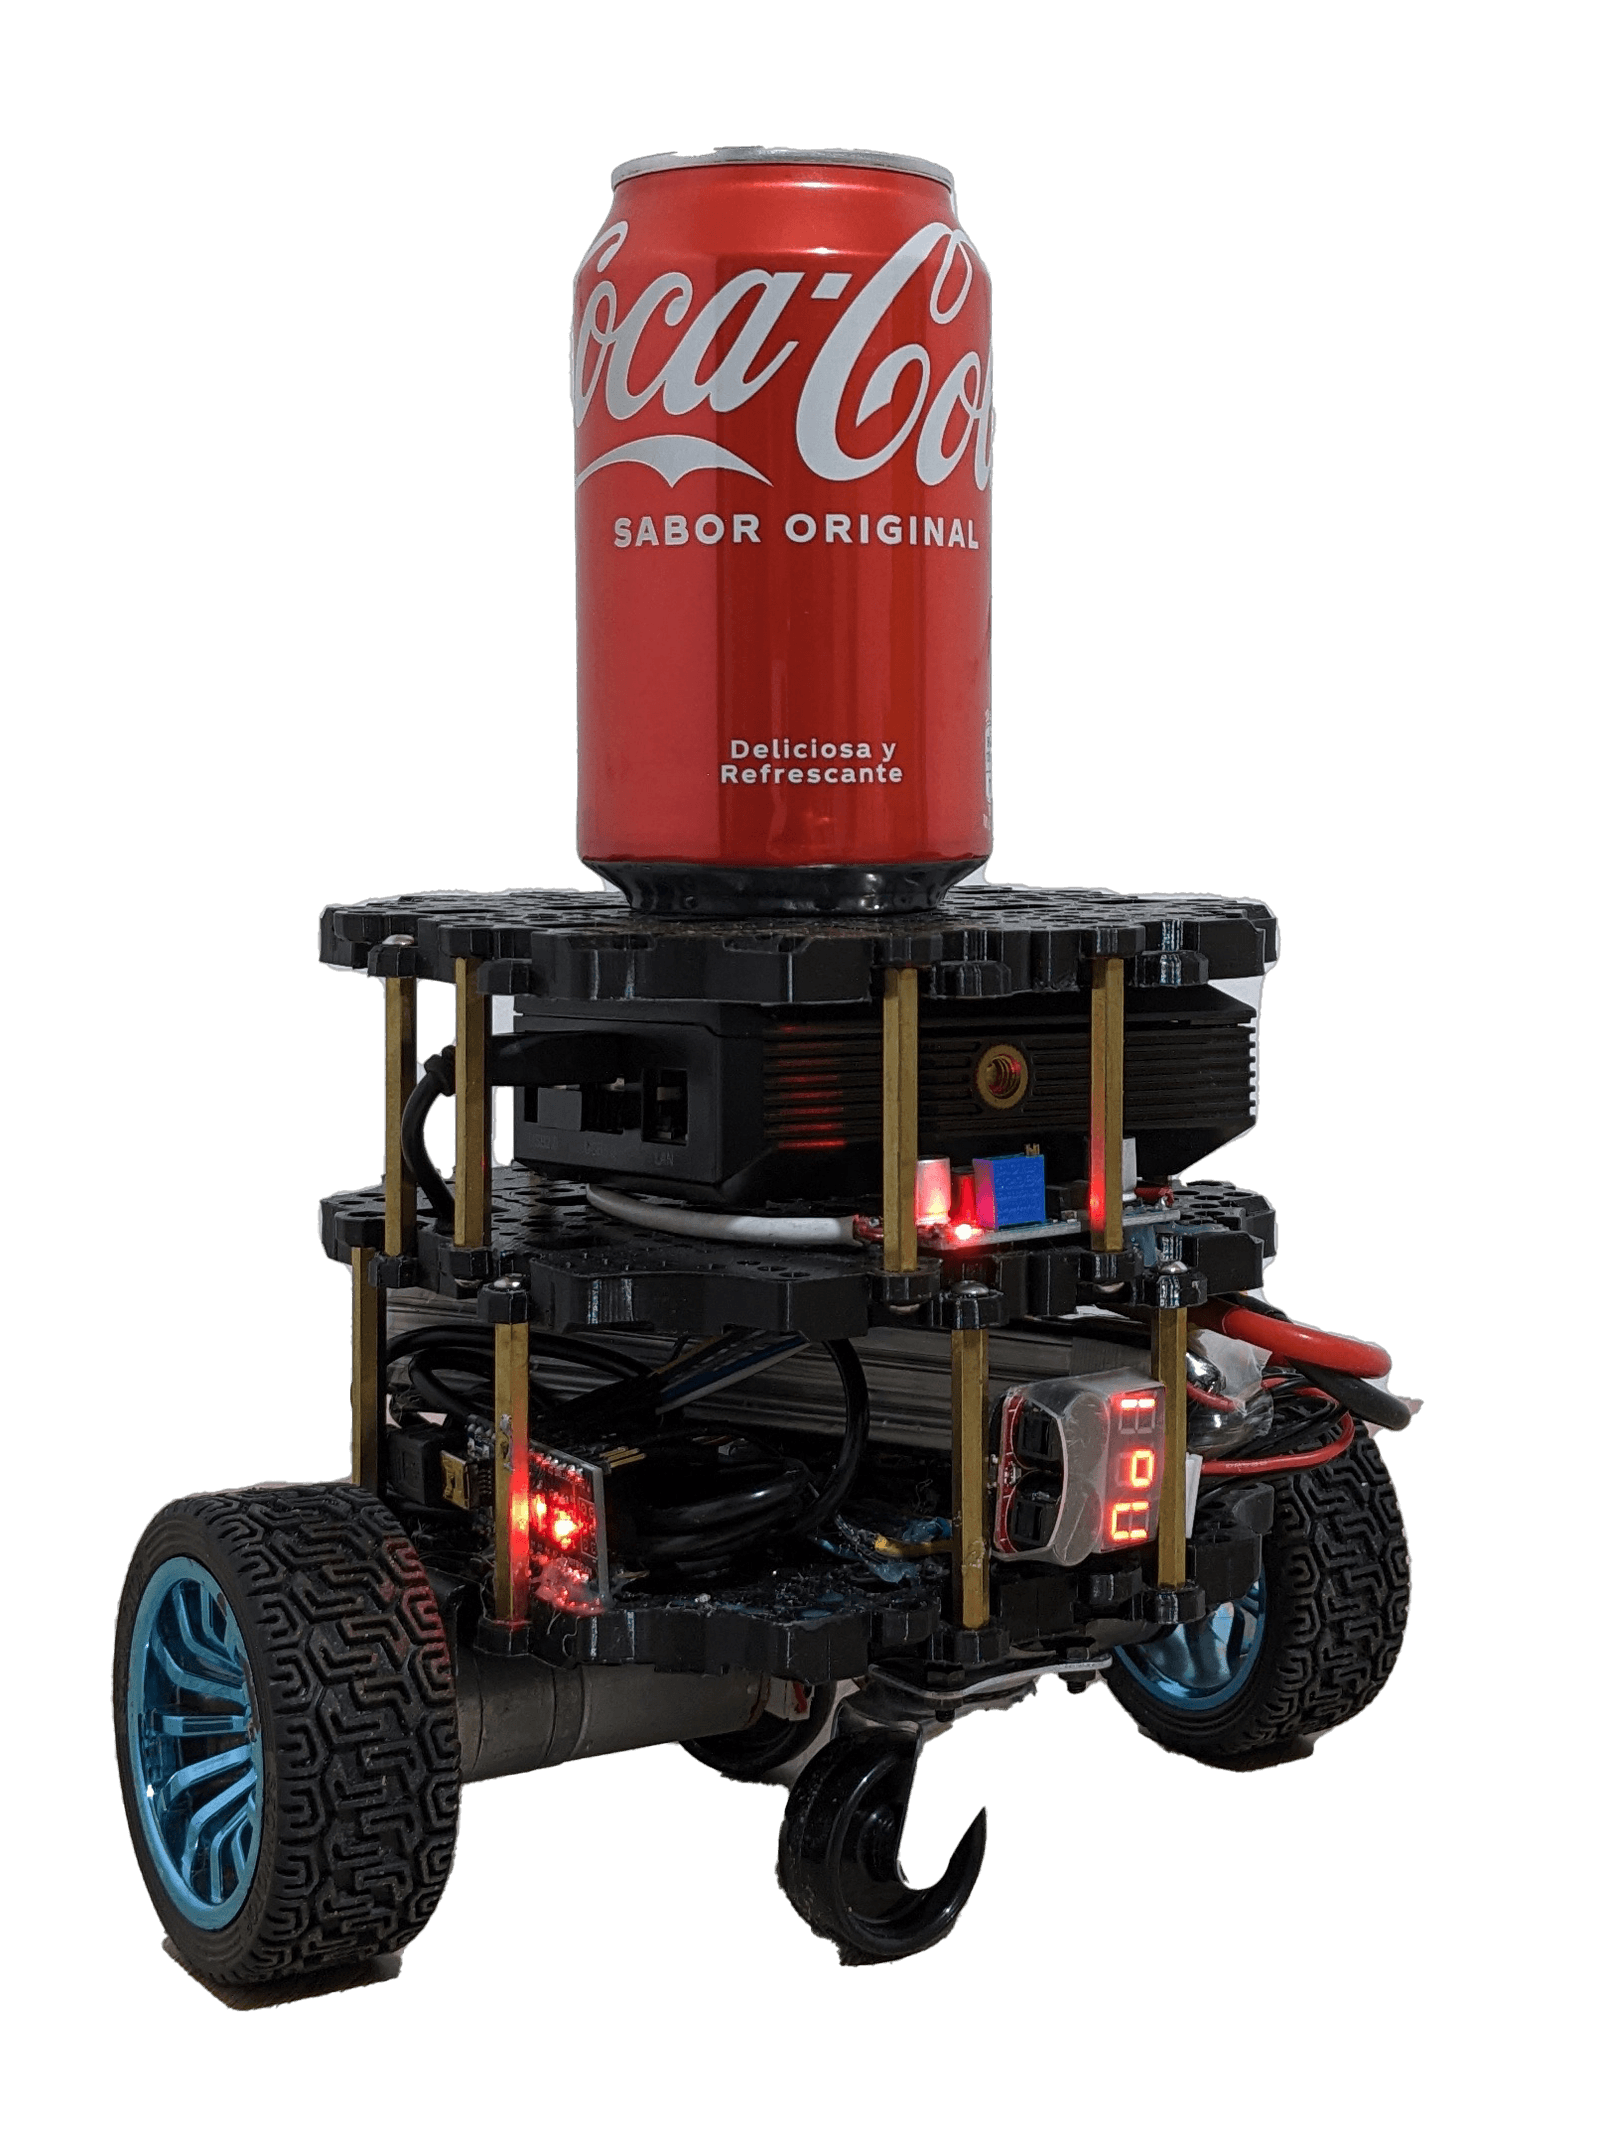
3D preview converted from github.com/AntoBrandi/Bumper-Bot at ffb3948, under Apache-2.0. View the original files from GitHub (15.0 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Self-driving differential-drive robot built on ROS 2, usable in simulation or on the real robot
- Odometry calculation using robot_localization and global localization with Nav2 AMCL
- Mapping with SLAM Toolbox and known-pose mapping
- Path planning and motion control integrated with the Nav2 planner and controller servers
- Launch files start all functionality for the simulated robot or the real robot
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @AntoBrandi (README.md), under Apache-2.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino board that actuates the robot's motors
- Motors driven by the Arduino firmware
- 3D printed chassis with CAD and STL files provided
Connections
- The Arduino controlling the motors is connected to the PC over USB
- The README does not describe further wiring details