No photo yet
Open source · free files
Arduinobot
Robot arm · Intermediate
- Score
- Buildability 63 out of 100
- Cost
- Not stated
ROS 2 is an open-source set of software libraries and tools for building robot applications, from drivers to algorithms and developer tooling.
Source on GitHub: github.com/ros2/ros2 (opens in a new tab). Facts read at commit f6edfcd (opens in a new tab).
No license at the repository's root: each package carries its own. Read the license of each package you use.
No license file at the repository's root at commit f6edfcd (opens in a new tab), on 24 Oct 2026.
No single license: each of the 103 repositories in ros2.repos carries its own. The core packages read (rclcpp, rclpy, rcl, rmw) are Apache-2.0, which allows commercial use.
Written by Robotheca from the project's README (opens in a new tab) at commit eb184ca.
Checked on GitHub on 31 Oct 2026.
Open source · free files
Robot arm · Intermediate
Found by Robotheca in arduinobot_controller/CMakeLists.txt (opens in a new tab)
Open source · free files
Robot arm · Advanced
Found by Robotheca in 2. ros_ws/src/arm_description/CMakeLists.txt (opens in a new tab)
Found by Robotheca in ros2_ws/src/hardware_check/CMakeLists.txt (opens in a new tab)
Open source · free files
Wheeled · Intermediate
Found by Robotheca in bumperbot_controller/CMakeLists.txt (opens in a new tab)
 3D render
Open source · free files
Quadruped · Advanced
Found by Robotheca in code/src/legged_examples/legged_damiao/dmbot_serial/CMakeLists.txt (opens in a new tab)
Found by Robotheca in el_a3_ros/el_a3_hardware/CMakeLists.txt (opens in a new tab)

Open source · free files
Robot arm · Intermediate
Found by Robotheca in giraffe_ws/src/giraffe_hardware/CMakeLists.txt (opens in a new tab)
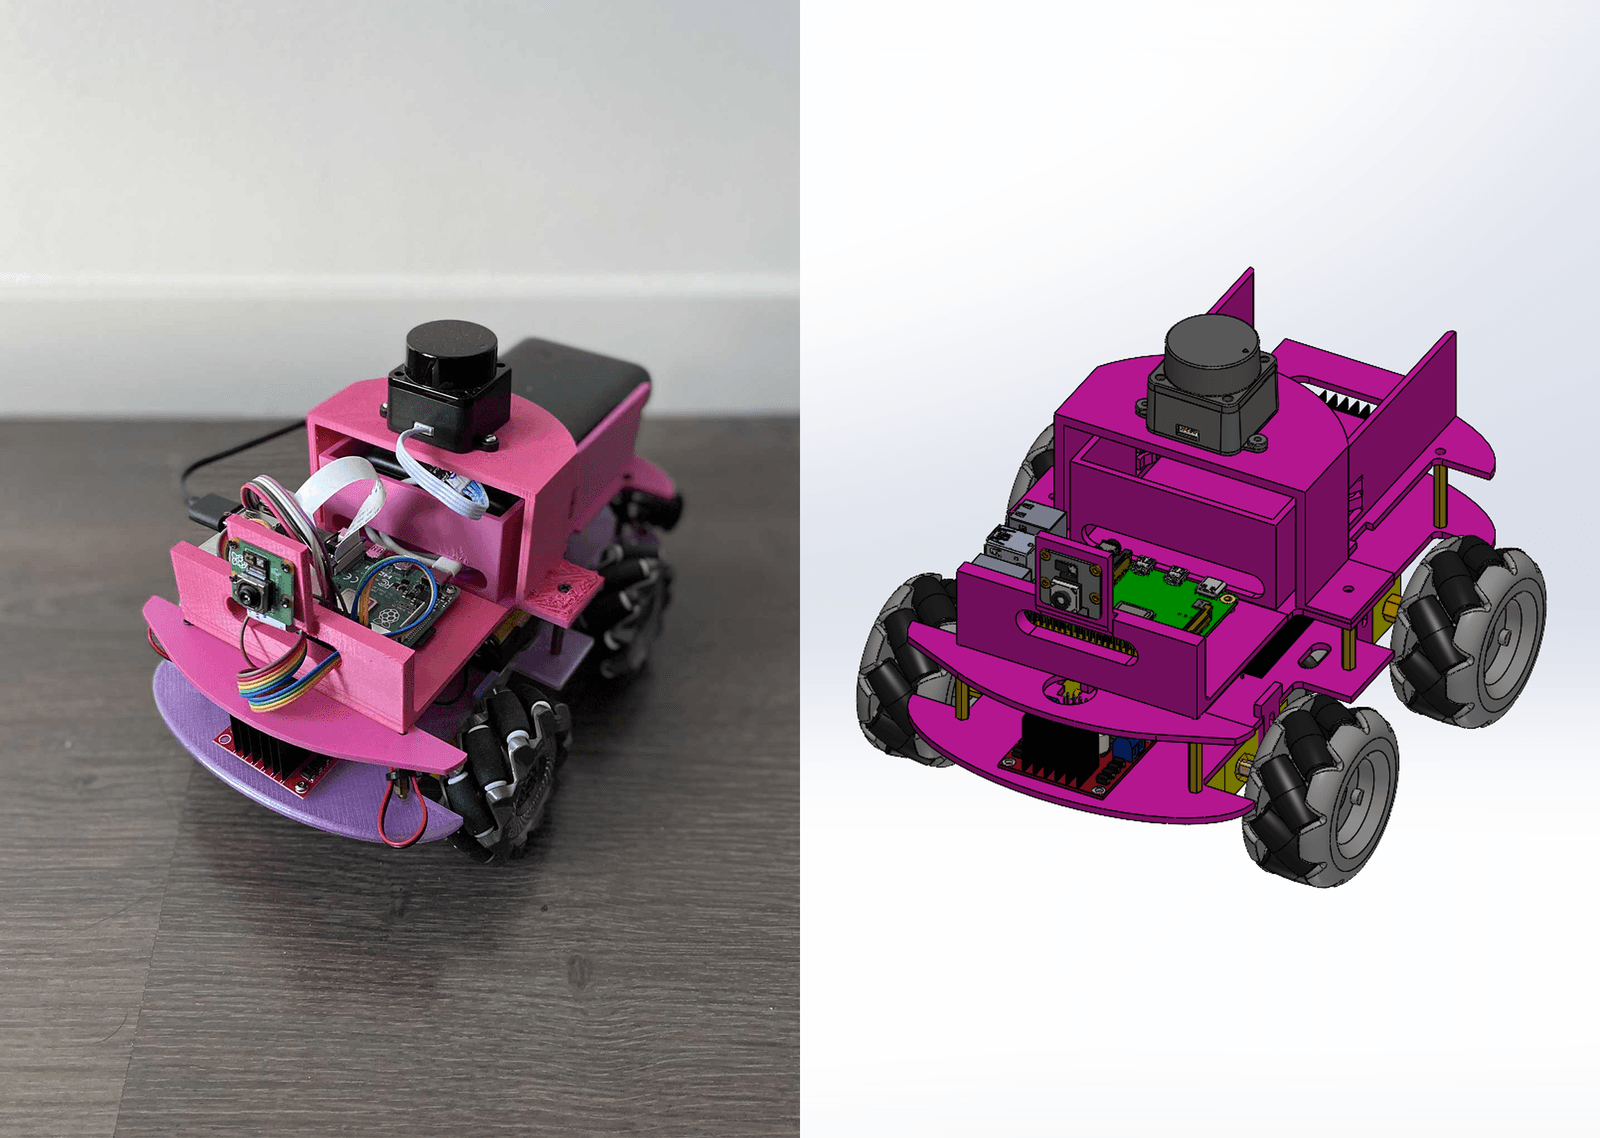
Found by Robotheca in Bot/Software/src/ldlidar_stl_ros2/CMakeLists.txt (opens in a new tab)
 3D render
Open source · free files
Robot arm · Intermediate
Found by Robotheca in ros2/miniarm_servo/CMakeLists.txt (opens in a new tab)
Open source · free files
Robot arm · Advanced
Found by Robotheca in dmmotor_hardware_interface/package.xml (opens in a new tab)
Open source · free files
Wheeled · Intermediate
Found by Robotheca in 参考资料/雷达相关/镭神N10P雷达资料/ROS2_SDK/LSLIDAR_N10P_ROS2/src/lslidar_driver_n10p/CMakeLists.txt (opens in a new tab)
Found by Robotheca in 05_software/real/sim2real_ros2_v2/src/odin_ros_driver/CMakeLists.txt (opens in a new tab)
Open source · free files
Humanoid · Advanced
Found by Robotheca in modules/roboparty_navigation/nav2_localization_adapter/CMakeLists.txt (opens in a new tab)
Open source · free files
Other · Advanced
Found by Robotheca in thing_ws/src/thing_hardware/CMakeLists.txt (opens in a new tab)
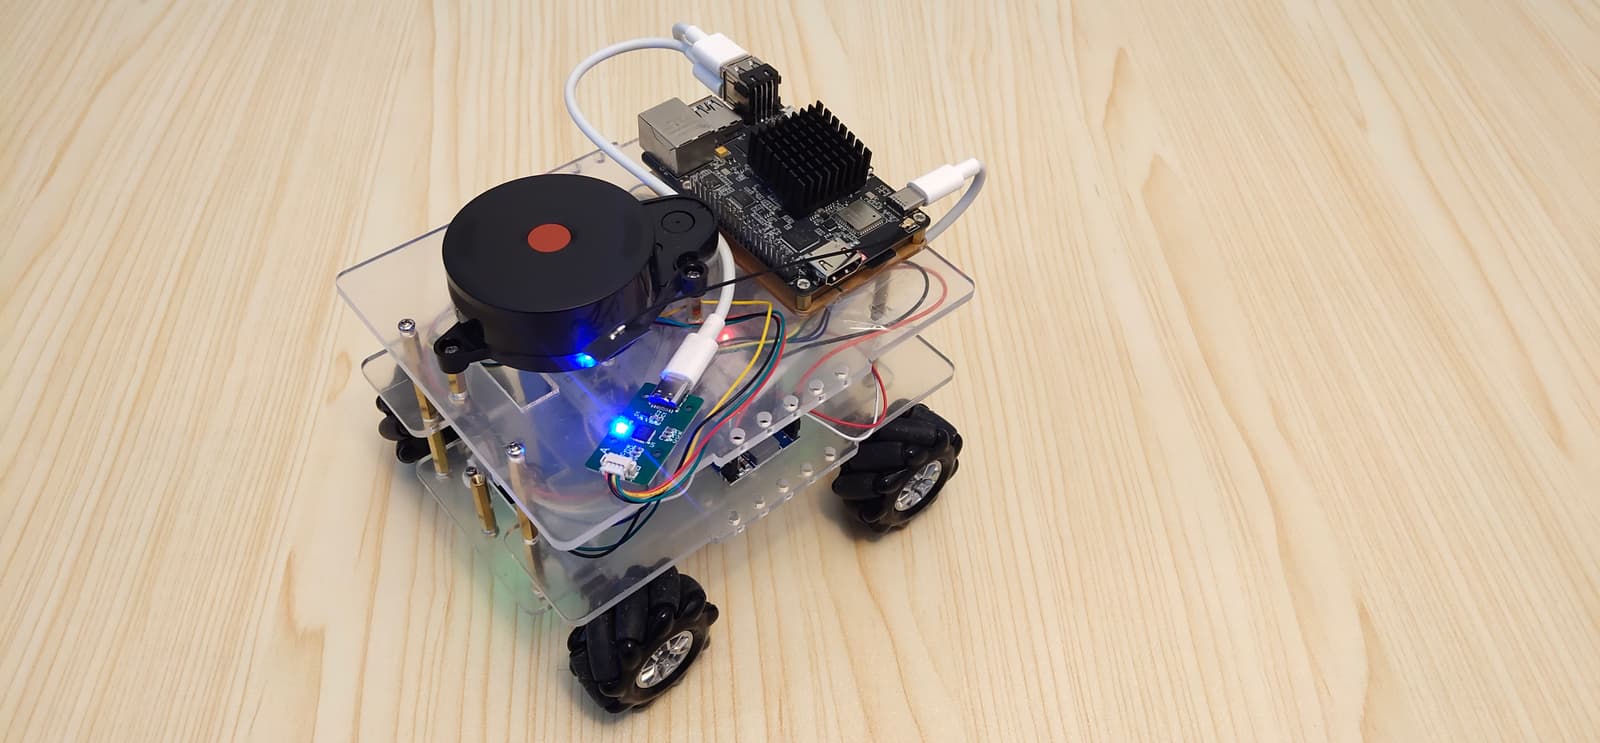
Found by Robotheca in ros2_packages/ld14/CMakeLists.txt (opens in a new tab)
Found by Robotheca in src/simulation/mani_skill/examples/bimanual.openarm/openarm_ros2/openarm_hardware/CMakeLists.txt (opens in a new tab)
No license yet
Drone · Intermediate
Found by Robotheca in 仿真/px4_ros_ws/src/my_flight_controller/CMakeLists.txt (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.