OpenMover
An open-source AGV chassis based on ROS for learning and practical applications.
- Wheeled
- Open source
- ROS
- 3D printable
Suggested by Robotheca, created by @wuyaolinglab (opens in a new tab), from github.com/wuyaolinglab/openmover (opens in a new tab). Pinned to commit 2ae5b2e (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
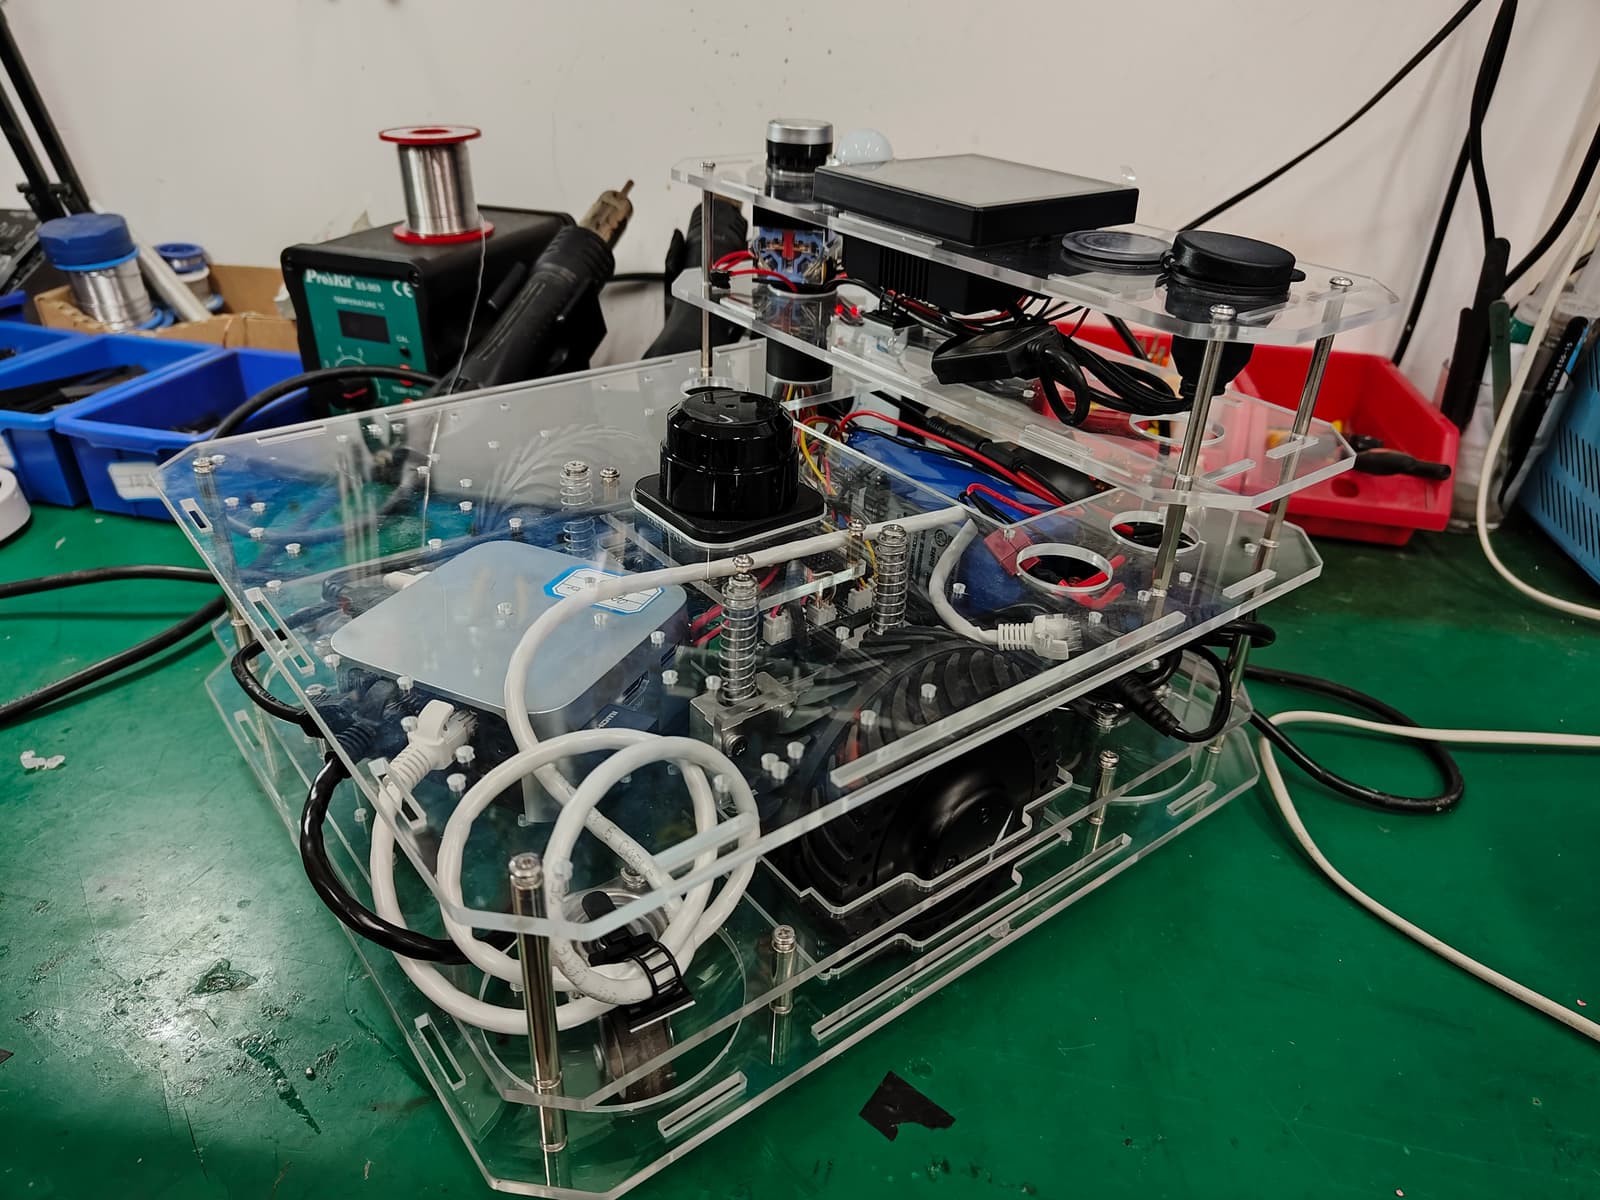
3D preview converted from github.com/wuyaolinglab/openmover at 2ae5b2e, under Apache-2.0. View the original files from GitHub (14.7 MB) (opens in a new tab)
- Height
- 320 mm
- Weight
- 50 kg
What it can do
Written by Robotheca from the project's documents.
- Moves on two differential wheels and four caster wheels
- Controlled via ROS from an N100 industrial computer over Ethernet
- Detects surroundings with a TOF laser radar (LDS-50C-C30E or N10P)
- Supports expansion with arms, lifting platforms, or inspection equipment
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Assemble the chassis structure
- 2Install the main control board
- 3Mount the motors and wheels
- 4Set up the power system
- 5Install the laser radar
- 6Configure the ROS system
The guide appears here as you scroll.
Guide by @wuyaolinglab (README.md), under Apache-2.0. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32S3 microcontroller on the base control board
- DDSM115 direct-drive servo hub motors with RS485 bus
- LDS-50C-C30E or N10P TOF laser radar connected via Ethernet
- 14.8 V lithium battery pack (10500 mAh)
- Dual 12 V power outputs (max 3 A each)
- Dual UART-to-Ethernet module (USR-TCP232-E) for communication
Connections
- ESP32S3 communicates with N100 via USR-TCP232-E Ethernet module
- ESP32S3 controls motors over RS485 bus
- Laser radar connects to N100 via Ethernet
- ESP32S3 provides dual 12 V power outputs for accessories
- ESP32S3 interfaces with external LEDs and buttons