No photo yet
Robot armArduinobot
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
- Level
- Intermediate
- Buildability
- 63/100
- Buildable with some effort
- Cost
- Not stated
rclpy is the Python client library for ROS 2, letting Python programs act as ROS 2 nodes. It is used to write robot software in Python.
Made by ROS 2.
Source on GitHub: github.com/ros2/rclpy (opens in a new tab). Facts read at commit 5c4cb9d (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (Apache-2.0) at commit 5c4cb9d (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 5c4cb9d.
Checked on GitHub on 16 Oct 2026.
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
Found by Robotheca in arduinobot_controller/CMakeLists.txt (opens in a new tab)
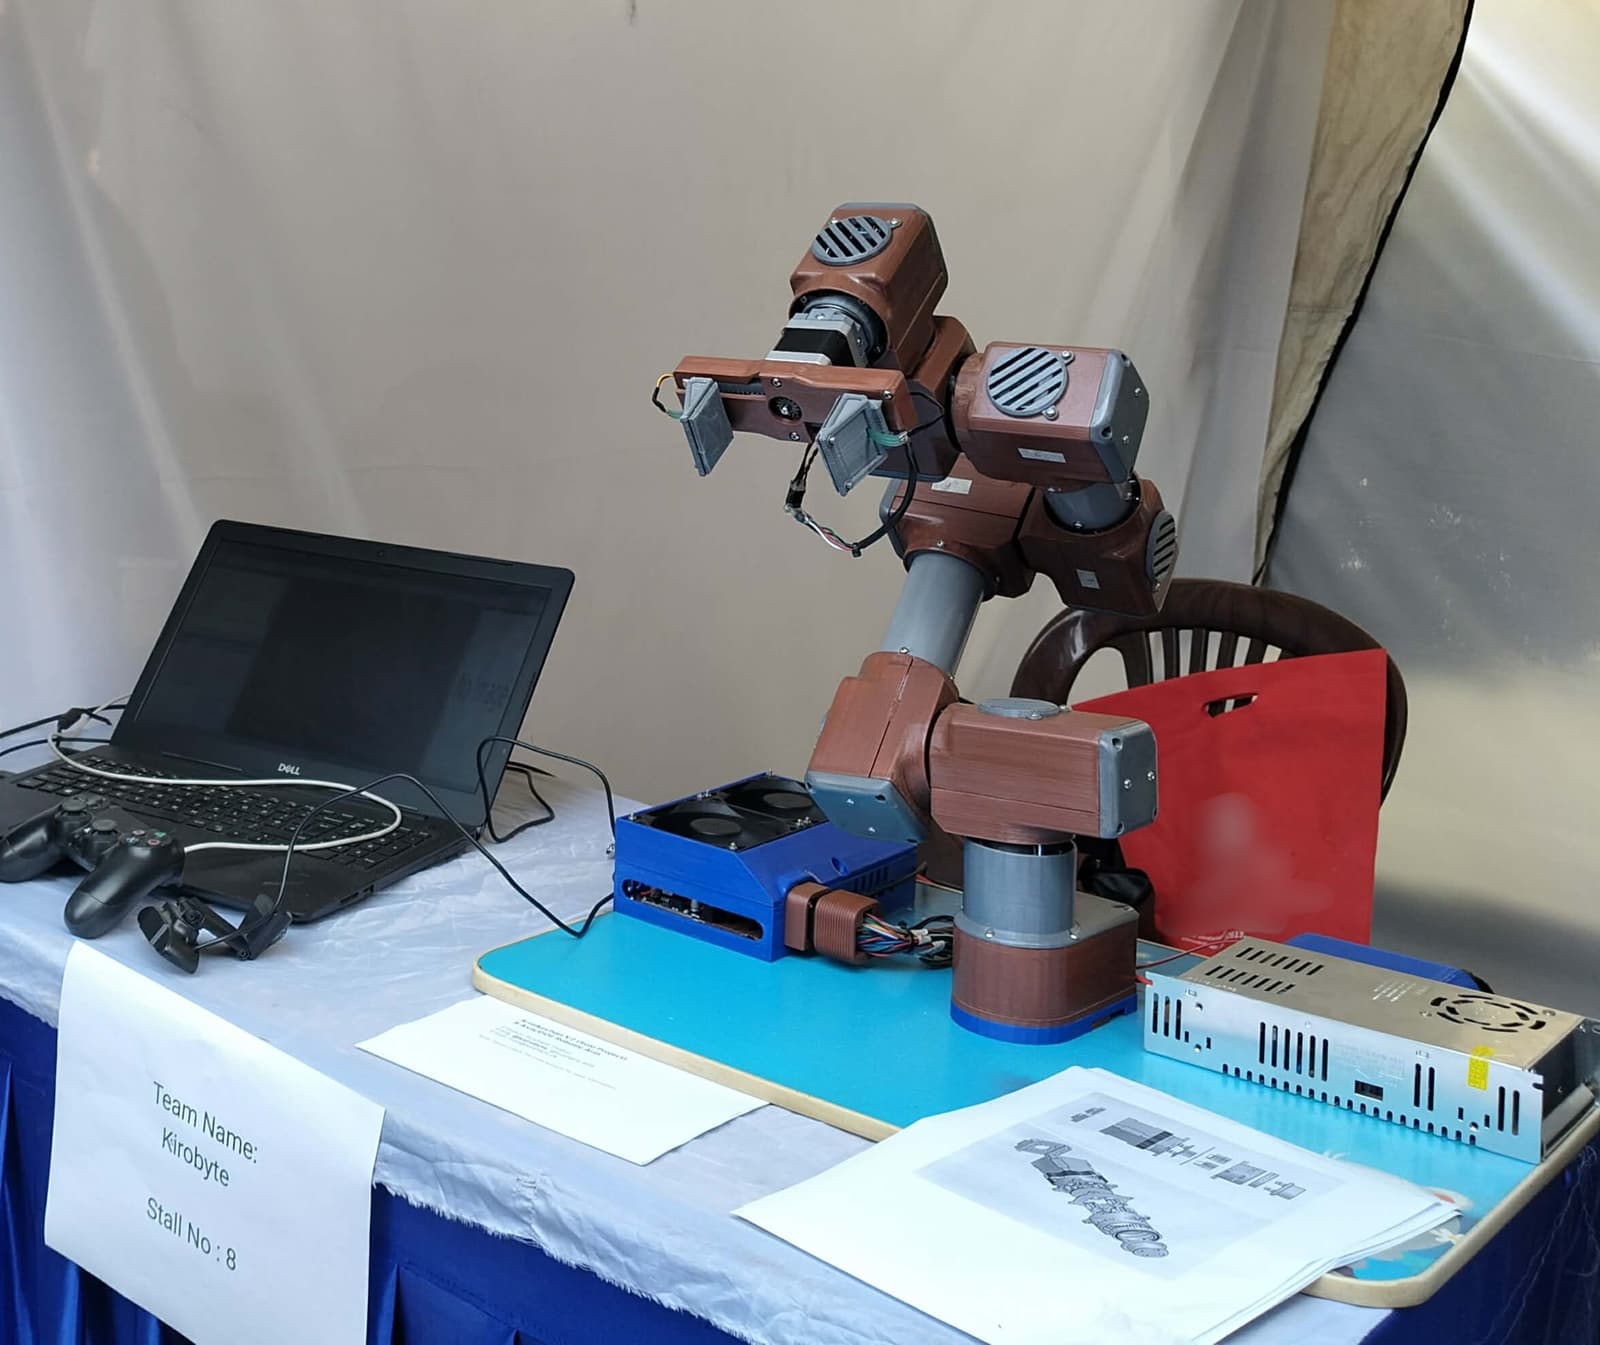 Robot arm
An open-source 8-axis ROS2 robotic arm with 3D-printed planetary gears and FSR-based tactile gripper feedback.
Found by Robotheca in 2. ros_ws/src/arm_controller/package.xml (opens in a new tab)
 Wheeled
An open-source 3D printed self-driving robot powered by ROS 2, designed as a low-cost learning platform.
Found by Robotheca in bumperbot_controller/CMakeLists.txt (opens in a new tab)
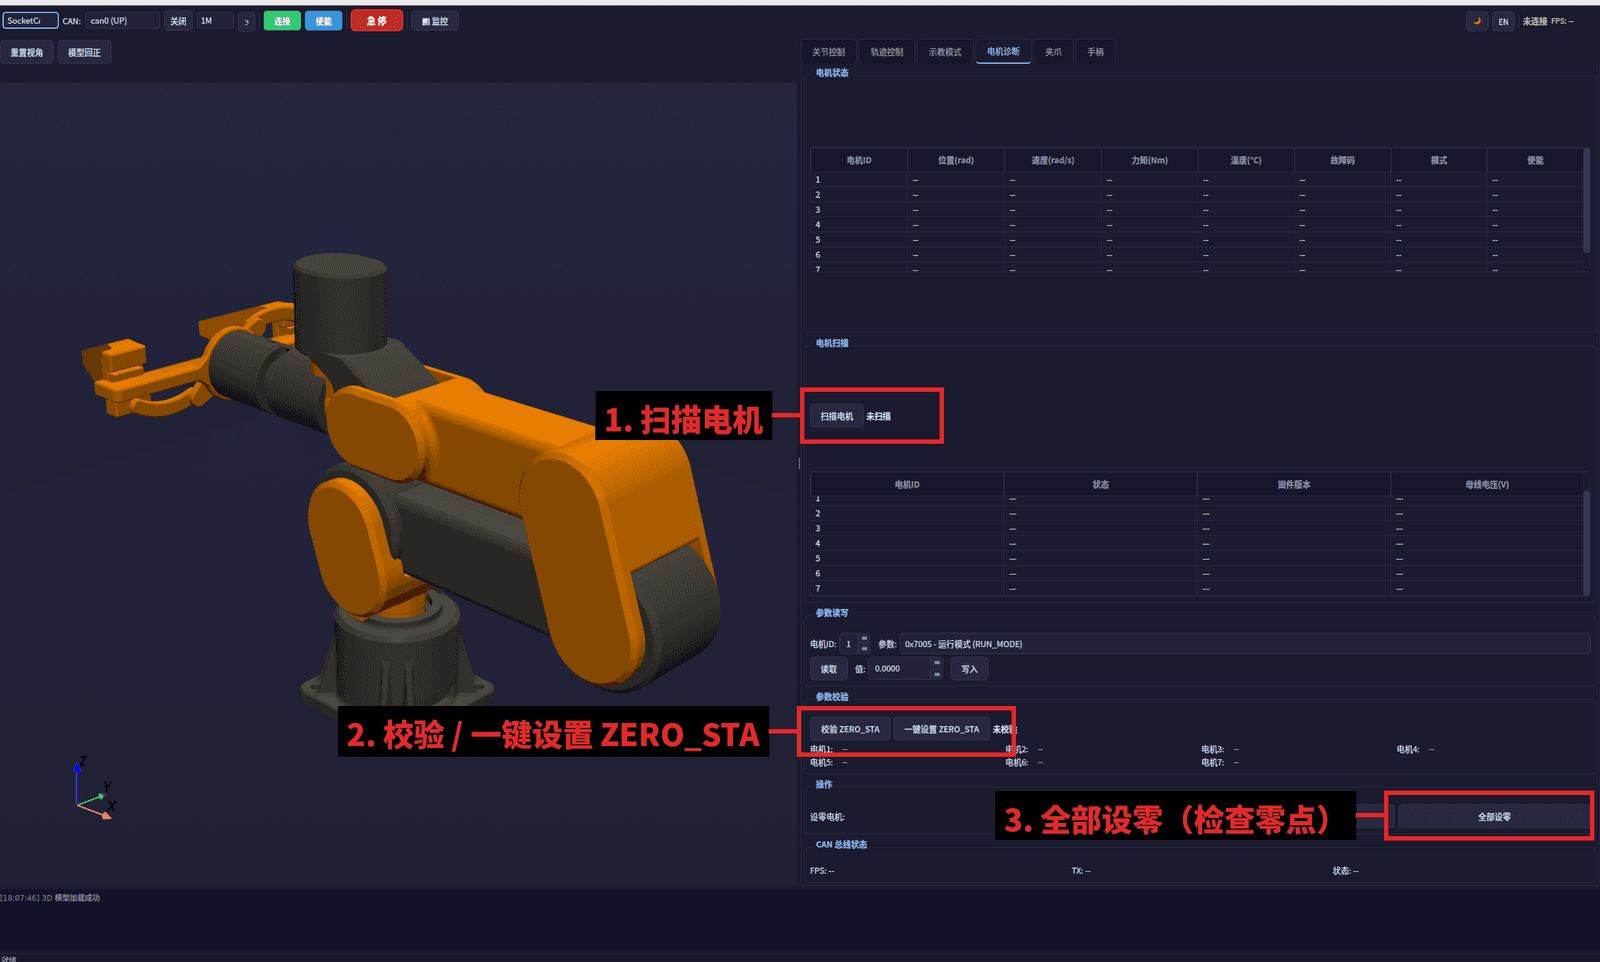 Robot arm
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
Found by Robotheca in el_a3_ros/el_a3_teleop/package.xml (opens in a new tab)
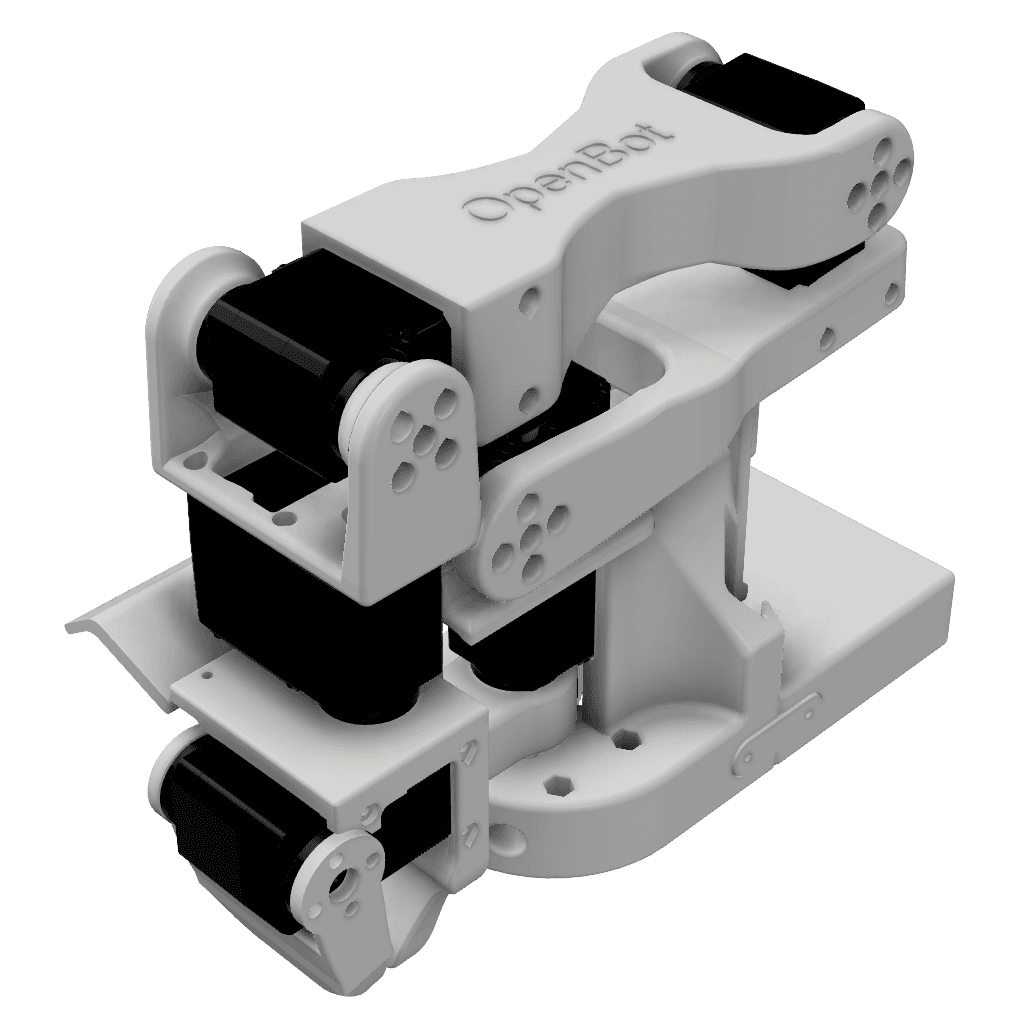 Robot arm
A cost-effective, ROS2-compatible 5-DoF robotic manipulator with a leader-follower teleoperation setup, designed to lower the barrier to entry for Embodied AI.
Found by Robotheca in giraffe_ws/src/giraffe_control/package.xml (opens in a new tab)
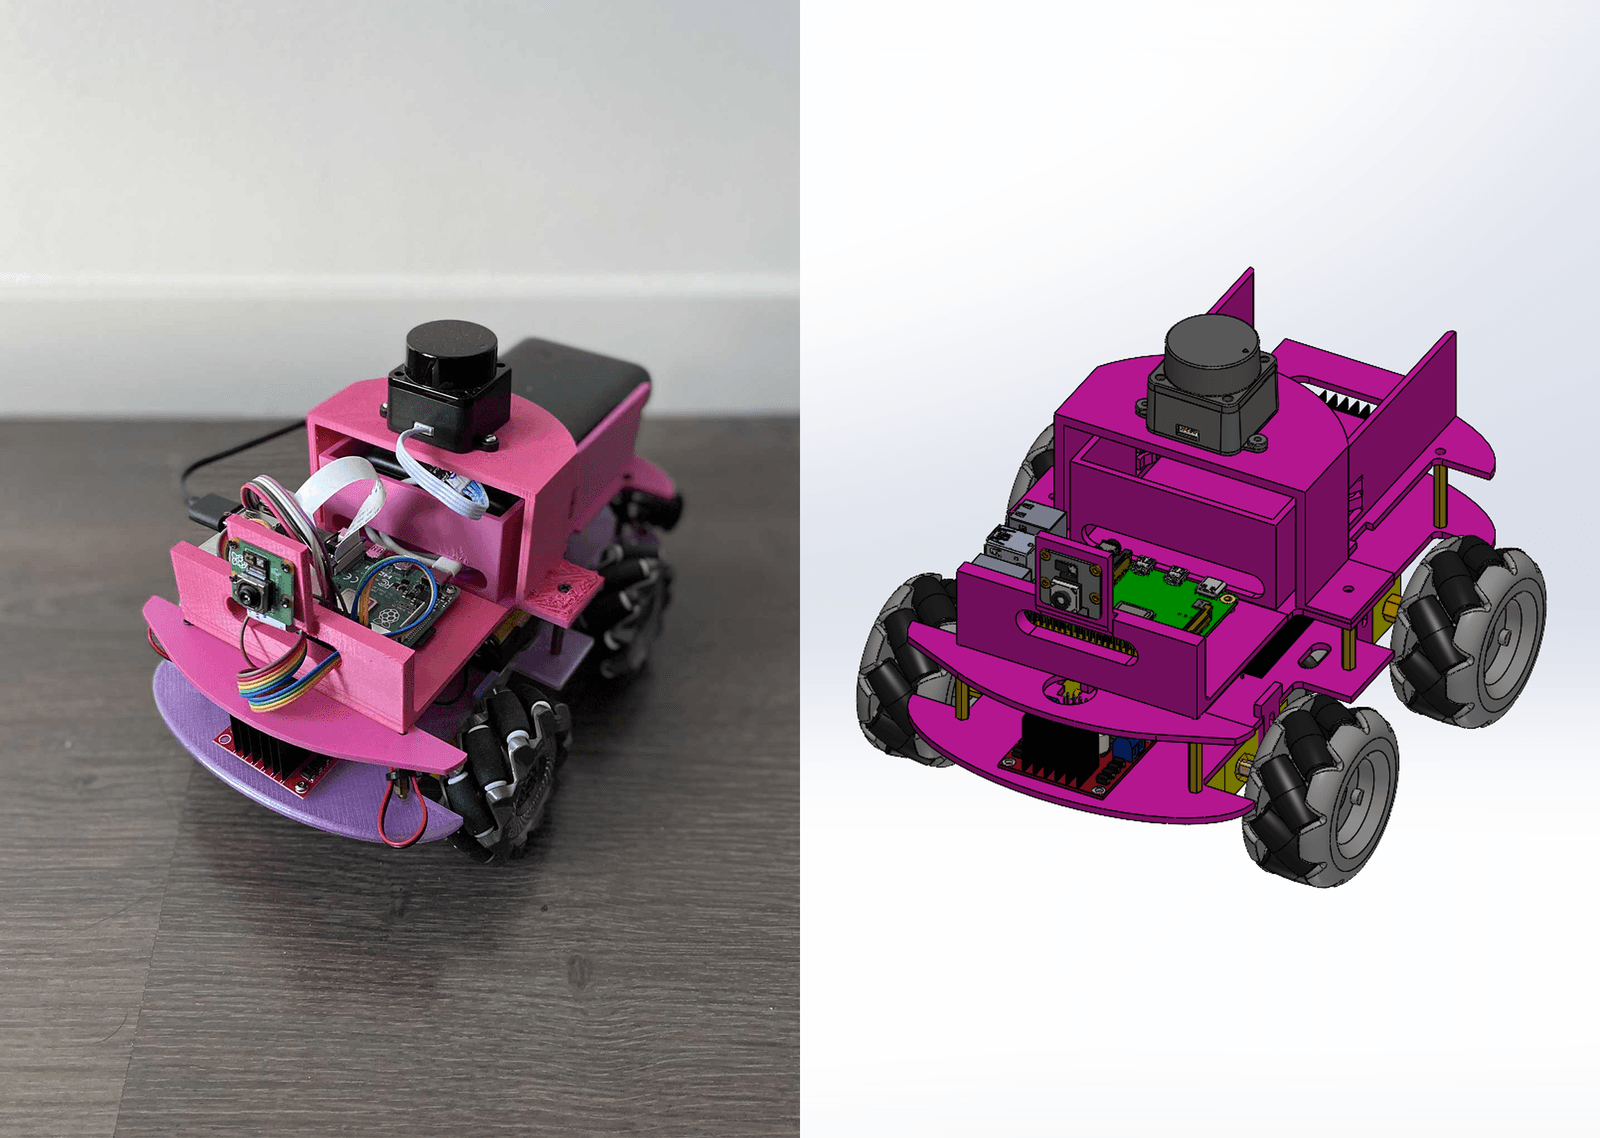 Wheeled
An open-source autonomous mecanum wheel robot for learning and experimentation that navigates manually or autonomously using a Lidar.
Found by Robotheca in Bot/Software/src/just1_camera/package.xml (opens in a new tab)
An open-source autonomous drone platform using ROS2 and AI-powered flight control, designed to be understood, built, and extended.
Found by Robotheca in src/swarm_ai_integration/CMakeLists.txt (opens in a new tab)
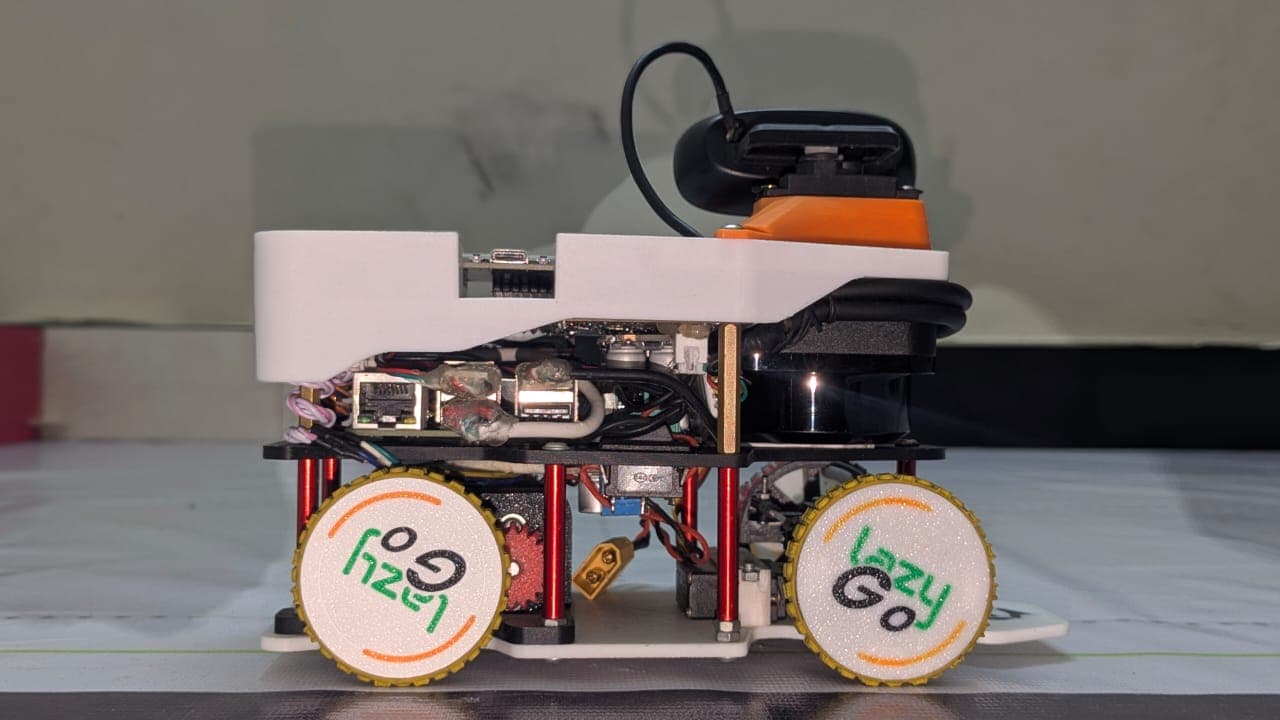 Self-driving 1:10
A self-driving robot built by Team LazyGo from Bangladesh to complete laps, avoid colored obstacles and park for the World Robot Olympiad 2025 Future Engineers category.
Found by Robotheca in src/lazybot/package.xml (opens in a new tab)
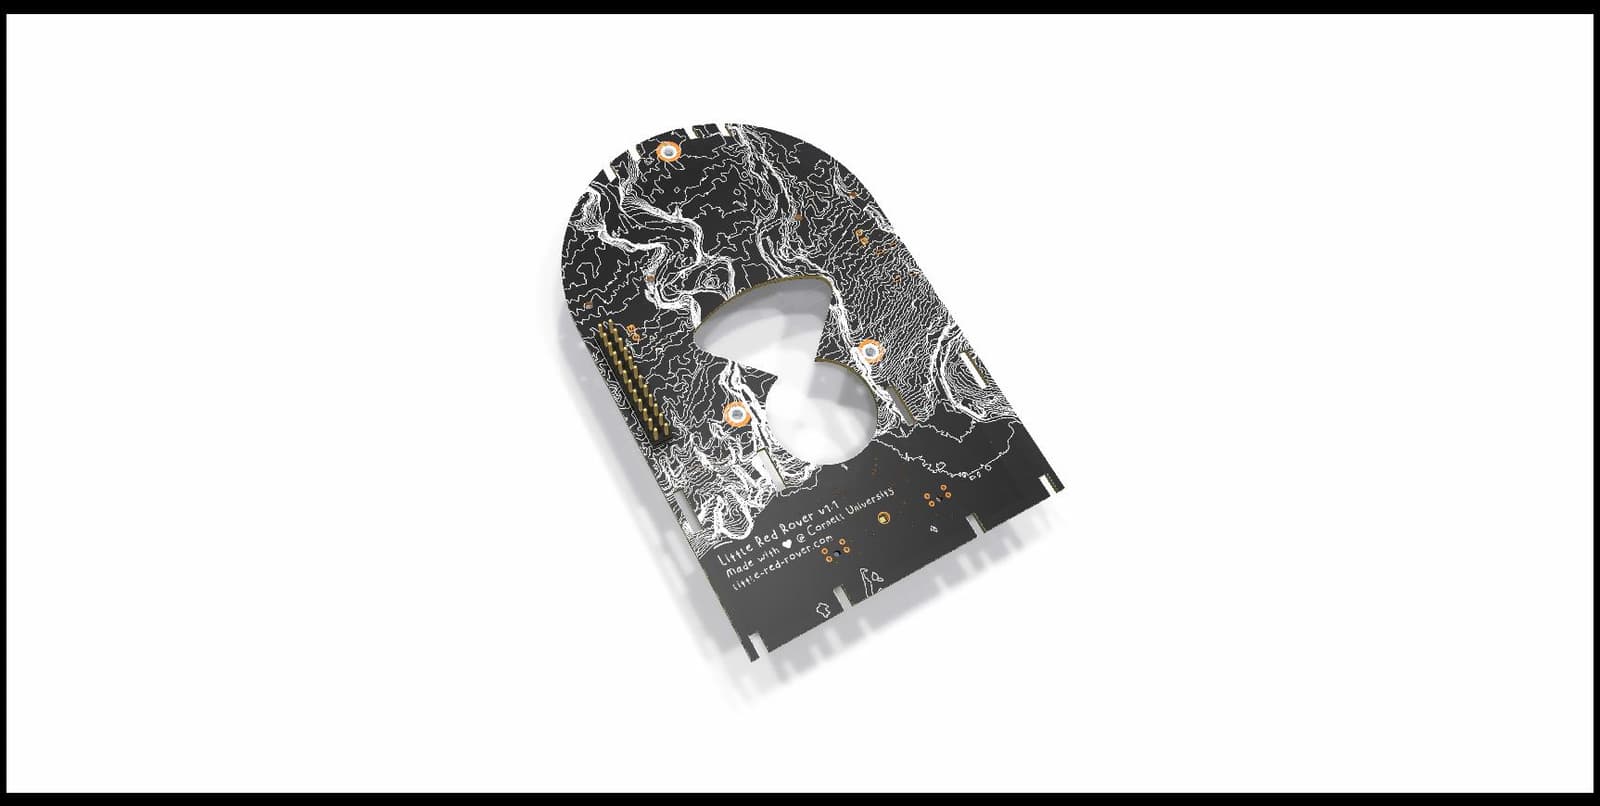 Wheeled
A minimal cost, maximal impact ROS 1 / ROS 2 mobile robot built for education.
Found by Robotheca in SOFTWARE/ros2_ws/src/little_red_rover/package.xml (opens in a new tab)
An open-source 6-DOF collaborative robotic arm system with mechanical structure, electronics, and software.
Found by Robotheca in mockway_moveit_servo/package.xml (opens in a new tab)
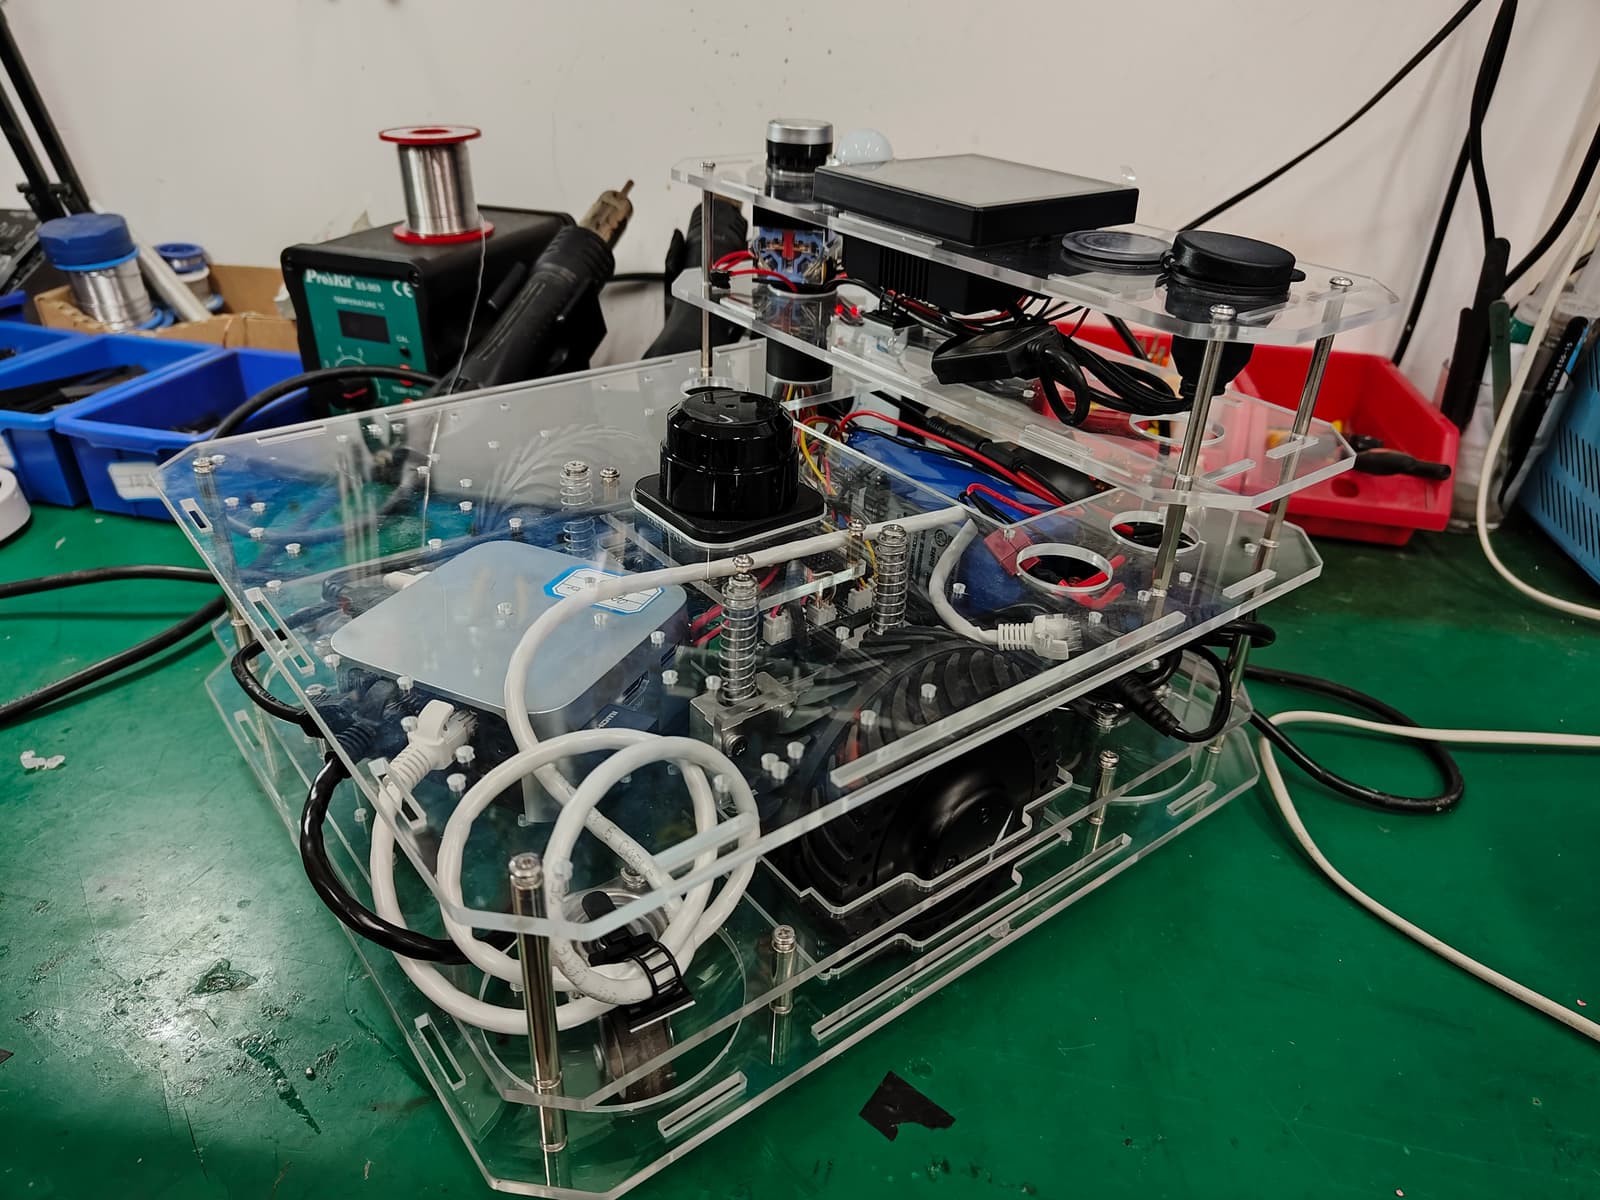 Wheeled
An open-source AGV chassis based on ROS for learning and practical applications.
Found by Robotheca in 参考资料/雷达相关/镭神N10P雷达资料/ROS2_SDK/LSLIDAR_N10P_ROS2/src/lslidar_driver_n10p/CMakeLists.txt (opens in a new tab)
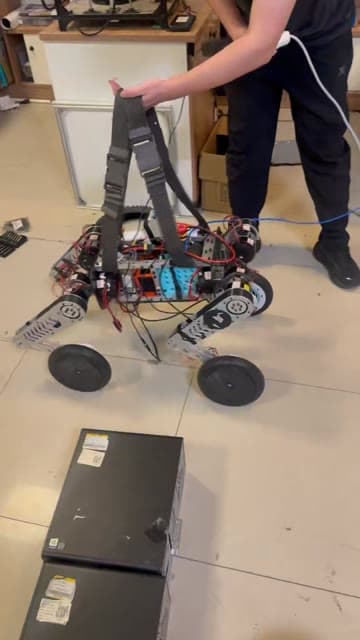 Wheeled
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
Found by Robotheca in 05_software/real/sim2real_ros2_v2/src/sim2real_runtime/package.xml (opens in a new tab)
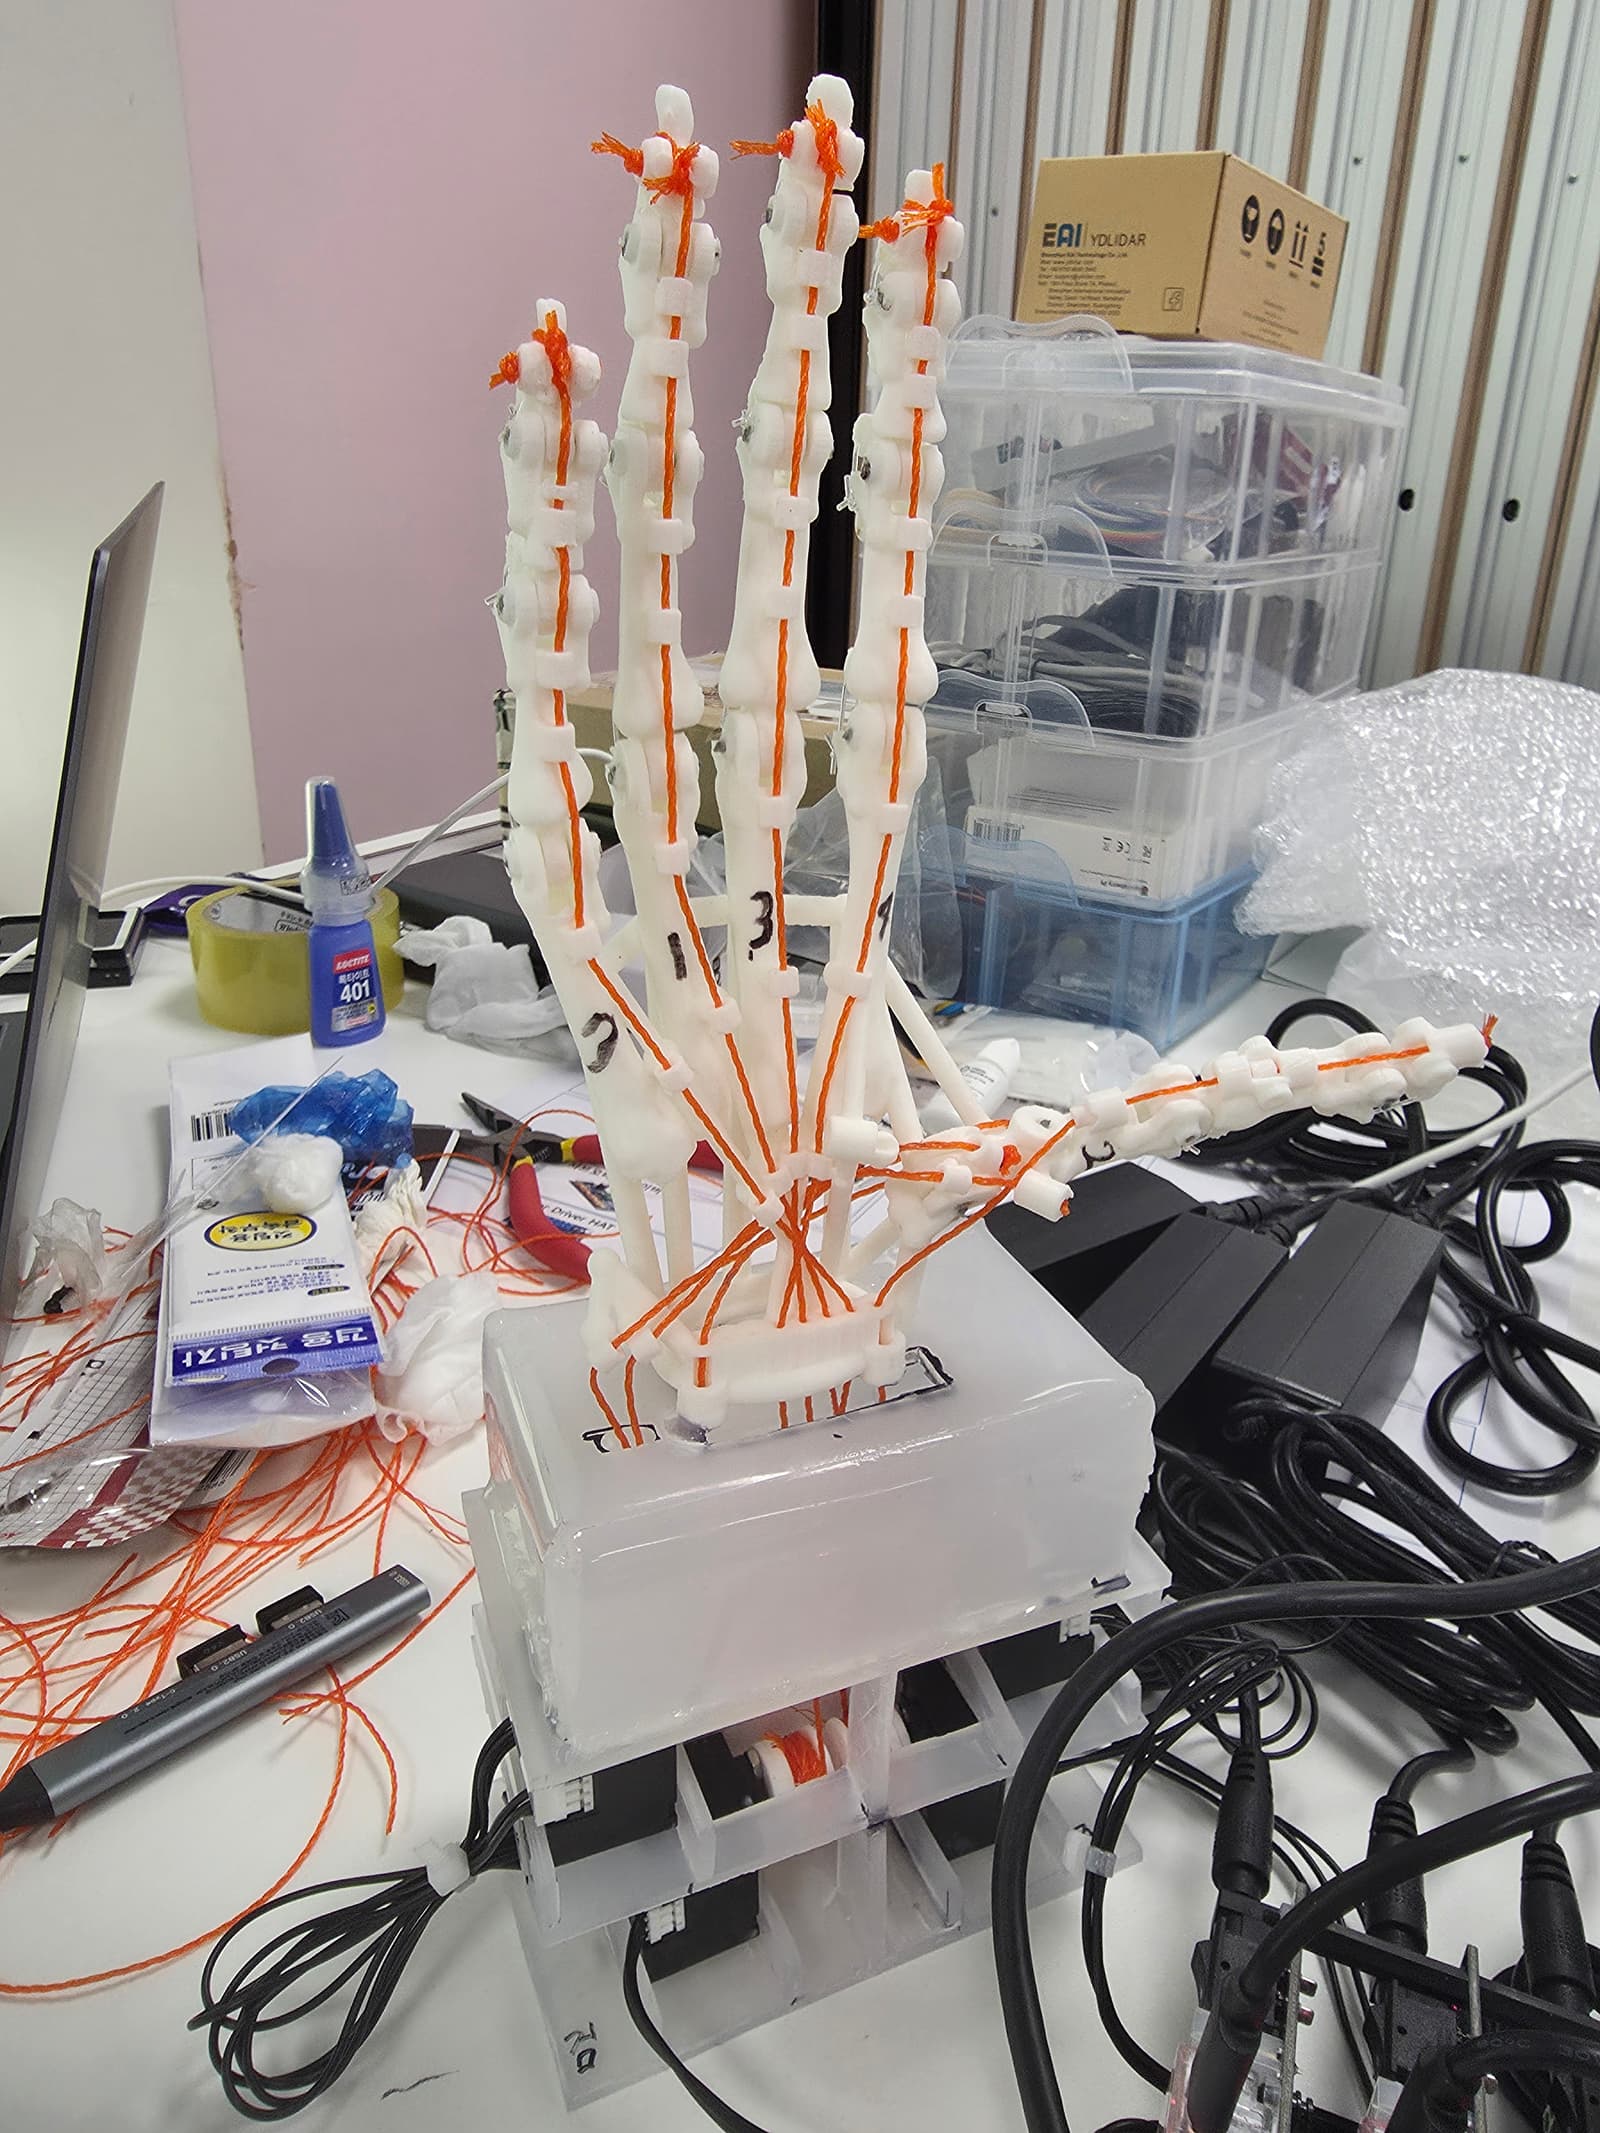 Other
A tendon-driven 7-axis robot hand that mimics the user's hand gestures in real time using MediaPipe vision and ROS 2.
Found by Robotheca in thing_ws/src/thing_control/package.xml (opens in a new tab)
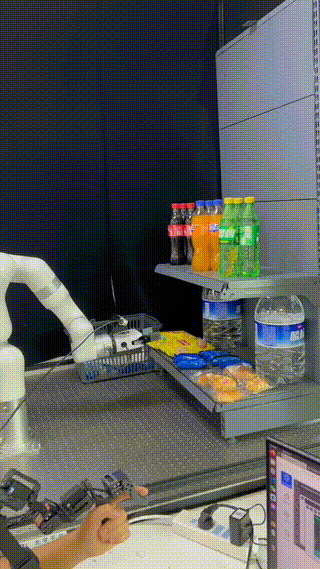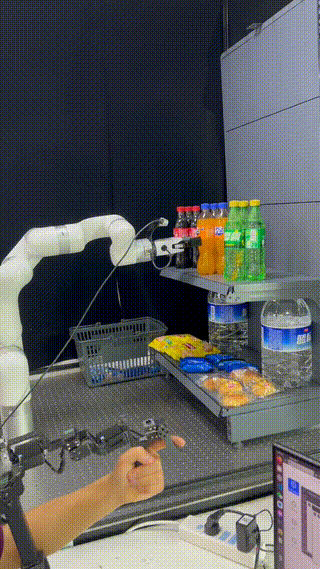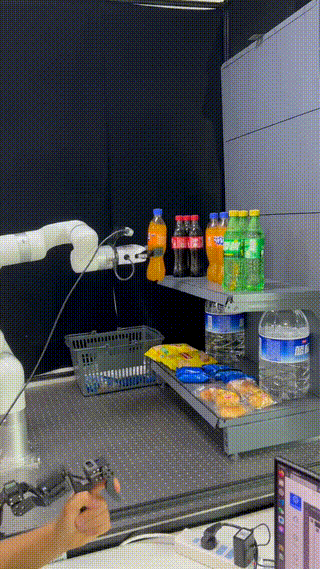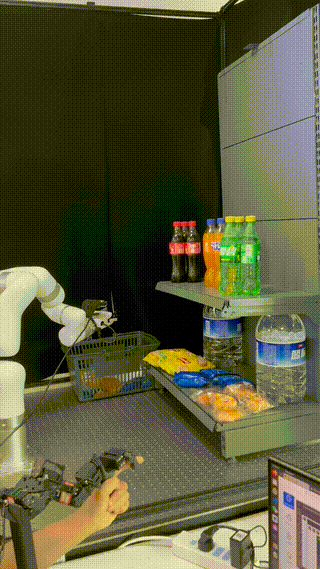 Robot arm
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
Found by Robotheca in src/simulation/mani_skill/examples/bimanual.openarm/ros2_ws/src/openarm_servo_teleop/package.xml (opens in a new tab)
A 3D printed quadrupedal robot with 4 limbs of 3 degrees of freedom each, built for locomotion research and reinforcement-learned walking.
Found by Robotheca in ros2/yertle_rl/package.xml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.