Little Red Rover
A minimal cost, maximal impact ROS 1 / ROS 2 mobile robot built for education.
- Wheeled
- Open source
- ROS 2
- 3D model (URDF)
Suggested by Robotheca, created by @little-red-rover (opens in a new tab), from github.com/little-red-rover/little-red-rover (opens in a new tab). Pinned to commit 1509a7a (opens in a new tab).
- Hardware license
- CERN-OHL-W-2.0 (opens in a new tab)
- Software license
- LGPL-2.1-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (3 files marked executable, 1 script)
- SOFTWARE/ros2_ws/tools/wifi_auth.bash (opens in a new tab)
- SOFTWARE/esp32_firmware/components/nanopb/generator-bin/nanopb_generator (opens in a new tab)
- SOFTWARE/esp32_firmware/components/nanopb/generator-bin/protoc (opens in a new tab)
- SOFTWARE/esp32_firmware/components/nanopb/generator-bin/protoc-gen-nanopb (opens in a new tab)
Photo and 3D model
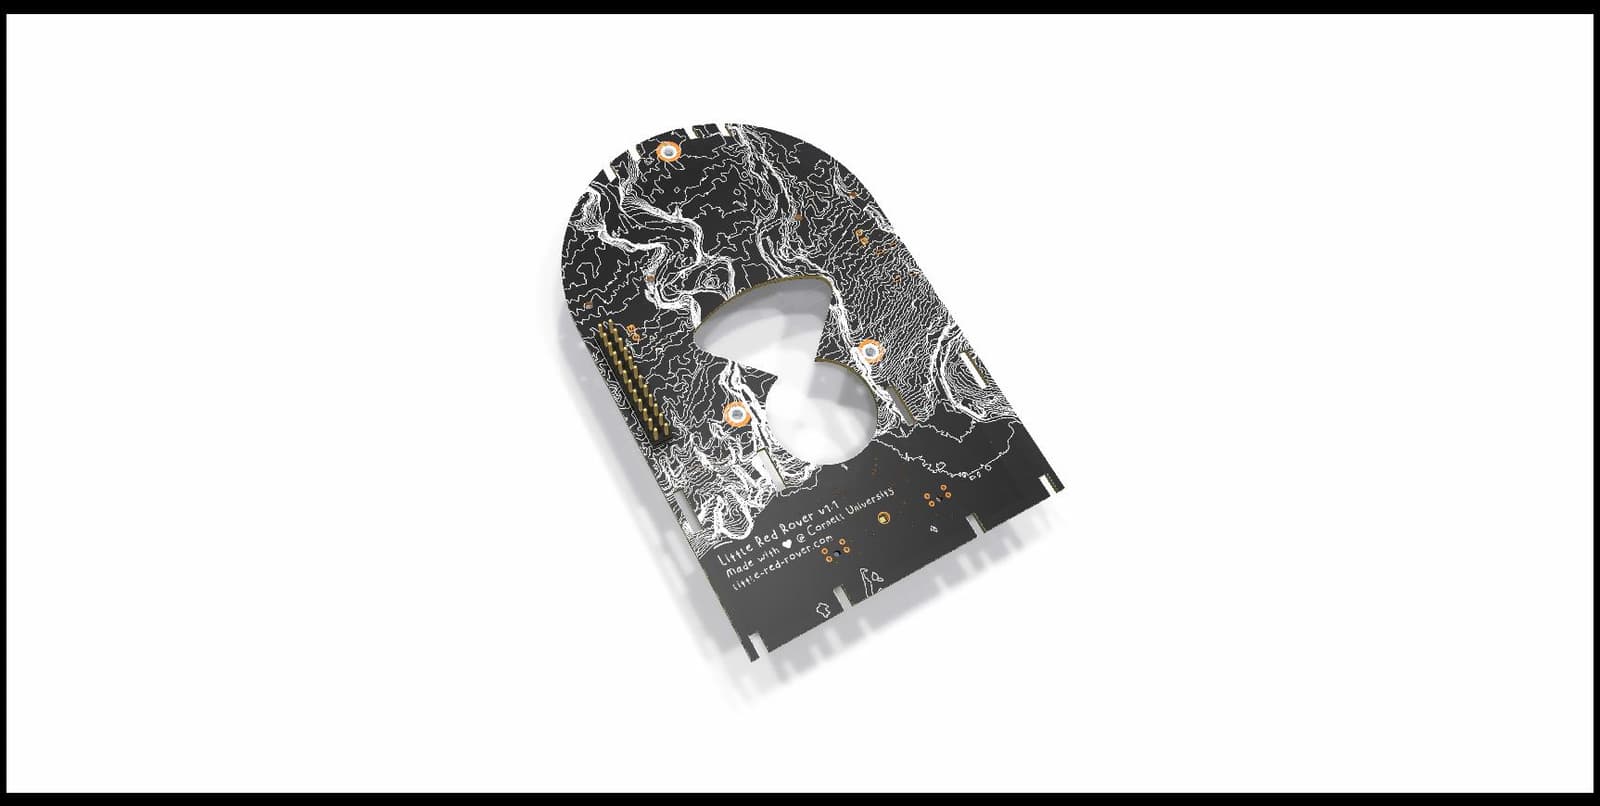
3D preview converted from github.com/little-red-rover/little-red-rover at 1509a7a, under CERN-OHL-W-2.0. View the original files from GitHub (2.4 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Differential drive ROS 2 robot intended as a low-cost research and learning platform.
- Carries a 2D LiDAR (LD20) for sensing its surroundings.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @little-red-rover (README.md), under CERN-OHL-W-2.0 (hardware) and LGPL-2.1-only (software).
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Custom PCB as the robot body, designed in KiCad.
- Two TT motors driving two wheels.
- One LD20 LiDAR.
Connections
- The documents do not describe how the motors, LiDAR and PCB are connected.