Just1
An open-source autonomous mecanum wheel robot for learning and experimentation that navigates manually or autonomously using a Lidar.
- Wheeled
- Open source
- ROS 2
Suggested by Robotheca, created by @NRdrgz (opens in a new tab), from github.com/NRdrgz/Just1 (opens in a new tab). Pinned to commit a00abd6 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
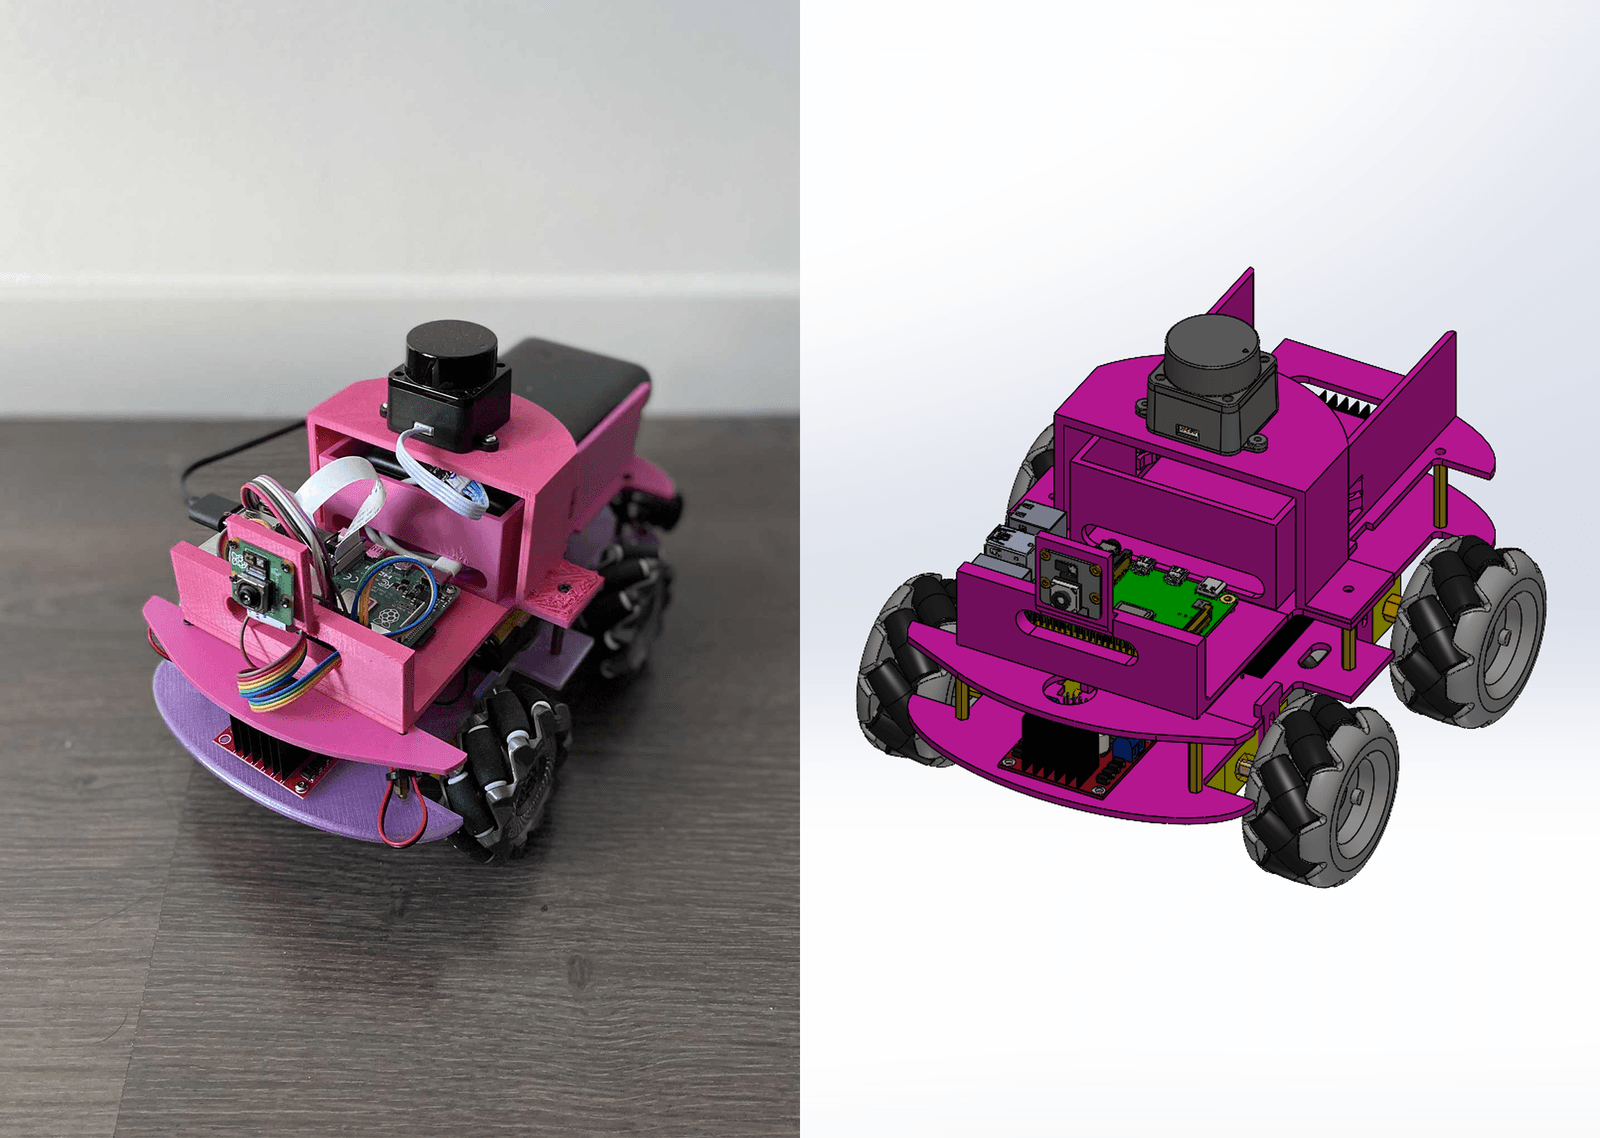
3D preview converted from github.com/NRdrgz/Just1 at a00abd6, under MIT. View the original files from GitHub (520 KB) (opens in a new tab)
- Payload
- 0.6 m
What it can do
Written by Robotheca from the project's documents.
- Navigates autonomously using Lidar-based obstacle avoidance and follows a path, with goals set from Foxglove
- Can also be driven manually with a gamepad (Nintendo Pro Controller)
- Uses SLAM (RTAB-Map) and Nav2 for mapping and navigation, with odometry from RTAB-Map
- Operates in complete darkness thanks to its Lidar
- Obstacles below 20cm are not detected due to Lidar position
- Reported maximum speeds: 0.6 m/s forward, 0.5 m/s sideways, 3.5 rad/s rotation (tested on flat indoor surface)
- Sensor feedback and monitoring available through Foxglove via WebSocket
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @NRdrgz (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi 4 (8GB) as control unit
- 4x Mecanum wheels driven by TT motors
- 2x L298N motor drivers
- LD19 2D Lidar
- MPU6050 IMU
- Raspberry Pi Camera Module 3 (optional)
- Power bank (5V 3A) powering the Pi
- 6x AA battery holder providing 9V for the motors
Connections
- Wiring diagrams are provided as images for motor driver connections and power distribution (WiringMotorDrivers.png and WiringPower.png); the pin-level details are not described in the text
- The 6x AA battery holder supplies motor power; the documents suggest the motors could instead be connected to the power bank through an appropriate adapter

