 Wheeled
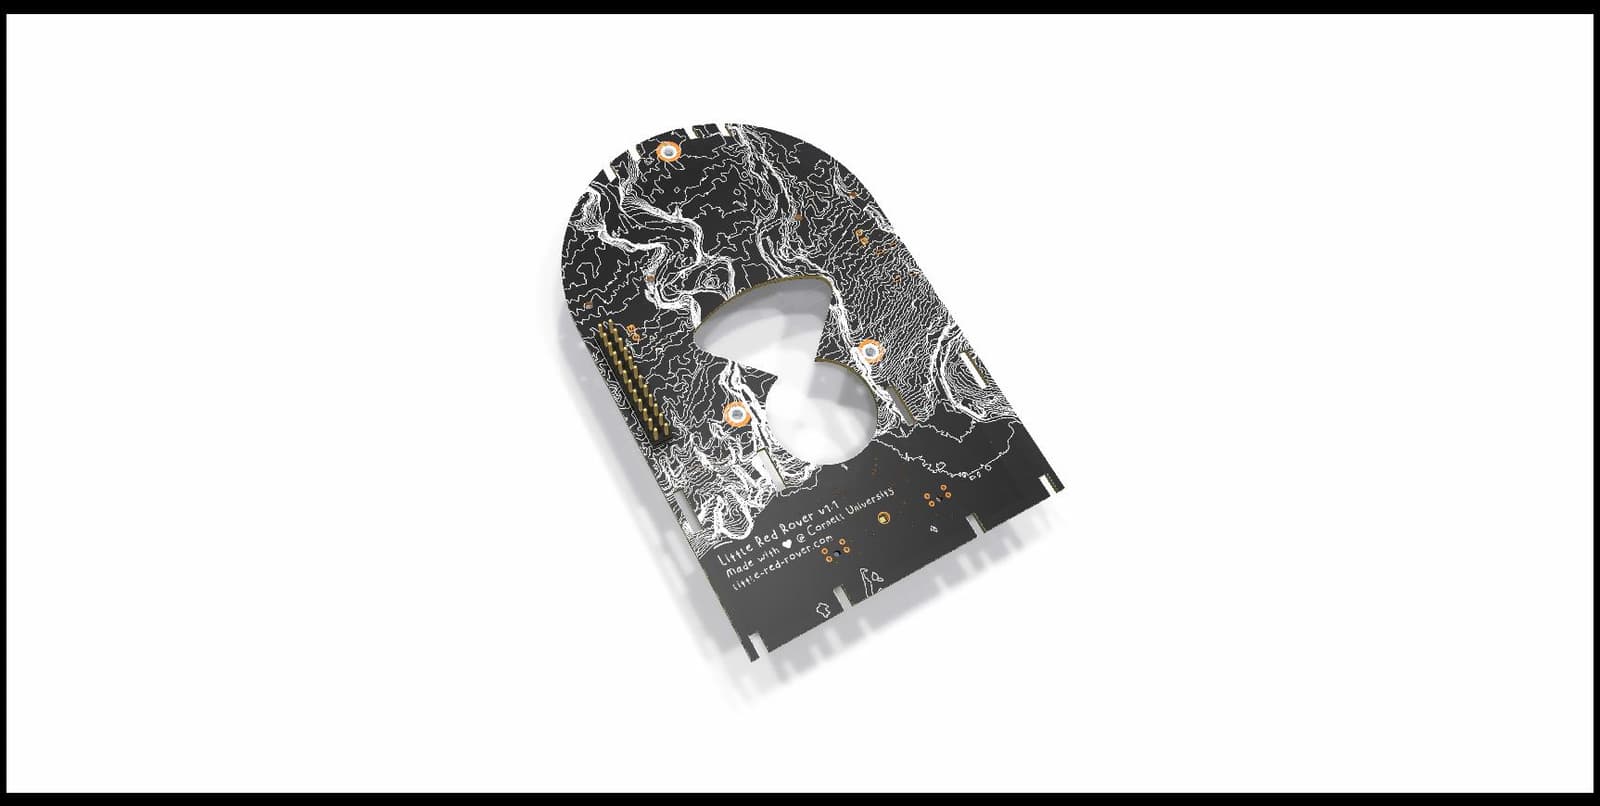
Little Red Rover
A minimal cost, maximal impact ROS 1 / ROS 2 mobile robot built for education.
- Level
- Intermediate
- Buildability
- 55/100
- Buildable with some effort
- Cost
- Not stated
A ROS 2 middleware plugin that lets ROS 2 use Eclipse Cyclone DDS as its underlying DDS implementation, with the aim of easy, fast and reliable communication.
Made by ROS 2.
Source on GitHub: github.com/ros2/rmw_cyclonedds (opens in a new tab). Facts read at commit f1bbef1 (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (Apache-2.0) at commit f1bbef1 (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit f1bbef1.
Checked on GitHub on 16 Oct 2026.
WheeledA minimal cost, maximal impact ROS 1 / ROS 2 mobile robot built for education.
Found by Robotheca in SOFTWARE/ros2_ws/src/little_red_rover/package.xml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.