ARMIKOCHAN V2 8-Axis Arm
An open-source 8-axis ROS2 robotic arm with 3D-printed planetary gears and FSR-based tactile gripper feedback.
- Robot arm
- Open source
- ROS 2
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @kairobyte (opens in a new tab), from github.com/kairobyte/armikochan (opens in a new tab). Pinned to commit bd9e2d4 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
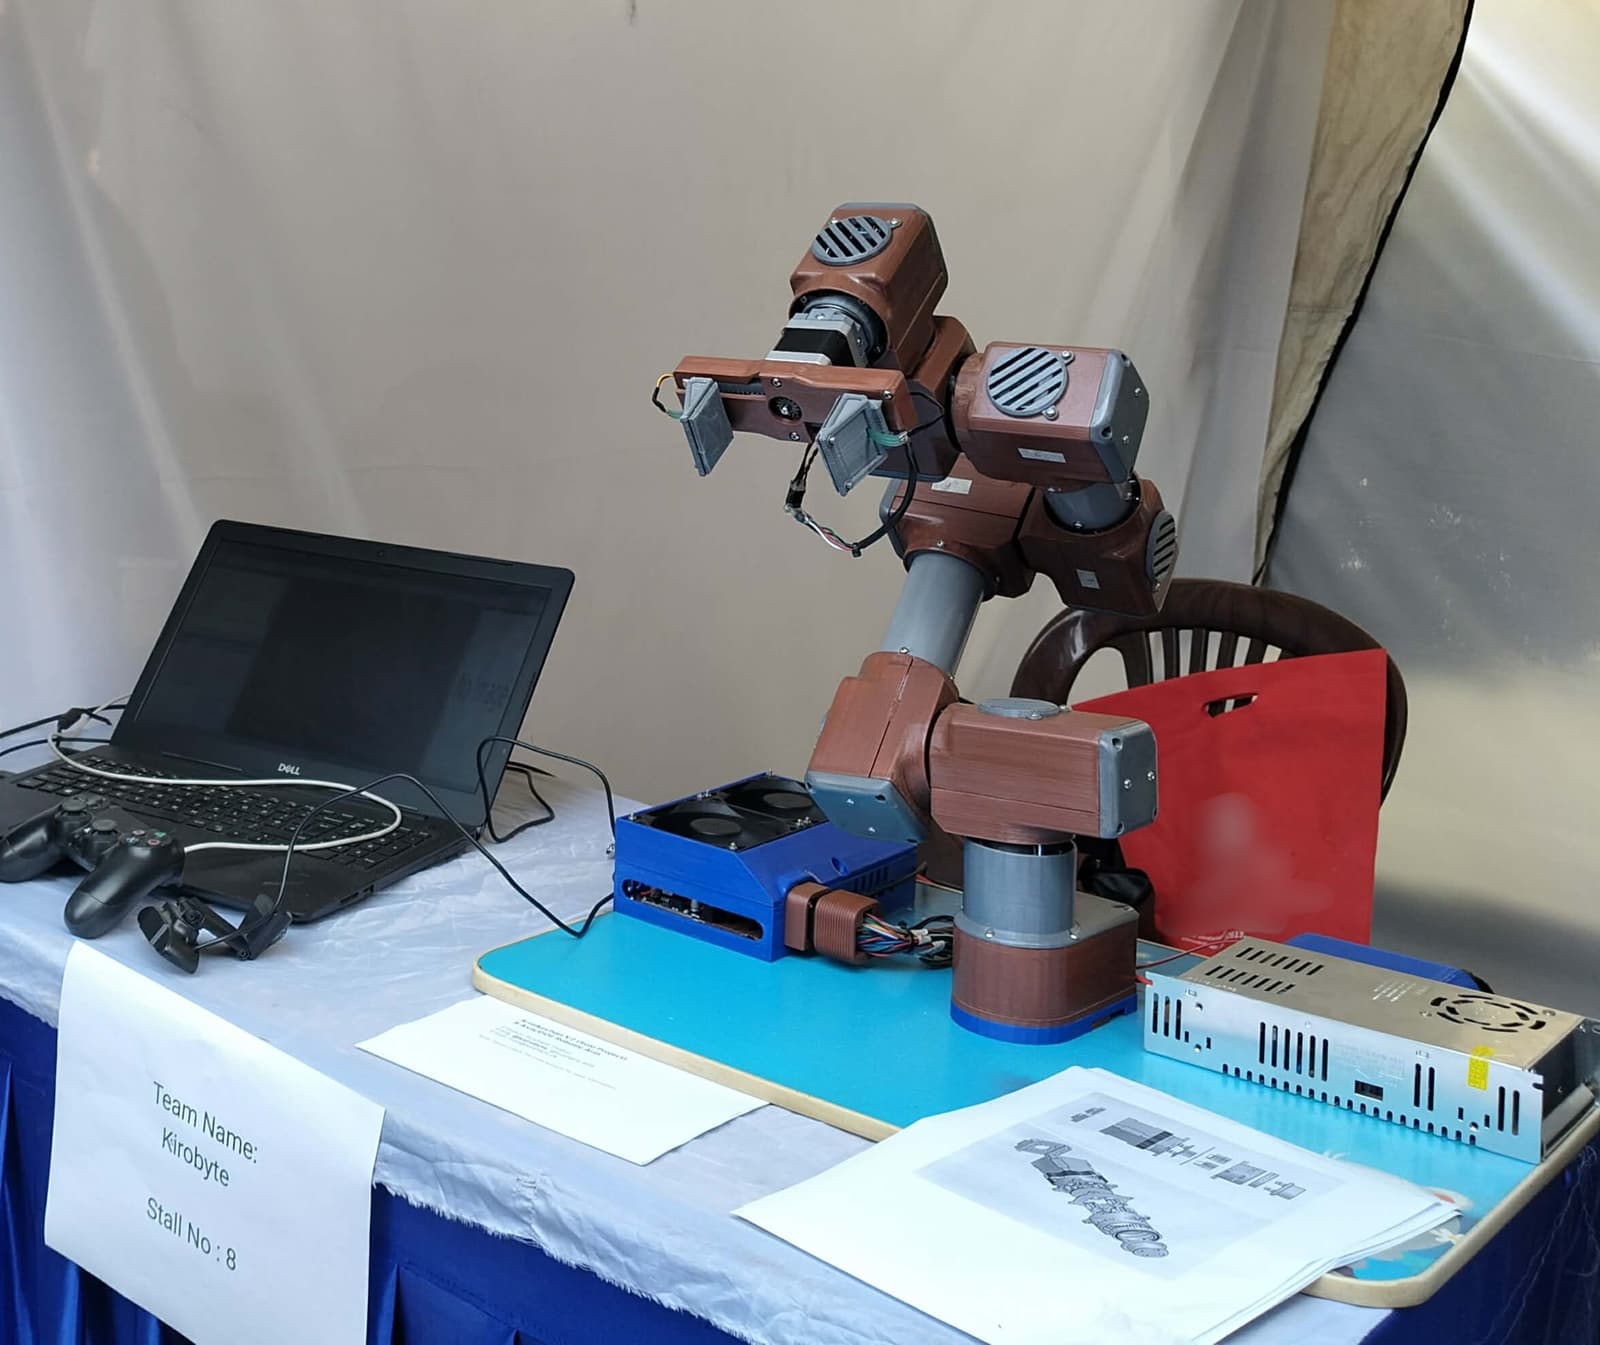
Try it in the browser
3D preview converted from github.com/kairobyte/armikochan at bd9e2d4, under MIT. View the original files from GitHub (12.7 MB) (opens in a new tab)
- Degrees of freedom
- 8
What it can do
Written by Robotheca from the project's documents.
- Eight-degree-of-freedom robotic arm designed for high-precision motion
- Real-time control via MoveIt2 and MoveIt Servo nodes in ROS2
- Gripper force feedback from force-sensitive resistors with a silicone layer
- Joint angle feedback from AS5600 magnetic encoders
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @kairobyte (README.md), under MIT.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32 microcontroller for low-latency motor driving and FSR sensor processing
- Raspberry Pi as an intermediate computer
- PC or laptop running ROS2 Jazzy on Ubuntu 24.04
- Nema 17 stepper motors with custom planetary gear sets
- Force-sensitive resistors (FSR) in the gripper
- AS5600 magnetic encoders for joint angles
Connections
- Control chain runs from PC or laptop to Raspberry Pi to ESP32
- Wires for actuators pass through the cavity inside the actuators