No photo yet
Robot armArduinobot
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
- Level
- Intermediate
- Buildability
- 50/100
- Buildable with some effort
- Cost
- Not stated
Packages for working with URDF, the XML format that describes robot models. Documentation is kept on the ROS wiki.
Made by ROS 2.
Source on GitHub: github.com/ros2/urdf (opens in a new tab). Facts read at commit 137cacc (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (BSD-3-Clause) at commit 137cacc (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 137cacc.
Checked on GitHub on 16 Oct 2026.
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
Found by Robotheca in arduinobot_description/package.xml (opens in a new tab)
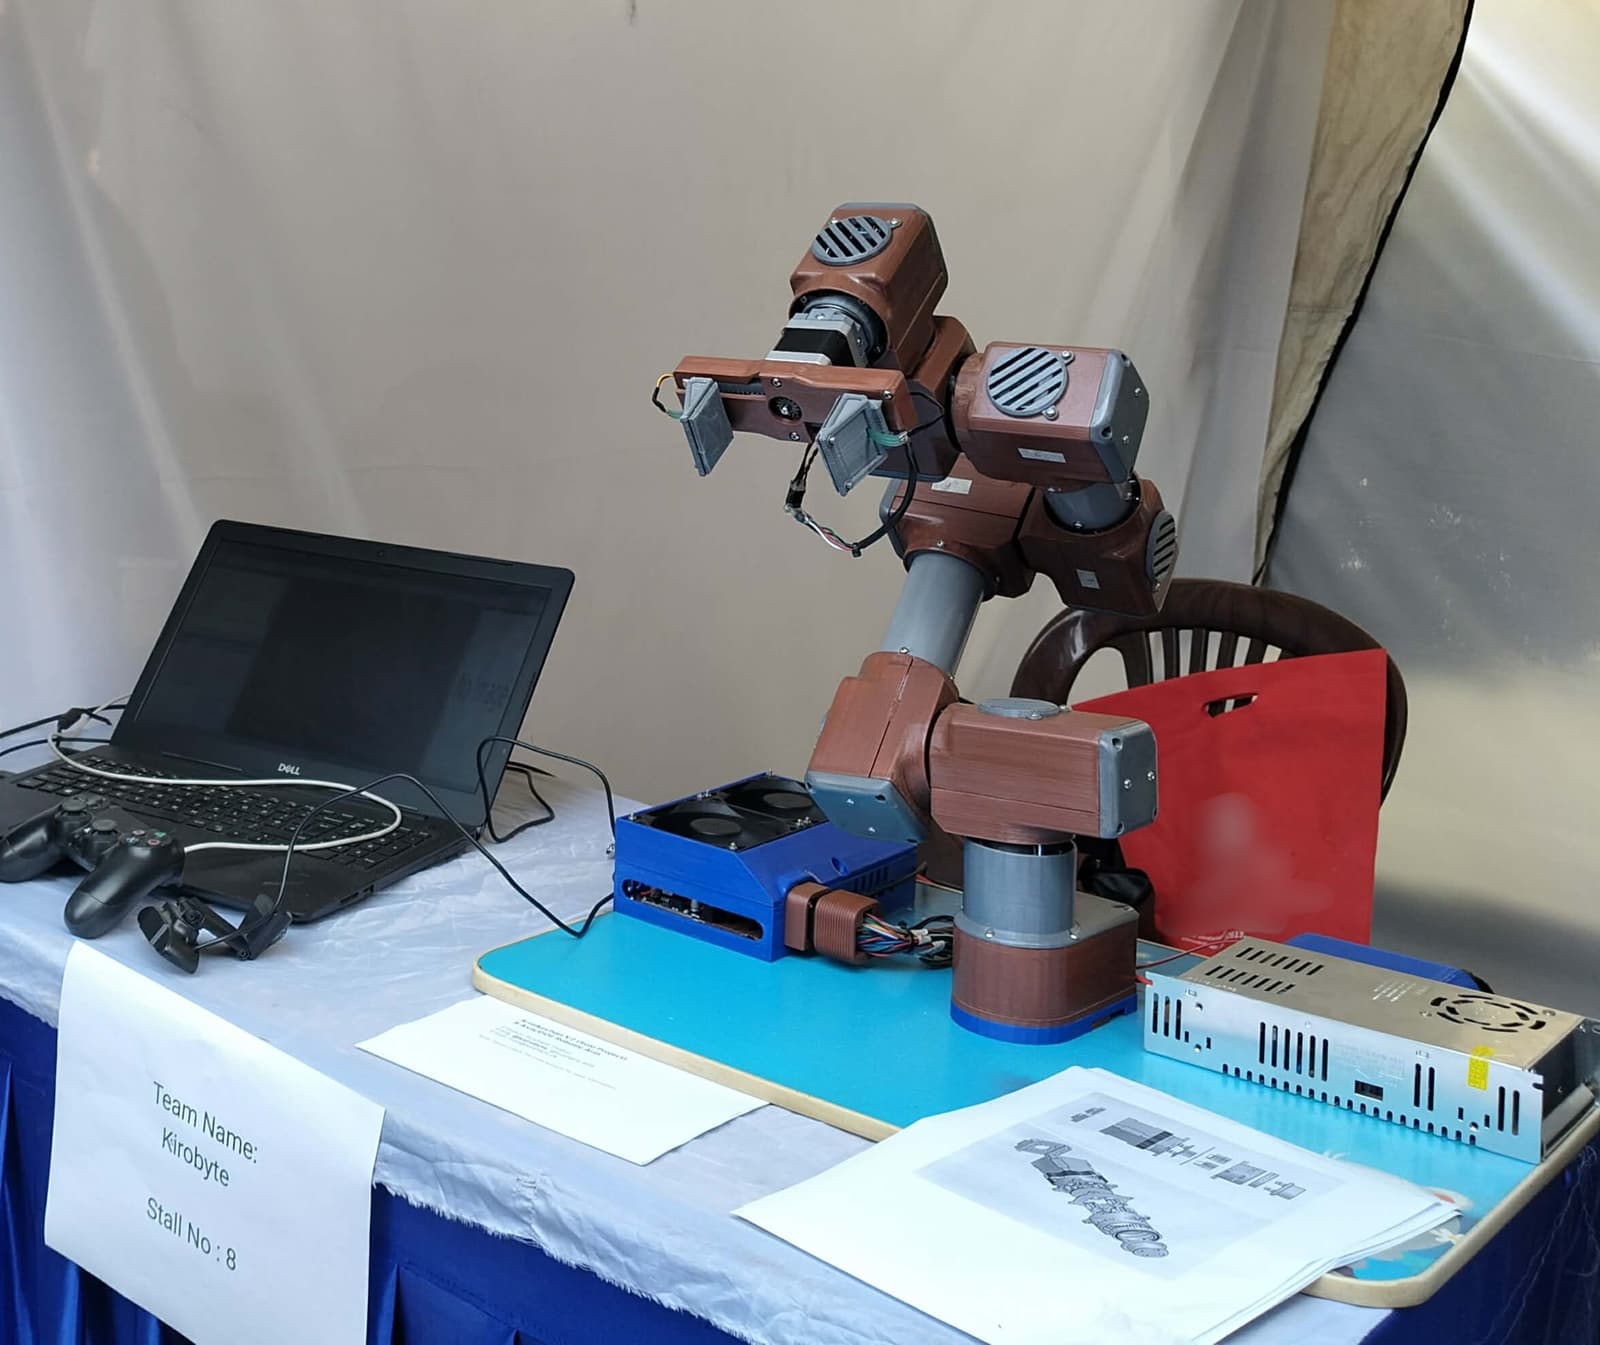 Robot arm
An open-source 8-axis ROS2 robotic arm with 3D-printed planetary gears and FSR-based tactile gripper feedback.
Found by Robotheca in 2. ros_ws/src/arm_description/package.xml (opens in a new tab)
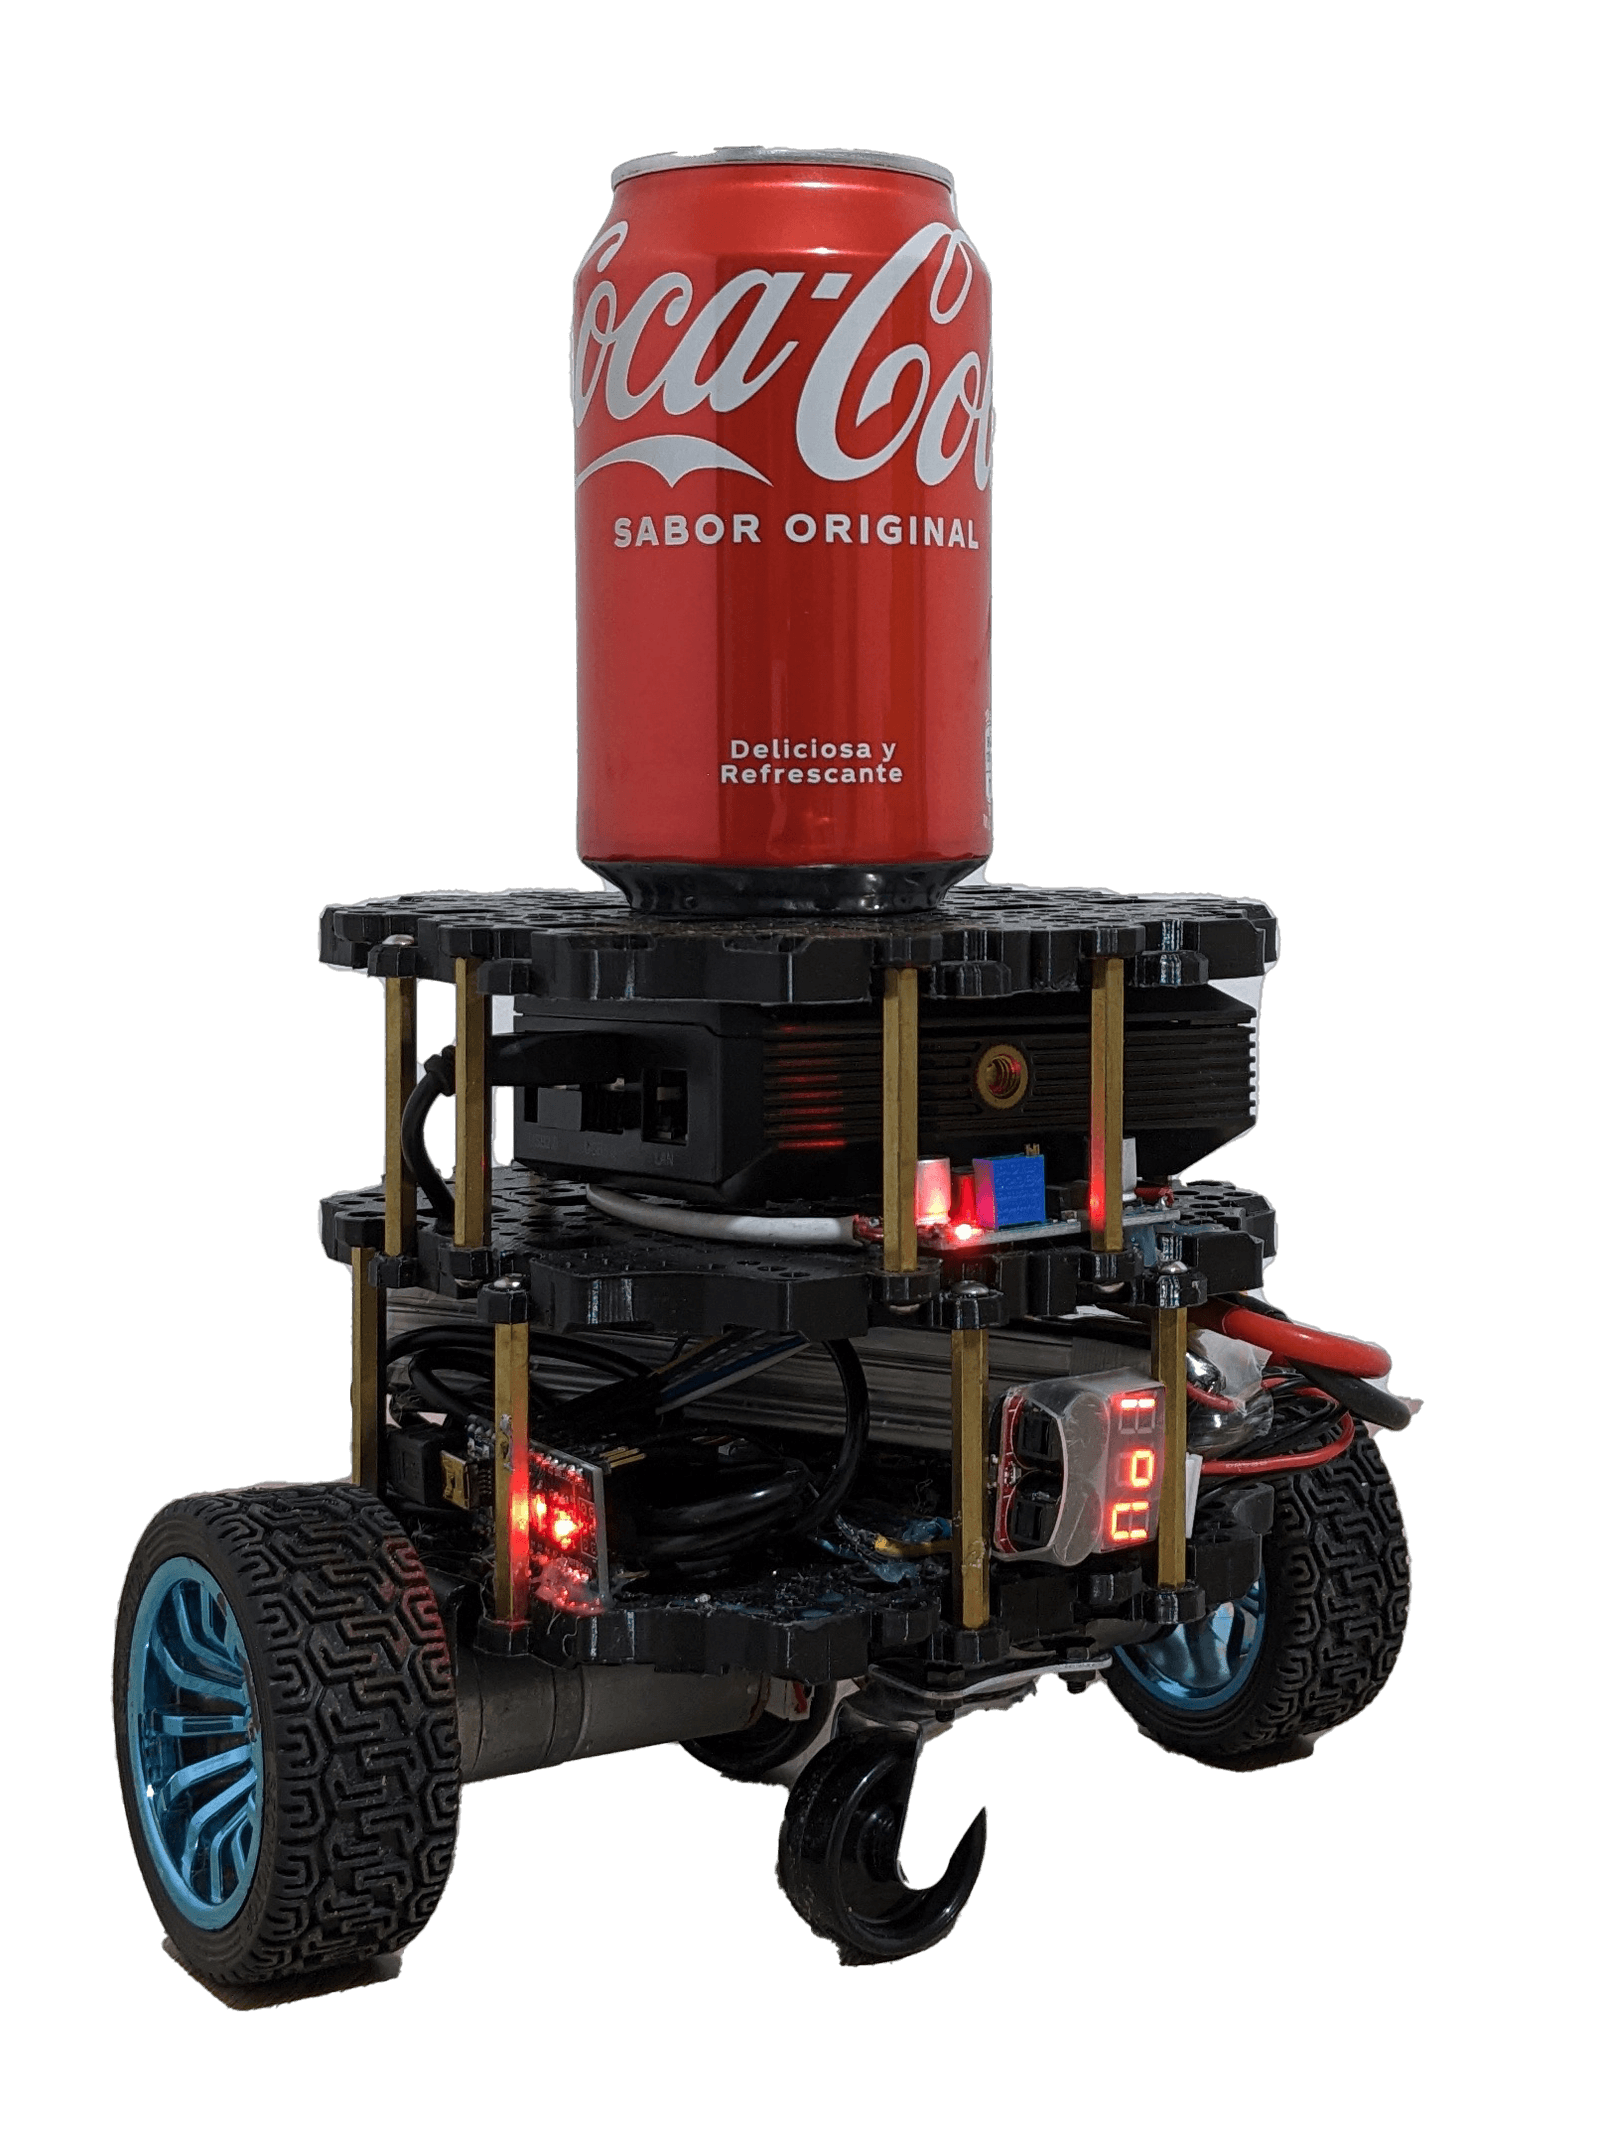 Wheeled
An open-source 3D printed self-driving robot powered by ROS 2, designed as a low-cost learning platform.
Found by Robotheca in bumperbot_description/CMakeLists.txt (opens in a new tab)
 Quadruped
D1 is an open-source quadruped robot project whose repository provides hardware resources such as mechanical models, manufacturing drawings, BOM and BMS resources.
Found by Robotheca in code/src/legged_hw/package.xml (opens in a new tab)
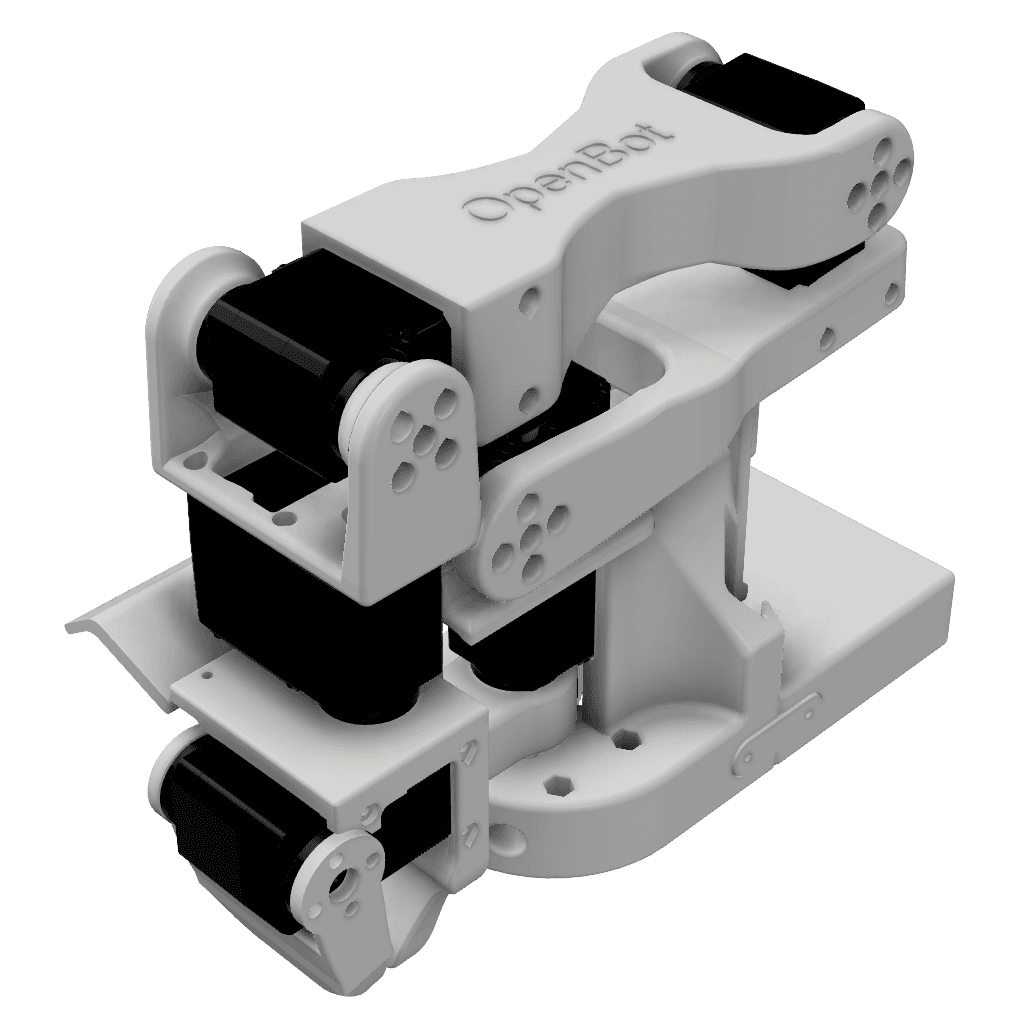 Robot arm
A cost-effective, ROS2-compatible 5-DoF robotic manipulator with a leader-follower teleoperation setup, designed to lower the barrier to entry for Embodied AI.
Found by Robotheca in giraffe_ws/src/giraffe_description/CMakeLists.txt (opens in a new tab)
A 200mm 3D-printed DIY home pet robot that maps rooms with a 360-degree laser distance sensor and drives autonomously, compatible with the Kaia.ai platform.
Found by Robotheca in CMakeLists.txt (opens in a new tab)
A 300mm round, 3D-printed DIY pet robot that maps rooms with a laser distance sensor and navigates autonomously using the Kaia.ai platform.
Found by Robotheca in CMakeLists.txt (opens in a new tab)
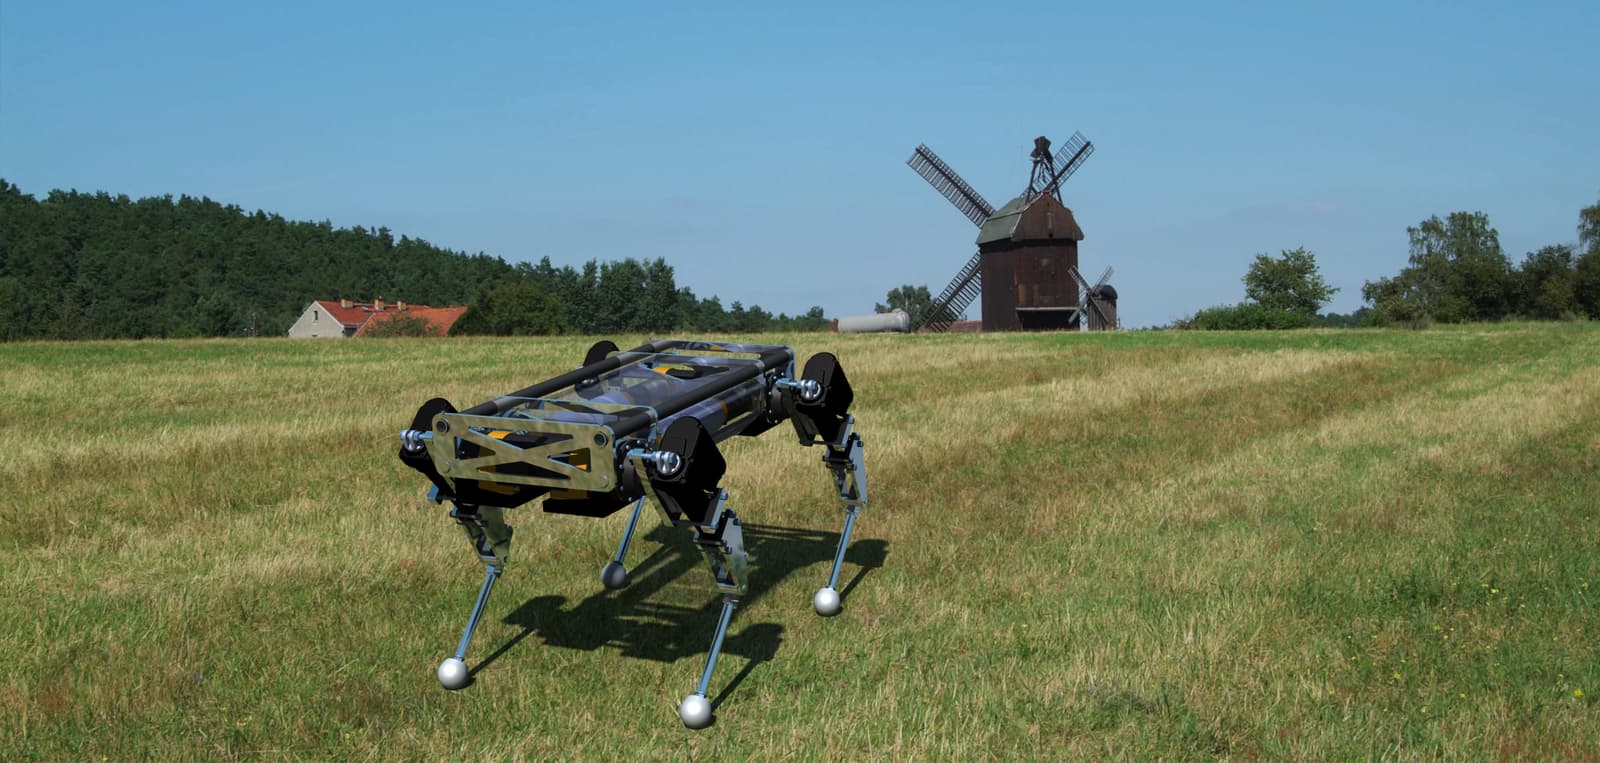 Quadruped
POPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
Found by Robotheca in popi_software/popi/popi_control/package.xml (opens in a new tab)
A ROS-based two-wheeled mobile robot with a lidar that can map and navigate indoors, with an open-source Gazebo simulation.
Found by Robotheca in ROS/rur_description/package.xml (opens in a new tab)
An open source six degree of freedom industrial robot arm that can hold 2kg at 80cm.
Found by Robotheca in ROSPackage/package.xml (opens in a new tab)
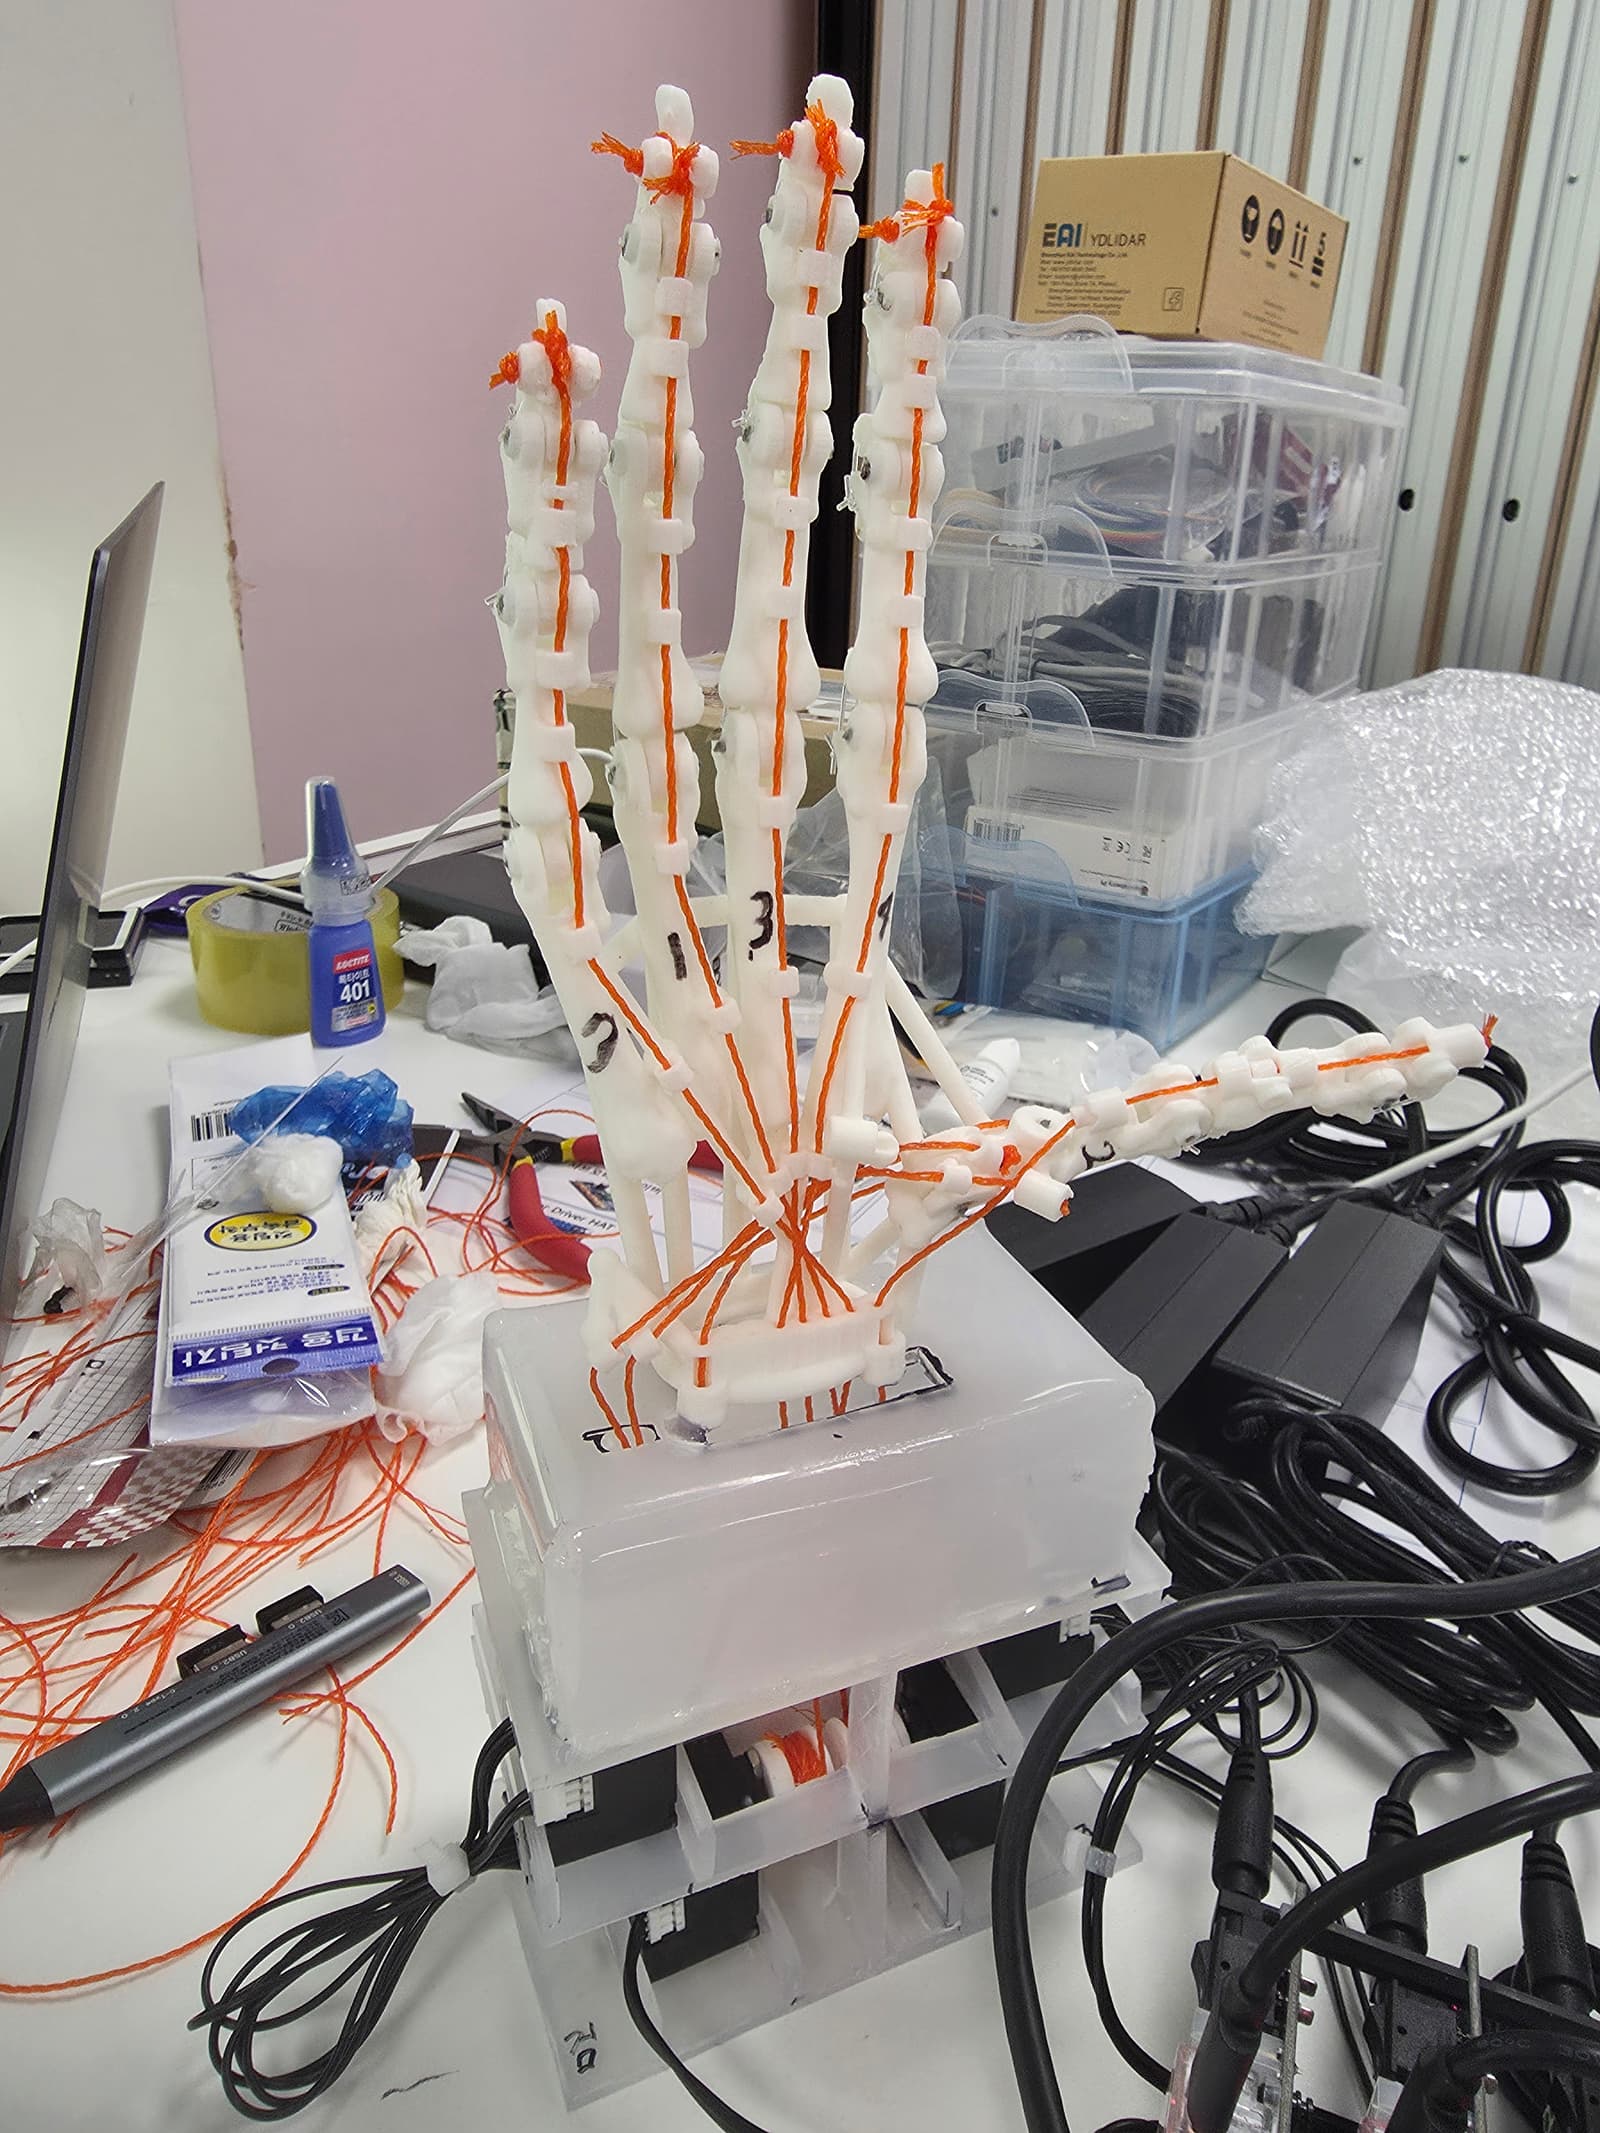 Other
A tendon-driven 7-axis robot hand that mimics the user's hand gestures in real time using MediaPipe vision and ROS 2.
Found by Robotheca in thing_ws/src/thing_description/package.xml (opens in a new tab)
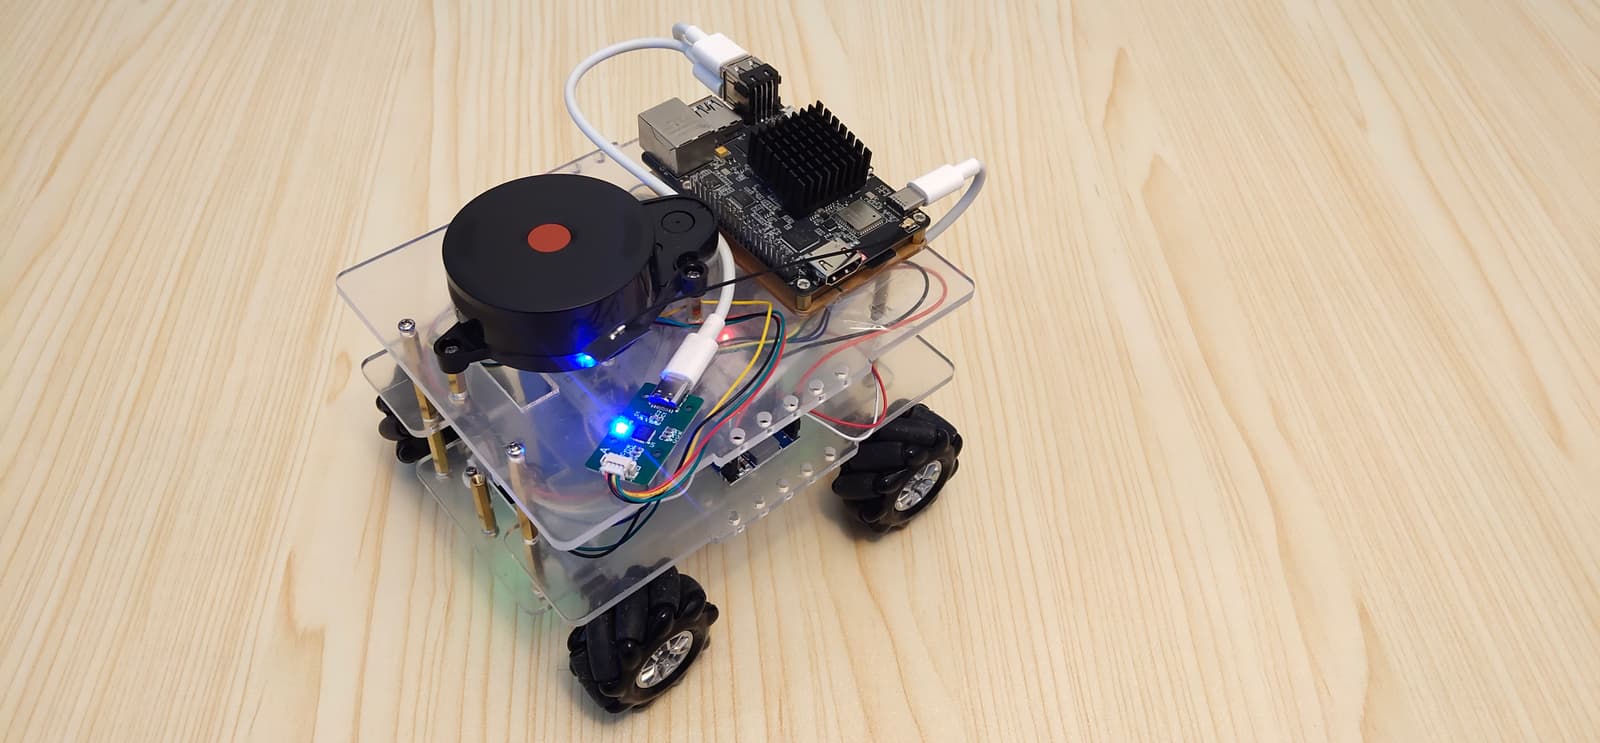 Wheeled
A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
Found by Robotheca in ros2_packages/robot_description/CMakeLists.txt (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.