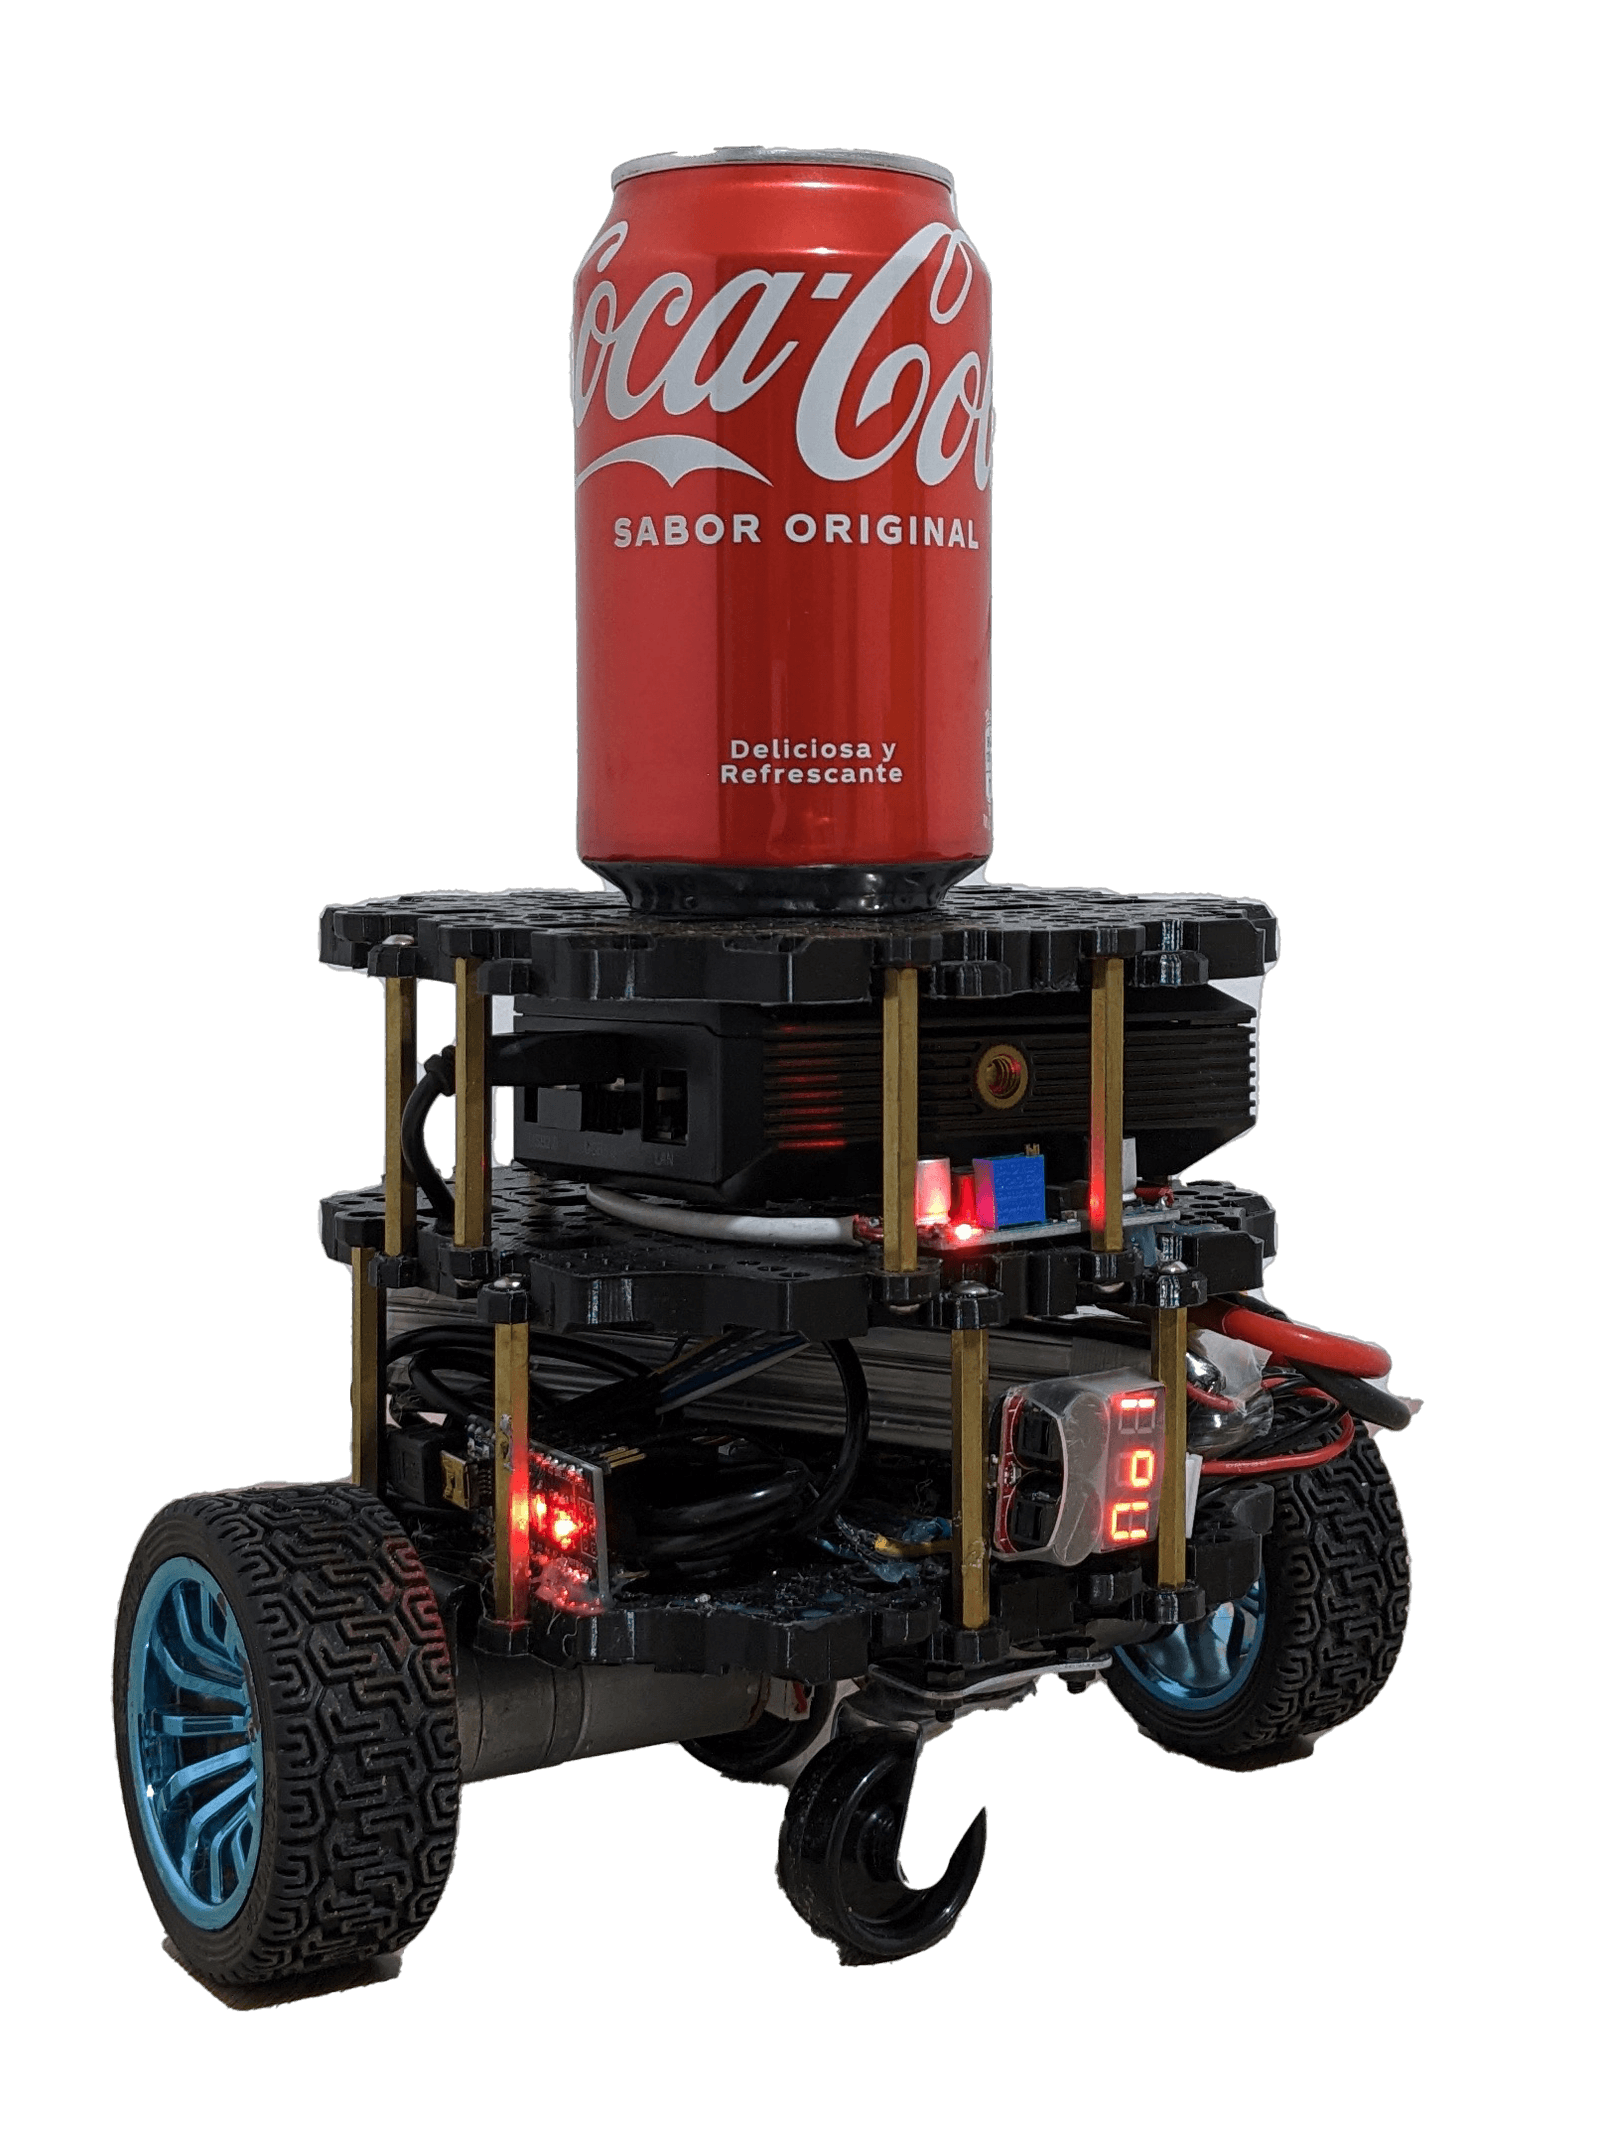
Open source · free files
Bumperbot
Wheeled · Intermediate
- Score
- Buildability 71 out of 100
- Cost
- Not stated
Software
By ROS device drivers, from github.com/ros-drivers/joystick_drivers (opens in a new tab)
A set of ROS nodes that read joystick inputs and publish them as ROS messages, converting them from the underlying operating system's input messages.
Checked on GitHub on 6 Nov 2026.
No license at the repository's root: each package carries its own. Read the license of each package you use.
No license file at the repository's root at commit 50bcf0f (opens in a new tab), on 16 Oct 2026.
Each package has its own licence file (joy, joy_linux, ps3joy, spacenav BSD-3-Clause; sdl2_vendor Apache-2.0; wiimote GPL-2.0), except wiimote_msgs: only its package.xml says BSD.
Written by Robotheca from the project's README (opens in a new tab) at commit 50bcf0f, not by its creator.
Robotheca never hosts the code: each link goes to the creator's own page.
The robots on Robotheca that use it or can run it, each with how the link was found.
Open source · free files
Wheeled · Intermediate
Found by Robotheca in bumperbot_controller/package.xml (opens in a new tab)
 3D render
Found by Robotheca in el_a3_ros/el_a3_teleop/package.xml (opens in a new tab)
 3D render
Open source · free files
Robot arm · Intermediate
Found by Robotheca in ros2/miniarm_servo/package.xml (opens in a new tab)
Open source · free files
Quadruped · Advanced
Found by Robotheca in ros-workspace/src/open_quadruped/package.xml (opens in a new tab)
Found by Robotheca in popi_software/popi/popi_robot/package.xml (opens in a new tab)
How to install it, in the creator's words: The project's README (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.