Open Quadruped
An open-source 3D-printed quadrupedal robot that performs gait generation with Bezier curves and full 6-axis body pose control.
- Quadruped
- Open source
- ROS
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @adham-elarabawy (opens in a new tab), from github.com/adham-elarabawy/open-quadruped (opens in a new tab). Pinned to commit b0ab4fa (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
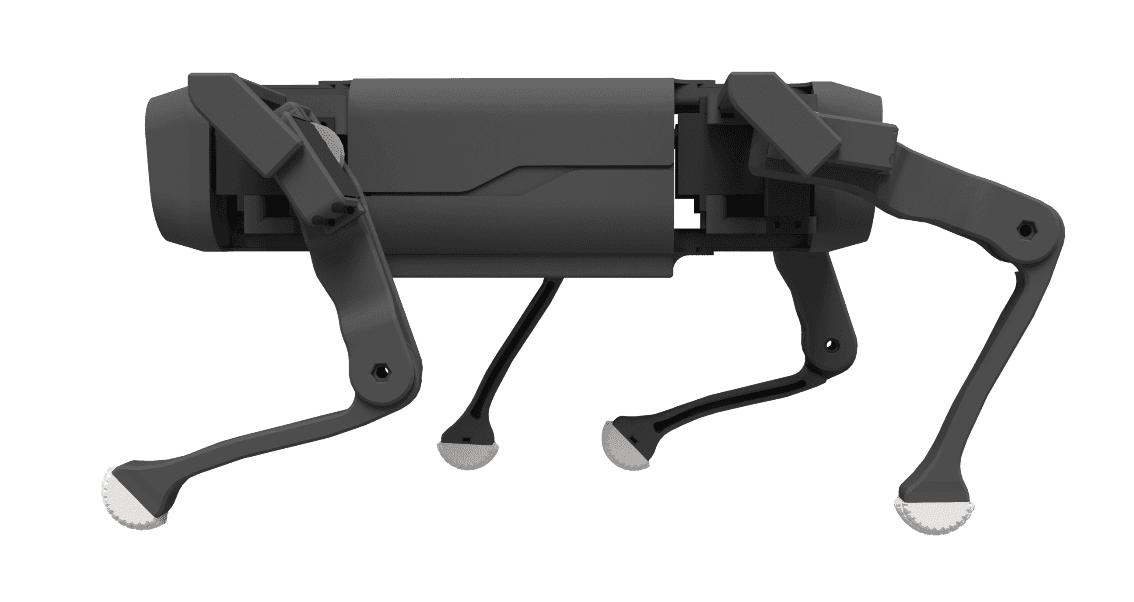
Try it in the browser
3D preview converted from github.com/adham-elarabawy/open-quadruped at b0ab4fa, under MIT. View the original files from GitHub (19.0 MB) (opens in a new tab)
- Degrees of freedom
- 12
What it can do
Written by Robotheca from the project's documents.
- Open-source 3D-printed quadrupedal robot with intuitive gait generation through 12-DOF Bezier curves.
- Full 6-axis body pose manipulation.
- Custom 3DOF leg inverse kinematics model accounting for offsets.
- Simulation available in Gazebo, plus a custom matplotlib visualization tool that is noted as likely broken for now.
- Gazebo and RViz visualization via ROS are mentioned.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @adham-elarabawy (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Custom PCB that controls the position and speed of 12 servos simultaneously and interfaces with all sensors.
- Servos (12 total) serving as the robot's actuators.
- Sensors connected to the custom PCB; a force-sensitive leg test is shown in demos.
Connections
- Wiring is described only in a wiring diagram image (media/wiring_diagram.png); the text documents do not explain the connections.
