Sesame Robot
An open and affordable ESP32-based mini quadruped robot with an OLED face that walks, waves and dances.
- Quadruped
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @dorianborian (opens in a new tab), from github.com/dorianborian/sesame-robot (opens in a new tab). Pinned to commit d106cbc (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
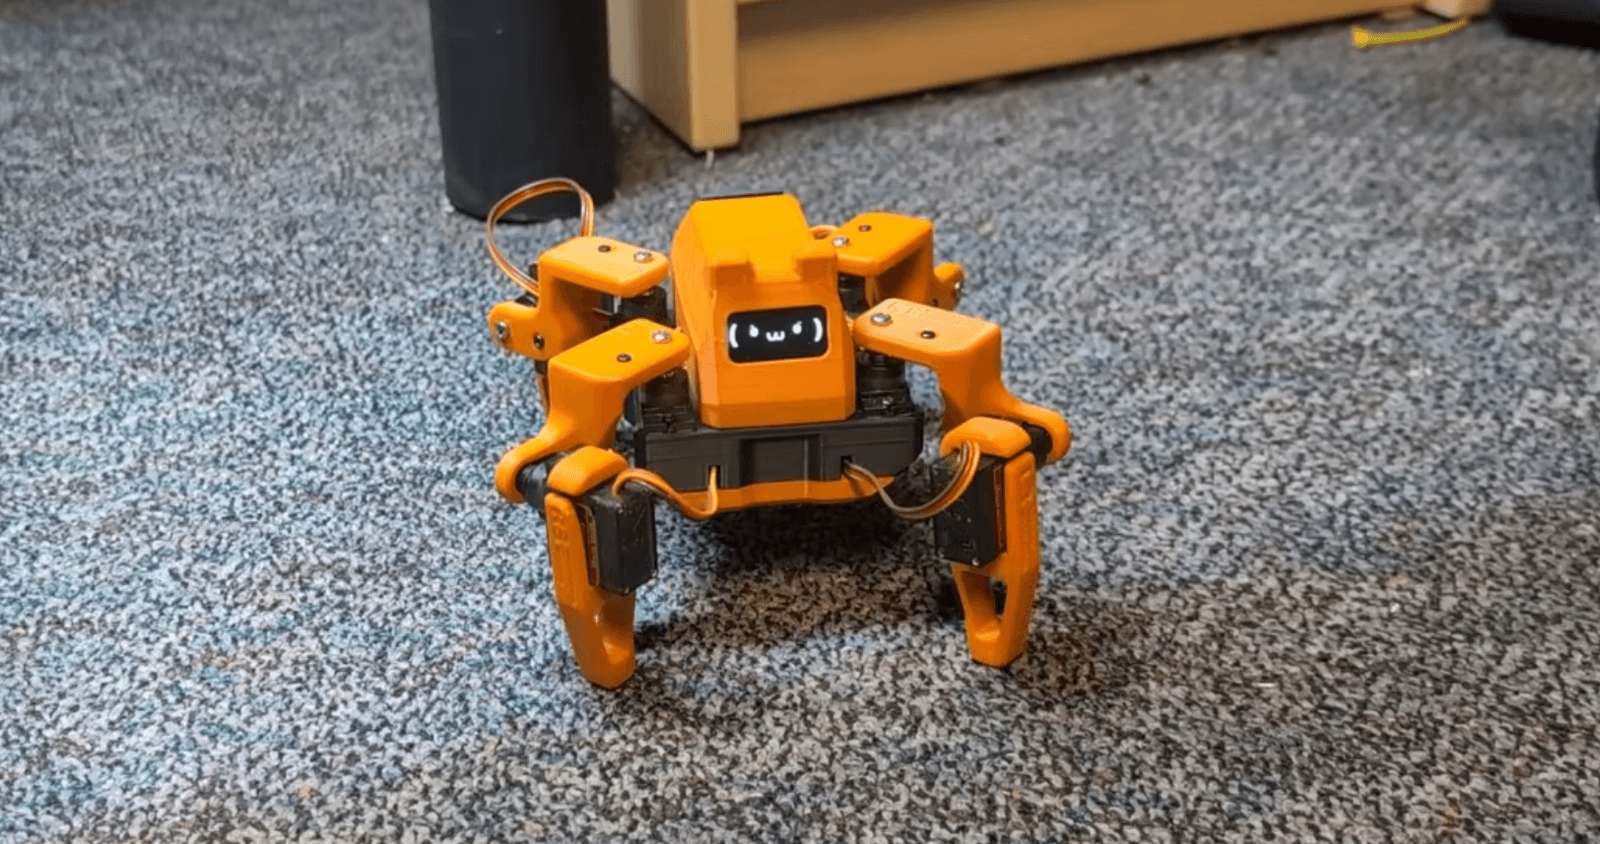
3D preview converted from github.com/dorianborian/sesame-robot at d106cbc, under Apache-2.0. View the original files from GitHub (3.0 MB) (opens in a new tab)
- Power
- 5 V
What it can do
Written by Robotheca from the project's documents.
- Walks as a quadruped using 8 servo motors, two per leg, for roughly 8 degrees of freedom
- Shows an emotive face on a 128x64 OLED screen that syncs with movement
- Runs a built-in web UI and JSON API over its own Wi-Fi access point or local network
- Plays pre-programmed emotes such as walking, waving, dancing, pointing and resting
- Can be controlled through a serial command line interface or the web portal
Bill of materials
22 parts22 of 22 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | 22nF | 3 | – | LCSC |
| 2 | 100nF | 3 | – | LCSC |
| 3 | 10nF | 1 | – | LCSC |
| 4 | 3.3uH | 1 | – | LCSC |
| 5 | KT-0603R | 1 | – | LCSC |
| 6 | 5.1kΩ | 2 | – | LCSC |
| 7 | 56kΩ | 1 | – | LCSC |
| 8 | 10kΩ | 4 | – | LCSC |
| 9 | 3.5MM-2PIN | 1 | – | LCSC |
| 10 | B4B-XH-A(LF)(SN) | 1 | – | LCSC |
| 11 | HX 3X4X2-2P-1.6N TACTILE SWITCH | 2 | – | LCSC |
| 12 | SolderPad (No Part Required) | 2 | – | – |
| 13 | 1uF | 1 | – | LCSC |
| 14 | 470uF | 1 | – | LCSC |
| 15 | SS34_C8678 | 2 | – | LCSC |
| 16 | 3PIN MALE HEADER | 8 | – | LCSC |
| 17 | ESP32-S3-WROOM-1(N16R8) | 1 | – | LCSC |
| 18 | AMS1117-3.3 | 1 | – | LCSC |
| 19 | MSTPS563200DDCR | 1 | – | LCSC |
| 20 | 10uF | 1 | – | LCSC |
| 21 | EXPANSION HEADER (No Part Required) | 1 | – | – |
| 22 | TYPE-C-31-M-12 | 1 | – | LCSC |
22 of 22 parts have no price in the source, so there is no parts total. Read from hardware/pcb/distro-v2/BOM_Sesame-Distro-V2.csv at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Gather parts from the bill of materials
- 2Print parts in PLA
- 3Build the frame and wire the electronics
- 4Flash the firmware via Arduino IDE
- 5Create animations with Sesame Studio
The guide appears here as you scroll.
Guide by @dorianborian (README.md), under Apache-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-based controller, such as a Lolin S2 Mini or the Sesame Distro Board
- 8x MG90 180-degree servo motors
- 128x64 OLED display
- Power from USB-C PD (5V 3A) or a battery with buck converter
- Optional Bambu Lab 14500 Li-ion battery pack with rocker switch
Connections
- Servo signal leads run to the controller data pins, with 30AWG wire for data lines and 22AWG wire for power and ground
- Shared 5V rail and ground rail are built on a protoboard for hand-wired builds
- OLED connects to the controller via its SDA and SCL lines
- Battery leads solder to battery pads on the main board, and the Distro Board uses a screw terminal for battery input
- Motor connectors plug into numbered headers, with the brown wire aligned to the ground rail
Schematics, boards and diagrams
- docs/build-guide/assets/top-cover-wiring.pngDiagram
- docs/wiring-guide/distro-board-wiring-guide.pngDiagram
- docs/wiring-guide/s2-mini-wiring-guide-new.pngDiagram
- hardware/pcb/distro-v1/Gerber_Sesame-Distro-Board_PCB_Sesame-Distro-Board_V1.zipGerber (PCB manufacturing)
- hardware/pcb/distro-v1/Schematic_Sesame-Distro-Board.pngDiagram
- hardware/pcb/distro-v2/Gerber_Sesame-Distro-V2_PCB.zipGerber (PCB manufacturing)
- hardware/pcb/distro-v3.1/assets/Schematic_Sesame-Distro-Board-V3_2026-05-30.pngDiagram
- hardware/pcb/distro-v3.1/assets/Schematic_Sesame-Distro-Board-V3.1.pngDiagram
- hardware/pcb/distro-v3.1/Gerber_Sesame-Distro-Board-V3.1.zipGerber (PCB manufacturing)


