No photo yet
Robot armArduinobot
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
- Level
- Intermediate
- Buildability
- 50/100
- Buildable with some effort
- Cost
- Not stated
A ROS 2 Python library that provides the rotation and quaternion conversion functions of ROS 1's tf transformations module, so existing code can be ported with a small import change.
Source on GitHub: github.com/DLu/tf_transformations (opens in a new tab). Facts read at commit 457aa9b (opens in a new tab).
Read by Robotheca from LICENSE (opens in a new tab) (BSD-3-Clause) at commit 457aa9b (opens in a new tab), on 16 Oct 2026.
Written by Robotheca from the project's README (opens in a new tab) at commit 457aa9b.
Checked on GitHub on 16 Oct 2026.
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
Found by Robotheca in arduinobot_utils/package.xml (opens in a new tab)
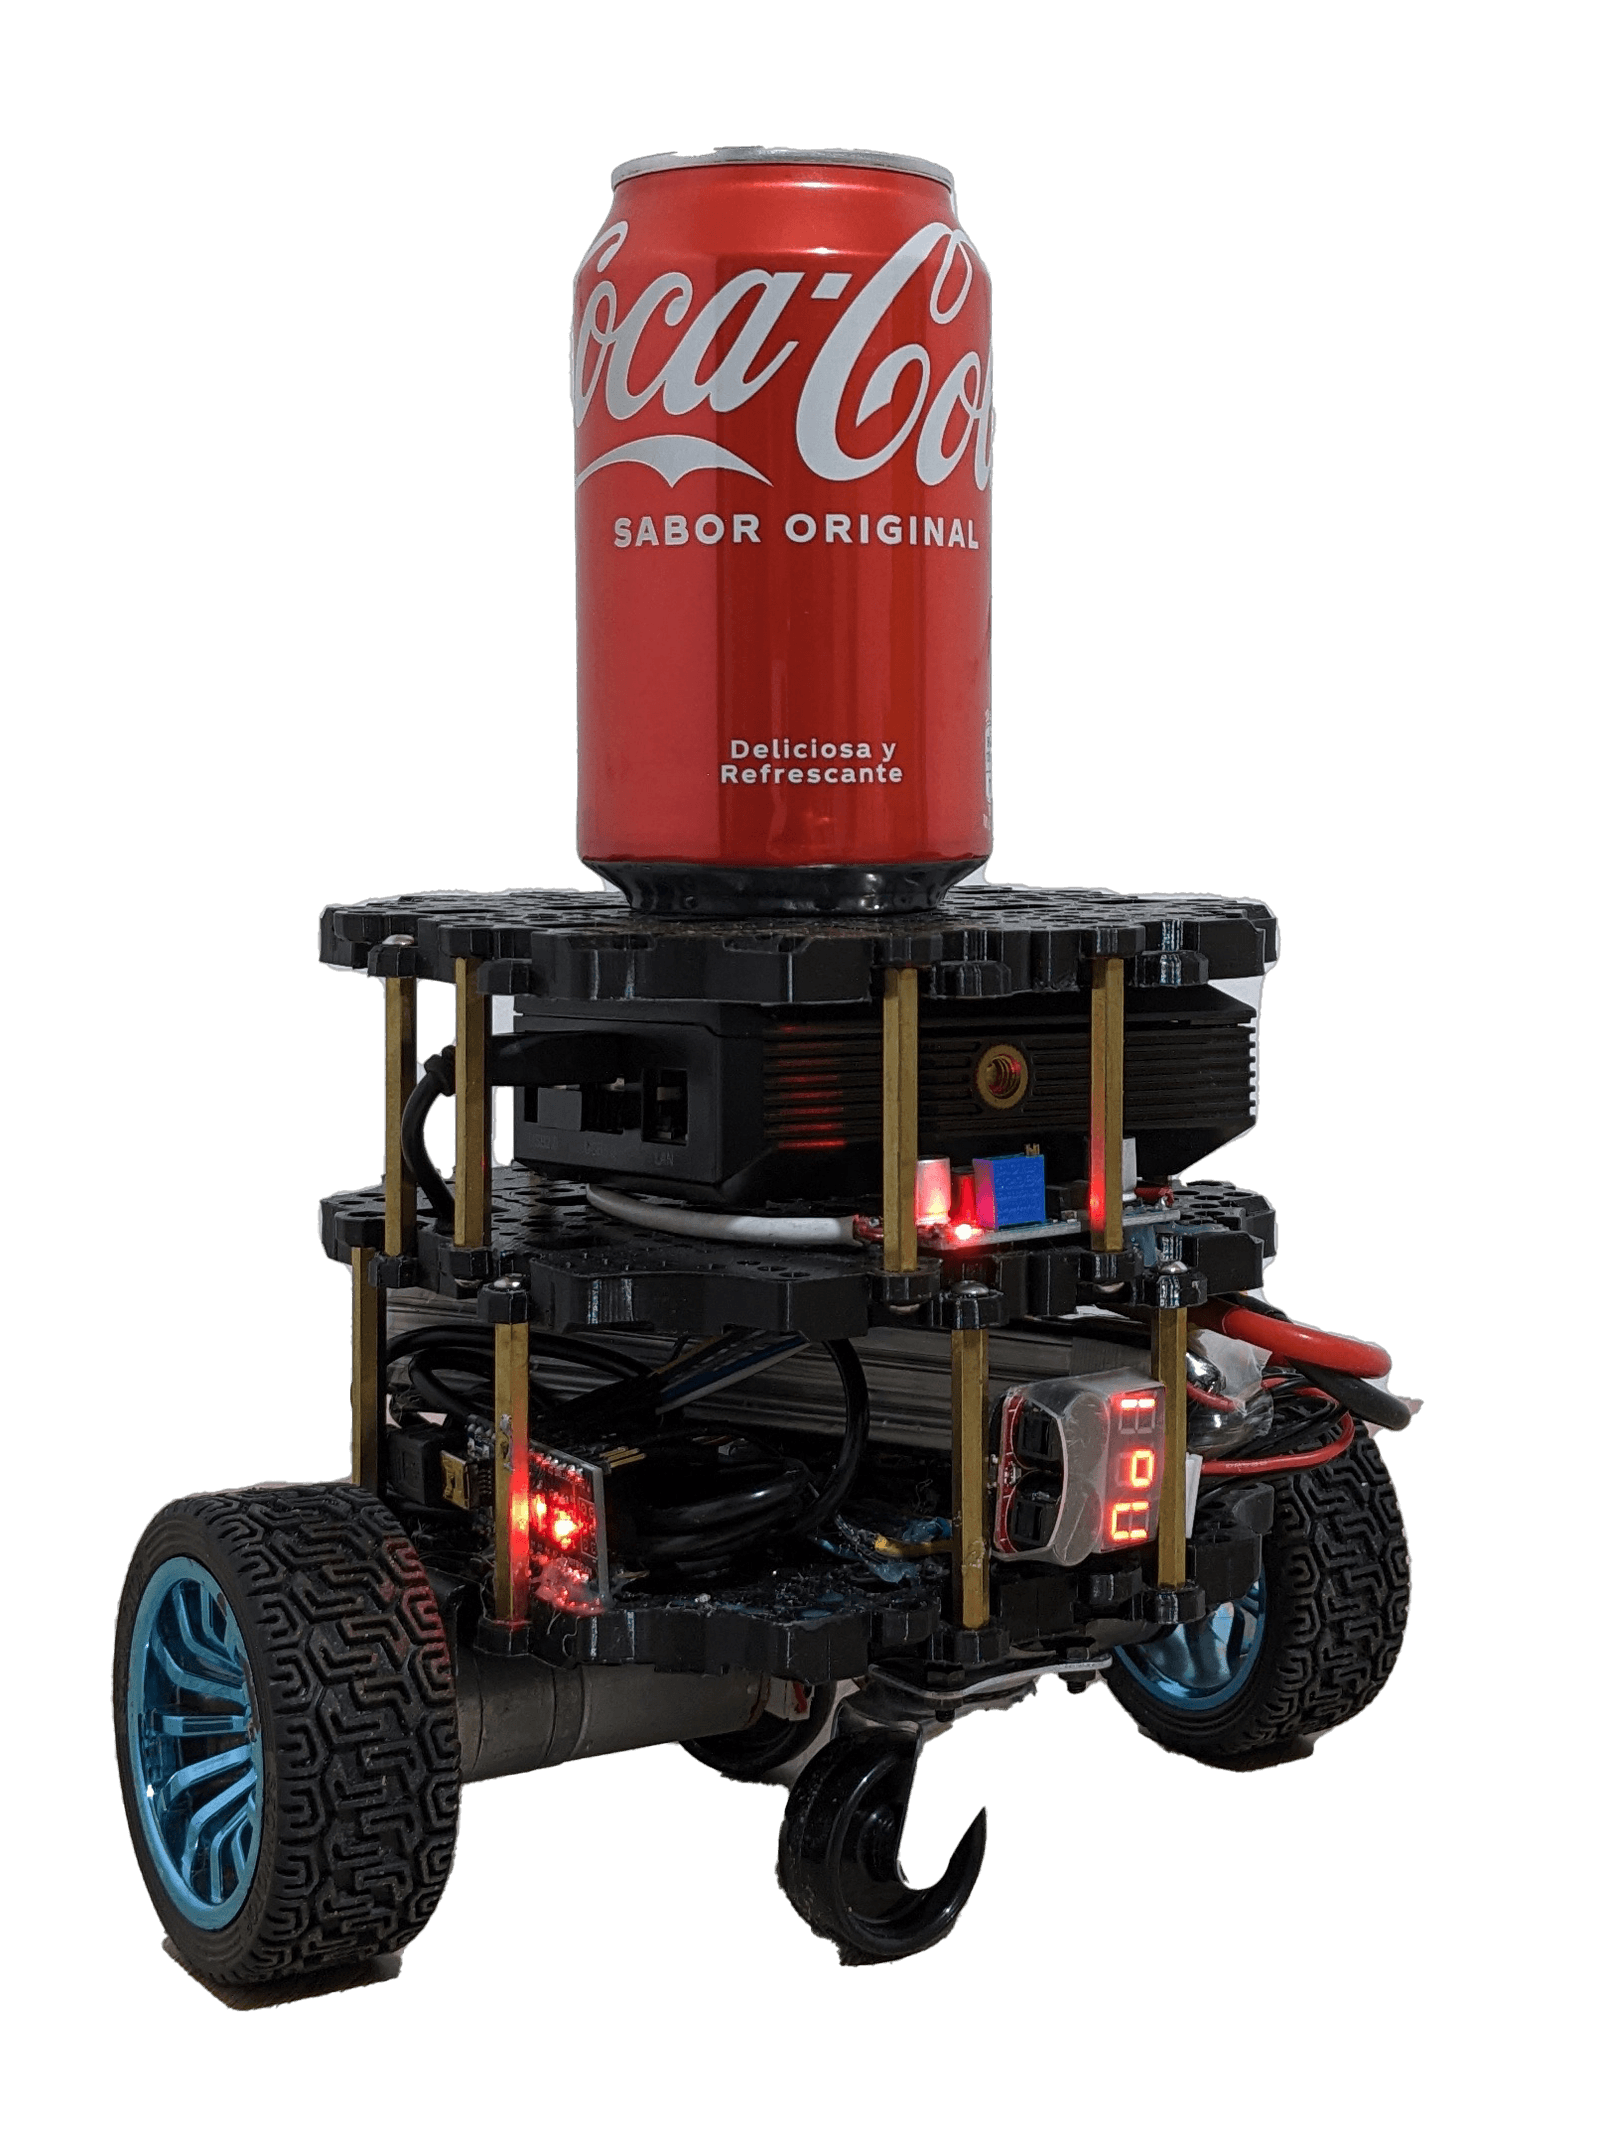 Wheeled
An open-source 3D printed self-driving robot powered by ROS 2, designed as a low-cost learning platform.
Found by Robotheca in bumperbot_controller/package.xml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.