PAROL6
A 6-axis 3D-printed desktop robot arm with stepper motors, gearboxes and belts, modelled on industrial arms, with its own control firmware.
- Robot arm
- Open source
- 3D model (URDF)
- 3D printable
Added from github.com/Source-Robotics/PAROL6-Desktop-robot-arm (opens in a new tab), created by @Source-Robotics (opens in a new tab). Pinned to commit 45a7502 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
One part's design is not open
- PAROL6 control board: Sold by Source Robotics. Its firmware is in the repository, but its circuit board design is not.
Photo and 3D model
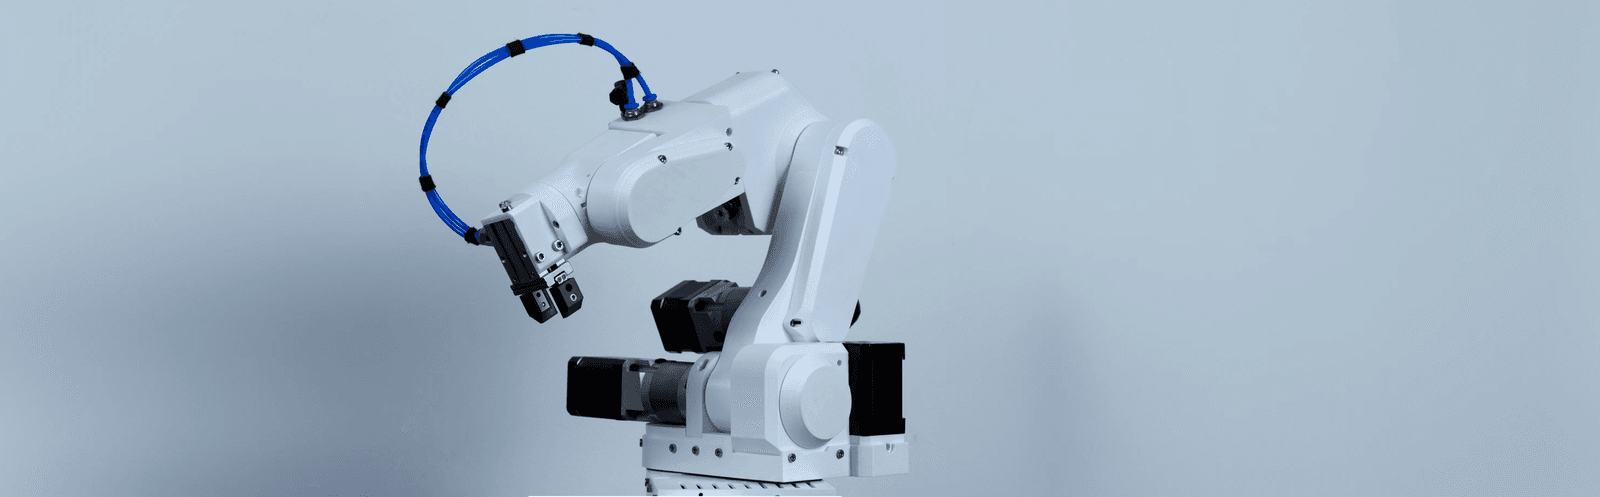
3D preview converted from github.com/Source-Robotics/PAROL6-Desktop-robot-arm at 45a7502, under GPL-3.0-only. View the original files from GitHub (9.2 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- 6-axis articulated arm with belt-driven joints
- Controlled via GUI or Python API
- Supports ROS2 and MoveIt simulation
- Can use electric or pneumatic grippers
- Programmable trajectories and positions
- Emergency stop function
Bill of materials
62 parts62 of 62 parts shown
62 of 62 parts have no price in the source, so there is no parts total. Read from BOM/BOM.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Get the partsBOM.md
- 2Print the parts in PETGPETG_printing.md
- 3Assemble the robotParol building instructions.pdf
- 4Set up the software and run the robot (opens in a new tab)source-robotics.github.io
The guide appears here as you scroll.
Guide by @Source-Robotics (README.md), under GPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- PAROL control board
- TMC5160 stepper motor drivers
- Three stepper motors
- Limit switches
- Three inductive sensors
- Estop button
- Noctua NF-A4x20 5V cooling fan
- USB B cable for communication
- XT30 power connector
- 5/2 solenoid air valve for pneumatic gripper
- Vacuum generator and suction cup gripper
- On/off button
Connections
- Stepper motors connected to TMC5160 drivers on the control board
- Limit switches wired to control board inputs
- Inductive sensors wired to control board inputs
- Estop button wired to control board
- Cooling fan connected to control board
- Pneumatic gripper connected via solenoid valve and tubes
- Power supplied through XT30 connector to control board
Cables and connectors
From the parts list.
- JST PH 2.0mm 200mm 4PIN × 1
- Power connector - male + female × 1
- Gripper connector (electric) × 1
- Cable gland for estop × 1
- Pneumatic connector - robot × 4
- Pneumatic gripper connector × 2
- xt30 connector female × 1
- USB B cable × 1