PAR6 Collaborative Robot Arm
A 3D-printed collaborative robot arm for research, education and rapid prototyping in physical AI.
- Robot arm
- Open source
- Works with AI
- ROS 2
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @Source-Robotics (opens in a new tab), from github.com/Source-Robotics/PAR6-Collaborative-Robot-Arm (opens in a new tab). Pinned to commit b67174a (opens in a new tab).
- Hardware license
- CERN-OHL-S-2.0 (opens in a new tab)
- Software license
- CERN-OHL-S-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
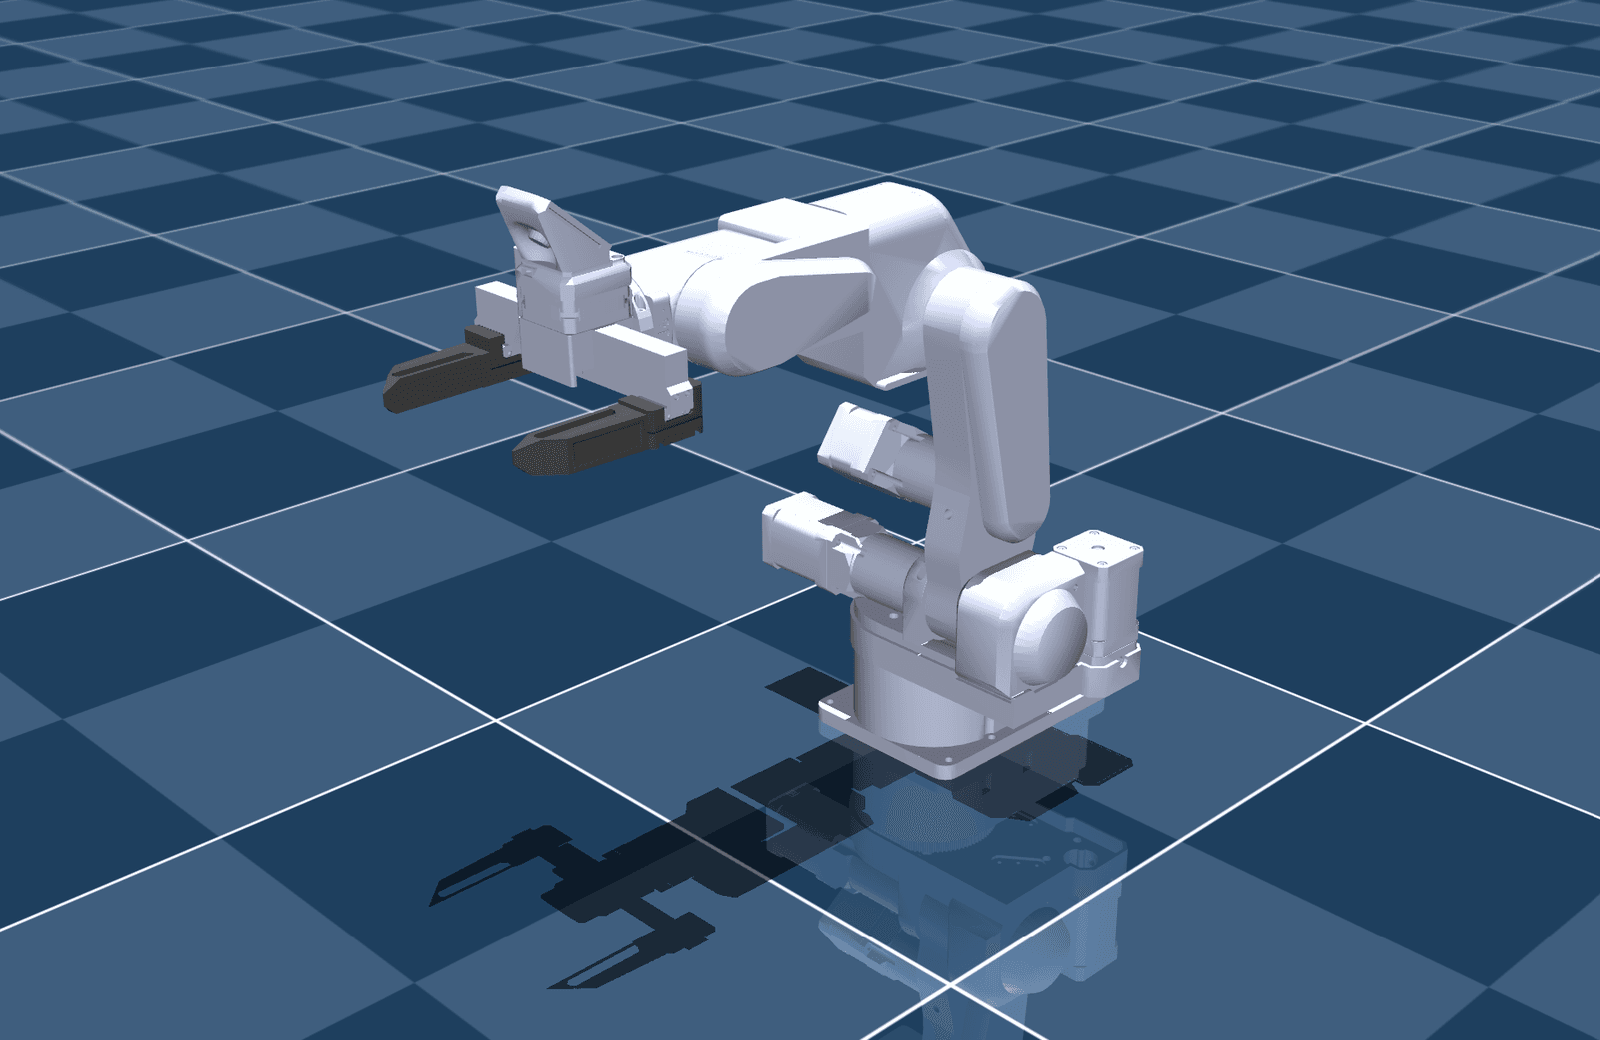
3D preview converted from github.com/Source-Robotics/PAR6-Collaborative-Robot-Arm at b67174a, under CERN-OHL-S-2.0. View the original files from GitHub (8.3 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Serves as a 3D-printed collaborative robot arm platform for research, education and rapid prototyping in physical AI.
- Supports teleoperation and human-in-the-loop control workflows.
- Supports learning from demonstration, imitation learning and dataset generation.
- Includes a MuJoCo MJCF simplified description and URDF files for simulation.
- Offers two gripper options: MSG gripper and SSG48 gripper.
Works with AI
Found by Robotheca in the project's files at commit b67174a, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
“Serves as a 3D-printed collaborative robot arm platform for research, education and rapid prototyping in physical AI.”
Robotheca's notes: What it can do“Supports learning from demonstration, imitation learning and dataset generation.”
Robotheca's notes: What it can do
Bill of materials
74 parts74 of 74 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | M4 10 mm DIN 912 / ISO 4762 (Socket head cap) | 7 | – | – |
| 2 | M3 8 mm DIN 912 / ISO 4762 (Socket head cap) | 50 | – | – |
| 3 | M3 14 mm DIN 912 / ISO 4762 (Socket head cap) | 33 | – | – |
| 4 | M3 25 mm DIN 912 / ISO 4762 (Socket head cap) | 4 | – | – |
| 5 | M2 10 mm DIN 912 / ISO 4762 (Socket head cap) | 2 | – | – |
| 6 | M2 4 mm DIN 912 / ISO 4762 (Socket head cap) | 2 | – | – |
| 7 | M3 45 mm DIN 912 / ISO 4762 (Socket head cap) | 6 | – | – |
| 8 | M3.5 14 mm used for shaft couplers! DIN 912 / ISO 4762 (Socket head cap) | 8 | – | – |
| 9 | M3 16 mm DIN 912 / ISO 4762 (Socket head cap) | 6 | – | – |
| 10 | M3 12 mm DIN 912 / ISO 4762 (Socket head cap) | 3 | – | – |
| 11 | M4 16 mm DIN 912 / ISO 4762 (Socket head cap) | 16 | – | – |
| 12 | M4 14 mm DIN 912 / ISO 4762 (Socket head cap) | 4 | – | – |
| 13 | M4 50 mm DIN 912 / ISO 4762 (Socket head cap) | 4 | – | – |
| 14 | M3 15 mm or 16 Tapered / Countersunk screw head | 5 | – | – |
| 15 | M5 16 mm DIN 912 / ISO 4762 (Socket head cap) | 8 | – | – |
| 16 | M3 22 mm DIN 912 / ISO 4762 (Socket head cap) | 4 | – | – |
| 17 | M3 40 mm DIN 912 / ISO 4762 (Socket head cap) | 8 | – | – |
| 18 | M3 60 mm DIN 912 / ISO 4762 (Socket head cap) | 12 | – | – |
| 19 | Threadlocker blue | 1 | – | – |
| 20 | Threadlocker green | 1 | – | – |
| 21 | Gearbox 20:1 | 1 | – | Link: buy Gearbox 20:1, opens in a new tab |
| 22 | Gearbox 10:1 | 1 | – | Link: buy Gearbox 10:1, opens in a new tab |
| 23 | Gearbox 25:1 | 1 | – | Link: buy Gearbox 25:1, opens in a new tab |
| 24 | Stepper 17HS08-1004S | 1 | – | Link: buy Stepper 17HS08-1004S, opens in a new tab |
| 25 | Stepper 17HS16-2004S1 | 2 | – | Link: buy Stepper 17HS16-2004S1, opens in a new tab |
| 26 | Stepper 17HS24-2104S | 3 | – | Link: buy Stepper 17HS24-2104S, opens in a new tab |
| 27 | Joint 1 belt | 1 | – | Link: buy Joint 1 belt, opens in a new tab |
| 28 | Joint 3 belt | 1 | – | Link: buy Joint 3 belt, opens in a new tab |
| 29 | Joint 4 belt | 1 | – | Link: buy Joint 4 belt, opens in a new tab |
| 30 | Joint 5 belt | 1 | – | Link: buy Joint 5 belt, opens in a new tab |
| 31 | J4/J5 Pulley | 2 | – | Link: buy J4/J5 Pulley, opens in a new tab |
| 32 | J1 Pulley | 1 | – | Link: buy J1 Pulley, opens in a new tab |
| 33 | Shaft coupler | 2 | – | Link: buy Shaft coupler, opens in a new tab |
| 34 | Shaft coupler | 2 | – | Link: buy Shaft coupler, opens in a new tab |
| 35 | Shaft coupler | 2 | – | Link: buy Shaft coupler, opens in a new tab |
| 36 | Shaft coupler | 1 | – | Link: buy Shaft coupler, opens in a new tab |
| 37 | AXK3552 | 1 | – | Link: buy AXK3552, opens in a new tab |
| 38 | NSK HR32906J | 5 | – | Link: buy NSK HR32906J, opens in a new tab |
| 39 | NSK HR32907J | 4 | – | Link: buy NSK HR32907J, opens in a new tab |
| 40 | Tensioning bearing | 2 | – | Link: buy Tensioning bearing, opens in a new tab |
| 41 | Tensioning bearing | 8 | – | Link: buy Tensioning bearing, opens in a new tab |
| 42 | Brass inserts | 6 | – | Link: buy Brass inserts, opens in a new tab |
| 43 | Closed loop Stepper Drivers | 6 | – | Link: buy Closed loop Stepper Drivers, opens in a new tab |
| 44 | Gripper connector PCB | 1 | – | Link |
| 45 | Hall sensor PCB | 1 | – | Link |
| 46 | Base Distribution PCB | 1 | – | Link |
| 47 | Motor controller Magnets | 6 | – | Link: buy Motor controller Magnets, opens in a new tab |
| 48 | Gripper Magnet | 1 | – | Link: buy Gripper Magnet, opens in a new tab |
| 49 | Thermistor | 6 | – | Link: buy Thermistor, opens in a new tab |
| 50 | Robot base connector | 1 | – | Link: buy Robot base connector, opens in a new tab |
| 51 | E-stop | 1 | – | Link: buy E-stop, opens in a new tab |
| 52 | Connectors JST ZH 1.5MM 2PIN male | 10 | – | Link: buy Connectors JST ZH 1.5MM 2PIN male, opens in a new tab |
| 53 | Connectors JST XH 2.54MM 2PIN male | 10 | – | Link: buy Connectors JST XH 2.54MM 2PIN male, opens in a new tab |
| 54 | Thermal cement | 1 | – | Link: buy Thermal cement, opens in a new tab |
| 55 | JST ZH 1.5MM 2PIN female-female 20-30cm | 3 | – | Link: buy JST ZH 1.5MM 2PIN female-female 20-30cm, opens in a new tab |
| 56 | JST XH 2.54MM 2PIN female-female 20-30cm | 3 | – | Link: buy JST XH 2.54MM 2PIN female-female 20-30cm, opens in a new tab |
| 57 | JST ZH 1.5MM 2PIN female-male 23cm | 2 | – | Link |
| 58 | JST XH 2.54MM 2PIN female-male 23cm | 2 | – | Link |
| 59 | JST ZH 1.5MM 2PIN female-female 10cm | 1 | – | Link: buy JST ZH 1.5MM 2PIN female-female 10cm, opens in a new tab |
| 60 | JST XH 2.54MM 2PIN female-female 10cm | 1 | – | Link: buy JST XH 2.54MM 2PIN female-female 10cm, opens in a new tab |
| 61 | JST ZH 1.5MM 2PIN male-bare wire 50cm | 1 | – | Link: buy JST ZH 1.5MM 2PIN male-bare wire 50cm, opens in a new tab |
| 62 | JST XH 2.54MM 2PIN male-bare wire 50cm | 1 | – | Link: buy JST XH 2.54MM 2PIN male-bare wire 50cm, opens in a new tab |
| 63 | JST ZH 1.5MM 2PIN female-bare wire 50cm | 3 | – | Link: buy JST ZH 1.5MM 2PIN female-bare wire 50cm, opens in a new tab |
| 64 | JST XH 2.54MM 2PIN female-bare wire 50cm | 3 | – | Link: buy JST XH 2.54MM 2PIN female-bare wire 50cm, opens in a new tab |
| 65 | 18AWG wire 4 colors | – | – | Link: buy 18AWG wire 4 colors, opens in a new tab |
| 66 | Thin wire 3 colors 20 cm AWG 30 - 35 | – | – | Link: buy Thin wire 3 colors 20 cm AWG 30 - 35, opens in a new tab |
| 67 | Wire 2 colors for XH extensions | 5 m | – | – |
| 68 | Wire 2 colors for ZH extensions | 5 m | – | – |
| 69 | 26 AWG cable 0.15 mm², 4-wire twisted pair ~40 cm usually sufficient | 0.4 m | – | Link: buy 26 AWG cable 0.15 mm², 4-wire twisted pair ~40 cm usually sufficient, opens in a new tab |
| 70 | M8 4-pin male wire connector See reference image | 1 | – | Link: buy M8 4-pin male wire connector See reference image, opens in a new tab |
| 71 | M8 4-pin female wire connector See reference image | 1 | – | Link: buy M8 4-pin female wire connector See reference image, opens in a new tab |
| 72 | MHZ2-16D gripper | 1 | – | Link: buy MHZ2-16D gripper, opens in a new tab |
| 73 | Pneumatic Tube | 4 | – | Link: buy Pneumatic Tube, opens in a new tab |
| 74 | Solenoid valve | 1 | – | Link: buy Solenoid valve, opens in a new tab |
74 of 74 parts have no price in the source, so there is no parts total. Read from BOM/BOM.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Source all parts from the BOM
- 23D print the robot parts
- 3Assemble the robot arm
- 4Build the cable assemblies
- 5Build the RCB control box
The guide appears here as you scroll.
Guide by @Source-Robotics (README.md), under CERN-OHL-S-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Stepper motors: 17HS08-1004S, 17HS16-2004S1 and 17HS24-2104S, paired with closed loop stepper drivers.
- Gearboxes with 10:1, 20:1 and 25:1 ratios.
- Base Distribution PCB, Hall sensor PCB, gripper connector PCB and motor controller magnets.
- Thermistor and an E-stop.
- Robot Control Box (RCB) mainboard, which runs RCB code, plus a separate STEPFOC stepper controller repository.
Connections
- JST XH series cables deliver power to the motor drivers (22 or 24 AWG).
- JST ZH series cables carry CAN communication between motor drivers (28 AWG); twisting CAN cables is recommended.
- Robot base to RCB cable uses GX16 4-pin connectors with a twisted shielded cable: pins 1 and 4 carry power, pins 2 and 3 carry CAN.
- Gripper cable uses M8 4-pin connectors; MSG and SSG48 grippers use different cables that must not be interchanged.
- On the RCB mainboard, some traces must be cut and jumper wires added before operation, and the two E-stop connectors need pins bridged across them.
Cables and connectors
From the parts list.
- Gripper connector PCB × 1
- Robot base connector × 1
- Connectors JST ZH 1.5MM 2PIN male × 10
- Connectors JST XH 2.54MM 2PIN male × 10
- JST ZH 1.5MM 2PIN female-female 20-30cm × 3
- JST XH 2.54MM 2PIN female-female 20-30cm × 3
- JST ZH 1.5MM 2PIN female-male 23cm × 2
- JST XH 2.54MM 2PIN female-male 23cm × 2
- JST ZH 1.5MM 2PIN female-female 10cm × 1
- JST XH 2.54MM 2PIN female-female 10cm × 1
- JST ZH 1.5MM 2PIN male-bare wire 50cm × 1
- JST XH 2.54MM 2PIN male-bare wire 50cm × 1
- JST ZH 1.5MM 2PIN female-bare wire 50cm × 3
- JST XH 2.54MM 2PIN female-bare wire 50cm × 3
- 18AWG wire 4 colors
- Thin wire 3 colors 20 cm AWG 30 - 35
- Wire 2 colors for XH extensions × 5 m
- Wire 2 colors for ZH extensions × 5 m
- 26 AWG cable 0.15 mm², 4-wire twisted pair ~40 cm usually sufficient × 0.4 m
- M8 4-pin male wire connector See reference image × 1
- M8 4-pin female wire connector See reference image × 1