MiniLoong
A small 22-degree-of-freedom humanoid robot designed for reinforcement learning and imitation learning, featuring a rotatable waist, head, and upper limbs.
- Humanoid
- Open source
- Work in progress
- Works with AI
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @loongOpen (opens in a new tab), from github.com/loongOpen/MiniLoong (opens in a new tab). Pinned to commit 50d93a5 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (80 scripts, 3 programs or installers, 1 firmware image)
- 下位机代码/Linux/control_task2/eigen/bench/bench_multi_compilers.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/btl/data/mk_gnuplot_script.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/btl/data/mk_mean_script.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/btl/data/mk_new_gnuplot.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/btl/data/smooth_all.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/perf_monitoring/gemm/make_plot.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/bench/perf_monitoring/gemm/run.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/eigen/blas/testing/runblastest.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/catgets/test-gencat.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/debug/catchsegv.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/debug/xtrace.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/elf/tst-pathopt.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/grp/tst_fgetgrent.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/gen-8bit-gap-1.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/gen-8bit-gap.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/gen-8bit.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/run-iconv-test.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/tst-table-charmap.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/tst-table.sh (opens in a new tab)
- 下位机代码/Linux/control_task2/lcm_3party/glibc-2.2.3/iconvdata/tst-tables.sh (opens in a new tab)
- and 64 more
Photo and 3D model
3D preview converted from github.com/loongOpen/MiniLoong at 50d93a5, under Apache-2.0. View the original files from GitHub (14.0 MB) (opens in a new tab)
- Height
- 55 cm
What it can do
Written by Robotheca from the project's documents.
- Walks and balances with 22 degrees of freedom including waist, arms, hands and head
- Runs end-to-end reinforcement learning and imitation learning algorithms
- Runs upper-limb operation algorithms and open-source VLA models for embodied operation
- Displays facial expressions on an OLED screen and runs AI voice agent via ESP32
- Provides isomorphic dual-arm remote control for data acquisition and teleoperation
Works with AI
Found by Robotheca in the project's files at commit 50d93a5, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Ships trained model files: model_jitt.pt and 7 more
In the project files: 下位机代码/Linux/control_task2/model/model_jitt.ptUses a machine-learning library: ONNX
In the project files: 下位机代码/Linux/control_task2/loong_ctrl/src/rl/onnx.cpp“Runs end-to-end reinforcement learning and imitation learning algorithms”
Robotheca's notes: What it can do“Runs upper-limb operation algorithms and open-source VLA models for embodied operation”
Robotheca's notes: What it can do“Displays facial expressions on an OLED screen and runs AI voice agent via ESP32”
Robotheca's notes: What it can do
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Prepare 3D printed parts and carbon fiber sheets
- 2Assemble the robot's mechanical structure
- 3Install motors and servos
- 4Wire the power distribution and control systems
- 5Install the main controller (e.g., Jetson Nano or Raspberry Pi)
- 6Configure motor IDs and CAN bus connections
- 7Install and calibrate sensors (IMU, OLED, cameras)
- 8Flash firmware to STM32 boards
- 9Install and configure control software
- 10Test and calibrate the robot's movements
The guide appears here as you scroll.
Guide by @loongOpen (README.md), under Apache-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
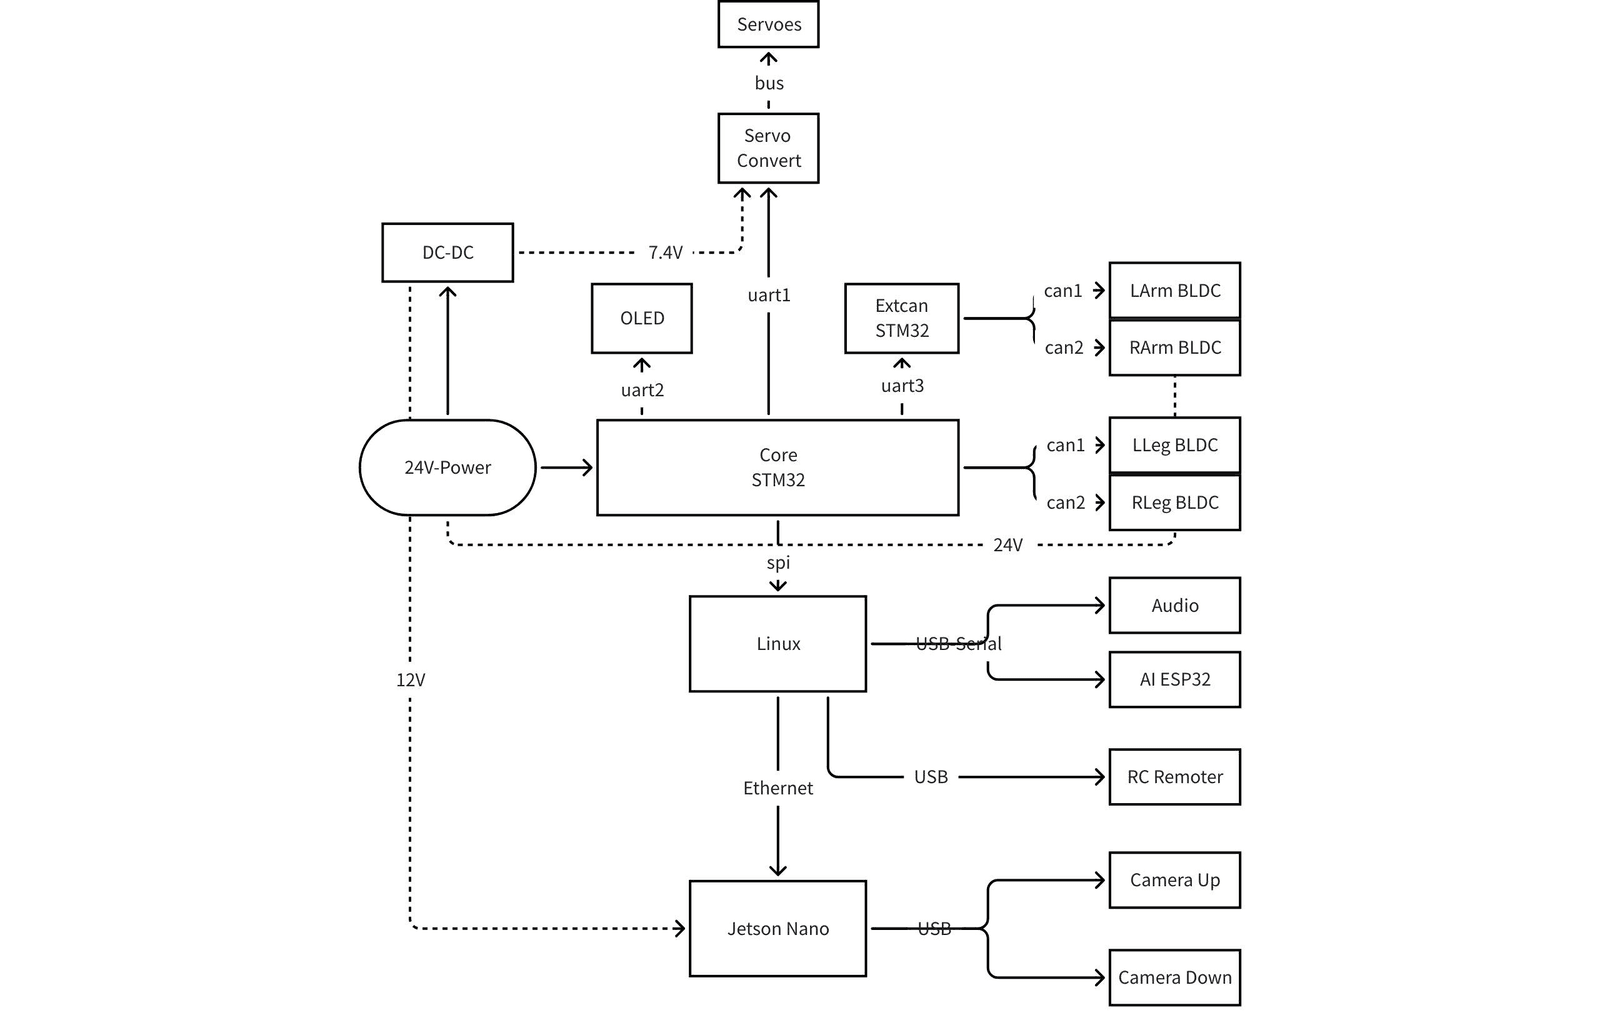
- Main controller board (STM32-Core) for motor control
- ExtCan board for CAN bus expansion
- Brushless motors: six 6006, eight 8006 and eight 3507
- IMU and high-performance IMU for orientation sensing
- Two USB cameras for vision
- OLED display for facial expressions
- ESP32-based face module for AI voice agent
- Power distribution boards and DCDC converters (12 V and 5 V)
- Battery: 6S1P 24 V 7 Ah Li-ion
- Optional Jetson Nano or Raspberry Pi class SBC for higher-level control
Connections
- Motors connected via CAN bus to STM32-Core and ExtCan boards with CAN IDs configured per motor
- IMU connected via serial port conversion cable to main controller
- USB cameras connected to host computer via USB
- OLED connected to ESP32 face module
- Power distribution boards feed 12 V and 5 V rails to controllers and peripherals
- XT30 connectors and XT-CAN cables used for power and CAN bus wiring
Schematics, boards and diagrams
- 硬件接线图/硬件接线图.pngDiagram
- 硬件电路板开源资料/omnibothub-corev1.PcbDocAltium
- 硬件电路板开源资料/omnibothub-debug.PcbDocAltium
- 硬件电路板开源资料/omnibothub-download.PcbDocAltium
- 硬件电路板开源资料/omnibothub-extcan.PcbDocAltium
- 硬件电路板开源资料/omnibothub-power-four.PcbDocAltium
- 硬件电路板开源资料/omnibothub-power-one-usb.PcbDocAltium
- 硬件电路板开源资料/omnibothub-power-one.PcbDocAltium
