Asimov 1
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
- Humanoid
- Open source
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @menloresearch (opens in a new tab), from github.com/menloresearch/asimov-1 (opens in a new tab). Pinned to commit f71f3fe (opens in a new tab).
- Hardware license
- CERN-OHL-S-2.0 (opens in a new tab)
- Software license
- GPL-2.0-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 script)
Photo and 3D model
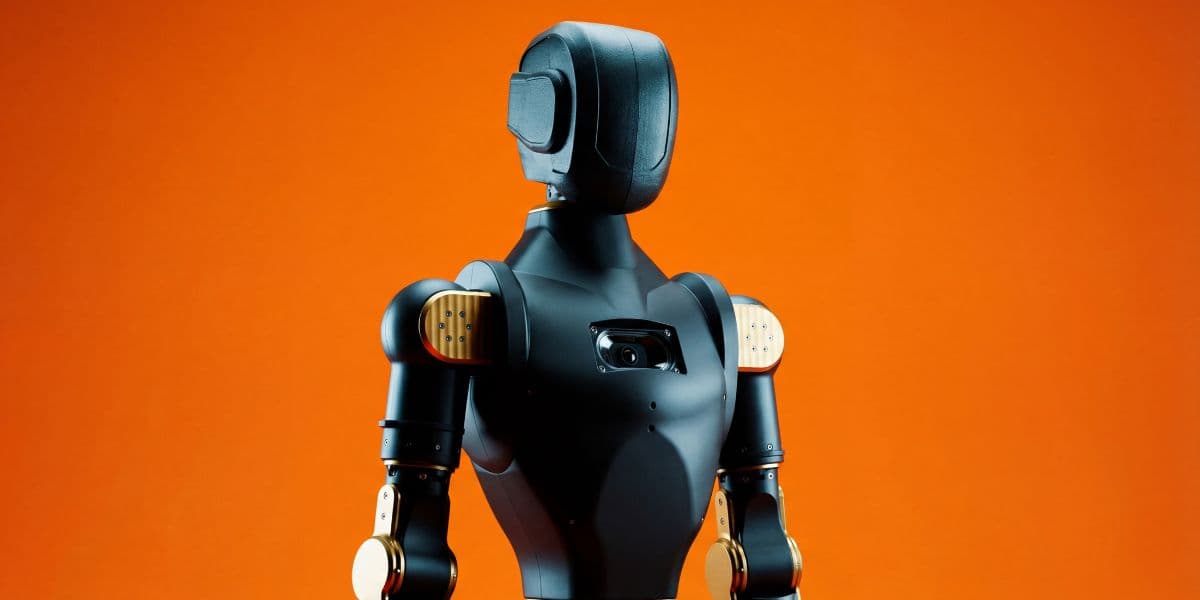
3D preview converted from github.com/menloresearch/asimov-1 at f71f3fe, under CERN-OHL-S-2.0. View the original files from GitHub (43.4 MB) (opens in a new tab)
- Height
- 1.2 m
- Weight
- 35 kg
What it can do
Written by Robotheca from the project's documents.
- Open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom
- Legs have 6 DOF each and arms have 5 DOF each; waist yaw and 2-DOF neck
- Head carries a stereo microphone array and a 2MP monocular camera
- Torso has a 10 W speaker and a 6-DOF IMU
- Motor communication runs over 5 CAN buses at 1 Mbps and 1 CAN bus at 500 kbps
- Onboard compute uses a Raspberry Pi 5 for media and network plus a Radxa CM5 for motion control
- Simulation model in MuJoCo with 23 hinge joints for locomotion policy training and hardware-in-the-loop testing
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @menloresearch (README.md), under CERN-OHL-S-2.0 (hardware) and GPL-2.0-only (software).
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Radxa CM5 mounted on the Motion Control Board, a carrier with an onboard LSM6DSV IMU
- Power Distribution Board stacked on top of the Motion Control Board
- Raspberry Pi 5 in the head with a head board of buck converters and an audio IC, plus an RPi5 hat with button, LED and buzzer
- CAN via SPI bridge, RS485 and TTL shifting circuits on the motion control board
- Power supplied through an XT90(2+2) connector on the Power Distribution Board
Connections
- Power enters through the XT90(2+2) connector on the Power Distribution Board, with 5V routed down to the Motion Control Board
- Motion Control Board ports are labeled LL, RL, LA, RA, NP, NY and W for the left leg, right leg, left arm, right arm, neck pitch, neck yaw and waist yaw buses
- Each wiring harness line corresponds to a pre-made cable; some connections must be completed after assembly using WAGO or solder joints
- UART TTL debug lines are fanned out to test pads on the Power Distribution Board
Schematics, boards and diagrams
- electrical/media/hat/board/board.kicad_pcbKiCad
- electrical/media/hat/board/board.kicad_schKiCad
- electrical/media/head/board/board.eproEasyEDA
- electrical/rpu/motion_control/board/board.kicad_pcbKiCad
- electrical/rpu/motion_control/board/board.kicad_schKiCad
- electrical/rpu/motion_control/board/can.kicad_schKiCad
- electrical/rpu/motion_control/board/cm5-j1.kicad_schKiCad
- electrical/rpu/motion_control/board/cm5-u13a.kicad_schKiCad
- electrical/rpu/motion_control/board/cm5-u13b.kicad_schKiCad
- electrical/rpu/motion_control/board/rs485.kicad_schKiCad
- electrical/rpu/motion_control/board/spi-can.kicad_schKiCad
- electrical/rpu/motion_control/board/TTL_SHIFT.kicad_schKiCad
- electrical/rpu/motion_control/board/u13a.kicad_schKiCad
- electrical/rpu/motion_control/board/u13b.kicad_schKiCad
- electrical/rpu/power_distribution/board/board.kicad_pcbKiCad
- electrical/rpu/power_distribution/board/board.kicad_schKiCad