Skip to content

Photo and 3D model

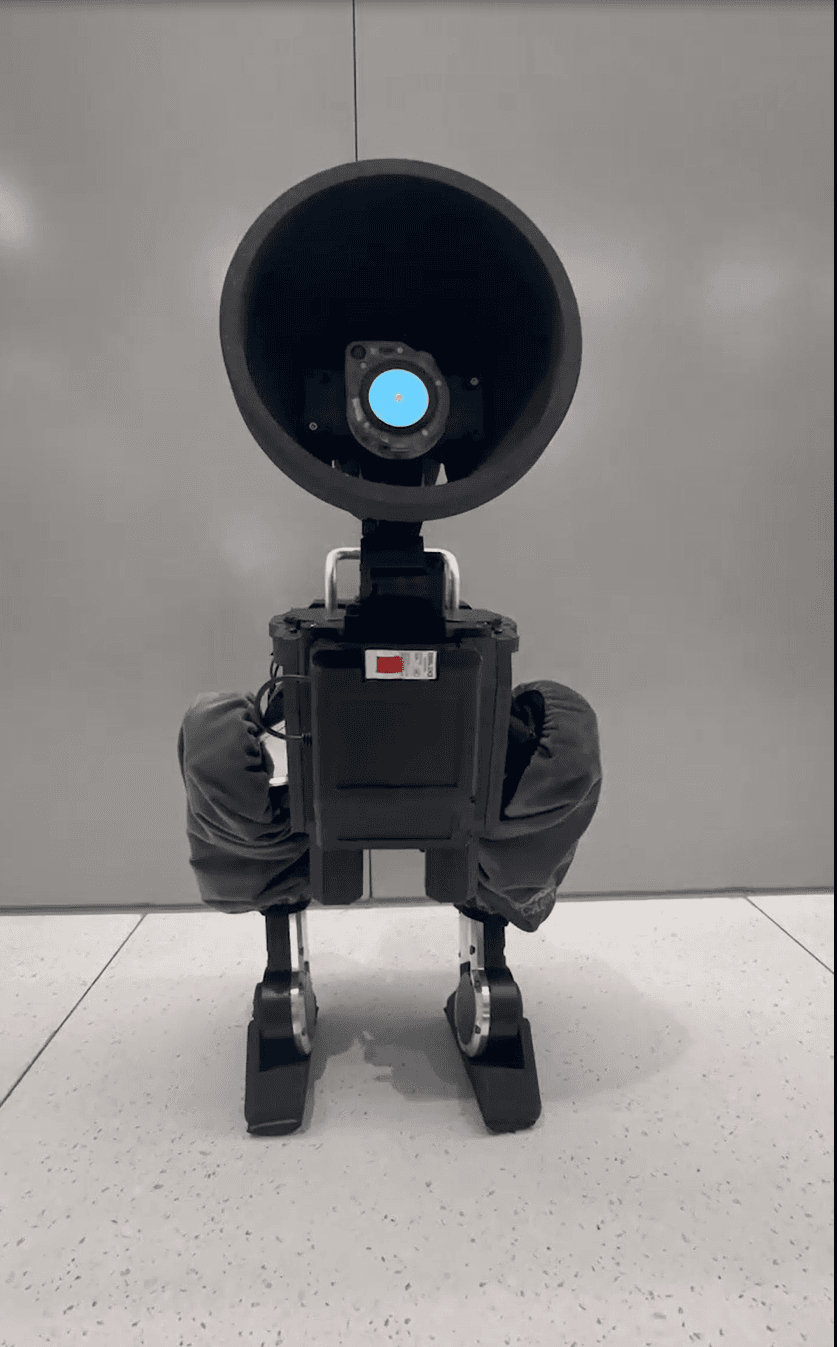
TinkerV2, photo from its repository
Photo@golaced (opens in a new tab)Apache-2.0source file (opens in a new tab)
Try it in the browser

3D preview converted from github.com/golaced/OmniBotSeries-Tinker at 075e79c, under Apache-2.0. View the original files from GitHub (9.1 MB) (opens in a new tab)

Open source · free files

TinkerV2

Humanoid

A 60 cm high-performance bipedal robot combining Pixar's lamp robot and Disney's BDX robot, driven by brushless motors and trained with reinforcement learning.

Project information

Buildability
70/100Buildable with some effort
Estimated cost
under ¥15,000up to approx. €2,018 (ECB rate, 30 Oct 2026)As the creator writes in README.md; the repository with its parts list and guide says “under 20,000 RMB”: Yuexuan9/Tinker (opens in a new tab).
Level
Advanced
Parts
Not listed
Tools
3D printer
Licenses
Apache-2.0 (opens in a new tab), hardware and software
Commercial use
Allowed
Height
60 cm

This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.

Which files (59 scripts, 37 programs or installers, 6 firmware images)

Suggested by Robotheca, created by @golaced (opens in a new tab), from github.com/golaced/OmniBotSeries-Tinker (opens in a new tab), pinned to commit 075e79c (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

This repository has no parts list Robotheca can read yet.

Why it scores 70

It measures the published files, not the robot · How we score

70/100

Buildable with some effort

How complete the published files are for rebuilding this robot, measured by Robotheca at commit 075e79c. It isn't a rating of the robot.

  1. 13D and CAD files52 printable parts (STL, 3MF), 62 CAD source files.20/20
  2. 2Robot descriptionA URDF with all its mesh files.15/15
  3. 3Parts listNo parts list in the repository or linked.Most points to gain: Link to your parts list, or add it to the repository (a CSV or a Markdown table) with quantities, prices and where to buy each part.0/20
  4. 4SoftwareCode in this repository, instructions to install or run it.Say which software framework it uses (ROS 2, LeRobot, Arduino…).10/15
  5. 5DocumentationREADME of 7,287 characters with 3 pictures; 0 build steps.Split the build into at least 3 steps.10/15
  6. 6Simulation4 simulation files (MuJoCo, Gazebo, Webots or Isaac).5/5
  7. 7LicensesHardware: Apache-2.0; software: Apache-2.0.10/10

Build it

The guide appears here as you scroll.

Guide by @golaced (README.md), under Apache-2.0.

More guides

Wiring and electronics

Notes written by Robotheca from the project's documents

Main parts

  • Brushless motors drive the robot's joints.
  • Odroid C4 onboard computer runs the control policies.
  • ESP32-S3 based remote controller with a 2.4 inch LCD module (from the ESP32 example README).
  • Custom Altium PCBs include power boards (power-one, power-two, power-four, power-one-usb), a core board, a debug board, an external CAN board, and a remote board with a USB converter.
  • Bill of materials is maintained externally in linked documents rather than in the repository.

Connections

  • Power boards in the OmniBotHub design are split into several variants, indicating power distribution across the robot.
  • An external CAN interface board (omnibothub-extcan) suggests motor communication over CAN bus.
  • A debug board and USB converter board are included for programming and communication with a computer.
  • Detailed pin and connector wiring is not described in the provided documents; refer to the Altium schematics and linked guides.

What it can do

Written by Robotheca from the project's documents
  • Bipedal walking gait trained with reinforcement learning and transferred to a real robot (sim2real), described as closely matching the BDX style gait.
  • Runs trained locomotion policies (TVM) on an onboard computer (Odroid C4).
  • Locomotion with reinforcement learning is shown in the Ctrl package README, with real-robot performance demonstrated in an external video.
  • Optional large language model voice interaction via installable Xiaozhi AI modules.
  • Remote control handled by a separate ESP32-based remote with an LVGL display.

Works with AI

Found by Robotheca in the project's files at commit 075e79c, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.

Software

Framework
Not stated
Languages
C++, C, Python, MATLAB / Objective-C, Shell, JavaScript
License
Apache-2.0

Robotheca doesn't review code. Read it before running it.

How to run it

Written by Robotheca from the project's documents.

  1. 1Refer to the linked software guide describing how to run TVM policies on the Odroid C4 onboard computer.
  2. 2Training your own policies uses IsaacGym according to the linked repository document.
  3. 3The OmniBotTele ESP32 example documents that the code is built for a Zhengdian Atom ESP32-S3 development board, with LED on IO4 and an LCD module; flashing steps are not given in the provided text.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

The code

Free files

Every file of the project, at commit 075e79c.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/tinkerv2/badge.svg)](https://robotheca.org/robots/tinkerv2)
[![Robotheca buildability](https://robotheca.org/robots/tinkerv2/score.svg)](https://robotheca.org/robots/tinkerv2)

Other humanoids

All 40 humanoids
  • Ready to build

    Open source · free files

    Roboto Origin

    Humanoid · Advanced

    Score
    Buildability 87 out of 100
    Cost
    ¥49,713≈ €6,689
  • Ready to build

    Open source · free files

    Poppy Humanoid

    Humanoid · Advanced

    Score
    Buildability 84 out of 100
    Cost
    $8,000≈ €7,161
  • Open source · free files

    NanoLoong Bipedal

    Humanoid · Advanced

    Score
    Buildability 70 out of 100
    Cost
    under ¥15,000≈ up to €2,018
  • Open source · free files

    ElectronBot

    Humanoid · Advanced

    Score
    Buildability 69 out of 100
    Cost
    Not stated

≈ € values are approximate, converted at the ECB euro reference rate of 30 Oct 2026. The creator's original price always comes first.