No photo yet
MuJoCo
- Software
- Simulators
- Simulator
MuJoCo is a general-purpose physics engine for simulating articulated bodies in contact, used in robotics, biomechanics, graphics, and machine learning research.
Source on GitHub: github.com/google-deepmind/mujoco (opens in a new tab). Facts read at commit c39fe6f (opens in a new tab).
Licenses
- Code
- Apache-2.0 (opens in a new tab)
Read by Robotheca from LICENSE (opens in a new tab) (Apache-2.0) at commit c39fe6f (opens in a new tab), on 30 Oct 2026.
- Commercial use
- Yes
What it does: Robotheca's summary
- Provides a C API tuned for fast simulation, with models compiled from XML into preallocated data structures.
- Includes interactive visualization through a native OpenGL GUI, including the simulate viewer.
- Offers Python bindings installable from PyPI, plus a Unity plug-in and C# bindings.
- Includes tutorial notebooks covering model editing, multithreaded rollouts, LQR control, and least-squares solving.
- Has MJX, a JAX-based branch for accelerated and differentiable physics simulation.
- Exposes many utility functions for computing physics-related quantities.
Written by Robotheca from the project's README (opens in a new tab) at commit f627a81.
Getting started
- Difficulty
- Intermediate
- Hardware it needs, as the project states it
- Prebuilt binaries are built for Linux (x86-64 and AArch64), Windows (x86-64 only), and macOS (universal); Python bindings need Python 3.10 or newer.
- How to start
- The project's website (opens in a new tab)
Maintenance
- Status
- Active: a commit in the last 90 days
- Newest commit
- 30 Oct 2026 on main
- Latest release
- 3.17.0 (22 Oct 2026)
Checked on GitHub on 30 Oct 2026.
Links
Robots that can run it
Found by Robotheca in requirements-macos.txt (opens in a new tab)
- No photo yet
Open source · free files
Dual Scorpion
Robot arm · Advanced
- Score
- Buildability 81 out of 100
- Cost
- $486.88≈ €434
Found by Robotheca in requirements-macos.txt (opens in a new tab)
- No photo yet
Found by Robotheca in mujoco/requirements.txt (opens in a new tab)
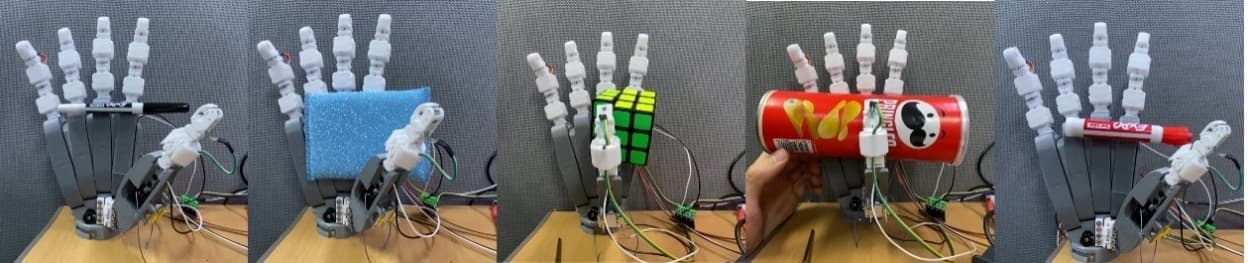
Found by Robotheca in requirements.txt (opens in a new tab)
Ready to build Open source · free files
Physical Ant
Quadruped · Intermediate
- Score
- Buildability 94 out of 100
- Cost
- $2,230.61≈ €1,987
Found by Robotheca in requirements.txt (opens in a new tab)
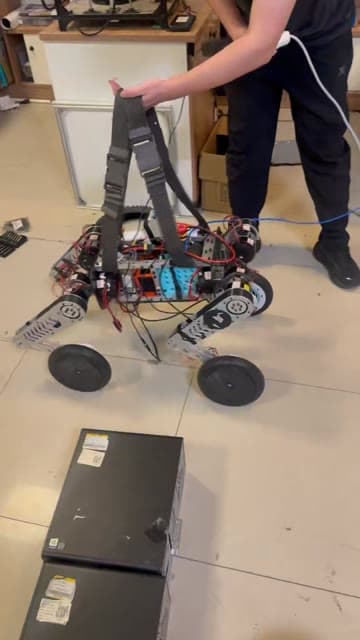
Found by Robotheca in 05_software/train/rc_mjlab/pyproject.toml (opens in a new tab)
Ready to build Open source · free files
Roboto Origin
Humanoid · Advanced
- Score
- Buildability 87 out of 100
- Cost
- ¥49,713≈ €6,642
Found by Robotheca in modules/roboparty_train/robolab/setup.py (opens in a new tab)
- No photo yet
Found by Robotheca in requirements.txt (opens in a new tab)
Open source · free files
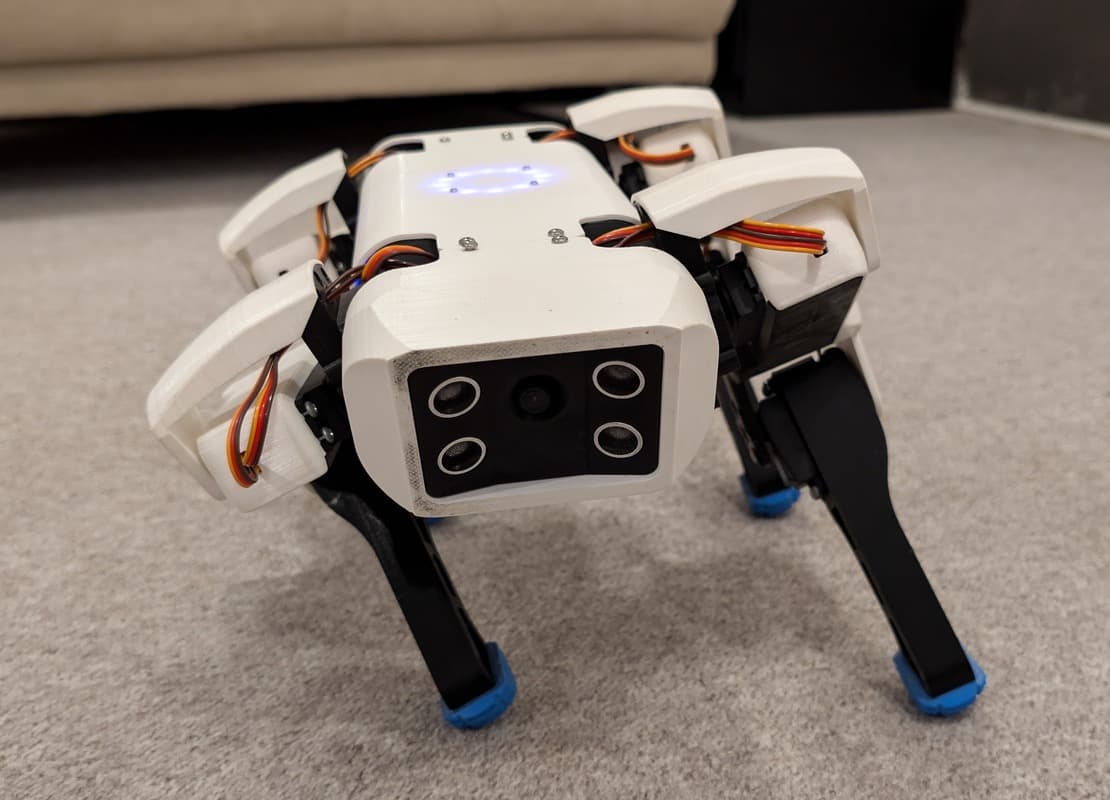
Spot Micro - Leika
Quadruped · Advanced
- Score
- Buildability 75 out of 100
- Cost
- Not stated
Found by Robotheca in simulation/pyproject.toml (opens in a new tab)
Found by Robotheca in src/simulation/mani_skill/examples/bimanual.openarm/openarm_mujoco/pyproject.toml (opens in a new tab)
Open source · free files
TRLC-DK1
Robot arm · Intermediate
- Score
- Buildability 69 out of 100
- Cost
- Not stated
Found by Robotheca in pyproject.toml (opens in a new tab)
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.