Kayra
An easy to modify, 3D printable open-source humanoid robot evolved by the community that walks, lifts and can be simulated.
- Humanoid
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @assadollahi (opens in a new tab), from github.com/assadollahi/kayra (opens in a new tab). Pinned to commit 100f3b7 (opens in a new tab).
- Hardware license
- BSD-3-Clause (opens in a new tab)
- Software license
- BSD-3-Clause (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
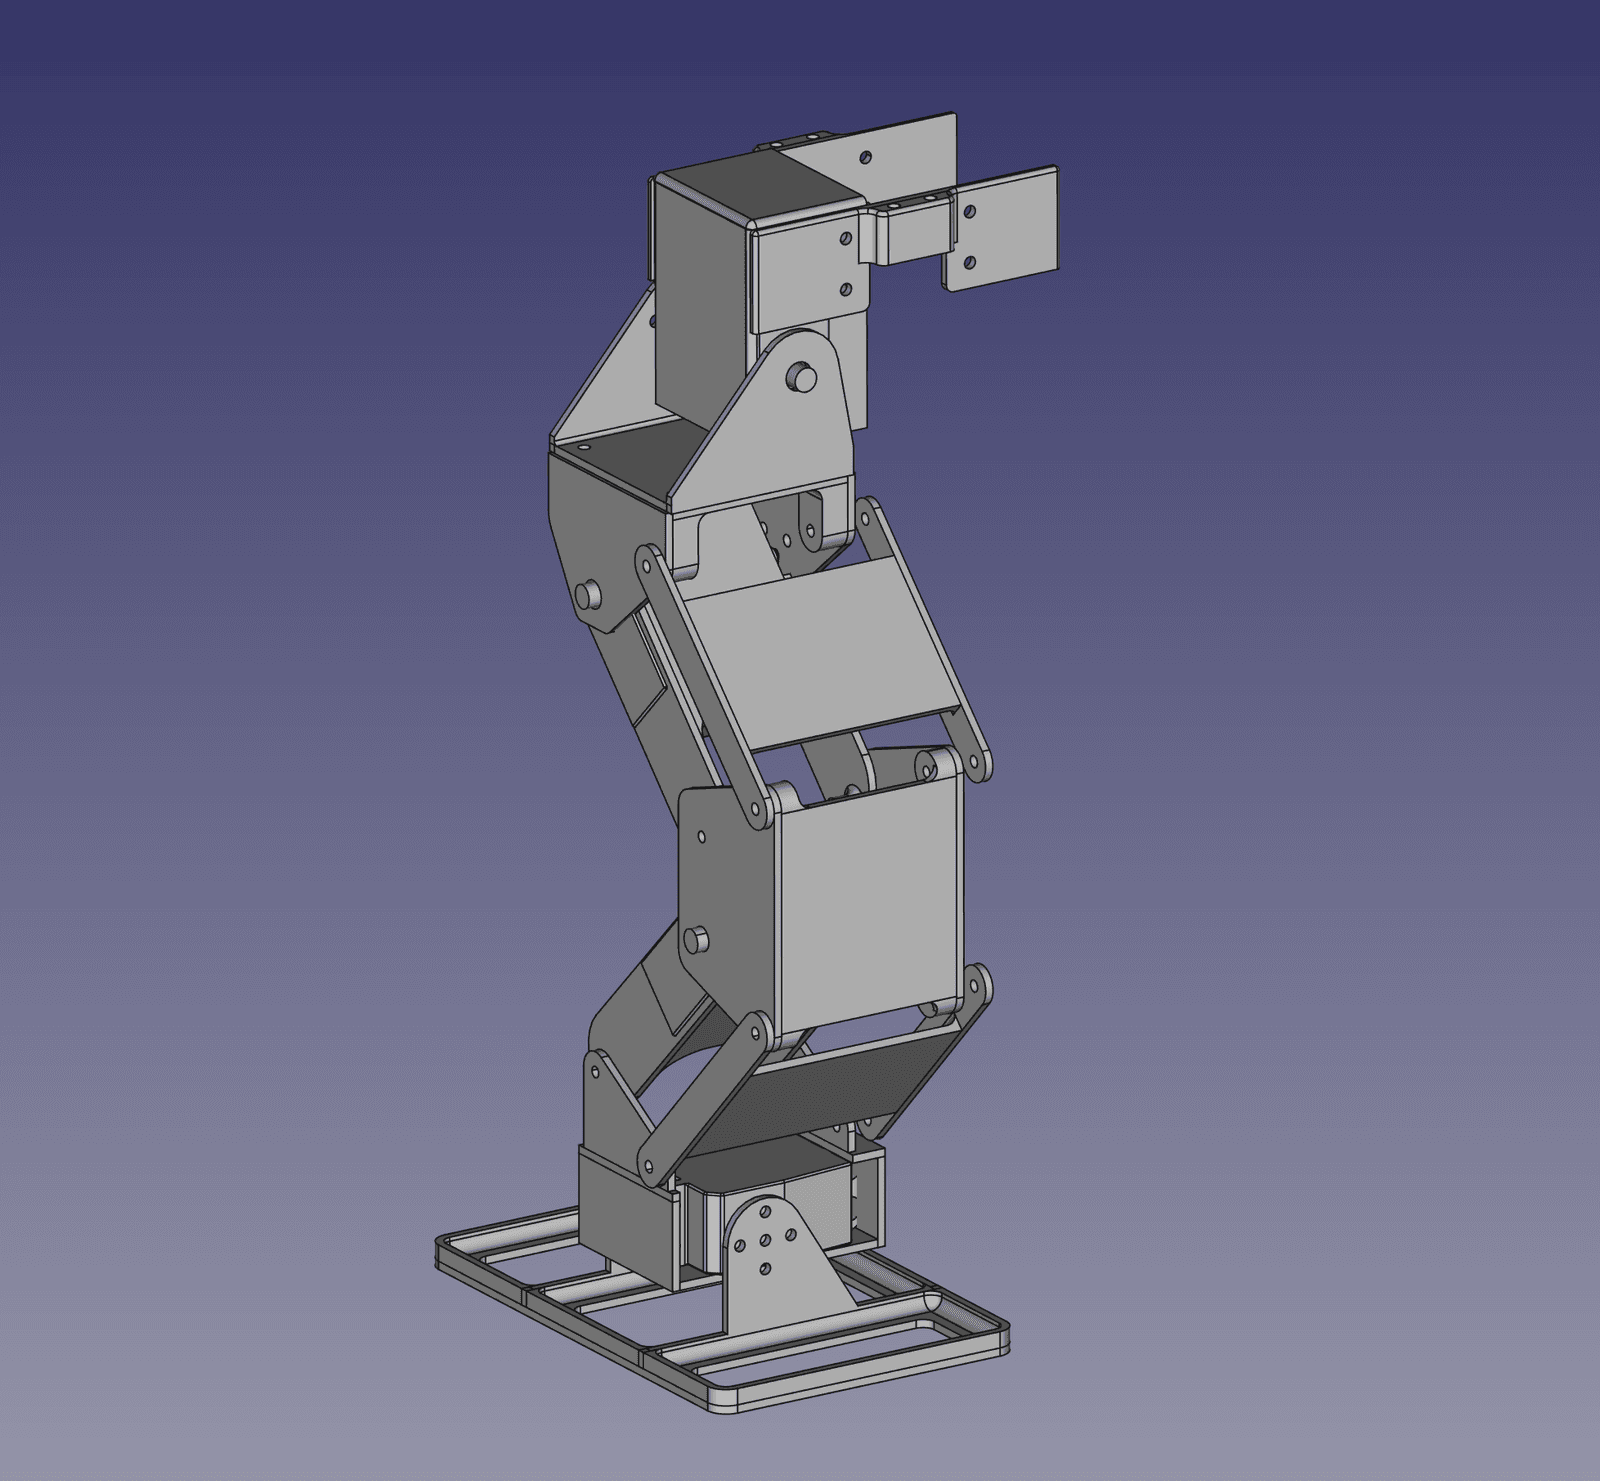
3D preview converted from github.com/assadollahi/kayra at 100f3b7, under BSD-3-Clause. View the original files from GitHub (29.2 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Walks, with walking and grabbing movement patterns provided, a design goal of walking nearly as fast as a human toddler.
- Arms are meant to lift at least a toy, a stated goal.
- Controlled from a Linux PC over USB serial using an interactive editor for poses and animations.
- Can run stored poses and animations untethered, triggered by the USER button on the servo controller.
- Simulated in MuJoCo, usable without hardware.
- Optional remote control via PS2 or 8Bitdo controllers, and a planned WiFi link to an ESP32 camera in the head.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @assadollahi (README.md), under BSD-3-Clause.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Pimoroni Servo 2040 (RP2040) as the body servo controller.
- 18 servos across ankles, knees, hips, arms, pelvis and head; servo model not yet settled in the documents.
- ESP32 camera in the head, out of scope for now.
- UBEC/BEC 10 A for servo voltage and a small 5 V BEC for controller logic.
- Battery supplying the power rails; exact battery not yet documented.
- WS2812 LED bar on the controller for status.
Connections
- Servo rail and 5 V logic rail are separate; the Separate USB and Ext. Power trace is cut, so the board only boots from USB or from the 5 V/GND solder pads beside the Qwiic connector.
- Servo headers numbered 1 to 18 on the silkscreen map to software channels 0 to 17.
- Controller connects to the PC by USB-C at 115200 baud.
- Servo channel-to-joint mapping is defined in software/servoMap.json.