Roomi
An open-source autonomous robot arm that cleans, makes beds and organizes rooms in hotels and homes.
- Home
- Open source
- Works with AI
- 3D printable
Suggested by Robotheca, created by @jadechoghari (opens in a new tab), from github.com/jadechoghari/roomi (opens in a new tab). Pinned to commit fa4d4bf (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
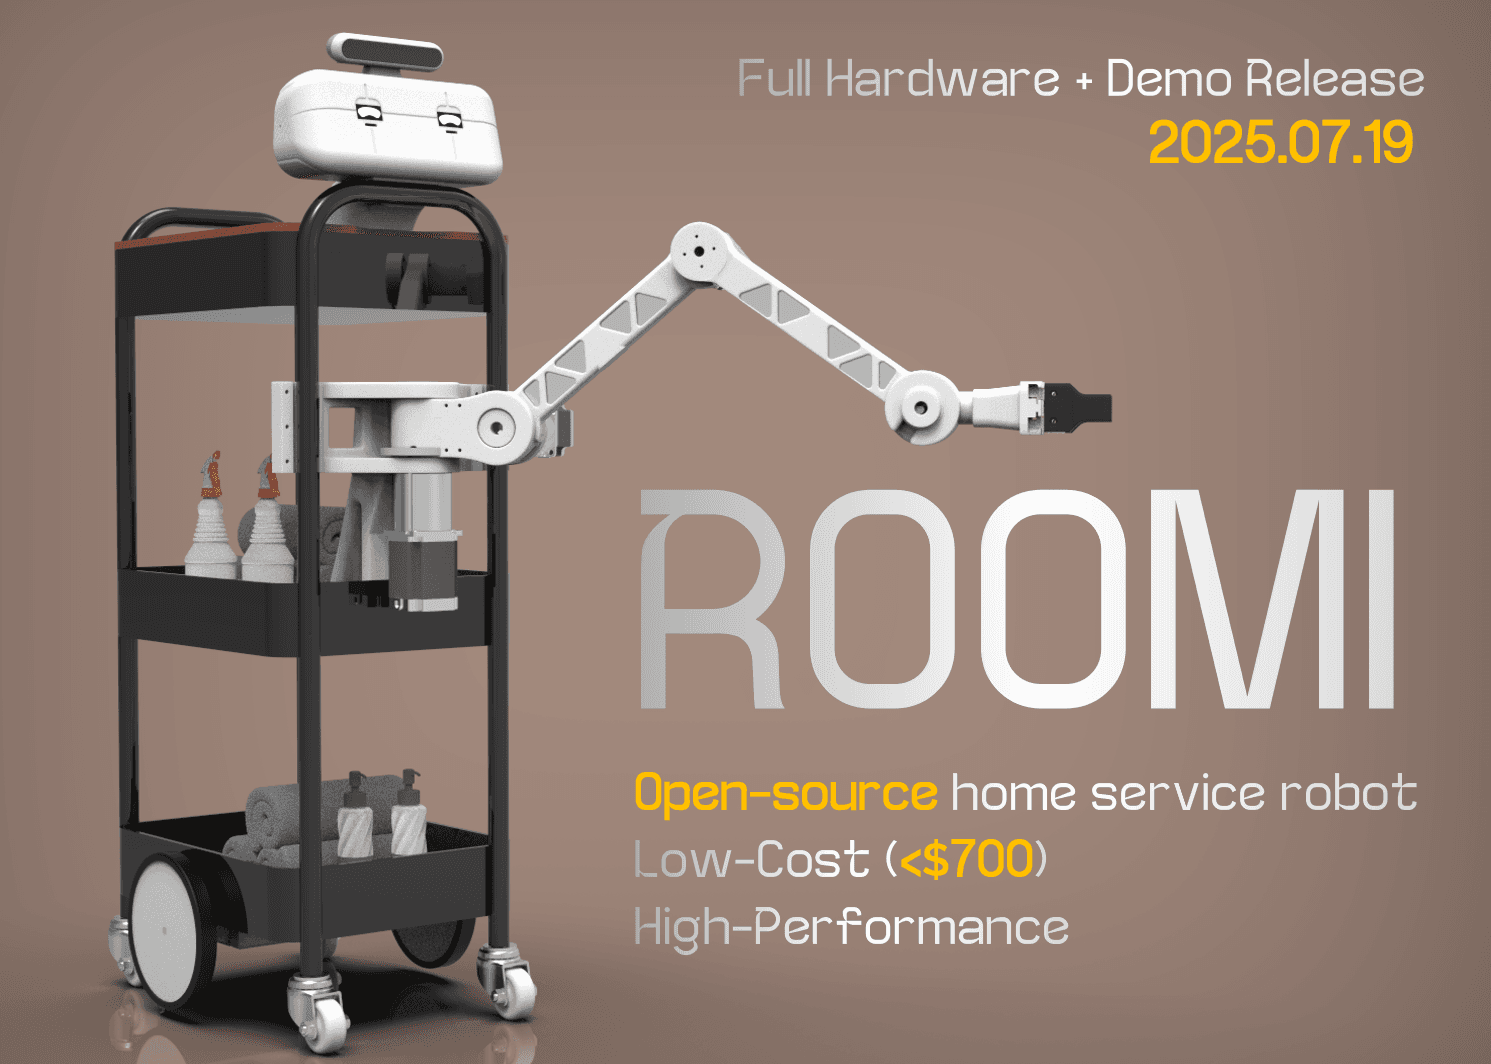
3D preview converted from github.com/jadechoghari/roomi at fa4d4bf, under Apache-2.0. View the original files from GitHub (9.8 MB) (opens in a new tab)
- Degrees of freedom
- 5
What it can do
Written by Robotheca from the project's documents.
- Autonomous cleaning and housekeeping tasks such as cleaning, making beds and organizing, per the README.
- Five degree-of-freedom robot arm with high torque and long reach.
- Teleoperation using a modified SO100 arm, plus imitation learning and demonstration collection.
- Simulation and teleoperation in MuJoCo via provided entry-point scripts.
- Friendly light-up OLED eyes.
Works with AI
Found by Robotheca in the project's files at commit fa4d4bf, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
“Teleoperation using a modified SO100 arm, plus imitation learning and demonstration collection.”
Robotheca's notes: What it can do
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Buy the parts from the Bill of Materials
- 23D print the parts
- 3Assemble Roomi
- 4Run the software
The guide appears here as you scroll.
Guide by @jadechoghari (README.md), under Apache-2.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- RP2040 microcontroller boards running custom tuned PID controllers, one per joint.
- AS5600 encoders for joint position sensing.
- OLED display used for the eyes.
- Modified SO100 arm used as the teleoperation input device.
Connections
- The documents do not describe how the parts are wired together.