Zooids
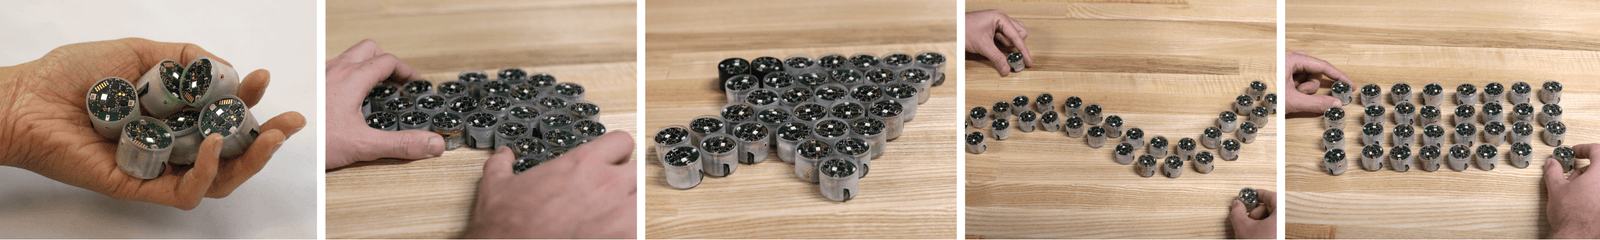
Small open-source wheeled micro robots, 26 mm in diameter, that form a tabletop swarm user interface for display and interaction.
- Other
- Open source
- 3D printable
Suggested by Robotheca, created by @ShapeLab (opens in a new tab), from github.com/ShapeLab/SwarmUI (opens in a new tab). Pinned to commit 8b48e53 (opens in a new tab).
- Hardware license
- CC-BY-SA-4.0 (opens in a new tab)
- Software license
- CC-BY-SA-4.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (18 files marked executable, 42 programs or installers, 23 firmware images)
- Software/Applications/Examples/Zooid_Bezier/bin/assimp.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/fmodex.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/fmodexL.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/FreeImage.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/freetype.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/glut32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/libeay32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/ssleay32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/Zlib.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Bezier/bin/Zooid_Bezier.exe (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/assimp.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/fmodex.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/fmodexL.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/FreeImage.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/freetype.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/glut32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/libeay32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/ssleay32.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/Zlib.dll (opens in a new tab)
- Software/Applications/Examples/Zooid_Scatterplot/bin/Zooid_Scatterplot.exe (opens in a new tab)
- and 63 more
Photo and 3D model
3D preview converted from github.com/ShapeLab/SwarmUI at 8b48e53, under CC-BY-SA-4.0. View the original files from GitHub (2.4 MB) (opens in a new tab)
- Weight
- 12 g
- Height
- 21 mm
What it can do
Written by Robotheca from the project's documents.
- Small wheeled tabletop robots, about 26 mm in diameter, that can display and receive touch input as a swarm.
- Each robot moves to positions using PID position control, or PID combined with HRVO collision avoidance.
- Robots receive new goal positions at 60 Hz and slow and stop near the final goal, then orient as commanded.
- Robot positions are tracked optically by projecting a sequence of gray-coded patterns onto a flat surface.
- Application software is written in C/C++ with OpenFrameworks and communicates with a simulation and server layer over sockets.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @ShapeLab (README.md), under CC-BY-SA-4.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Custom robot board with a microcontroller, motor-driven wheels, and a 100 mAh LiPo battery.
- Flexible electrode on each robot for capacitive touch sensing.
- NRF24L01+ radio chip on each robot for communication with the main computer.
- Photodiodes on each robot that decode the projected pattern for position.
- Radio base station, and a DLP LightCrafter 4500 projector running at 3000 Hz for tracking.
Connections
- Robots communicate with the main computer through a radio base station using the NRF24L01+ chip.
- The projector connects to the computer via USB and is controlled through its GUI.
- The repository includes PCB design files for the robot and receiver boards, but the documents do not describe their connections in detail.
Schematics, boards and diagrams
- Hardware/3D Model/Robot/Touch Circuit.pdfDiagram
- Hardware/Charging Station/PCB GerbersGerber (PCB manufacturing)
- Hardware/PCB/Altium Design Files/v1.3/Zooid/ZooidMicrocontroller.SchDocAltium
- Hardware/PCB/Altium Design Files/v1.3/Zooid/ZooidPCB.PcbDocAltium
- Hardware/PCB/Altium Design Files/v1.3/Zooid/ZooidPeripherals.SchDocAltium
- Hardware/PCB/Altium Design Files/v1.3/Zooid/ZooidRadio.SchDocAltium
- Hardware/PCB/Altium Design Files/v1.3/ZooidReceiver/ZooidReceiverPCB.PcbDocAltium
- Hardware/PCB/Altium Design Files/v1.3/ZooidReceiver/ZRMicrocontroller.SchDocAltium
- Hardware/PCB/Altium Design Files/v1.3/ZooidReceiver/ZRPeripherals.SchDocAltium
- Hardware/PCB/Altium Design Files/v1.3/ZooidReceiver/ZRRadio.SchDocAltium
- Hardware/PCB/Gerbers/ZooidGerber (PCB manufacturing)
- Hardware/PCB/Gerbers/ZooidReceiverGerber (PCB manufacturing)
- Hardware/PCB/PDF/Schematics/Zooid_schematics.pdfDiagram
- Hardware/PCB/PDF/Schematics/ZooidReceiver_schematics.pdfDiagram