EWU ASME SDC 2026 Robot
A remotely controlled garbage truck robot built for the 2026 ASME Student Design Competition that collects and dumps waste using a servo-driven arm and rotary dumping bucket.
- Other
- Open source
- arduino
Suggested by Robotheca, created by @SethHibpshman (opens in a new tab), from github.com/SethHibpshman/EWU-ASME-SDC-2026-Robot (opens in a new tab). Pinned to commit c2f365e (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
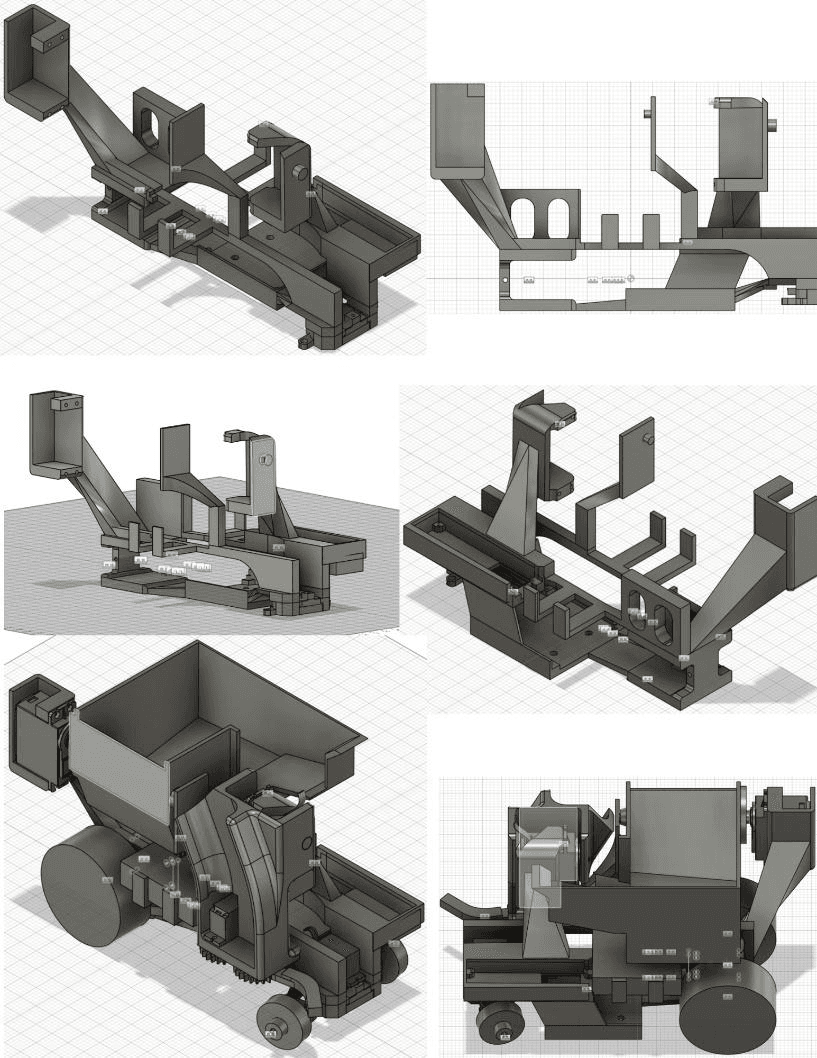
Photo
What it can do
Written by Robotheca from the project's documents.
- Remotely teleoperated garbage truck robot controlled by a FlySky FS-iA6B radio transmitter and receiver
- Rear wheel drive with two geared yellow DC motors driven forward and reverse through a brushed DC H-bridge
- Front servo steering through 3D printed control arms with a clamped safe pulse range
- Servo-driven arm with gripper and shoulder joint that slides material into a rotary dumper
- Rotary dumping bucket tipped by a servo with analog control to empty into a large receptacle
- Neutral deadband and exponential throttle smoothing to reduce drift and current spikes
- Failsafe that returns outputs to neutral on signal loss, stopping the motors
Bill of materials
10 parts10 of 10 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| Bill of Materials | ||||
| 1 | Arduino Nano Every | 1 $18.00 | $18 total≈ €16 | – |
| 2 | FS-iA6B/X TX/RX | 1 $45.00 | $45 total≈ €40 | – |
| 3 | Geared DC Motor | 2 $1.00 | $2 total≈ €2 | – |
| 4 | AA Battery Cage | 1 $8.00 | $8 total≈ €7 | – |
| 5 | Servo (SG90) | 1 $2.00 | $2 total≈ €2 | – |
| 6 | Servo (MG995) | 2 $4.50 | $9 total≈ €8 | – |
| 7 | PCB | 1 - | $5 total≈ €4 | – |
| 8 | PDB | 1 - | $2 total≈ €2 | – |
| 9 | Misc. Wires | – - | $2 total≈ €2 | – |
| 10 | 3D Printed Parts | – - | $4 total≈ €4 | – |
≈ € amounts use the ECB reference rate of 23 Oct 2026, for comparison only.
Parts total: $97. Read from README.md at the pinned commit.
Build guide
The guide appears here as you scroll.
Guide by @SethHibpshman (README.md), under GPL-3.0-only.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino Nano Every microcontroller
- FlySky FS-iA6B receiver with iBUS serial output and matching transmitter
- Brushed DC H-bridge motor driver
- Two geared yellow DC drive motors
- SG90 and MG995 servos for steering, gripper, shoulder and dumper
- LM2596 buck converter providing a 5 V logic rail
- Six NiMH AA cells in series, about 7.2 V nominal, in a battery cage
- Four 1000 µF electrolytic capacitors giving 4000 µF of bulk capacitance
- Custom KiCad control PCB and power distribution board with a physical power switch
Connections
- Battery pack feeds a power switch, then the power distribution board
- Raw battery voltage goes directly to the H-bridge and high torque servos, avoiding the regulator
- Raw battery voltage also reaches the LM2596 buck converter on the control PCB through a soldered harness
- The buck converter supplies 5 V to the Arduino, the receiver and the low torque servos
- Arduino PWM outputs drive the H-bridge and the servos; the H-bridge drives the two DC motors
- Receiver channels map to pins: CH1 steering on D2, CH2 drive on D9 and D10, CH3 auxiliary on D4, CH5 gripper on D3, CH6 shoulder on D5
- Power distribution board and control PCB are joined by two soldered wire harnesses
Cables and connectors
From the parts list.
- Misc. Wires