Open source · free files
Koriobots
Other · Intermediate
- Score
- Buildability 98 out of 100
- Cost
- $972.06≈ €866
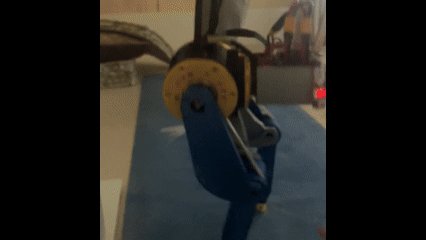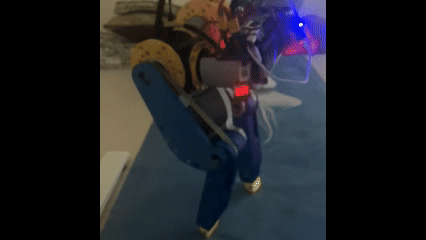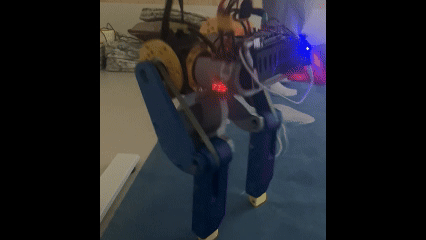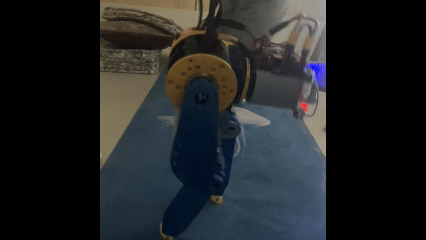
3D preview converted from github.com/jiz322/tiptoe-biped at c91dedb, under CC-BY-4.0. View the original files from GitHub (3.7 MB) (opens in a new tab)
Other
A 6-DOF point-foot biped with no ankles, built from printed parts and RobStride actuators, trained with PPO in Isaac Lab to stand up, step and sit on hardware.
Work in progress: the creator is still working on it.
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Suggested by Robotheca, created by @jiz322 (opens in a new tab), from github.com/jiz322/tiptoe-biped (opens in a new tab), pinned to commit c91dedb (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.
18 of 18 parts shown
| Item | Part | Qty | Unit price | Amount | Source |
|---|---|---|---|---|---|
| Priced lines | |||||
| 01 | RobStride RS01 | 4 599 | – | – | – |
| 02 | RobStride EL05 | 2 299 | – | – | – |
| 03 | Raspberry Pi 5 | 1 724 | – | – | – |
| 04 | microSD card | 1 289 | – | – | – |
| 05 | WHEELTEC H30 IMU | 1 254 | – | – | – |
| 06 | MCP2518FD SPI CAN module | 1 40 | – | – | – |
| 07 | 4S 6500 mAh semi-solid LiPo | 2 381 | – | – | – |
| 08 | Matek PDB-HEX | 1 98 | – | – | – |
| 09 | RA5008 crossed-roller bearing (hip roll) | 2 140 | – | – | – |
| 10 | HTD 5M timing belt | 2 30 | – | – | – |
| 11 | 3D-print filament | – | – | – | – |
| 12 | Screws, nuts, heat-set inserts | – | – | – | – |
| Unpriced lines — TBD | |||||
| 13 | ELRS receiver | 1 | – | – | – |
| 14 | Pulleys 22T and 30T, HTD 5M | 2 | – | – | – |
| 15 | Other bearings | – | – | – | – |
| 16 | Steel parts | 2 | – | – | – |
| 17 | Ball feet | 2 | – | – | – |
| 18 | Wiring | – | – | – | – |
18 of 18 needed parts have no price in the source, so there is no parts total.
60/100
Buildable with some effort
How complete the published files are for rebuilding this robot, measured by Robotheca at commit c91dedb. It isn't a rating of the robot.
The guide appears here as you scroll.
Guide by @jiz322 (README.md), under CC-BY-4.0 (hardware) and MIT (software).
From the parts list.
Found by Robotheca in the project's files at commit c91dedb, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Ships trained model files: r1r_3150.pt and 1 more
In the project files: control/r1r_3150.ptUses reinforcement learning: rsl_rl
In the project files: RL/scripts/rsl_rlRobotheca doesn't review code. Read it before running it.
Written by Robotheca from the project's documents, not by its creator.
No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.
Every file of the project, at commit c91dedb.
Questions and improvements go to the creator's repository.
For the creator: two badges that link back here. The second always shows this page's current label and score.

Markdown (one click selects it)
[](https://robotheca.org/robots/tiptoe) [](https://robotheca.org/robots/tiptoe)
Open source · free files
Other · Intermediate
Open source · free files
Other · Intermediate

Open source · free files
Other · Advanced
 3D render
Open source · free files
Other · Advanced
Open source · free files
Other · Intermediate
≈ € values are approximate, converted at the ECB euro reference rate of 5 Nov 2026. The creator's original price always comes first.