Atlas Rover Mk.1
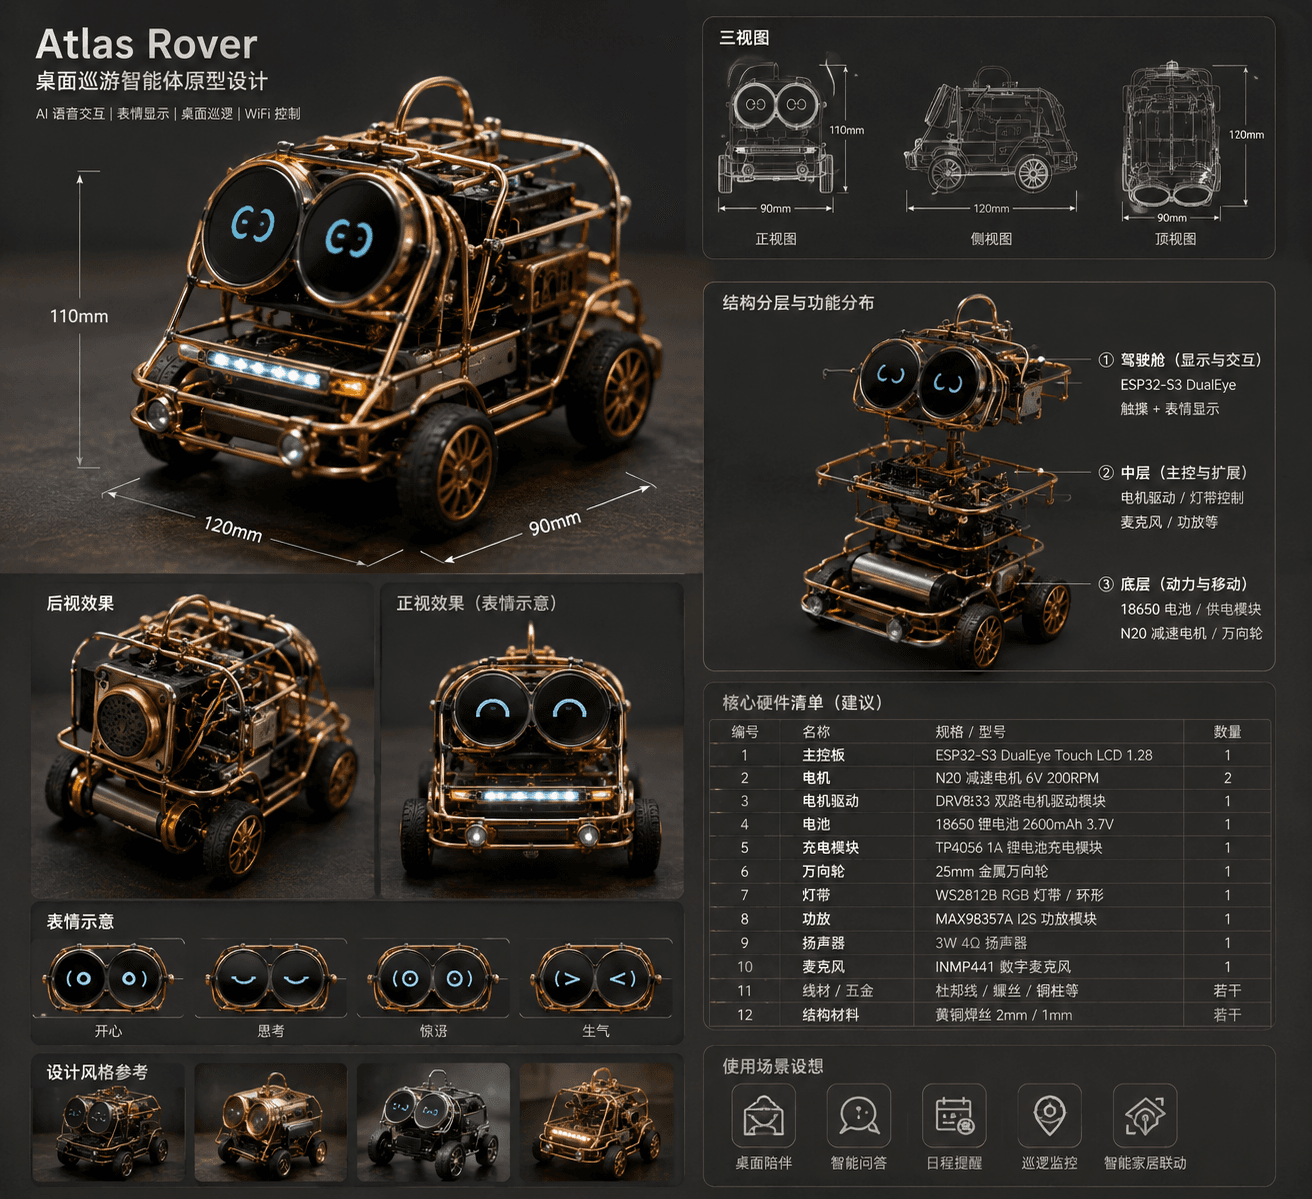
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
- Wheeled
- Open source
- Work in progress
- Works with AI
- 3D printable
Suggested by Robotheca, created by @davidwang960707-gpu (opens in a new tab), from github.com/davidwang960707-gpu/atlas-rover-mk1 (opens in a new tab). Pinned to commit 675d6f2 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo
What it can do
Written by Robotheca from the project's documents.
- Moves with four N20 motors using left/right differential steering
- Controlled via UART commands prefixed with AR1,
- Displays dual 1.28-inch round screens for eyes with expressions
- Supports touch input on the screens
- Accepts voice commands through MimiClaw integration
- Runs a web management interface for configuration and control
- Supports WS2812B RGB lighting with brightness control
- Plays audio through a small speaker
Works with AI
Found by Robotheca in the project's files at commit 675d6f2, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Uses a large language model
In the project files: firmware/dualeye/main/atlas_llm_client.c
Bill of materials
22 parts22 of 22 parts shown
22 of 22 parts have no price in the source, so there is no parts total. Read from Atlas_Rover_Mk1_制造图纸包_V1.0/采购清单_Atlas_Rover_Mk1_V1.0.csv at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Prepare copper wire frame and assemble mechanical structure
- 2Install Waveshare ESP32-S3 DualEye dual circular screens
- 3Assemble N20 motor chassis with DRV8833 driver
- 4Wire and connect DualEye to XIAO ESP32C3 chassis board via UART
- 5Flash and calibrate DualEye firmware for facial expressions and voice interactio
- 6Flash and test XIAO ESP32C3 chassis firmware for motor control
- 7Configure Wi-Fi and test voice interaction and dual-screen display
The guide appears here as you scroll.
Guide by @davidwang960707-gpu (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
More guides
- Atlas_Rover_Mk1_制造图纸包_V1.0/接线说明_Atlas_Rover_Mk1_V1.0.mdin English
- Atlas_Rover_Mk1_制造图纸包_V1.0/组装模拟与效果确认_Atlas_Rover_Mk1_V1.0.mdin English
- Atlas_Rover_Mk1_制造图纸包_V1.0/装配指南_Atlas_Rover_Mk1_V1.0.mdin English
- Atlas_Rover_Mk1_制造图纸包_V1.0/详细组装与接线手册_Atlas_Rover_Mk1_V1.0.mdin English
- Atlas_Rover_Mk1_制造图纸包_V1.0/说明.mdin English
- docs/DualEye固件V0.1设计说明_Atlas_Rover_Mk1.mdin English
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-S3-DualEye-Touch-LCD-1.28 main controller with dual round screens
- Seeed Studio XIAO ESP32C3 chassis control board
- Two DRV8833 dual H-bridge motor driver boards for N20 motors
- N20 metal gear motors with 64T steel gear cores
- 18650 lithium battery with battery holder
- 5V step-up module for motor and lighting power
- WS2812B addressable RGB LED strip or ring for lighting
- AHCT/HCT level shifter for WS2812B data line
- Small speaker for audio output
- PCA9685 I2C PWM expander (optional)
Connections
- 18650 battery positive to ESP32 battery input and motor power switch then to 5V step-up module input
- 18650 battery negative to ESP32 GND, XIAO GND, DRV8833 GND, and WS2812B GND (common ground)
- 5V step-up output to DRV8833 VM and WS2812B 5V input
- ESP32 DualEye UART TXD (Pin10) to XIAO GPIO20 RX
- ESP32 DualEye UART RXD (Pin9) to XIAO GPIO21 TX
- ESP32 DualEye GND to XIAO GND
- XIAO GPIO4/5/6/7 to DRV8833 AIN1/AIN2/BIN1/BIN2 (parallel for front and rear drivers)
- DRV8833 AOUT1/AOUT2 and BOUT1/BOUT2 to front N20 motors
- DRV8833 AOUT1/AOUT2 and BOUT1/BOUT2 to rear N20 motors
- ESP32 GPIO to AHCT/HCT level shifter input for WS2812B data
Cables and connectors
From the parts list.
- JST/杜邦线套装 × 1

