Bambot
An open-source, low-cost humanoid robot designed for AI experimentation and education.
- Humanoid
- Open source
- Work in progress
- Works with AI
- LeRobot
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @timqian (opens in a new tab), from github.com/timqian/bambot (opens in a new tab). Pinned to commit eba23eb (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
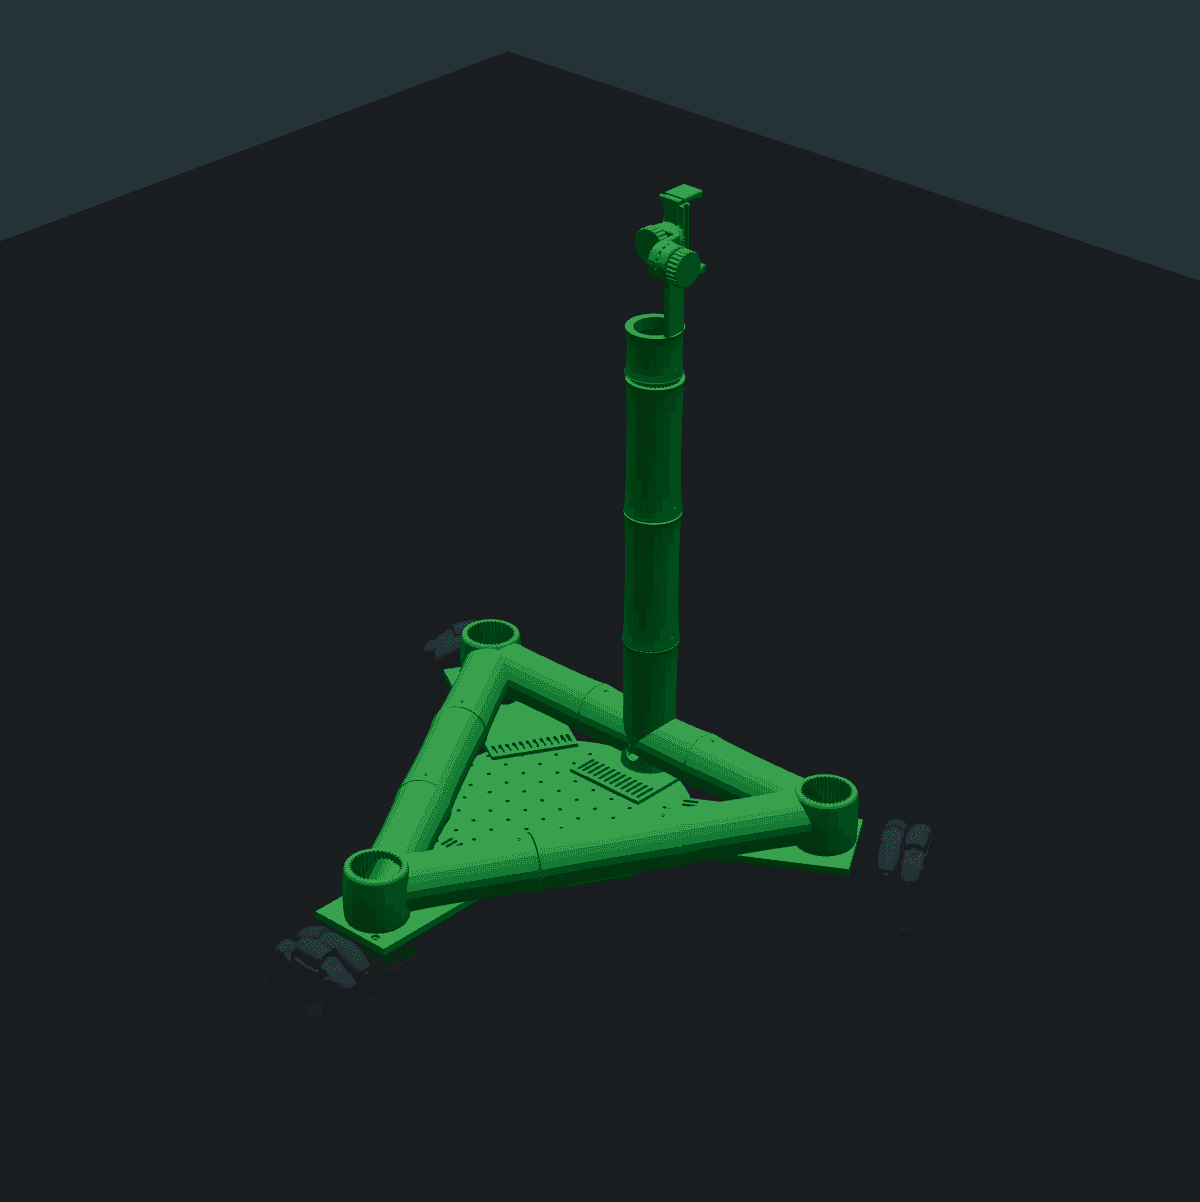
3D preview converted from github.com/timqian/bambot at eba23eb, under Apache-2.0. View the original files from GitHub (20.1 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Moves on three omni wheels
- Humanoid upper body with 15 servos for arms and head
- Controlled via web browser or SDK
- Supports teleoperation with extra hardware
- Runs AI models for perception and control
Works with AI
Found by Robotheca in the project's files at commit eba23eb, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Runs LeRobot
Stated in robot.yaml“Runs AI models for perception and control”
Robotheca's notes: What it can do
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @timqian (README.md), under Apache-2.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- 15 STS3215 servos (12V version)
- Motor control board (Waveshare integrated control circuit)
- 3 omni wheels (4 inch)
- Type C to DC power cable (12V/5V)
- 20000mAh power bank with USB PD
- Camera module (optional for teleoperation)
- Joycon controller (teleoperation, upcoming)
- M2 M3 M4 screw set
Connections
- Servos connected to motor control board via 5264 connectors and long wires
- Motor control board powered by Type C to DC cable from power bank
- USB connection from computer to motor control board for control