DreamingRobot
A quadruped (four-legged) walking robot built from 3D printed parts and Robotis Dynamixel AX-12 servos, driven by a Jetson Nano.
- Quadruped
- Open source
- Work in progress
- 3D printable
Suggested by Robotheca, created by @bakchanyeop (opens in a new tab), from github.com/bakchanyeop/DreamingRobot (opens in a new tab). Pinned to commit 594d6ca (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
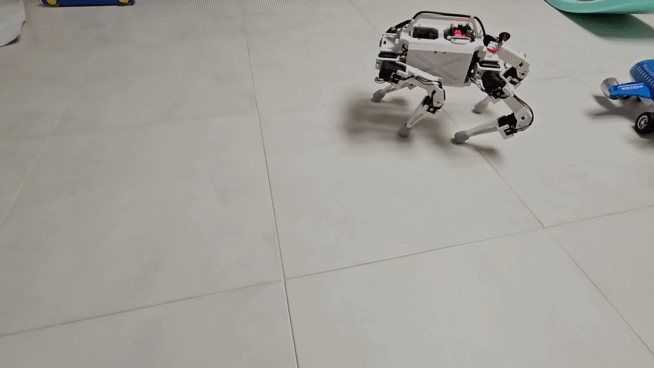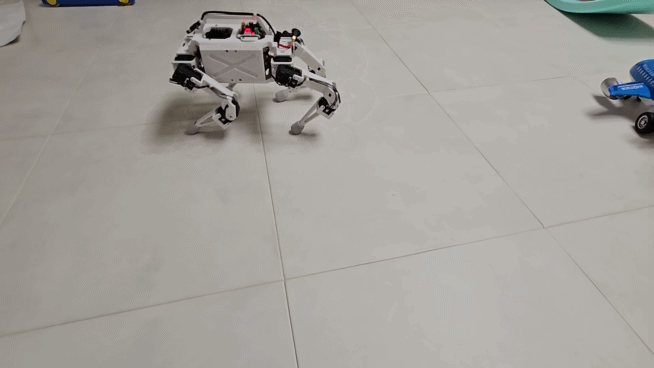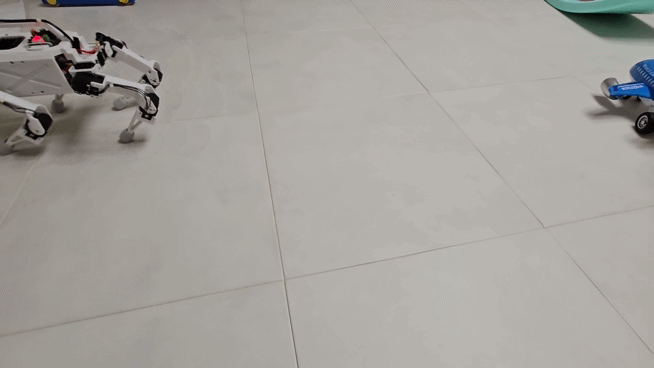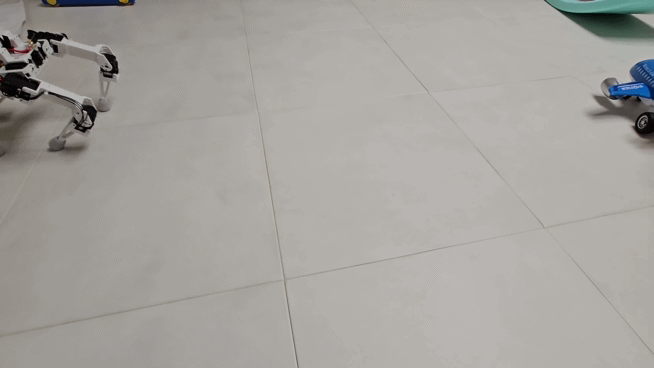
3D preview converted from github.com/bakchanyeop/DreamingRobot at 594d6ca, under GPL-3.0-only. View the original files from GitHub (7.9 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Quadruped (four-legged) walking robot built with Robotis Dynamixel AX-12 servos.
- Walking gait shown in a demo video, though the video predates the current model.
- Joystick is listed among the accessories, suggesting manual control.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @bakchanyeop (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Robotis Dynamixel AX-12 servo motors for the legs.
- Jetson Nano 2GB developer board as the main computer.
- U2D2 converter for communicating with the Dynamixel servos.
- XH-M609 module for lithium polymer over-discharge protection.
- 11.1V lithium polymer battery (30C).
- Power switch and a joystick.
Connections
- The U2D2 converter links the Jetson Nano to the Dynamixel servo bus.
- The XH-M609 module sits between the lithium polymer battery and the power system to prevent over-discharge.