Project files
- quadrobot51 files
- Assemble.jpg96 KB
- LICENSE35 KB
- Randering_GBOT.png253 KB
- README.md2 KB
- Walk img.gif798 KB


README.md
Machine-translated by Robotheca from the original in Korean (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
DreamingRobot
본 저작권은 꿈꾸는 로봇에 있습니다!
Image (opens in a new tab) https://www.youtube.com/@Dreamingrobot (opens in a new tab) ▲ 꿈꾸는 로봇 Youtube 주소
안녕하세요! 꿈꾸는 로봇 꿈봇입니다.
본 깃허브는 제가 제작하는 과정의 코드와 STL 파일들을 올릴 예정입니다.
5개월간 짬짬이 만들은 로봇입니다.
현재 4족 로봇을 로보티즈 다이나믹셀 AX12로 제작중입니다.
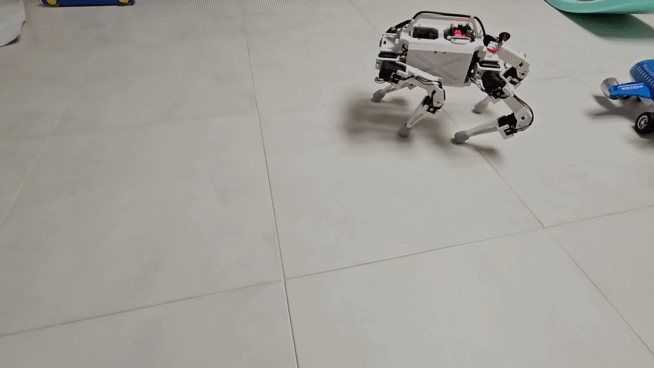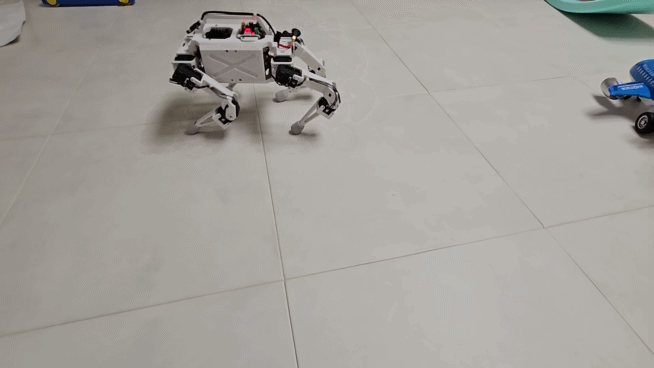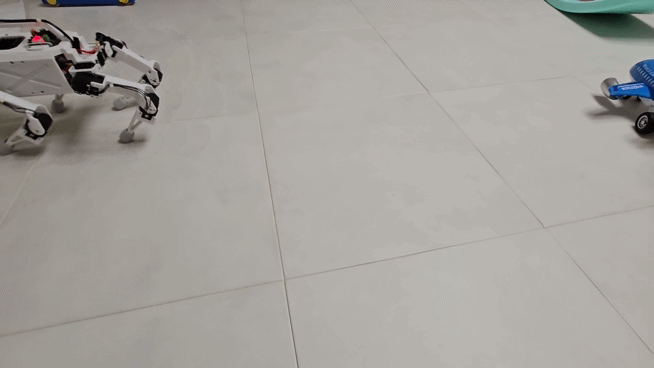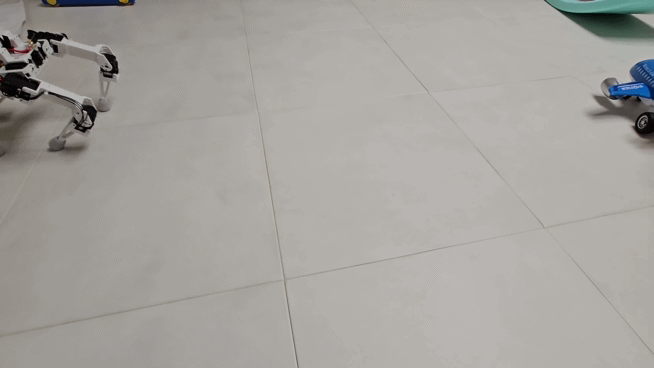 ▲ 보행 영상(이전 영상이라 지금 모델하고는 조금 차이가 있습니다)
Model File
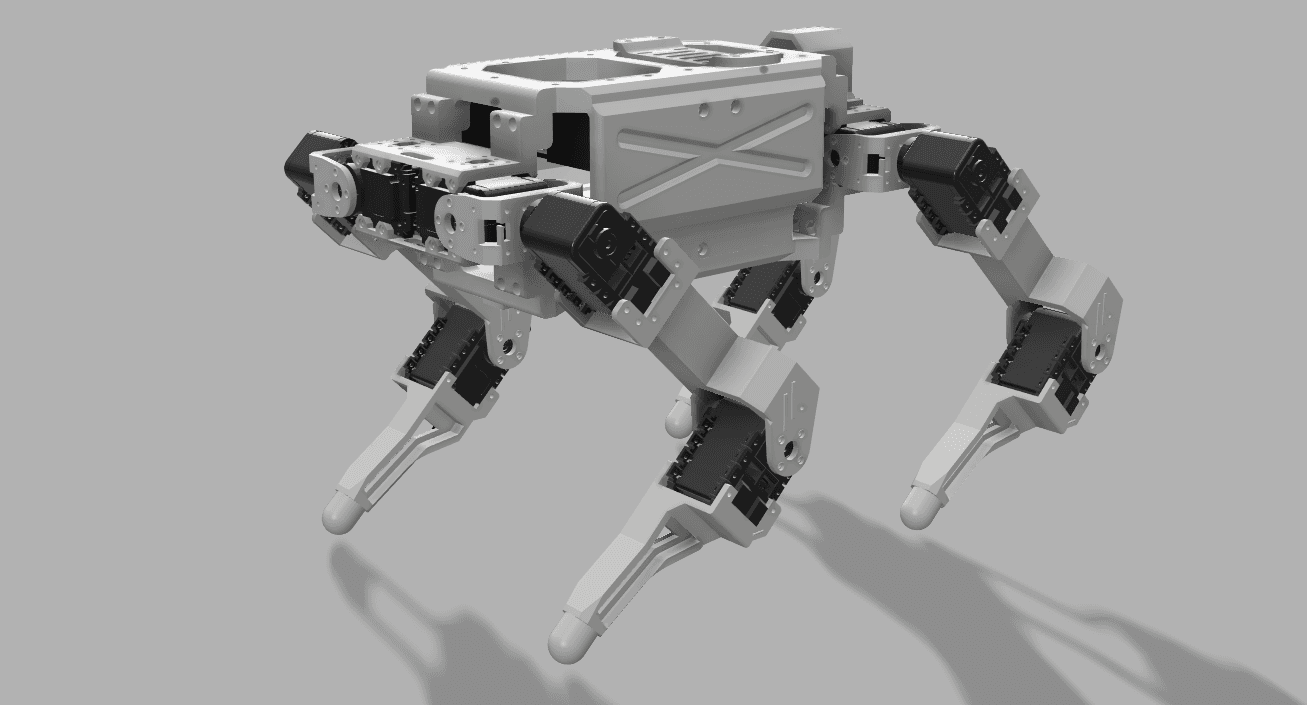
▲ Final assembly rendering image
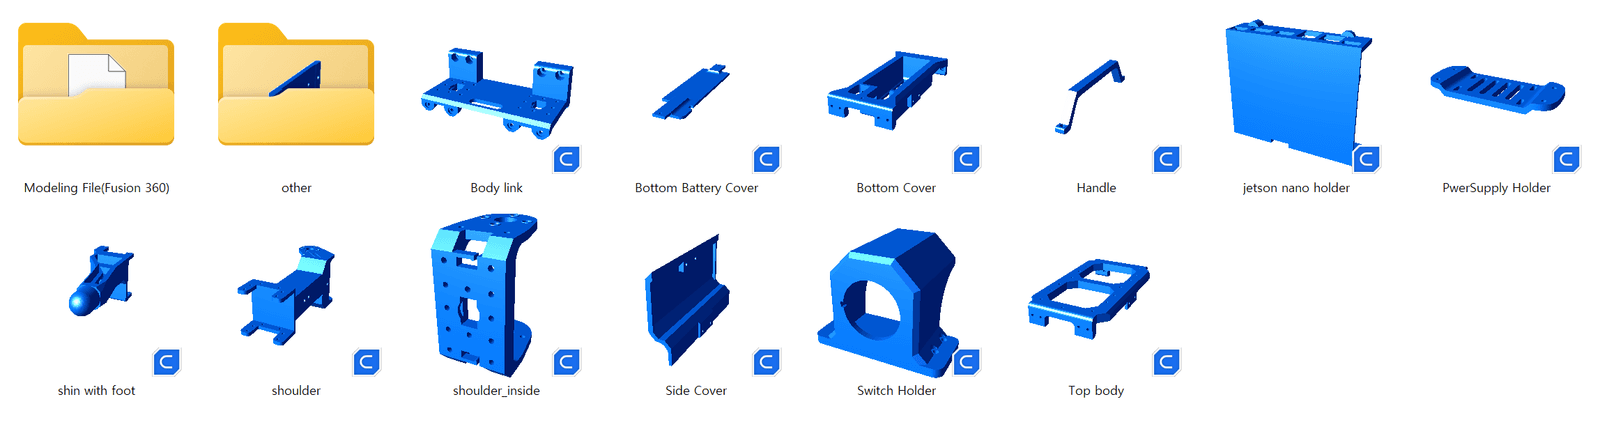 ' The model files are as shown in the image above, and the quantities are as follows.
Shoulder and Shin with foot are printed for both sides using the Mirror function in Cura.
| No. | Title | Qty |
|---|---|---|
| 1 | Body link | 4EA |
| 2 | Bottom Battery Cover | 1EA |
| 3 | Bottom Cover | 1EA |
| 4 | Handle | 1EA |
| 5 | jetson nano(ver.2GB Dev) holder | 1EA |
| 6 | shoulder(right) | 2EA |
| 7 | shoulder(left) | 2EA |
| 8 | Shin with foot(right) | 2EA |
| 9 | Shin with foot(left) | 2EA |
| 10 | Sude Civer | 2EA |
| 11 | Switch Holder | 1EA |
| 12 | Top Body | 1EA |
| 13 | shoulder_inside | 1EA |
부속품
| 순번 | 제목 | 수량 |
|---|---|---|
| 1 | M2x8 Bolt Nut Set | 52 EA |
| 2 | M2x6 | 48 EA |
| 3 | M3x10 Bolt nut set | 8 Set |
| 4 | M3x10 Bolt | 22 EA |
| 5 | U2D2 Converter | 1 EA |
| 6 | Jetson Nano 2GB version | 1 EA |
| 7 | XH-M609 (Lithium Polymer discharge protection) | 1 EA |
| 8 | Switch | 1 EA |
| 9 | Lithium Polymer 30C (11.1V) | 1 EA |
| 10 | Joystick | 1 EA |
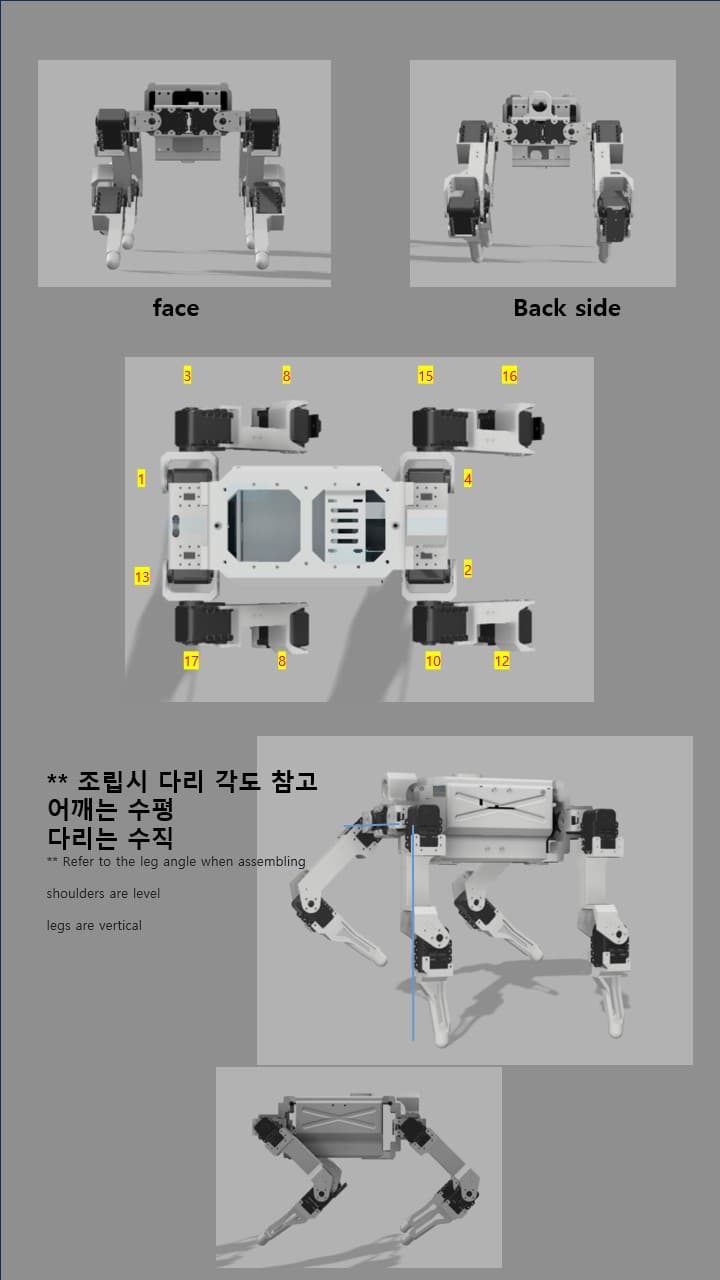
Assembly Instructions
Files by @bakchanyeop, at commit 594d6ca, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.