OpenEAI-Arm
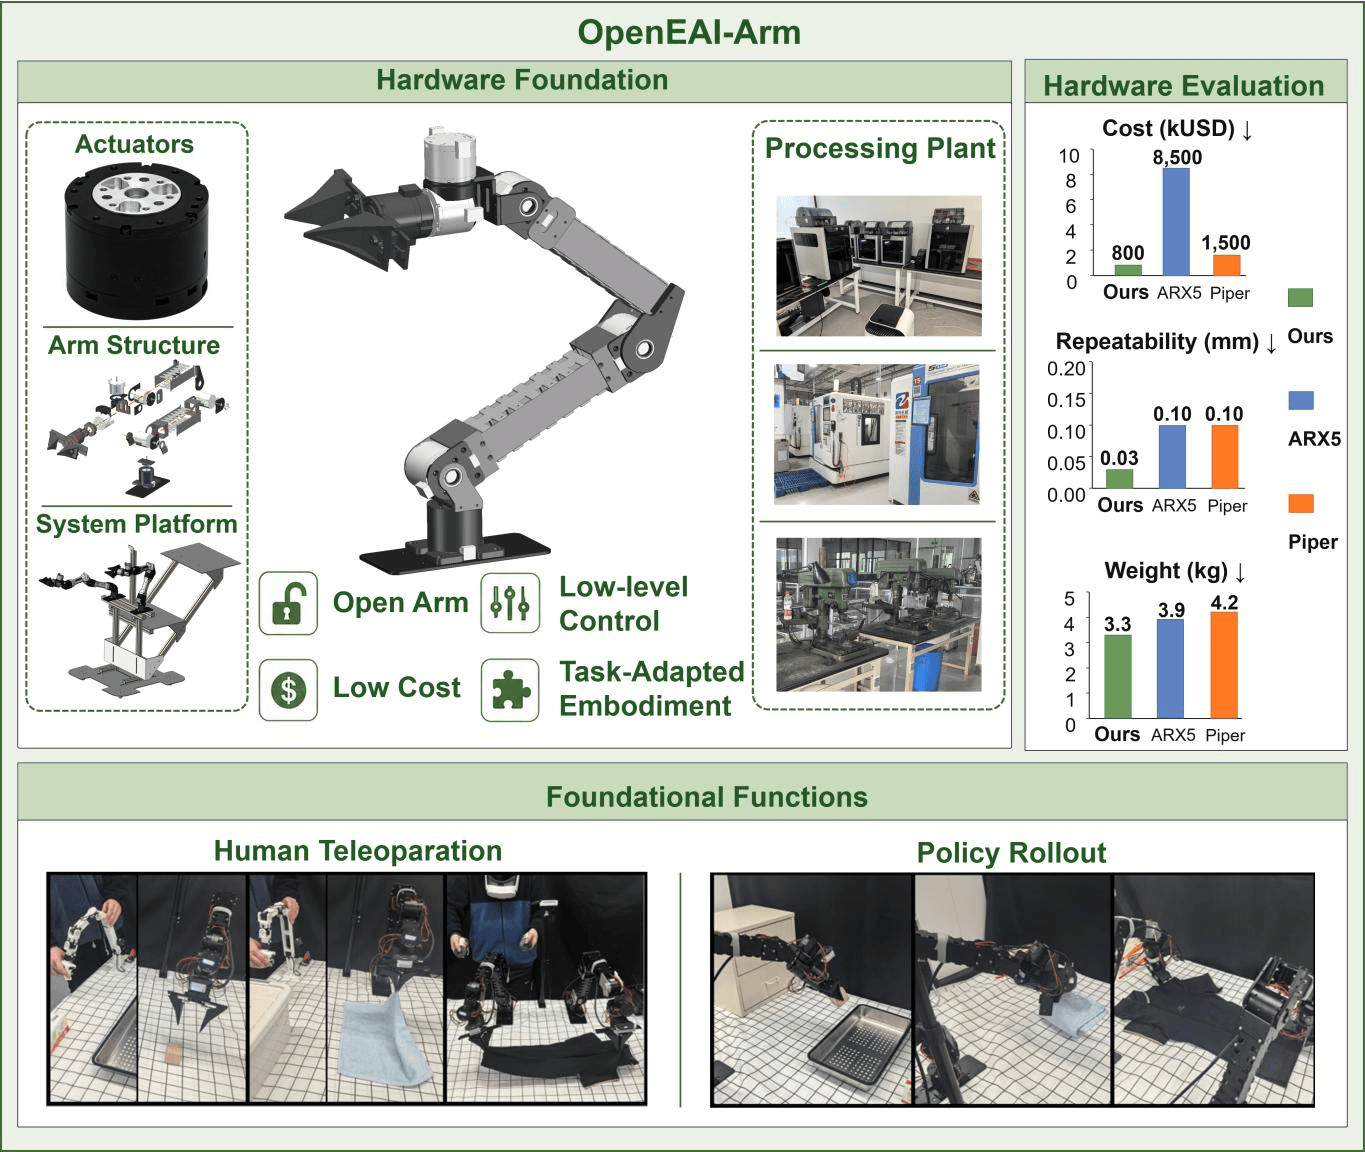
A low-cost, open-source 6-DoF desktop robot arm with an independently controlled end-effector channel for embodied-AI research and VLA data collection.
- Robot arm
- Open source
- ROS 2
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @eai-yeslab (opens in a new tab), from github.com/eai-yeslab/OpenEAI-Arm (opens in a new tab). Pinned to commit be3ea1e (opens in a new tab).
- Hardware license
- BSD-3-Clause (opens in a new tab)
- Software license
- BSD-3-Clause (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (3 scripts, 1 program or installer)
Photo and 3D model
Try it in the browser
3D preview converted from github.com/eai-yeslab/OpenEAI-Arm at be3ea1e, under BSD-3-Clause. View the original files from GitHub (30.7 MB) (opens in a new tab)
- Degrees of freedom
- 6
- Power
- 420 W
- Reach
- 636.7 mm
- Weight
- 3.3 kg
- Payload
- 2 kg
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @eai-yeslab (README.md), under BSD-3-Clause.