JAT Self-Driving Car (WRO 2025)
An autonomous 1/24-scale racing car built by a three-student team for the WRO 2025 Future Engineers challenge, driving laps and parallel parking using a camera and LiDAR.
- Self-driving 1:10
- Open source
- 3D printable
Suggested by Robotheca, created by @Jayden-boop (opens in a new tab), from github.com/Jayden-boop/WRO-2025 (opens in a new tab). Pinned to commit 5f06ce5 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
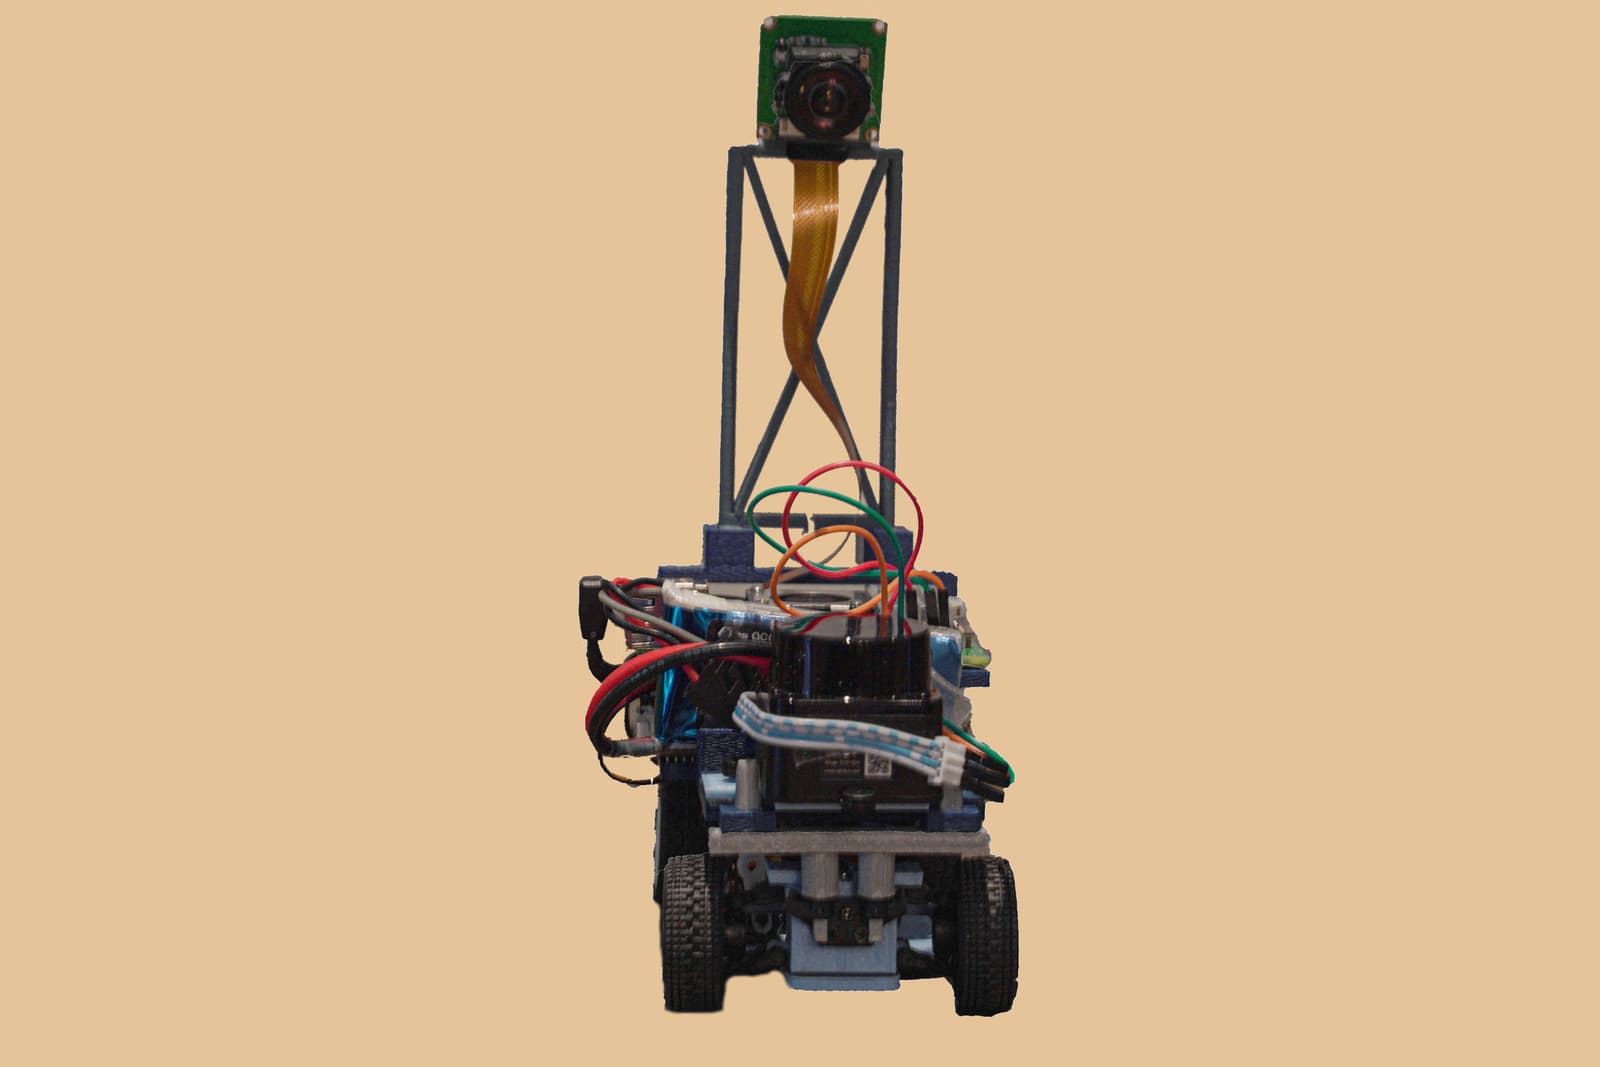
3D preview converted from github.com/Jayden-boop/WRO-2025 at 5f06ce5, under MIT. View the original files from GitHub (21.5 MB) (opens in a new tab)
- Power
- 120 W
- Weight
- 90 g
What it can do
Written by Robotheca from the project's documents.
- Drives autonomously around a randomized track for three laps while avoiding walls, using camera and LiDAR input.
- Follows lanes by steering around red and green pillars (red keep right, green keep left) in the obstacle challenge.
- Performs a parallel parking maneuver using LiDAR spatial data once the parking sequence starts.
- Steers with a PID controller that outputs precise servo angles for path following.
- Runs for roughly 30-40 minutes on one battery during obstacle challenge testing, including image and LiDAR processing.
Bill of materials
12 parts12 of 12 parts shown
≈ € amounts use the ECB reference rate of 16 Oct 2026, for comparison only.
Parts total: $790.56. Read from README.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Assemble the chassis foundation
- 2Mount the platform and electronics
- 3Integrate the sensors
- 4Integrate the drive system
- 5Assemble the custom steering system
- 6Install the wheels and tires
- 7Wire the system
- 8Perform final assembly and testing
The guide appears here as you scroll.
Guide by @Jayden-boop (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi 5 (8GB) as the central processing unit.
- Pi 5 Expansion Board for power distribution, PWM outputs and regulated voltage.
- Pi Camera module (5MP, 1080p) for color-based pillar and wall detection.
- LD19 D500 LiDAR for distance measurement, used for parking.
- Furitek Micro Komodo brushless motor driven by a Furitek Lizard Pro ESC.
- HS-5055MG digital metal-gear servo for steering.
- Gens Ace 2S LiPo battery, 7.4V, 1300mAh, 45C.
- Snap-in rocker power switch.
Connections
- The Pi 5 Expansion Board is the central hub that distributes power and signals to the Pi, sensors and servos.
- The battery feeds the expansion board, which provides regulated 5V/6.5V power to the Pi, sensors and servos.
- The camera connects directly to the Pi over its CSI interface.
- The LiDAR communicates with the Pi over UART.
- The steering servo and the motor ESC are driven by PWM outputs from the expansion board.
- A wiring schematic is provided in the repository's schemes and other folders.
Cables and connectors
From the parts list.
- USBC to USBC wire × 1


