Thor
Thor is an open source, 3D printed, 6 degrees of freedom robotic arm designed to be affordable and accessible for education and makers.
- Robot arm
- Open source
- ROS 2
- 3D printable
Suggested by Robotheca, created by @AngelLM (opens in a new tab), from github.com/AngelLM/Thor (opens in a new tab). Pinned to commit 286b081 (opens in a new tab).
- Hardware license
- CC-BY-SA-4.0 (opens in a new tab)
- Software license
- CC-BY-SA-4.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
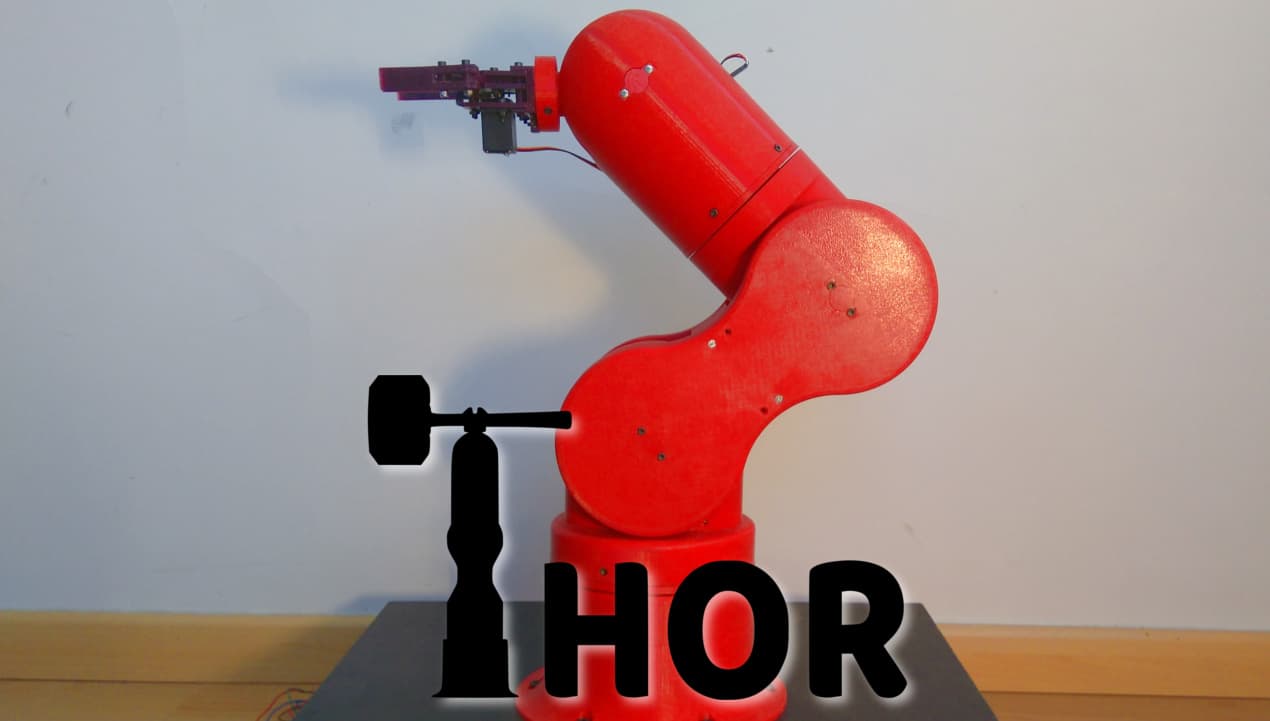
3D preview converted from github.com/AngelLM/Thor at 286b081, under CC-BY-SA-4.0. View the original files from GitHub (32.8 MB) (opens in a new tab)
- Height
- 625 mm
- Payload
- 750 g
What it can do
Written by Robotheca from the project's documents.
- Six degrees of freedom 3D-printed robotic arm with a yaw-roll-roll-yaw-roll-yaw configuration.
- Stretched height of 625mm without end effector and a payload capacity of up to 750g including end effector.
- Moves using G-code, the same language used by 3D printers and CNC machines.
- Optional ROS2 integration, with Moveit2 configuration files in a related repository.
- Motion is controlled with Asgard, a control software with a simple interface for the robot's motors.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Print the parts
- 2Get the hardware
- 3Assemble the robot
- 4Assemble and set up the electronics
- 5Install the firmware
- 6Control the robot
The guide appears here as you scroll.
Guide by @AngelLM (README.md), under CC-BY-SA-4.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Stepper motors drive the joints.
- Arduino Mega shield, designed in a related repository, controls the robot.
- Firmware based on GRBL, with RRF also mentioned among the software used.
- Printed gears, GT2 pulleys and belts form the transmission, which is not an electronic part.
Connections
- The documents describe the wiring and connections only as covered in the external online electronics guide, so no details are given here.